Week-7 Challenge: DC Motor Control
AIM:
1.
A. Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
B. Comment on the armature current shoot-up from the scope results.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
2. Develop a 2-quadrant chopper using simulink & explain the working of the same with the relevant results.
3. Explain in a brief about operation of BLDC motor.
INTRODUCTION:
BJT (Bipolar junction tansistor):-
The Bipolar Junction Transistor (BJT) when used for power switching applications, operates as an IGBT. When it is conducting (BJT operating in the saturated region), a forward voltage Vf is developed between collector and emitter (in the range of 1 V). Therefore, the IGBT block can be used to model the BJT device.
The IGBT block implements a semiconductor device controllable by the gate signal. The IGBT is simulated as a series combination of a resistor Ron, inductor Lon, and a DC voltage source Vf in series with a switch controlled by a logical signal
The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models). Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off. When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
1 (A) Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
* Open the matlab document and search for "Speed control of a DC motor using BJT H-bridge"
* The result tab open, select the model and click open.
* Open the window in simulink workspace.
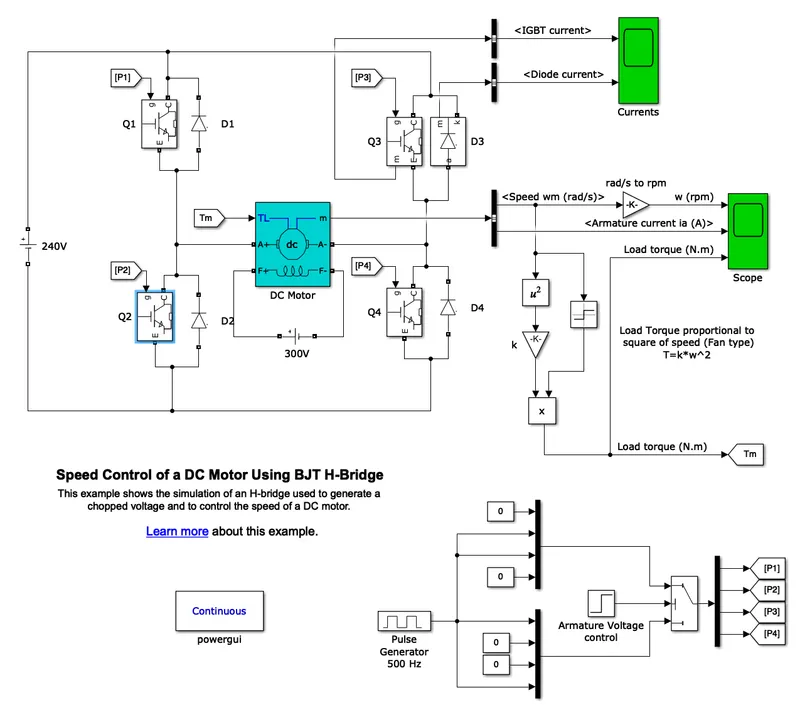
* Run the simulation as it is
* By the default Pulse width is 75%
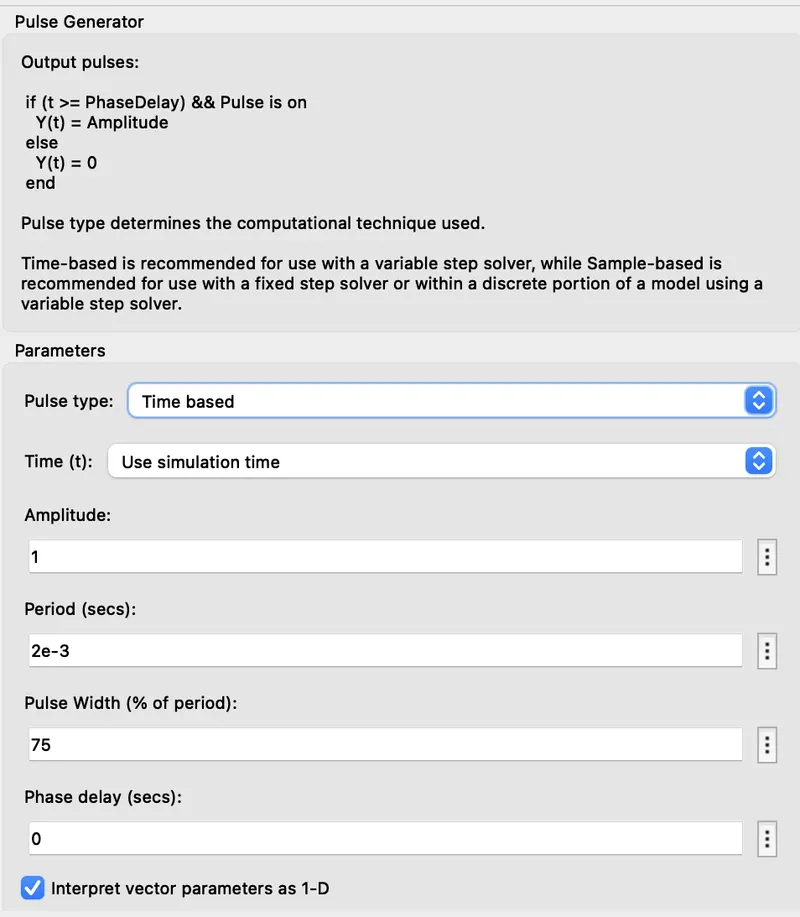
Result (Pulse width =75%)
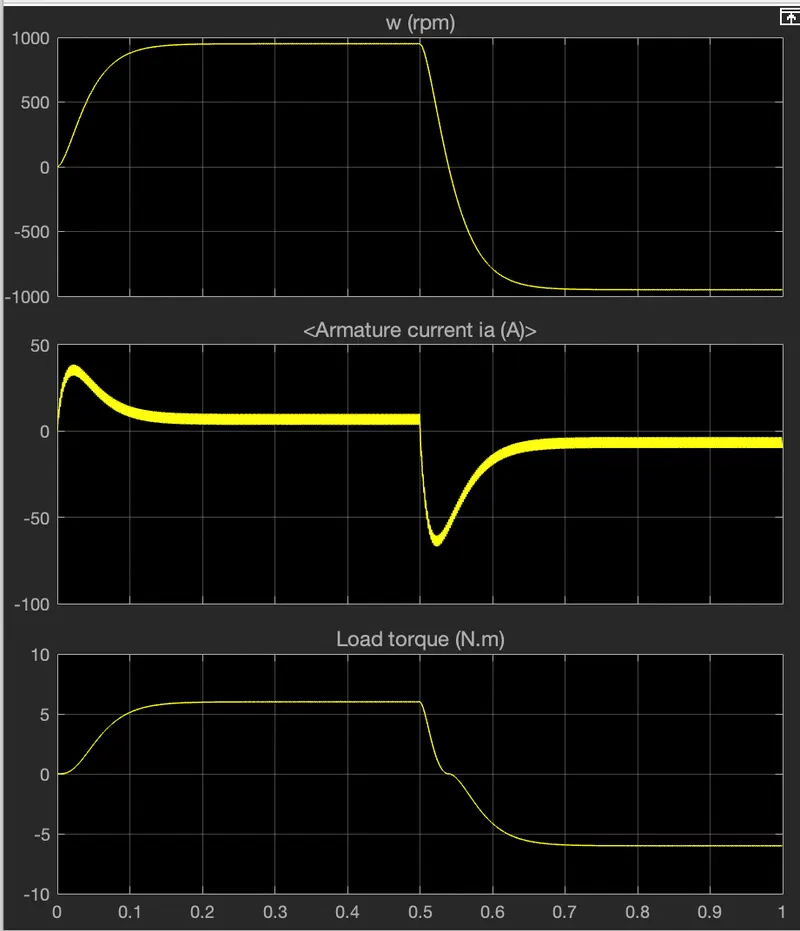
(B) For the the armature current shoot-up from the scope results change the pulse width as 55%,35%.
*By changing the Armature current having Pulse width 55%.
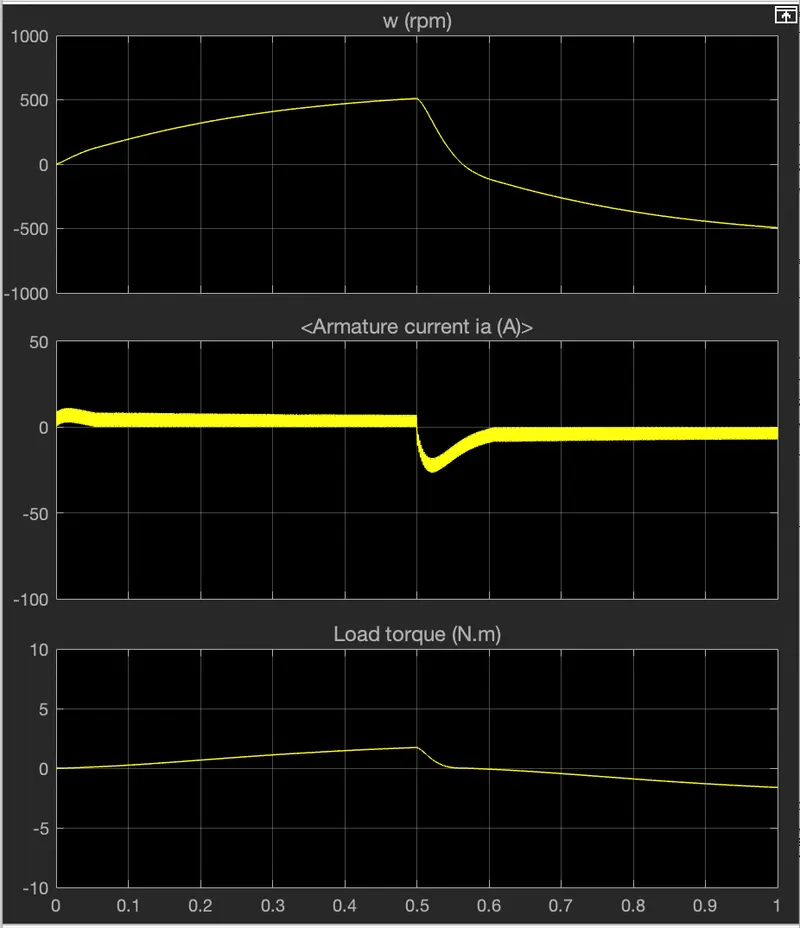
*By changing the Armature current having Pulse width 35%.
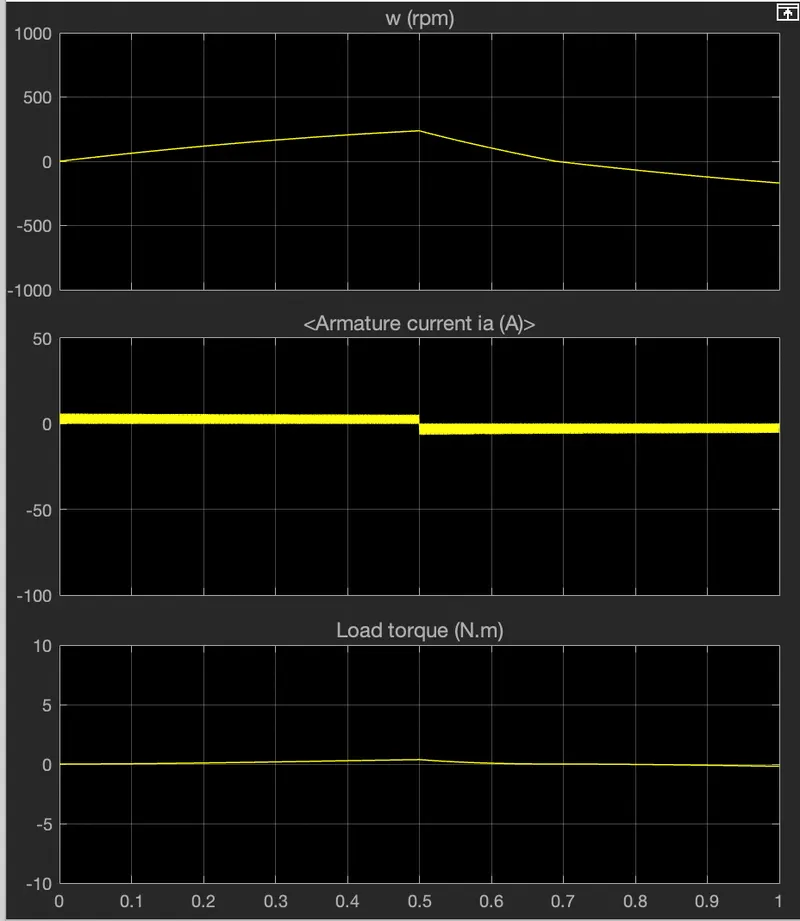
* As pulse width decreases the steap value of the armature current decreases.In last we can see that Current flow smootly compering to the first one
* This shoot up happens because of the switching in the circuit that cause heat losses during switching. To avoid these losses, we use HEAT SINK material to dissipate the heat. From this the motor can change its direction of rotation easily and very smoothly.
(C) The Four-Quadrant Chopper DC Drive:
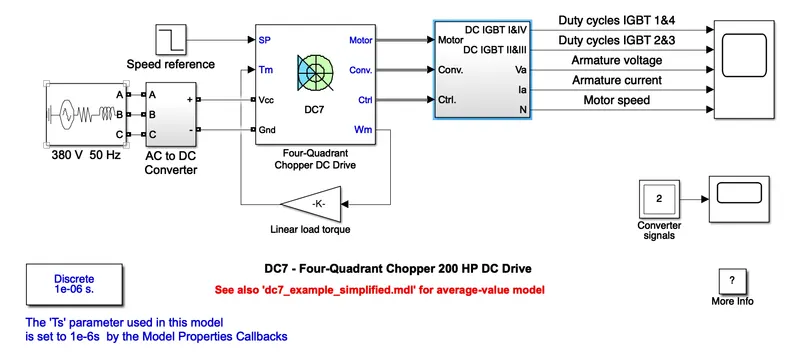
The Four-Quadrant Chopper DC Drive (DC7) block represents a four-quadrant, DC-supplied, chopper (or DC-DC PWM converter) drive for DC motors. This drive features closed-loop speed control with four-quadrant operation. The speed control loop outputs the reference armature current of the machine. Using a PI current controller, the chopper duty cycle corresponding to the commanded armature current is derived. This duty cycle is then compared with a sawtooth carrier signal to obtain the required PWM signals for the chopper.
The first regulator is a speed regulator, followed by a current regulator. The speed regulator outputs the armature current reference (in p.u.) used by the current controller in order to obtain the electromagnetic torque needed to reach the desired speed.The current regulator controls the armature current by computing the appropriate duty ratios of the 5 kHz pulses of the four IGBT devices (Pulse Width Modulation).
RESULT
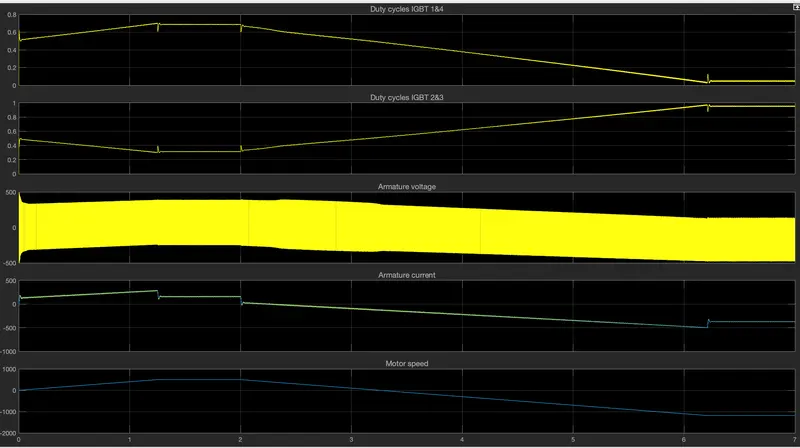
The current values are continuous in BJT and In Four Quadrants it is chopped so that the simulation takes less time.To change the direction of the motor, current signals are interrupted in four quadrants. Whereas in BJT the polarity of the current needs to be changed.The main advantage of Four quadrant is that it operates in all the four quadrants but BJT can movie only is two directions.Four Quadrants provides better efficiency and operates at high power levels when compared to BJT that operates at moderate power levels.
2 . 2-quadrant chopper using simulink:
The Two-Quadrant Chopper DC Drive (DC6) block represents a two-quadrant, DC-supplied, chopper (or DC-DC PWM converter) drive for DC motors. This drive features closed-loop speed control with two-quadrant operation. The speed control loop outputs the reference armature current of the machine. Using a PI current controller, the chopper duty cycle corresponding to the commanded armature current is derived. This duty cycle is then compared with a sawtooth carrier signal to obtain the required PWM signals for the chopper.
The main advantages of this drive, compared with other DC drives, are its implementation simplicity and that it can operate in two quadrants (forward motoring and reverse regeneration). In addition, due to the use of high switching frequency DC-DC converters, a lower armature current ripple (compared with thyristor-based DC drives) is obtained. However, for all two-quadrant DC drives, reversible and regenerative operations (reverse motoring and forward regeneration), which are required in most DC drives, cannot be obtained.
The Two-Quadrant Chopper DC Drive block uses these blocks from the Electric Drives/Fundamental Drive Blocks library:
Speed Controller (DC)
Regulation Switch
Chopper
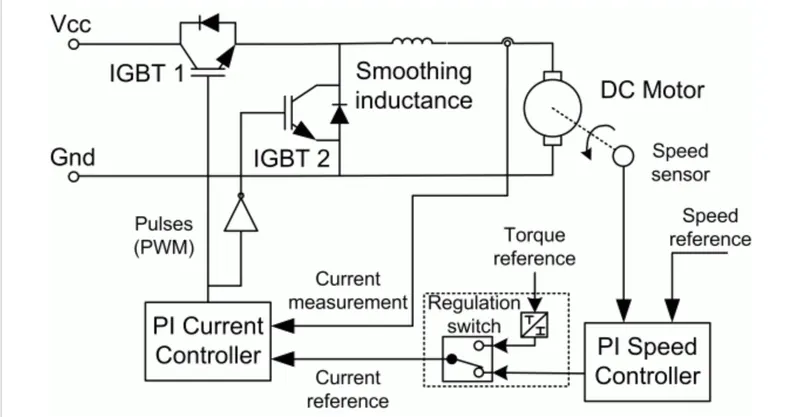
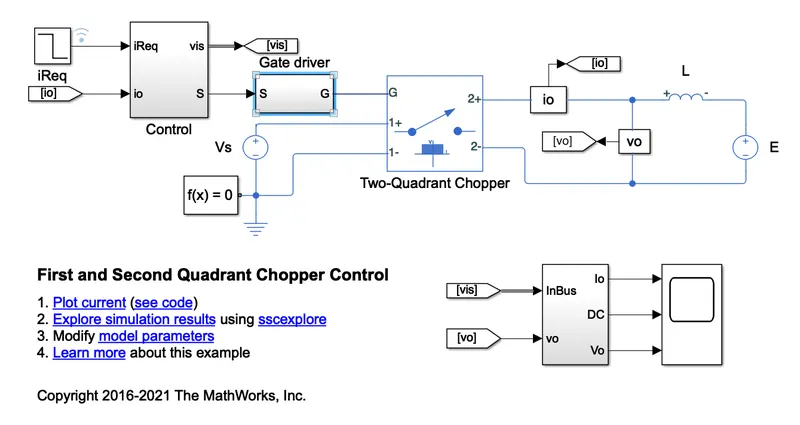
In the defaullt condition Setp time is of 0.2 and the threshold voltage applied is 0.5. result that we get is.
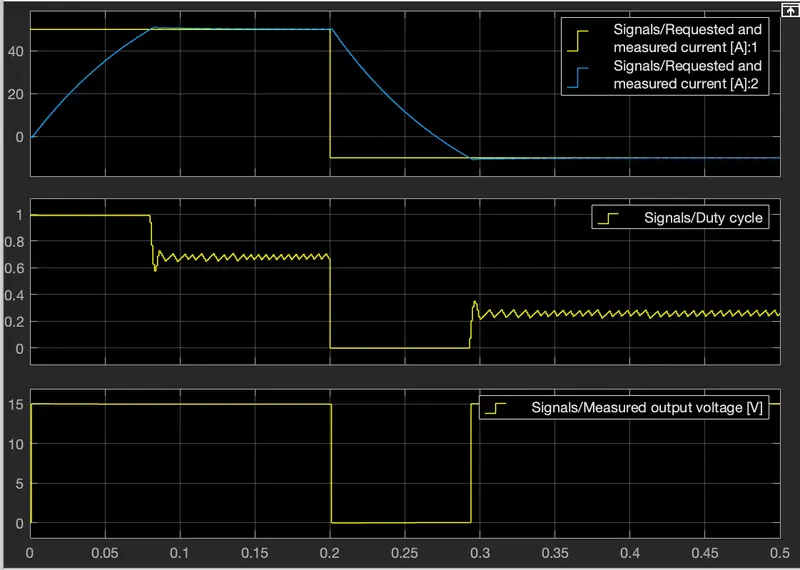
3. Explain in a brief about operation of BLDC motor.
Introduction
A brushless DC electric motor (BLDC motor or BL motor), also known as an electronically commutated motor (ECM or EC motor) or synchronous DC motor, is a synchronous motor using a direct current (DC) electric power supply. It uses an electronic closed looped controller to switch DC currents to the motor windings producing magnetic fields which effectively rotate in space and which the permanent magnet rotor follows. The controller adjusts the phase and amplitude of the DC current pulses to control the speed and torque of the motor. This control system is an alternative to the mechanical commutators (brushes) used in many conventional electric motors.
Construction
In this motor, the permanent magnets attach to the rotor. The current-carrying conductors or armature windings are located on the stator. They use electrical commutation to convert electrical energy into mechanical energy. The main design difference between a brushed and brushless motors is the replacement of mechanical commutator with an electric switch circuit. A BLDC Motor is a type of synchronous motor in the sense that the magnetic field generated by the stator and the rotor revolve at the same frequency.
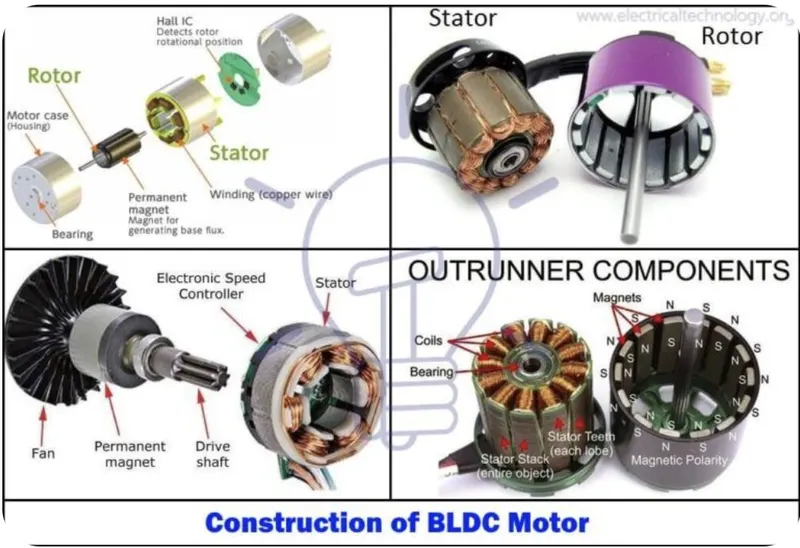
Working principle
BLDC motor works on the principle similar to that of a conventional DC motor, i.e., the Lorentz force law which states that whenever a current carrying conductor placed in a magnetic field it experiences a force. As a consequence of reaction force, the magnet will experience an equal and opposite force. In case BLDC motor, the current carrying conductor is stationary while the permanent magnet moves.
When the stator coils are electrically switched by a supply source, it becomes electromagnet and starts producing the uniform field in the air gap. Though the source of supply is DC, switching makes to generate an AC voltage waveform with trapezoidal shape. Due to the force of interaction between electromagnet stator and permanent magnet rotor, the rotor continues to rotate.
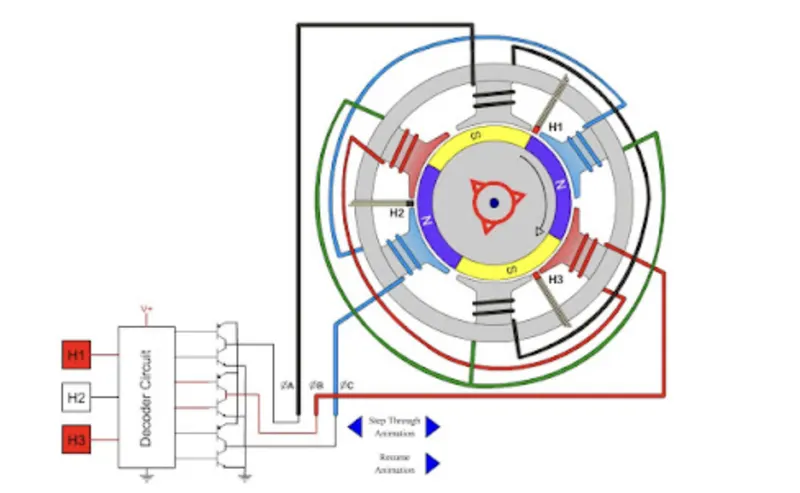
In simple words, a BLDC has no brushes and commutator for having unidirectional torque rather integrated inverter / switching circuit is used to achieve unidirectional torque. That is why these motors are, sometimes, also referred as Electronically Commutated Motors.