Week-7 Challenge: DC Motor Control
Que.1:A. Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
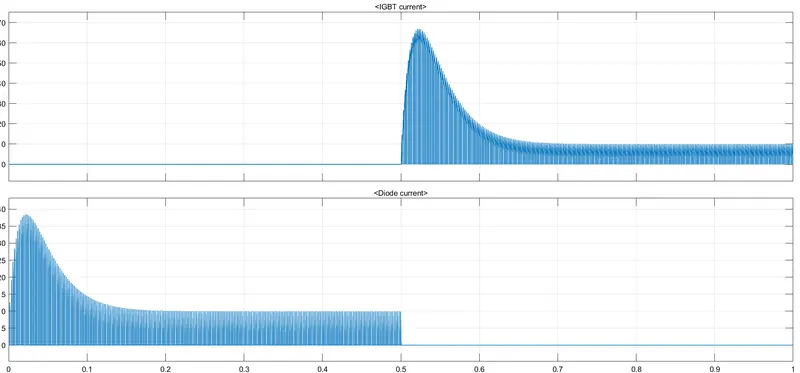
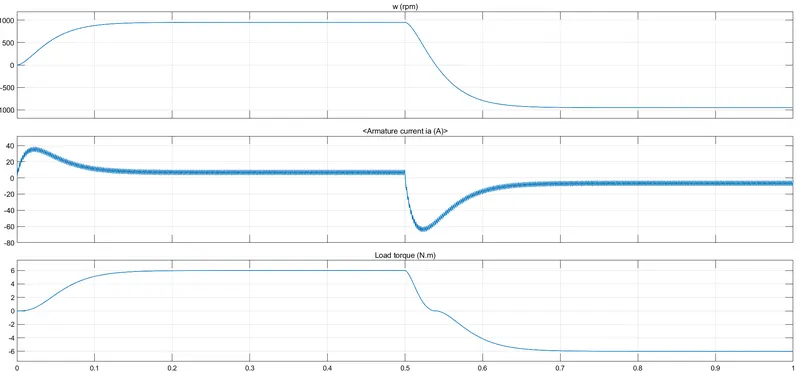
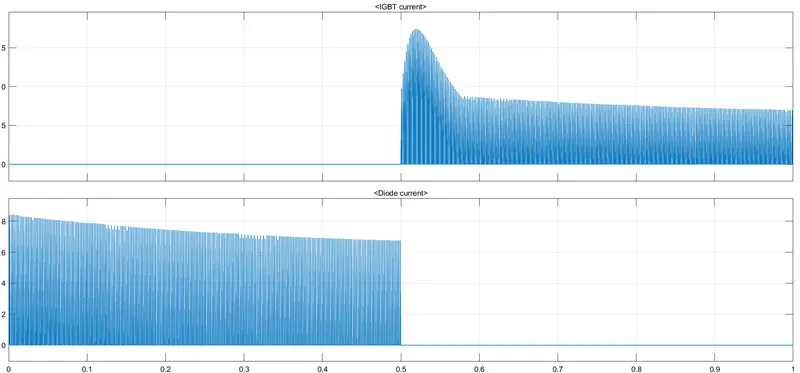
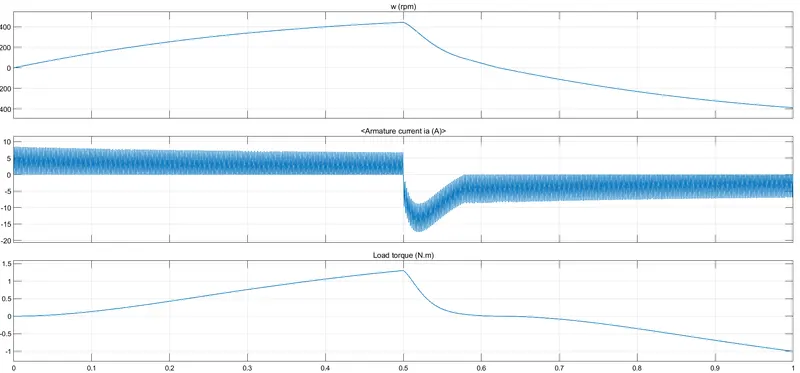
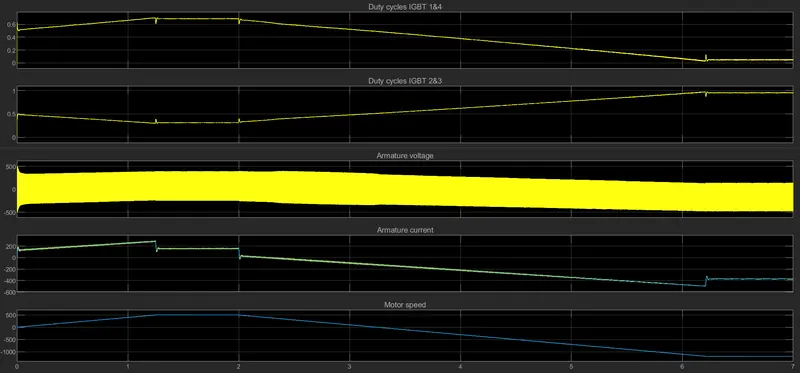
B. Comment on the armature current shoot-up from the scope results.
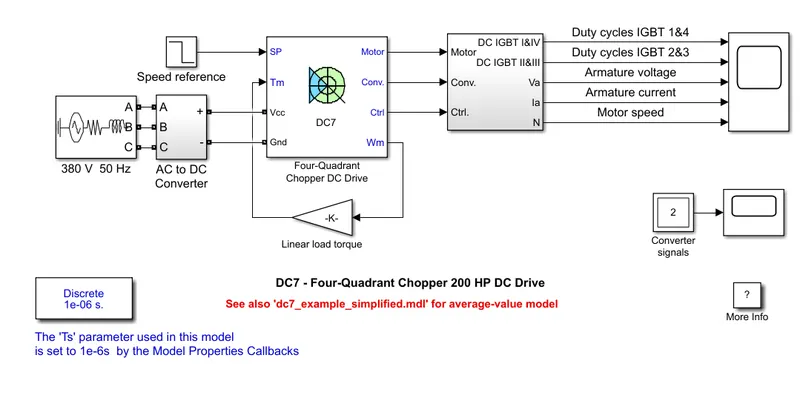
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
Ans:
A)"Speed Control of a DC Motor Using BJT H-Bridge":
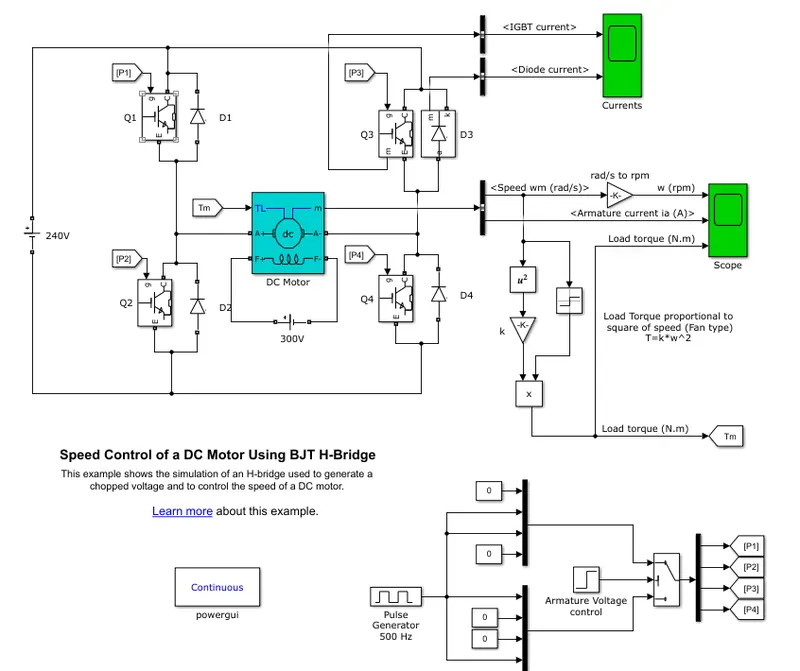
Fig.1. The simulation of an H-bridge used to generate a chopped voltage and to control the speed of a DC motor.
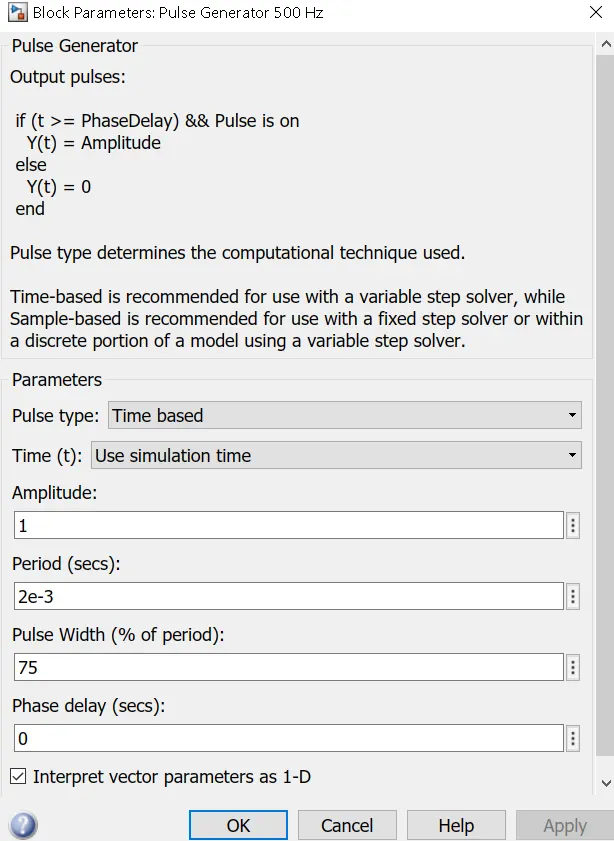
Conclusion:
Based on the above simulation performed we get the following result on the scope:
- The plot of duty cycles IGBT 1&4 are exactly opposite to that of duty cycles IGBT 2&3 as the pulse width of IGBT devices 1 and 4 are opposite to those of IGBT devices 2 and 3.
- The desired armature current is obtained from the average armature voltage.
- The armature current follows the current reference very well, with fast response time and small ripples.
Note-
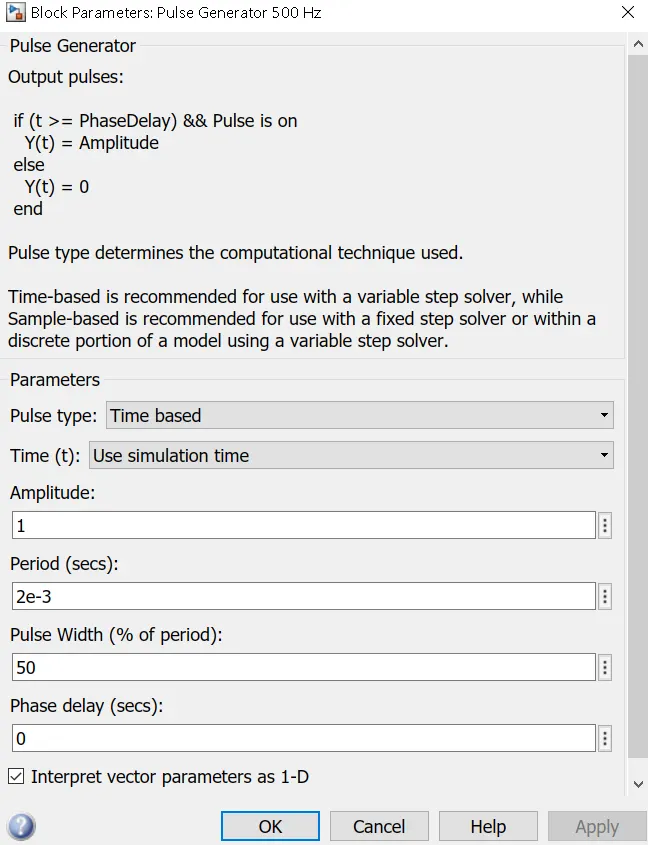
- The power system has been discretized with a 1 us time step. The speed and current controllers use a 100 us and 20 us sampling time respectively in order to simulate a microcontroller control device.
- In order to reduce the number of points stored in the scope memory, a decimation factor of 25 is used. Some transitions may thus not appear on the scope. To view detailed simulation results, reduce the decimation factor to 1.
- A simplified version of the model using an average-value converter can be used by selecting 'Average' in the 'Model detail level' menu of the graphical user-interface. The time step can then be increased up to the smallest control system sample time value. This can be done by typing 'Ts = 20e-6' in the workspace in the case of this example. See also dc7_example_simplified model.
ii)Comparison of Four Quadrant Chopper DC Drive(DC7) with BJT H bridge:
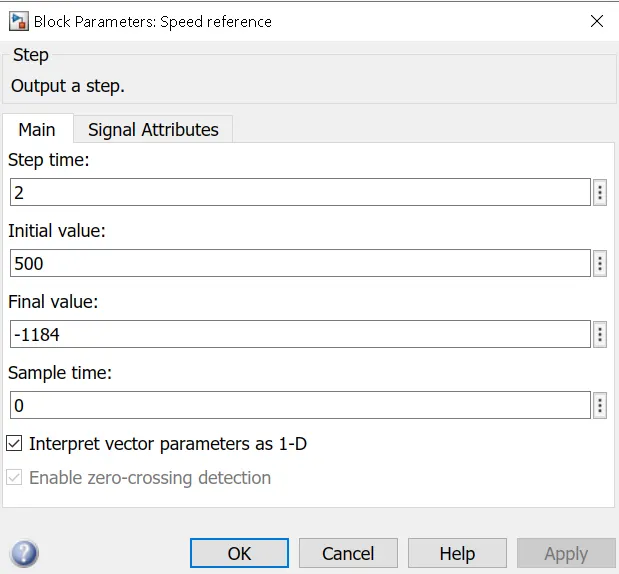
- In four quadrant chopper DC drive model, the speed reference input is used to change the direction of the motor rotation whereas in BJT H-bridge model, the polarity is reversed across the terminals of the motor with respect to the battery, to change the direction of the motor rotation.
- In four quadrant chopper, the speed reference values is changed to control the speed of the motor whereas, in BJT H-bridge the speed of the motor is controlled by varying the with of the pulse in pulse generator.
- The four quadrant chopper DC drive operates in four mode i.e, forward motoring, forward regenerative breaking, reverse motoring and reverse regenerative braking whereas, BJT H- bridge only operates in two modes i.e, forward and reverse.
- PI (Proportional) controllers are used for speed and current control in DC7 and it is absent in BJT H- bridge.
- The four quadrant chopper uses ramps to avoid current shoot up and smooth working and stability.
- The disturbances and current shoot up is low in DC7 whereas for BJT the shoot up is high because of switching losses.
- Due to the high switching frequency in the four quadrant chopper (DC-DC converters), a low armature current is obtained.
- This why the overall performance and stability is good in Four Quadrant Chopper DC Drive as compared to BJT H- bridge model.
- Only disadvantages is due to its complexity as it consist of four switching devices.
Que.2:Develop a 2-quadrant chopper using simulink & explain the working of the same with the relevant results. (Refer to article - Multiquadrant operation of motor )
Ans:
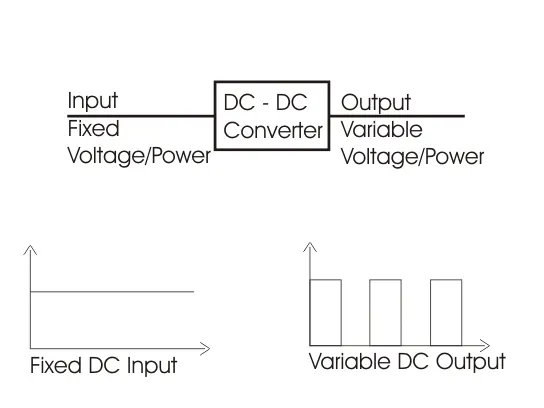
Chopper- A DC to DC converter, also known as dc chopper, is a static device which is used to obtain a variable dc voltage from a constant dc voltage source. . It is nothing but a high speed switch which connects and disconnects the load from source at a high rate to get variable or chopped voltage at the output.
Symbol of Chopper:
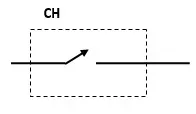
These devices are represented as a switch in a dotted box for simplicity. When it is closed current can flow in the direction of arrow only.
Choppers are widely used in trolley cars, battery-operated vehicles, traction motor control, control of large numbers of dc motors, etc.
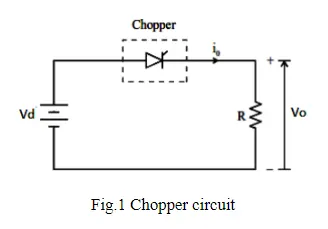
Devices Used in chopper:
Low power application: GTO, IGBT, Power BJT, Power MOSFET etc.
High power application: Thyristor or SCR.
Depending on the voltage output, choppers are classified as −
- Step Up chopper (Boost converter)
- Step Down Chopper (Buck converter)
- Step Up/Down Chopper (Buck−boost converter)
In step-down choppers, the output voltage will be less than the input voltage, whereas in step-up choppers output voltage will be more than the input voltage.
According to direction of output voltage and current
Semiconductors devices used in chopper circuit are unidirectional. But arranging the devices in proper way we can get output voltage as well as output current from chopper in our required direction. So, on the basis of this features chopper can be categorized as follows :
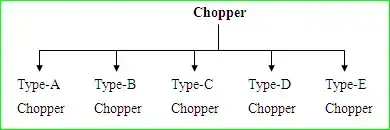
Type-A Chopper:
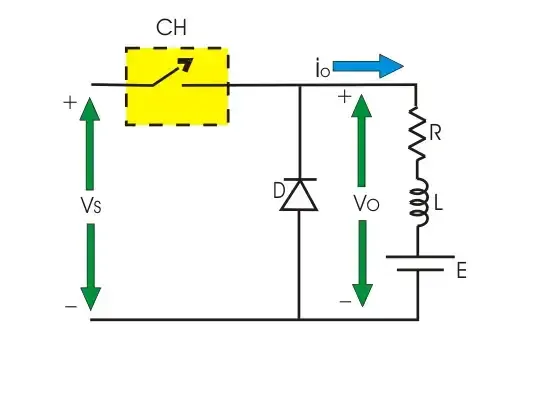
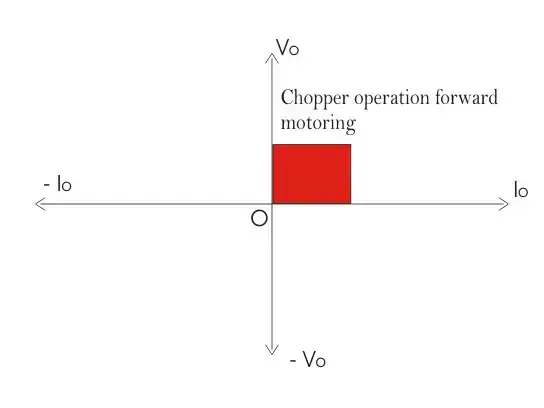
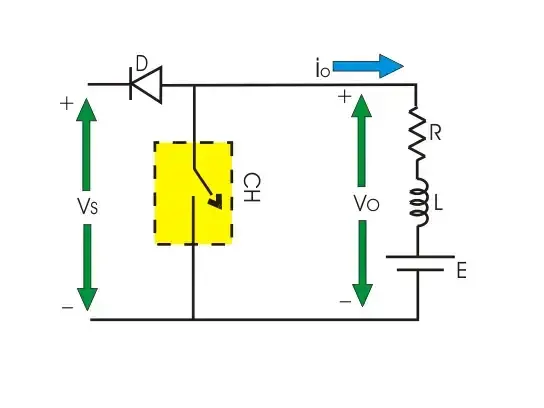
It is a single quadrant chopper whose operation is restricted in first quadrant of Vo – Io plane. The circuit diagram is shown as below :
When CH is ON both Vo and Io follows the direction as marked in the figures. So, both are taken as positive hence load power is positive which means power is delivered from source to land.
When CH is OFF current freewheels through diode. Hence Vo is zero and Io is positive.
In type-A chopper it is seen that average value of Vo and Io is always positive. This is also called step down chopper as average value of Vo is less than the input voltage. This type of chopper is suitable for motoring operation.
Type-B Chopper:
This is also a single quadrant chopper operating in second quadrant of Vo – Io plane. The circuit diagram is shown in the following figure.
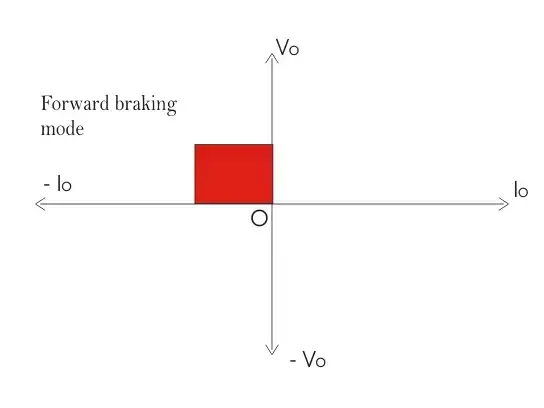
It is interesting to note that load must have a DC voltage source E for this kind of operation.When CH is ON Vo is zero but current flows in the opposite direction as marked in figure. When chopper is OFF.Which exceeds the source voltage VS. So current flows through diode D and treated as negative.Hence current Io is always negative here but Vo is positive (sometimes zero). So, power flows from load to source and operation of type-B chopper is restricted in second quadrant of Vo – Io plane. This type of chopper is suitable for forward braking operation.
Type-C Chopper:
This is a two quadrant chopper whose operation is bounded between first and second quadrant of Vo – Io plane. This type of chopper obtained by connecting type-A and type-B chopper in parallel as shown in the figure.
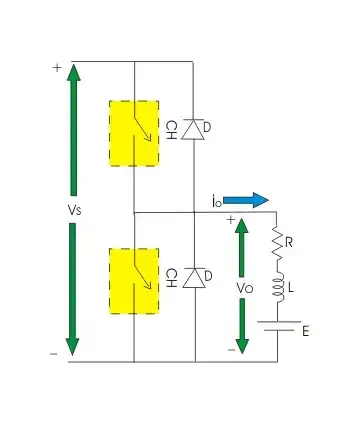
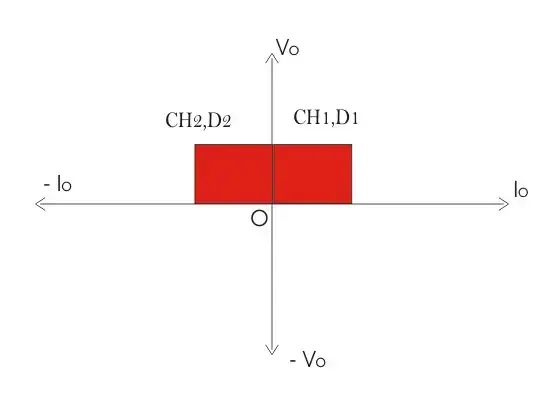
When CH1 is ON current flows through abcdefa and inductor L will be charged. Hence output voltage Vo and current Io both will be positive. When CH1 is OFF, induction will discharge through D1 and current Io will flow through same direction with zero output voltage. So, we can see the operation of CH1 is nothing but the operation of type-A chopper by which we can operate a chopper in the first quadrant.
When CH2 is ON, output voltage Vo will be zero but output current Io will flow in opposite direction of current shown in the figure and inductor will be charged up. When CH2 is OFF Output voltage.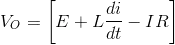
Which exceeds the value of source voltage VS. So current flows through diode D2 and treated as negative. Hence output voltage Vo is always positive and output current Io is always negative here. We can see operation of CH2 is nothing but operation of type-B chopper by which we can operate the chopper in the second quadrant.
We can conclude that the operation of type-C chopper is the combined operation of type-A and type-B chopper. This type of chopper is suitable for both forward motoring and forward braking operation.
Simulink Model:
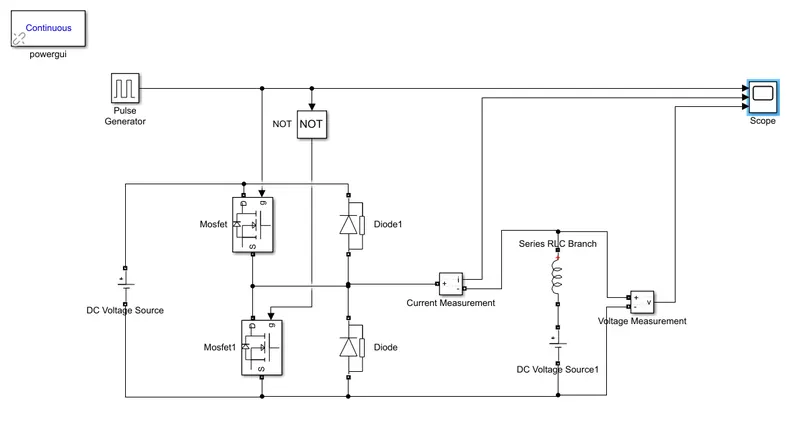
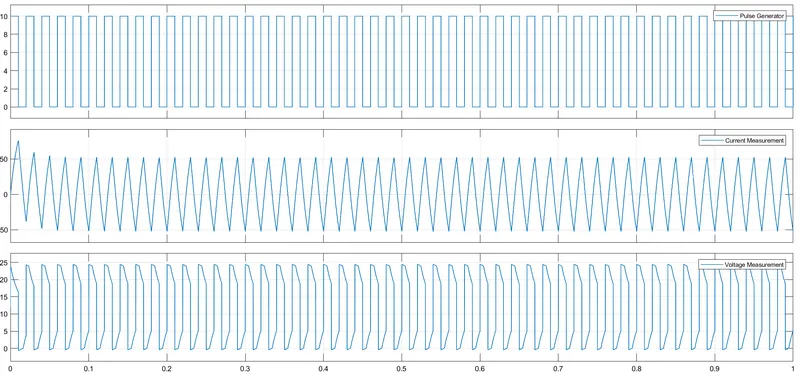
Observation/Results:
1)Pulse Generator:
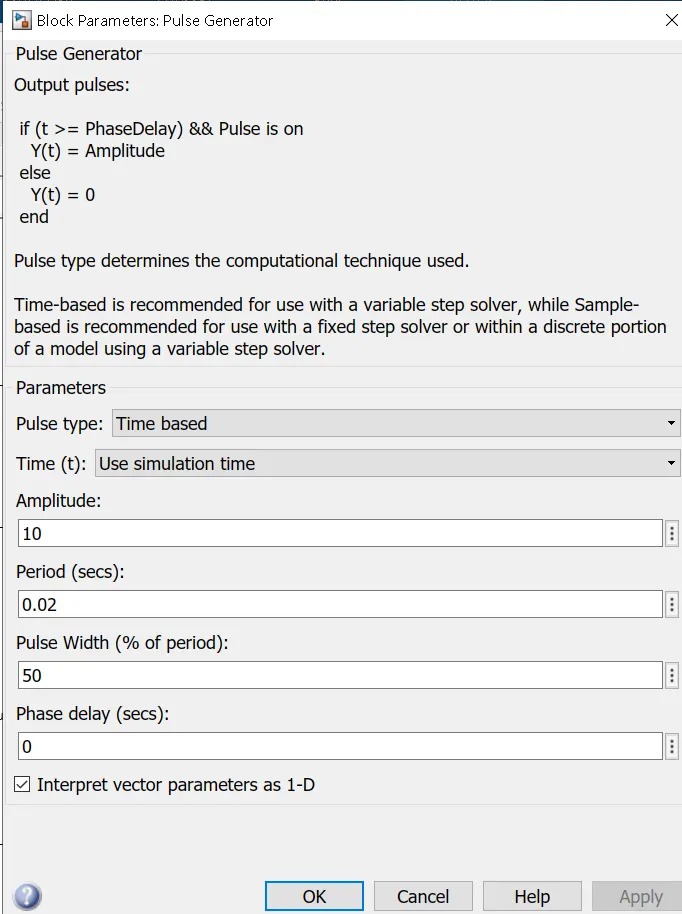
2)Input Supply Voltage:
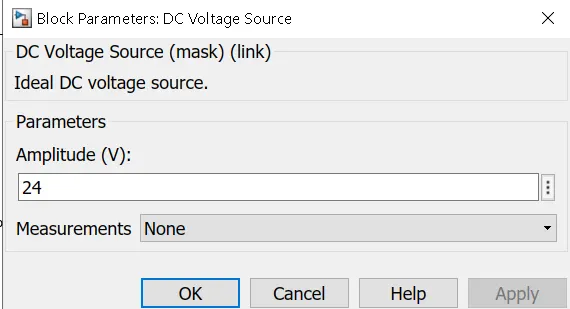
3)Load side applied Voltage:
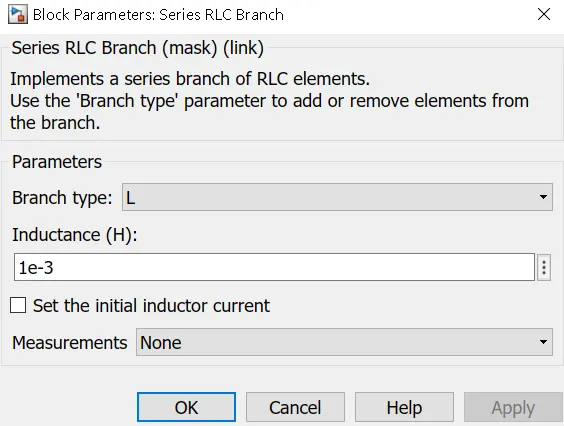
4)Applied Load:
5)Scope Results:
Que.3:Explain in a brief about operation of BLDC motor.
Ans:A brushless DC motor (known as BLDC) is a permanent magnet synchronous electric motor which is driven by direct current (DC) electricity and it accomplishes electronically controlled commutation system (commutation is the process of producing rotational torque in the motor by changing phase currents through it at appropriate times) instead of a mechanically commutation system. BLDC motors are also referred as trapezoidal permanent magnet motors.
These types of motors are highly efficient in producing a large amount of torque over a vast speed range. In brushless motors, permanent magnets rotate around a fixed armature and overcome the problem of connecting current to the armature. Commutation with electronics has a large scope of capabilities and flexibility. They are known for smooth operation and holding torque when stationary.
Construction Of BLDC Motor:BLDC motors can be constructed in different physical configurations. Depending on the stator windings, these can be configured as single-phase, two-phase, or three-phase motors. However, three-phase BLDC motors with permanent magnet rotor are most commonly used.
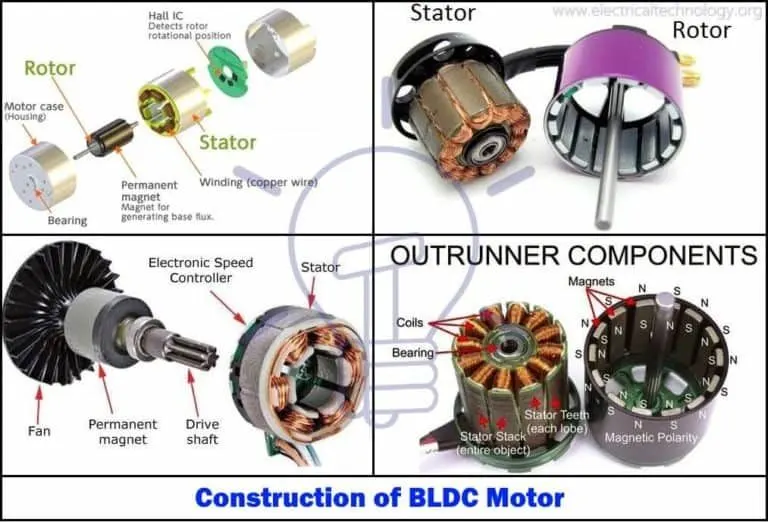
Brushless DC motor has only two basic parts: rotor and the stator. The rotor is the rotating part and has rotor magnets whereas stator is the stationary part and contains stator windings. In BLDC permanent magnets are attached in the rotor and move the electromagnets to the stator. The high power transistors are used to activate electromagnets for the shaft turns. The controller performs power distribution by using a solid-state circuit.
Hall Sensors- Hall sensor provides the information to synchronize stator armature excitation with rotor position. Since the commutation of BLDC motor is controlled electronically, the stator windings should be energized in sequence in order to rotate the motor. Before energizing a particular stator winding, acknowledgment of rotor position is necessary. So the Hall Effect sensor embedded in stator senses the rotor position.
Most BLDC motors incorporate three Hall sensors which are embedded into the stator. Each sensor generates Low and High signals whenever the rotor poles pass near to it. The exact commutation sequence to the stator winding can be determined based on the combination of these three sensor’s response.
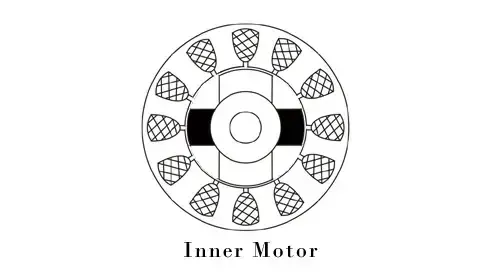
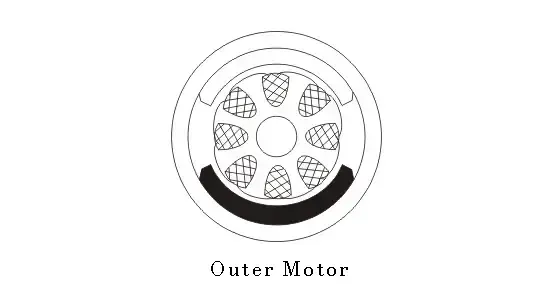
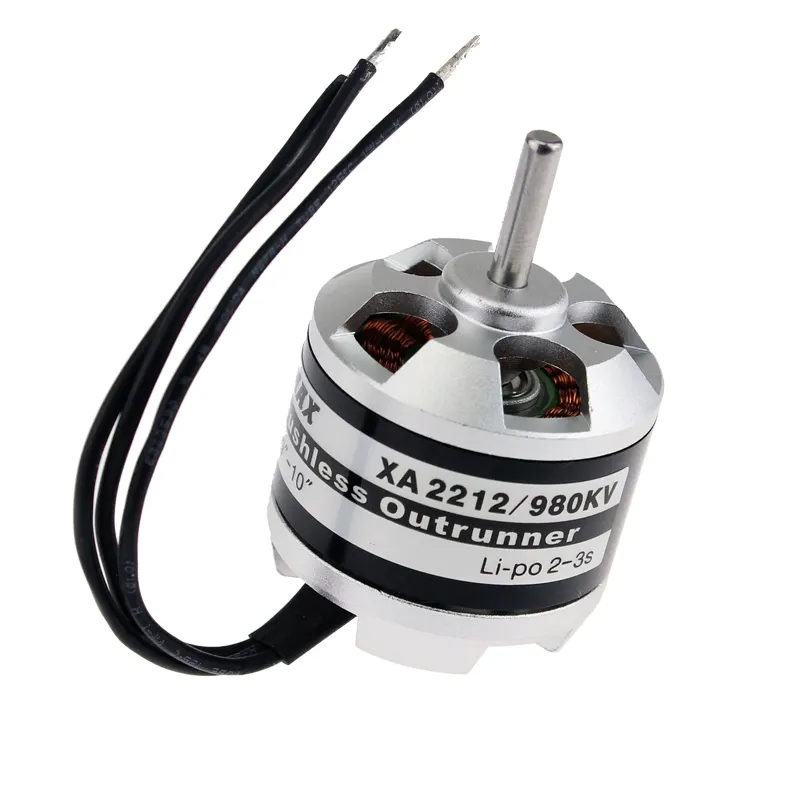
Types OF BLDC motor:Basically, BLDC are of two types, one is outer rotor motor and other is inner rotor motor. The basic difference between the two is only in designing, their working principles are same.
An Inner rotor design:In an inner rotor design, the rotor is located in the centre of the motor and the stator winding surround the rotor. As the rotor is located in the core, rotor magnets do not insulate heat inside and heat get dissipated easily. Due to this reason, inner rotor designed motor produces a large amount of torque and validly used.
Outer rotor design:In outer rotor design, the rotor surrounds the winding which is located in the core of the motor. The magnets in the rotor trap the heat of the motor inside and do not allow to dissipate from the motor. Such type of designed motor operates at lower rated current and has low cogging torque.
Working/Operation Of BLDC Motor:
Before explaining the working of a brushless DC motor, it is better to understand the function of a brushed motor. In brushes motors, there are permanent magnets on the outside and a spinning armature which contains electromagnet is inside. These electromagnets create a magnetic field in the armature when the power is switched on and help to rotate the armature.
The brushes change the polarity of the pole to keep the rotation on of the armature. The basic working principle for the brushed DC motor and for brushless DC motor are same i.e. internal shaft position feedback.
BLDC Motor operation is based on the attraction or repulsion between magnetic poles. Using the three-phase motor as shown in figure below, the process starts when current flows through one of the three stator windings and generates a magnetic pole that attracts the closest permanent magnet of opposite pole.Stator windings of a BLDC motor are connected to a control circuit (an integrated switching circuit). The control circuit energizes proper winding at proper time, in a pattern which rotates around the stator.
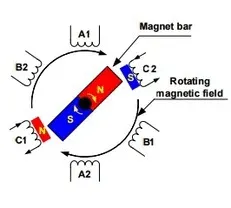
The rotor magnet tries to align with the energized electromagnet of the stator, and as soon as it aligns, the next electromagnet is energized. Thus the rotor keeps running.The rotor will move if the current shifts to an adjacent winding. Sequentially charging each winding will cause the rotor to follow in a rotating field. The torque in this example depends on the current amplitude and the number of turns on the stator windings, the strength and the size of the permanent magnets, the air gap between the rotor and the windings, and the length of the rotating arm.
Commutator helps in achieving unidirectional torque in a typical dc motor. Obviously, commutator and brush arrangement is eliminated in a brushless dc motor. And an integrated inverter/switching circuit is used to achieve unidirectional torque.
That is why these motors are, sometimes, also referred as ‘electronically commutated motors’.
Advantage Of BLDC Motor:The advantages of a BLDC motor are:
- Brushless motors are more efficient as its velocity is determined by the frequency at which current is supplied, not the voltage.
- As brushes are absent, the mechanical energy loss due to friction is less which enhanced efficiency.
- BLDC motor can operate at high-speed under any condition.
- There is no sparking and much less noise during operation.
- More electromagnets could be used on the stator for more precise control.
- BLDC motors accelerate and decelerate easily as they are having low rotor inertia.
- It is high performance motor that provides large torque per cubic inch over a vast sped rang.
- BLDC motors do not have brushes which make it more reliable, high life expectancies, and maintenance free operation.
- There is no ionizing sparks from the commutator, and electromagnetic interference is also get reduced.
- Such motors cooled by conduction and no air flow are required for inside cooling.
Disadvantage Of BLDC Motor:The disadvantages of a BLDC motor are:
- BLDC motor cost more than a brushed DC motor.
- The limited high power could be supplied to BLDC motor, otherwise, too much heat weakens the magnets and the insulation of winding may get damaged.