Week-7 Challenge: DC Motor Control
1. Run MATLAB demo ‘Speed control of a DC motor using BJT H-bridge’. Modify the model such that armature current doesn’t shoot up when motor changes direction from forward to reverse.
To know more about the Speed control of a DC motor using BJT H-bridge, we need to know about the components used in the circuit:
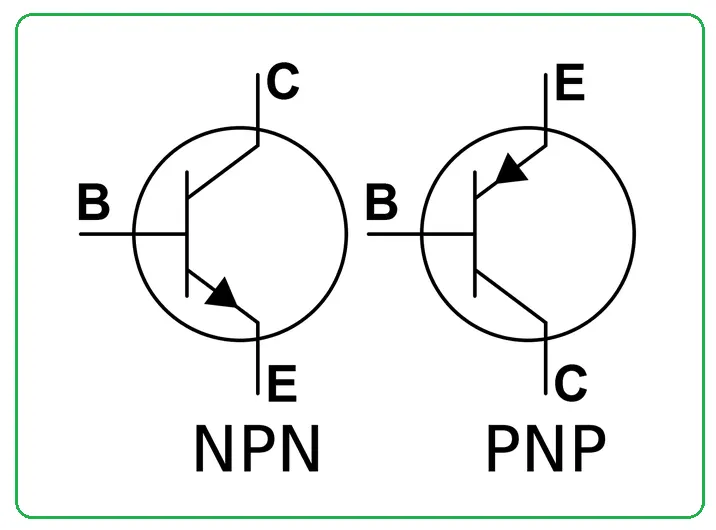
- BJT: Bipolar Junction Transistors (BJT) are current regulating devices that control the amount of current flowing through them from the Emitter to the Collector terminals in proportion to the amount of biasing voltage applied to their base terminal, thus acting like a current-controlled switch.
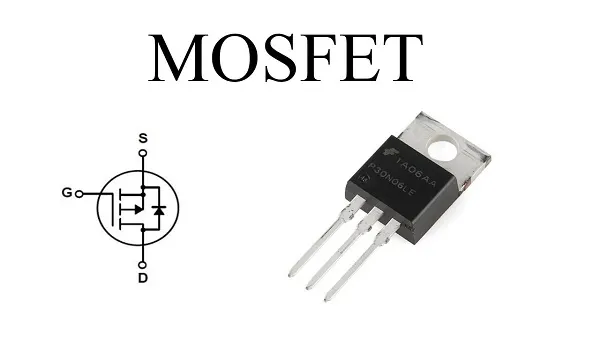
- MOSFET: The MOSFET(Metal Oxide Semiconductor Field Effect Transistor) transistor is a semiconductor device which is widely used for switching and amplifying electronic signals in the electronic devices. The MOSFET is a three terminal device such as source, gate, and drain.
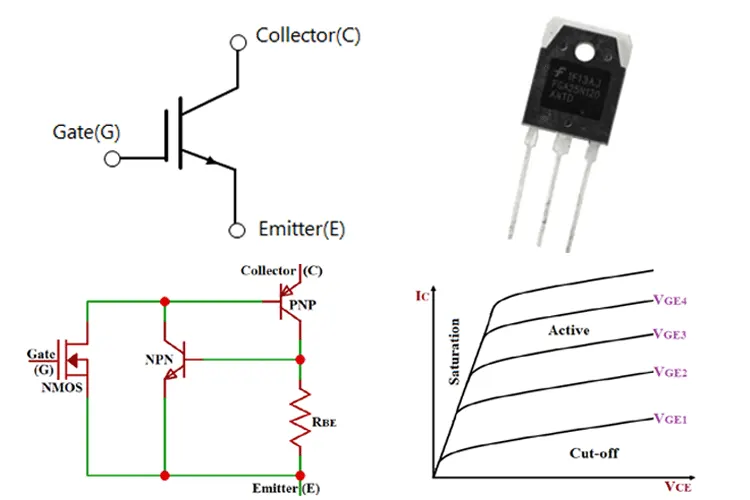
- IGBT: An Insulated Gate Bipolar Transistor (IGBT) is a key component in what makes up a VFD (Variable Frequency Drive). An IGBT is the inverter element in a VFD, pulsing voltage faster than we can even blink. An IGBT is a semiconductor with three terminals which work as a switch for moving electrical current. Just as the word “gate” suggests, when voltage is applied to the gate, it opens or “turns on” and creates a path for current to flow between the layers. If no voltage is applied to the gate, or if the voltage is not high enough, the gate remains closed and there will be no flow of electricity. In this way, an IGBT behaves like a switch: on when the gate is open and flowing current and off when it is closed. Thus the IGBT acts as the switch used to create Pulse-Width Modulation (PWM). An IGBT will switch the current on and off so rapidly that less voltage will be channelled to the motor, helping to create the PWM wave.
Speed control of a DC motor using BJT H-Bridge:
The Bipolar Junction Transistor (BJT) when used for power switching applications and operates as an IGBT. When it is conducting (BJT operating in the saturated region), a forward voltage Vf is developed between collector and emitter (in the range of 1 V). Therefore, the IGBT block can be used to model the BJT device.
The IGBT block does not simulate the gate current controlling the BJT or IGBT.
The switch is controlled by a Simulink signal (1/0). The DC motor uses the preset model (5 HP 24V 1750 rpm). It simulates a fan type load (where Load torque is proportional to square of speed). The armature mean voltage can be varied from 0 to 240 V when the duty cycle (specified in the Pulse Generator block) is varied from 0 to 100%.
The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models). Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off. When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
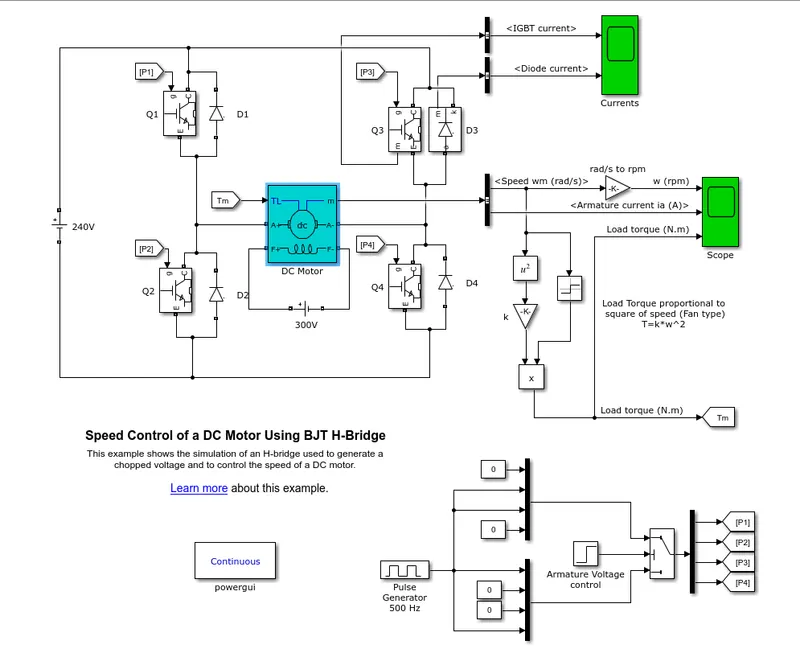
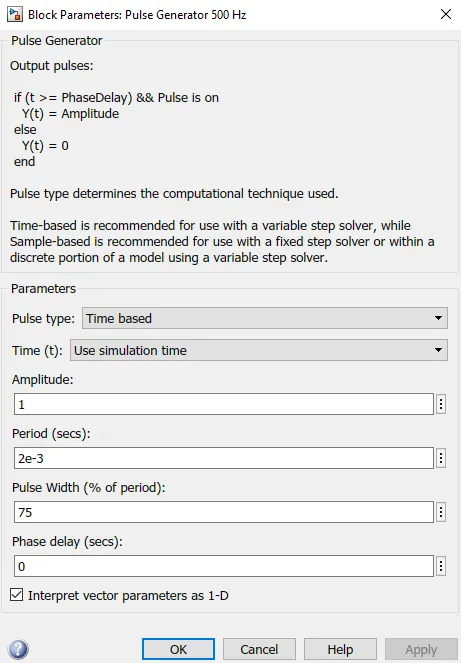
The Pulse Generator is used to generate pulses which are fed to the four IGBTs to create Pulse Width Modulation. Here in this model, the simulation is such that the motor starts in the positive direction with a duty cycle of 75% (mean DC voltage of 180V). 'Scope' shows motor speed, armature current and load torque and 'Currents' shows currents flowing in BJT Q3 and diode D3.
Initial the Block Parameters for Pulse Generator are as follows:
When we run the model, we get the following results:
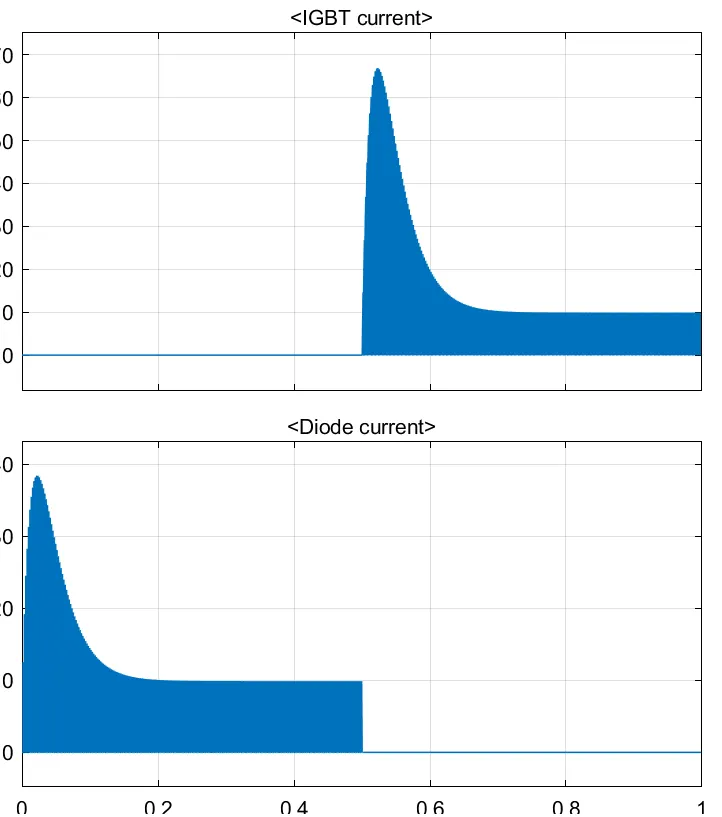
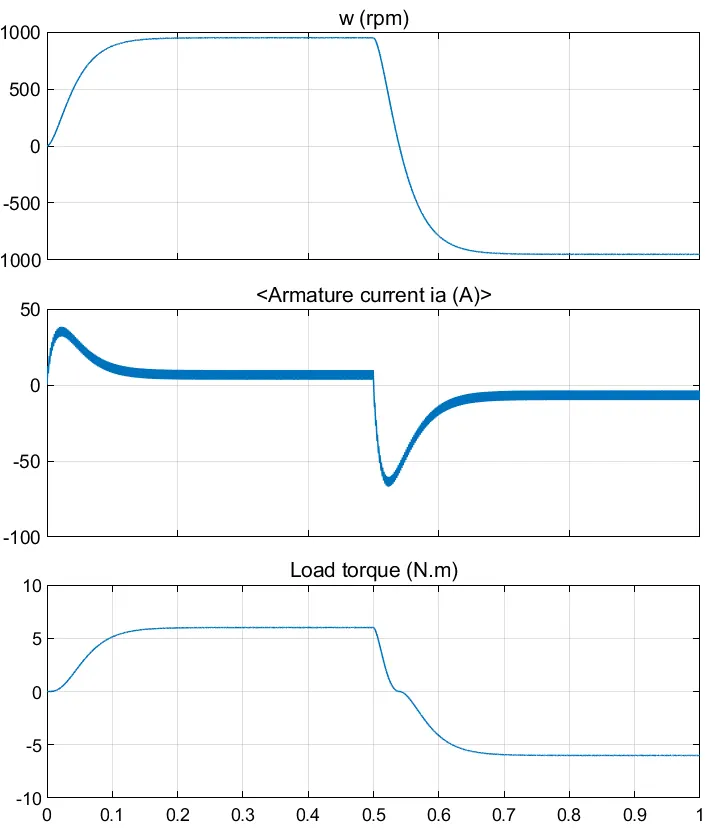
At t = 0.5 sec., the armature voltage is suddenly reversed and the motor runs in the negative direction. So in the first half cycle, we can see the motor attains a speed of 1000 rpm a load torque of 6 N.m whereas the second half cycle the same values in the negative direction. Here we can see that the armature current of DC motor does get shoot up. To avoid this, we will have to reduce the pulse width from the pulse generator.
We can modify the model by reducing the Pulse width to 40%.
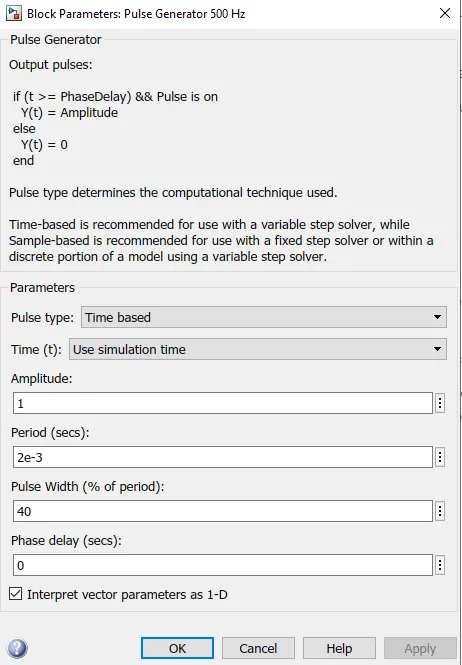
After Modifying:
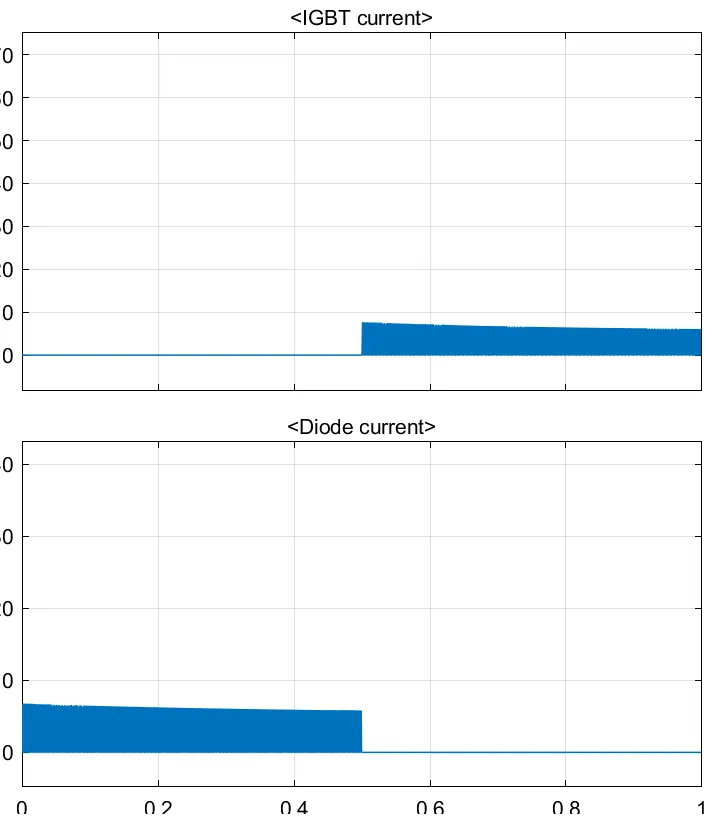
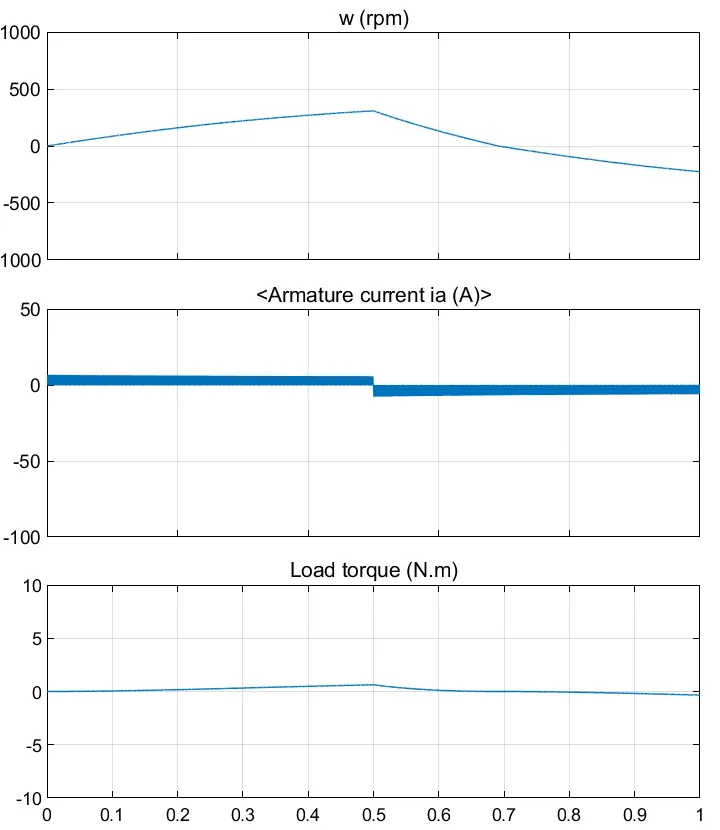
When we run the model after the modification, we get the following results:
Here we can observe that the Armature current is almost 0 A, that means the armature current doesn’t shoot up at 40% pulse width. Also the motor speed and torque is reduced to 300 rpm and 0.6 N.m respectively due to the reduction in Pulse width. This indicates that, as we reduce the pulse width, the motor speed and torque reduces and can attain zero at a certain value.
Refer to help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with H-bridge model.
The Four-Quadrant Chopper DC Drive (DC7) block:
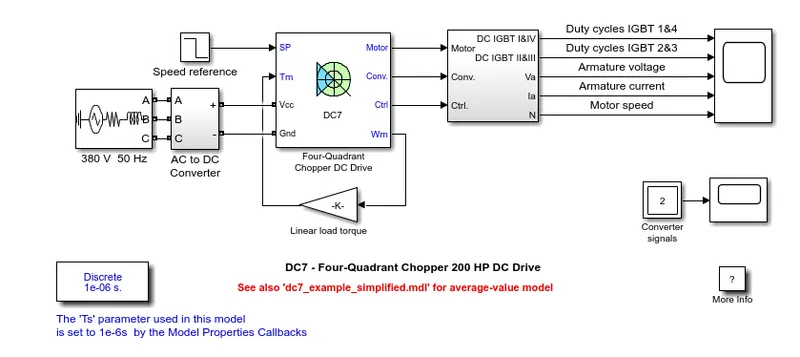
Description:
The 200 HP DC motor is separately excited with a constant 150 V DC field voltage source. The armature voltage is provided by an IGBT converter controlled by two PI regulators. The converter is fed by a 515 V DC bus obtained by rectification of a 380 V AC 50 Hz voltage source. In order to limit the DC bus voltage during dynamic braking mode, a braking chopper has been added between the diode rectifier and the DC7 block.
The first regulator is a speed regulator, followed by a current regulator. The speed regulator outputs the armature current reference (in p.u.) used by the current controller in order to obtain the electromagnetic torque needed to reach the desired speed. The speed reference change rate follows acceleration and deceleration ramps in order to avoid sudden reference changes that could cause armature over-current and destabilize the system. The current regulator controls the armature current by computing the appropriate duty ratios of the 5 kHz pulses of the four IGBT devices (Pulse Width Modulation). For proper system behaviour, the instantaneous pulse values of IGBT devices 1 and 4 are opposite to those of IGBT devices 2 and 3. This generates the average armature voltage needed to obtain the desired armature current. In order to limit the amplitude of the current oscillations, a smoothing inductance is placed in series with the armature circuit.
The main advantage of this drive, compared with other DC drives, is that it can operate in all four quadrants (forward motoring, reverse regeneration, reverse motoring, and forward regeneration). In addition, due to the use of high switching frequency DC-DC converters, a lower armature current is obtained. However, four switching devices are required, which increases the complexity of the drive system.
Simulation :
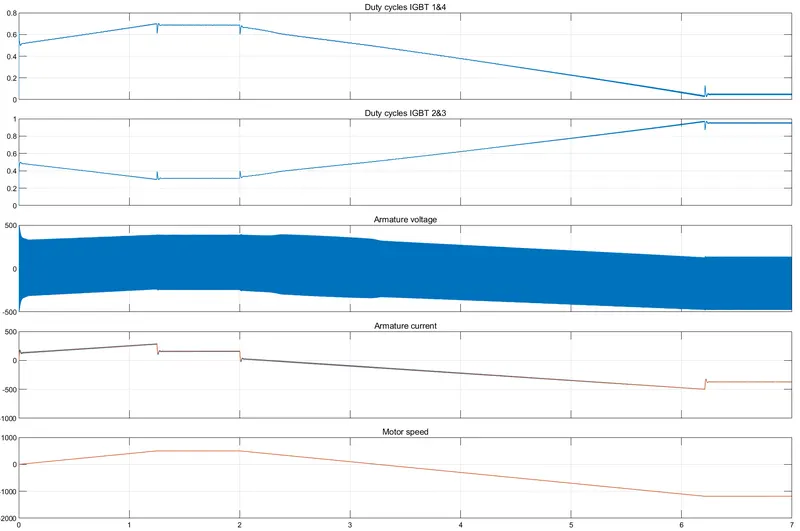
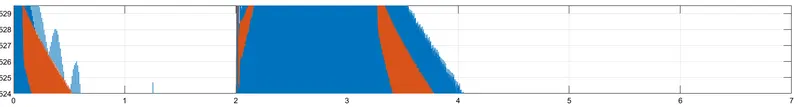
Based on the above simulation results, we can see that,
- The plot of duty cycles IGBT 1&4 are exactly opposite to that of duty cycles IGBT 2&3 as the pulse values of IGBT devices 1 and 4 are opposite to those of IGBT devices 2 and 3.
- The desired armature current is obtained from the average armature voltage.
- The armature current follows the current reference very well, with fast response time and small ripples.
Comparing the Four-Quadrant Chopper DC Drive (DC7) block with BJT H-bridge :
- In Four Quadrant Chopper DC Drive Block, the speed reference input is used to change the direction of the motor rotation whereas in BJT H-bridge model, the polarity is reversed to change the direction of motor rotation.
- In the BJT H-bridge model, the motor can be controlled by changing the pulse width of the pulse generator whereas in Four Quadrant Chopper DC Drive Block, the speed reference values can be changed to control the motor.
- The Four Quadrant Chopper DC Drive operates in four modes wiz. forward motoring, forward regenerative braking, reversing motoring and reverse regenerative braking mode whereas BJT H-Bridge model operates only on two modes wiz. forward and reverse.
- PI (Proportional Integral) Controllers are used for speed and current control in DC7 block and it is absent in BJT H-bridge model.
- The Four Quadrant Chopper DC Drive Block uses ramps to avoid current shoot up and smooth working stability.
- The disturbances and current shoot up is high in H-Bridge model because of switching losses.
- This is why the overall performance and stability is good in Four Quadrant Chopper DC Drive comparing BJT H-Bridge model.
2. Develop a 2-quadrant chopper using simulink & explain the working of the same with the relevant results.
Circuit Diagram of 2-quadrant chopper:
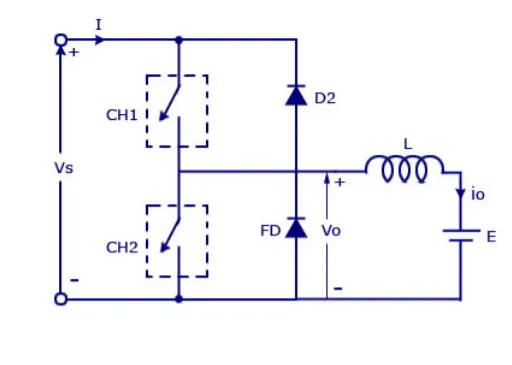
Two quadrant chopper is also called as type c chopper. Type C chopper is obtained by connecting type –A and type –B choppers in parallel. We will always get a positive output voltage V0 as the freewheeling diode FD is present across the load. When the chopper is on the freewheeling diode starts conducting and the output voltage v0 will be equal to Vs . The direction of the load current i0 will be reversed. The current i0 will be flowing towards the source and it will be positive regardless the chopper is on or the FD conducts. The load current will be negative if the chopper is or the diode D2 conducts. We can say the chopper and FD operate together as type-A chopper in first quadrant. In the second quadrant, the chopper and D2 will operate together as type –B chopper.
Creating Excel file:
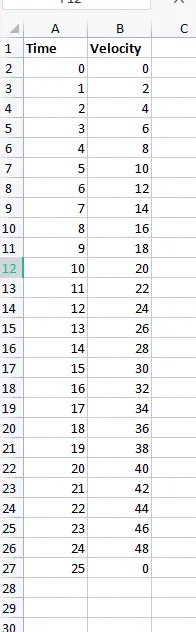
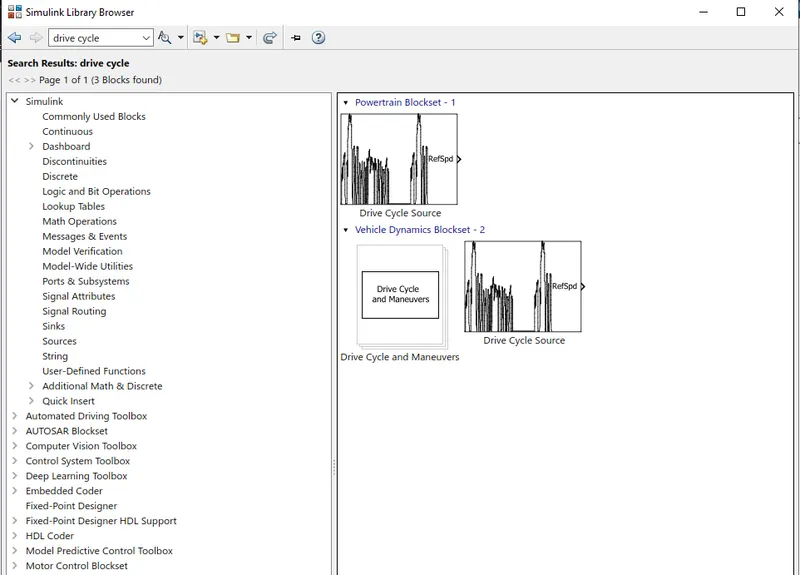
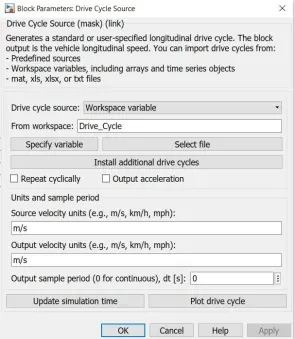
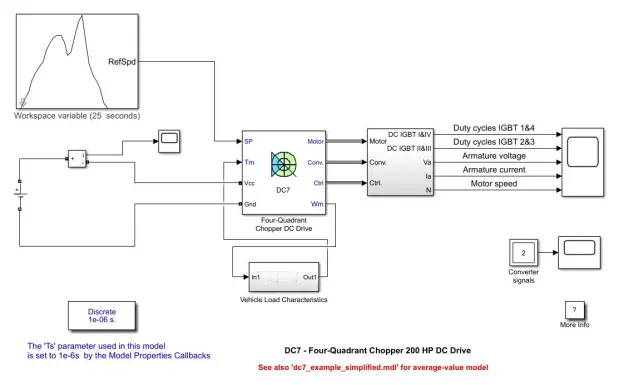
The Drive Cycle data is then imported to the workspace. Then we need to add Drive Cycle Block from Library Browser to DC7 model and in Drive Cycle Block, select the Drive Cycle Source as Workspace Variable.
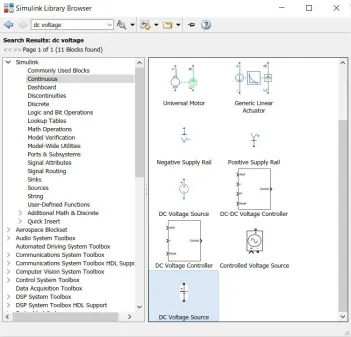
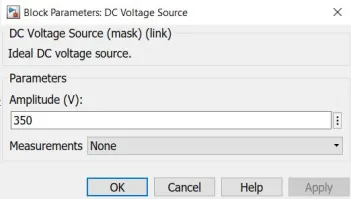
Now, as it is an EV, we need to add a DC source from the Library Browser. The DC Voltage value is set to be 350 V from reference.
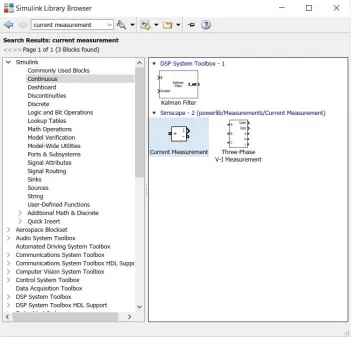
To measure the current from the DC source, a Current measurement block is placed between DC7 block and DC source block along with a scope.
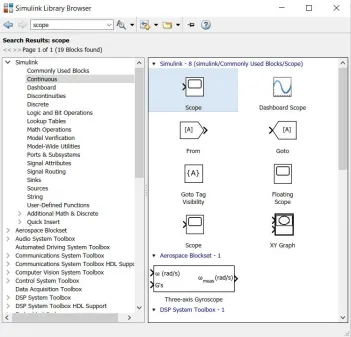
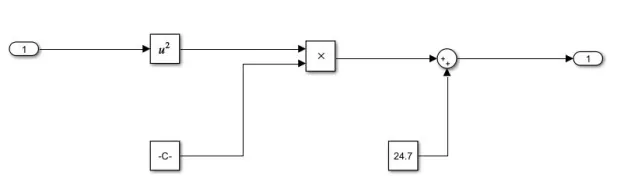
The Linear Load Torque will be replaced with a subsystem model according to the load characteristics given by,
TTR = 24.7 + 0.0051`omega^2`
We can model the above equation in Simulink as follows:
Select the Subsystem block,
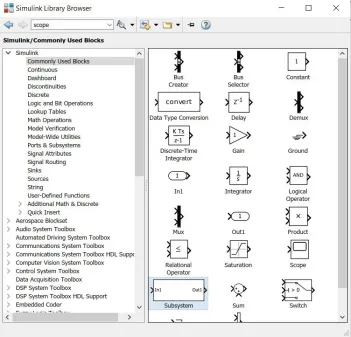
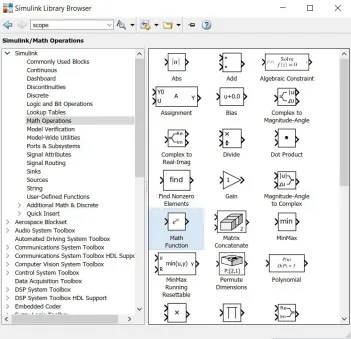
In the subsystem block, to resemble the equation select Constant, Product, Sum from commonly used blocks and Math Function from Math Operations blocks.
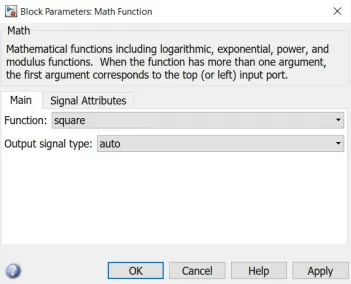
Model the Vehicle Load Characteristics equation as shown below:
The main EV model of DC7 block will look like:
Plot and Result:
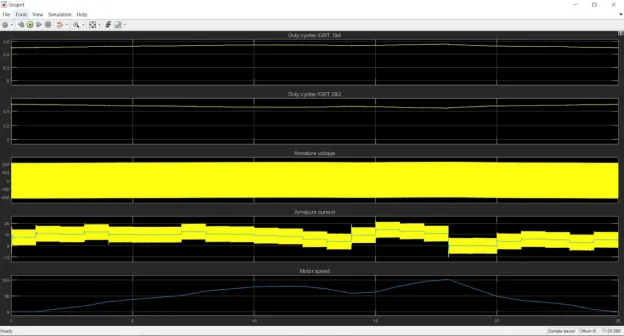
- The Duty Cycle plot of IGBT 1&4 follows the same relation as that of motor speed, i.e. it increases during acceleration and decreases during deceleration.
- The Duty Cycle plot of IGBT 2&3 follows the opposite relation to IGBT 1&4, thus with motor speed as the pulse values are opposite.
- The average armature voltage remains constant throughout the operation or experiences a negligible change.
- The armature voltage increases with increasing speed and decreases with decreasing speed.
3. Explain in a brief about operation of BLDC motor:
Brushless DC electric motors also known as electronically commutated motors .A brushless DC motor (known as BLDC) is a permanent magnet synchronous electric motor which is driven by direct current (DC) electricity and it accomplishes electronically controlled commutation system (commutation is the process of producing rotational torque in the motor by changing phase currents through it at appropriate times) instead of a mechanically commutation system. BLDC motors are also referred as trapezoidal permanent magnet motors.
Unlike conventional brushed type DC motor, wherein the brushes make the mechanical contact with commutator on the rotor so as to form an electric path between a DC electric source and rotor armature windings, BLDC motor employs electrical commutation with permanent magnet rotor and a stator with a sequence of coils. In this motor, permanent magnet (or field poles) rotates and current carrying conductors are fixed.
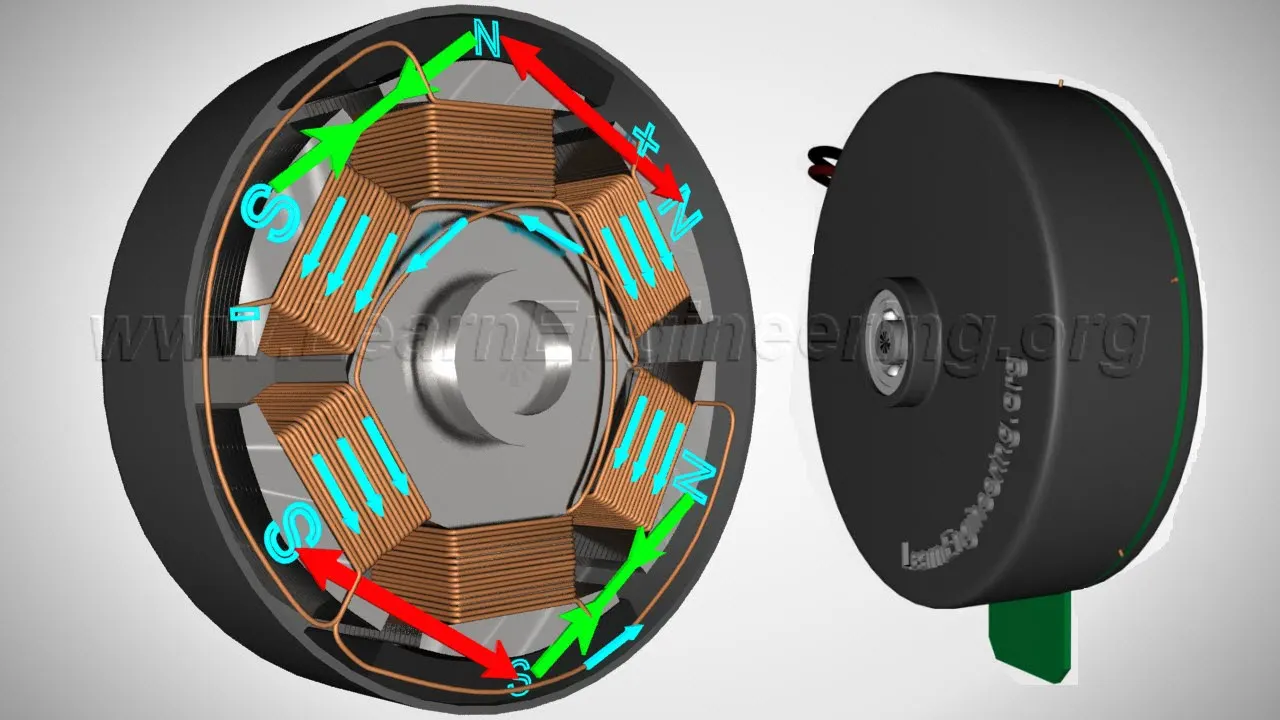
The armature coils are switched electronically by transistors or SCR at the correct rotor position in such a way that armature field is in space quadrature with the rotor field poles. Hence the force acting on the rotor causes it to rotate. Hall sensors or rotary encoders are most commonly used to sense the position of the rotor and are positioned around the stator. The rotor position feedback from the sensor helps to determine when to switch the armature current.
This electronic commutation arrangement eliminates the commutator arrangement and brushes in a DC motor and hence more reliable and less noisy operation is achieved. Due to the absence of brushes BLDC motors are capable to run at high speeds. The efficiency of BLDC motors is typically 85 to 90 percent, whereas as brushed type DC motors are 75 to 80 percent efficient. There are wide varieties of BLDC motors available ranging from small power range to fractional horsepower, integral horsepower and large power ranges.
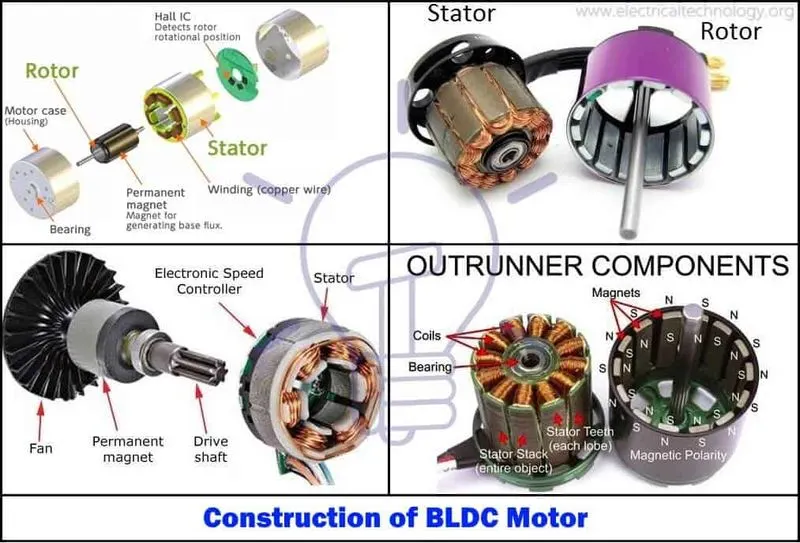
In this motor, the permanent magnets attach to the rotor. The current-carrying conductors or armature winding are located on the stator. They use electrical commutation to convert electrical energy into mechanical energy.
The main design difference between a brushed and brushless motors is the replacement of mechanical commutator with an electric switch circuit. A BLDC Motor is a type of synchronous motor in the sense that the magnetic field generated by the stator and the rotor revolve at the same frequency.
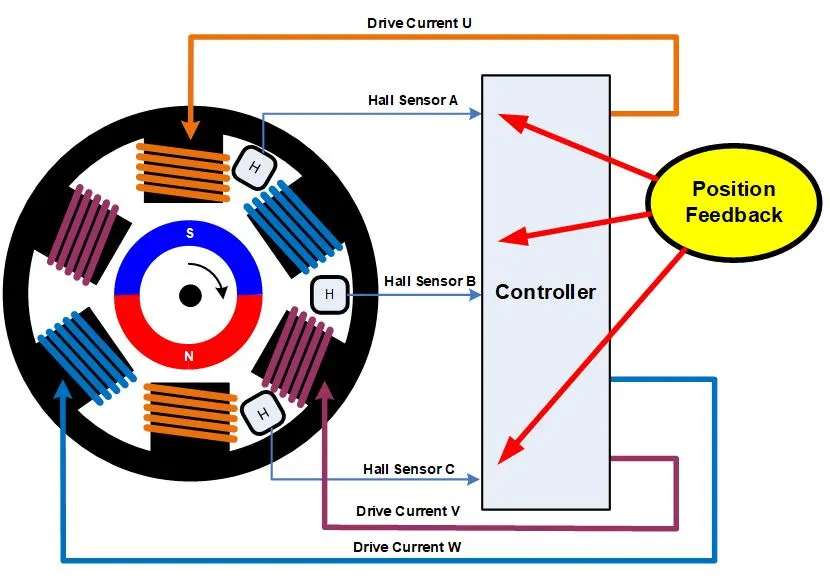
Brushless motor does not have any current carrying commutators .The field inside a brushless motor is switched through an amplifier which is triggered by the commutating device like an optical encoder. BLDC motors can be constructed in different physical configurations. Depending on the stator windings, these can be configured as single-phase, two-phase, or three-phase motors. However, three-phase BLDC motors with permanent magnet rotor are most commonly used.
Hall Sensors
Hall sensor provides the information to synchronize stator armature excitation with rotor position. Since the commutation of BLDC motor is controlled electronically, the stator windings should be energized in sequence in order to rotate the motor. Before energizing a particular stator winding, acknowledgment of rotor position is necessary. So the Hall Effect sensor embedded in stator senses the rotor position.
Most BLDC motors incorporate three Hall sensors which are embedded into the stator. Each sensor generates Low and High signals whenever the rotor poles pass near to it. The exact commutation sequence to the stator winding can be determined based on the combination of these three sensor’s response.
WORKING OF BLDC MOTOR:
The underlying principles for the working of a BLDC motor are the same as for a brushed DC motor; i.e., internal shaft position feedback. In case of a brushed DC motor, feedback is implemented using a mechanical commutator and brushes. With a in BLDC motor, it is achieved using multiple feedback sensors. The most commonly used sensors are hall sensors and optical encoders. Hall sensors work on the hall-effect principle that when a current-carrying conductor is exposed to the magnetic field, charge carriers experience a force based on the voltage developed across the two sides of the conductor.
If the direction of the magnetic field is reversed, the voltage developed will reverse as well. For Hall-effect sensors used in BLDC motors, whenever rotor magnetic poles (N or S) pass near the hall sensor, they generate a HIGH or LOW level signal, which can be used to determine the position of the shaft.
In a commutation system – one that is based on the position of the motor identified using feedback sensors – two of the three electrical windings are energized at a time as shown in figure 4.
In figure 4 (A), the GREEN winding labeled “001” is energized as the NORTH pole and the BLUE winding labeled as “010” is energized as the SOUTH pole. Because of this excitation, the SOUTH pole of the rotor aligns with the GREEN winding and the NORTH pole aligns with the RED winding labeled “100”. In order to move the rotor, the “RED” and “BLUE” windings are energized in the direction shown in figure 4(B). This causes the RED winding to become the NORTH pole and the BLUE winding to become the SOUTH pole. This shifting of the magnetic field in the stator produces torque because of the development of repulsion (Red winding – NORTH-NORTH alignment) and attraction forces (BLUE winding – NORTH-SOUTH alignment), which moves the rotor in the clockwise direction.
ADVANTAGES OF BLDC MOTOR
- Less overall maintenance due to absence of brushes
- Reduced size with far superior thermal characteristics
- Higher speed range and lower electric noise generation.
- It has no mechanical commutator and associated problems
- High efficiency and high output power to size ratio due to the use of permanent magnet rotor
- High speed of operation even in loaded and unloaded conditions due to the absence of brushes that limits the speed
- Smaller motor geometry and lighter in weight than both brushed type DC and induction AC motors.
- Long life as no inspection and maintenance is required for commutator system
- Higher dynamic response due to low inertia and carrying windings in the stator
- Less electromagnetic interference
- Low noise due to absence of brushes.
DISADVANTAGES OF BLDC MOTOR
- These motors are costly
- Electronic controller required control this motor is expensive
- Requires complex drive circuitry
- Need of additional sensors