Week-7 Challenge: DC Motor Control
1. A. Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
B. Comment on the armature current shoot-up from the scope results.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
A. Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
Chopper: DC to DC converter is very much needed many industrial applications are dependent upon DC voltage source. The performance of these applications will be improved if we use a variable DC supply. It will help to improve controllability of the equipments also. Examples of such applications are subway cars, trolley buses, battery operated vehicles etc. We can control and vary a constant DC voltage with the help of a chopper. Chopper is a basically static power electronics device which converts fixed DC voltage/power to variable DC voltage or power. It is nothing but a high speed switch which connects and disconnects the load from source at a high rate to get variable or chopped voltage at the output. Choppers are two types which is step-up and step-down choppers.
BJT H-Bridge:
In general an H-Bridge is a rather simple circuit, containing four switching element, with the load at the center in an H like configuration. An H-bridge is an arrangement of transistors that allows a circuit full control over a standard electric DC motor. That is, an H-bridge allows a microcontroller, logic chip, or remote control to electronically command the motor to go forward, reverse, brake, and coast.
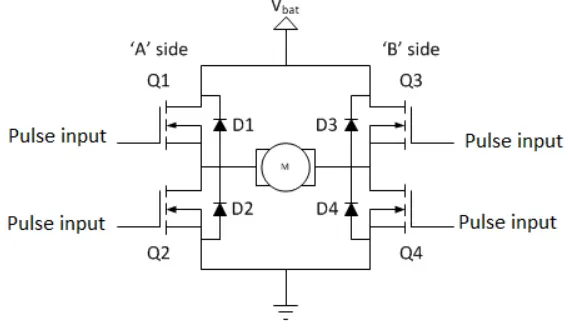
The basic operation of the H-bridge circuit diagram
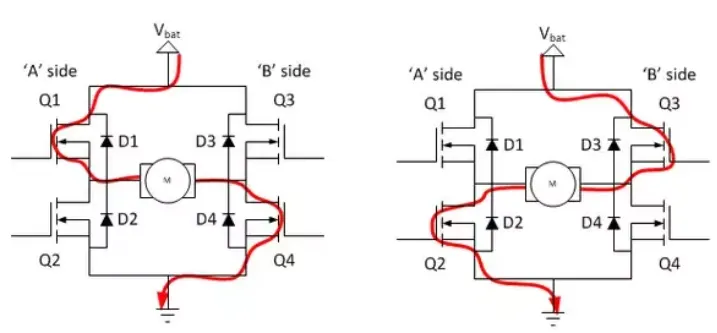
Motor rotates in Forward direction Motor rotates in Reverse direction
When the positive gate signal is given to the switches Q1 and Q4 are turned on the motor rotates in forward direction and when positive gate signal is given to the switches Q3 and Q2 are turned on the motor rotates in reverse direction.
The Q1 and Q2 is never trigger positive signal to get switches on because the diodes are get short-circuit and the low resistance path will occur and switches get damage.
when Q1 and Q4 is triggered the signal will ON and the D1 and D4 is OFF condition. During the changing of positive to negative time period D1 and D4 is ON condition at that time the Q1 and Q4 is OFF condition.
The Q3 and Q2 is triggered the signal will ON and the D3 and D2 is OFF condition. During the changing of positive to negative time period Q3 and Q2 is triggered OFF condition at that time the D3 and D2 is ON condition.
The Bipolar Junction Transistor (BJT) when used for power switched applications operates as an IGBT. When it is conducting (BJT operated in saturated region) a forward voltage Vf is developed between collector and emitter in the range of 1 v.
The IGBT does not simulate the gate current controlling the BJT or IGBT. The switch is controlled by a Simulink® signal (1/0). The DC motor uses the preset model (5 HP 24V 1750 rpm). It simulates a fan type load (where Load torque is proportional to square of speed). The armature mean voltage can be varied from 0 to 240 V when the duty cycle (specified in the Pulse Generator block) is varied from 0 to 100%.
Simulink Model of ‘Speed control of a DC motor using BJT H-bridge’ :
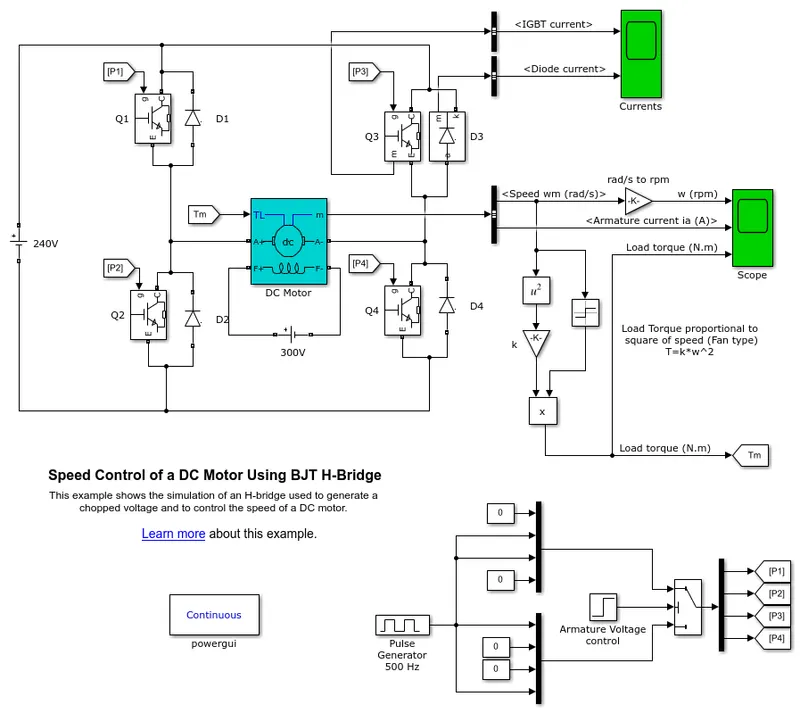
The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models). Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off. When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
Pulse width modulation (PWM) : It is a modulation technique that generates the variable width pulses to represent the amplitude of an analog input signal.The length of time that is pulse is in a given state High/low is the width of a pulse wave. Here the term comes the duty cycle which represents in perrcentage values.
The pulse generator given a pulse width of 75% and period of 2e-3 seconds. The motor parameters of the torque and field voltage and armature voltages are taken as default values of the model.
The OUTPUT Waveforms of the Diode current and IGBT current as shown in figure below:
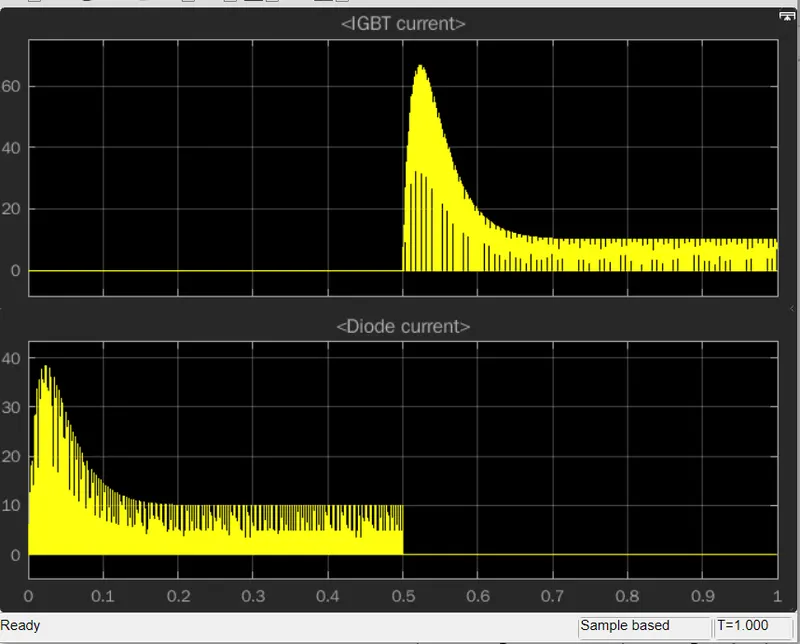
The above graph shows the current passing through the IGBT and Diode. So, for 0 to 0.5 sec current is flowing through the diode D3 and 0.5 to 1 sec the current passing through the Q3.
Now we will take OUTPUT Waveform of the load torque, armature current and speed.
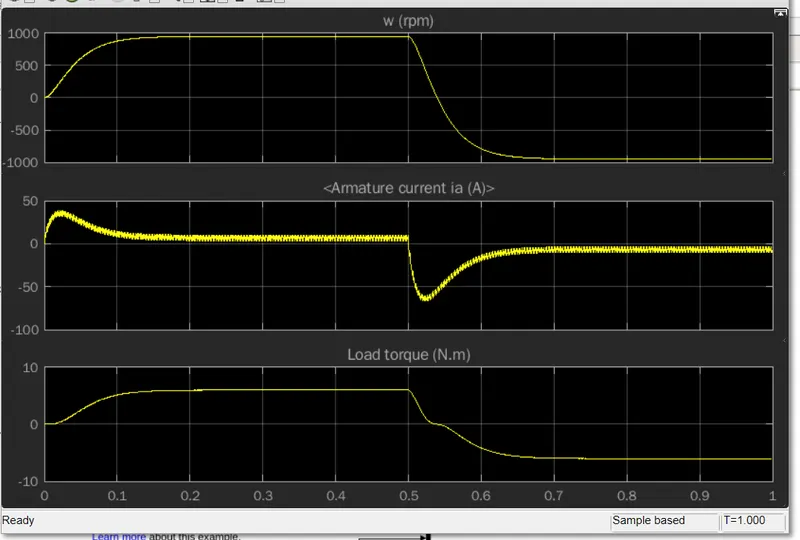
The above graph shows that at the beginning of the cycle there is a sudden peak in armature current that same repeats in opposite direction when motor rotates opposite direction.
B. Comment on the armature current shoot-up from the scope results.
The principle of Pulse Width Modulation (PWM).
The average value of voltage and current fed to th load is controlled by turning the switch between supply and load on and off at a fast rate. The PWM switching frequency is as to be high enough not to effect the load, which is to say that the resultant waveform perceived by the load must be as smooth as possible.
The peaks can be remove by reducing the duty cycle.
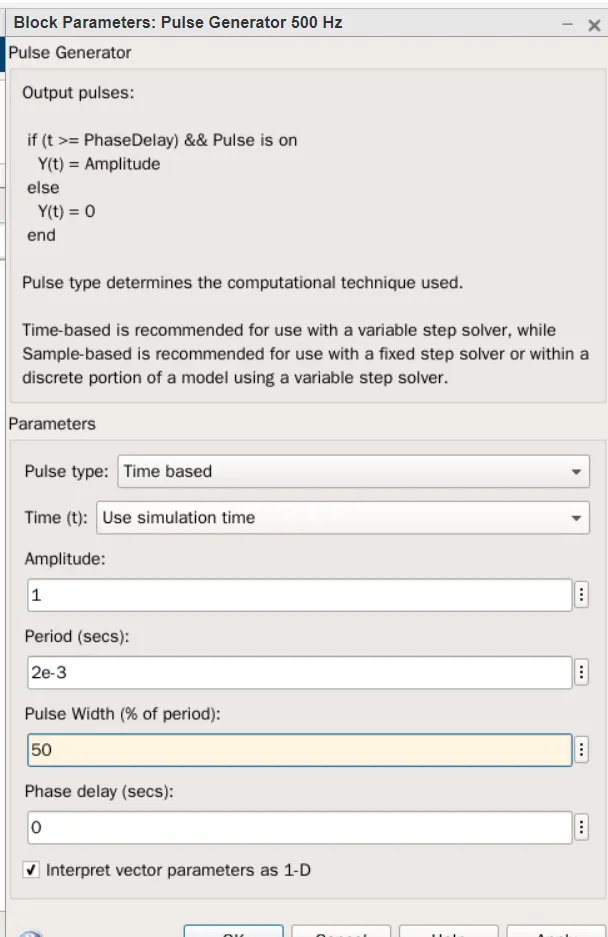
The following plot shows the OUTPUT waveform when pulse width value changed with 50%.
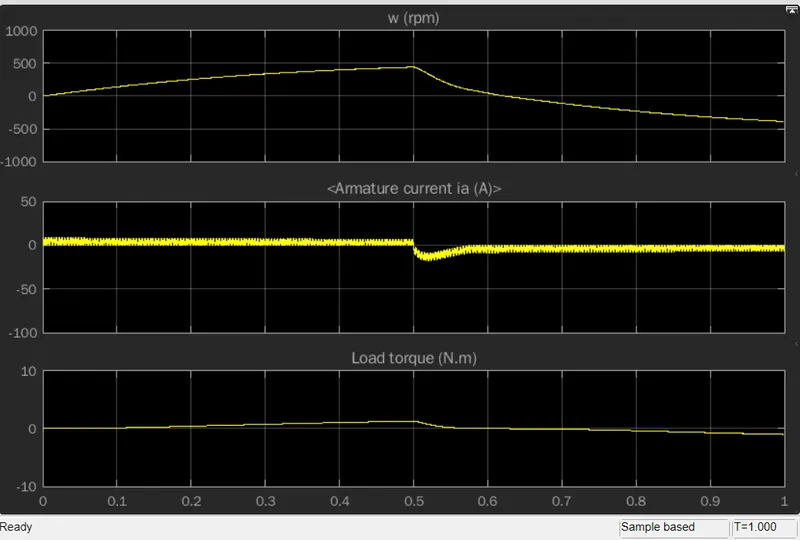
The armature current in this graph we observe that there is no sudden rise at the starting of the armature current. If we further reduced the PWM the negative of the rise will get reduced.
The following Plot shows the OUTPUT waveform when pulse width value changed with 40%.
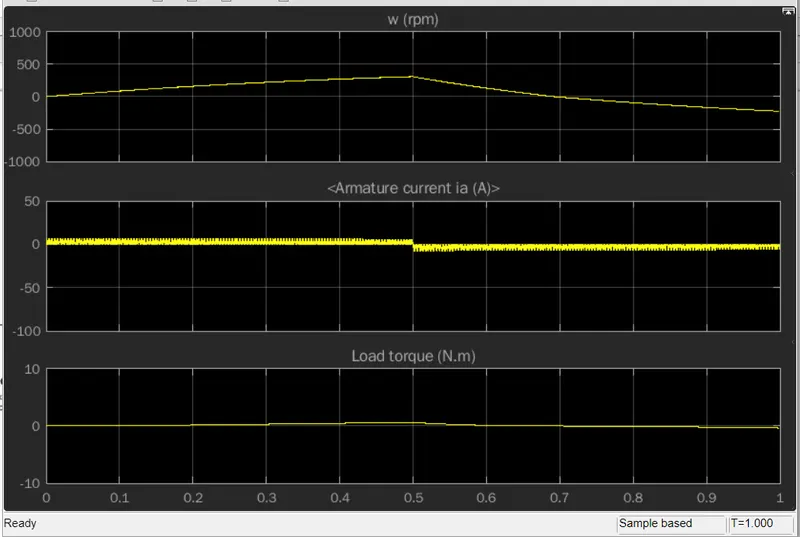
If we reduced the duty cycle ratio than we obtain a smooth variation in the armature current, torque and speed. The above graph PWM is 40% and the motor details are default as the model.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
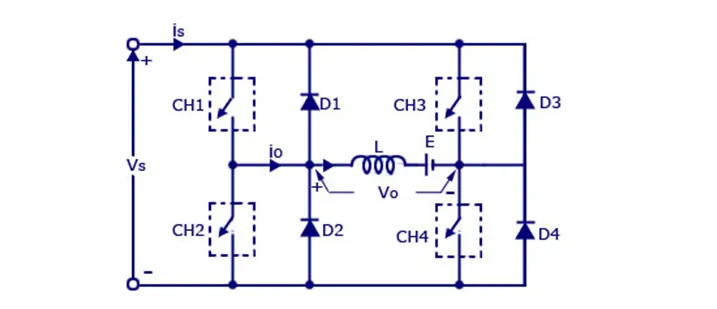
The circuit is therefore called as four quadrant chopper circuit or dc to dc converter. The output of the full bridge converter can also be an AC voltage with variable frequency and amplitude in which case the converter is called as dc- to-ac conversion (inverter).
First Quadrant :
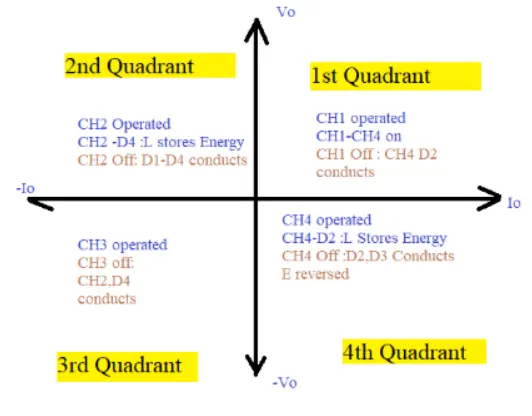
During the first quadrant operation the chopper CH4 will be on . Chopper CH3 will be off and CH1 will be operated. AS the CH1 and CH4 is on the load voltage v0 will be equal to the source voltage Vs and the load current i0 will begin to flow . v0 and i0 will be positive as the first quadrant operation is taking place. As soon as the chopper CH1 is turned off, the positive current freewheels through CH4 and the diode D2 . The type E chopper acts as a step- down chopper in the first quadrant.
Second Quadrant:
In this case the chopper CH2 will be operational and the other three are kept off. As CH2 is on negative current will starts flowing through the inductor L . CH2 ,E and D4. Energy is stored in the inductor L as the chopper CH2 is on. When CH2 is off the current will be fed back to the source through the diodes D1 and D4. Here (E+L.di/dt) will be more than the source voltage Vs . In second quadrant the chopper will act as a step-up chopper as the power is fed back from load to source.
Third Quadrant:
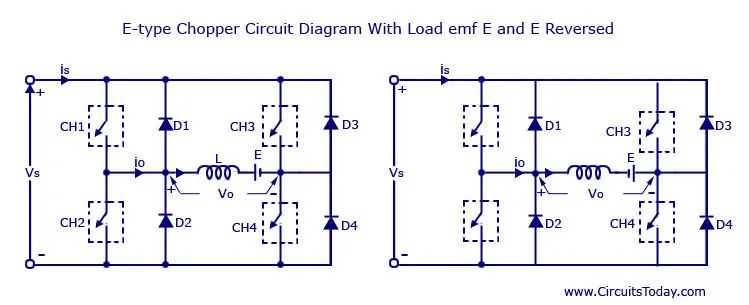
In third quadrant operation CH1 will be kept off , CH2 will be on and CH3 is operated. For this quadrant working the polarity of the load should be reversed. As the chopper CH3 is on, the load gets connected to the source Vs and v0 and i0 will be negative and the third quadrant operation will takes place. This chopper acts as a step-down chopper.
Fourth Quadrant:
CH4 will be operated and CH1, CH2 and CH3 will be off. When the chopper CH4 is turned on positive current starts to flow through CH4, D2 ,E and the inductor L will store energy. As the CH4 is turned off the current is feedback to the source through the diodes D2 and D3 , the operation will be in fourth quadrant as the load voltage is negative but the load current is positive. The chopper acts as a step up chopper as the power is fed back from load to source.
The Simulink model od Dc7 Block:
The armature voltage is provided by an IGBT converter controlled by two PI regulators. The converter is fed by a 515 V DC bus obtained by rectification of a 380 V AC 50 Hz voltage source. In order to limit the DC bus voltage during dynamic braking mode, a braking chopper has been added between the diode rectifier and the DC7 block.
The first regulator is a speed regulator, followed by a current regulator. The speed regulator outputs the armature current reference (in p.u.) used by the current controller in order to obtain the electromagnetic torque needed to reach the desired speed. The speed reference change rate follows acceleration and deceleration ramps in order to avoid sudden reference changes that could cause armature over-current and destabilize the system. The current regulator controls the armature current by computing the appropriate duty ratios of the 5 kHz pulses of the four IGBT devices (Pulse Width Modulation). For proper system behaviour, the instantaneous pulse values of IGBT devices 1 and 4 are opposite to those of IGBT devices 2 and 3. This generates the average armature voltage needed to obtain the desired armature current. In order to limit the amplitude of the current oscillations, a smoothing inductance is placed in series with the armature circuit.
Compare the Four Quadrant Chopper and H-Bridge:
Four quadrant chopper H-Bridge
1. The motor can be operated in all four 1. In this model we have only modes forward and reverse by changing
modes Forward motoring, Reverse motoring, the direction of motor.
Forward braking, Reverse braking.
2. Regenerative braking can be acieved 2. In this regenerative is not possible.
3. The signals given to the four quadrant 3. In this the signals are continous.
operations are discrete.
4. To change the direction of motor current 4. To change the direction of motor only the polarity of current is
signal are interrupted with one another. changed.
2. Develop a 2-quadrant chopper using simulink & explain the working of the same with the relevant results. (Refer to article - Multiquadrant operation of motor )
The 2- Quadrant chopper are two types Class-D and Class-C
Class- C Chopper:
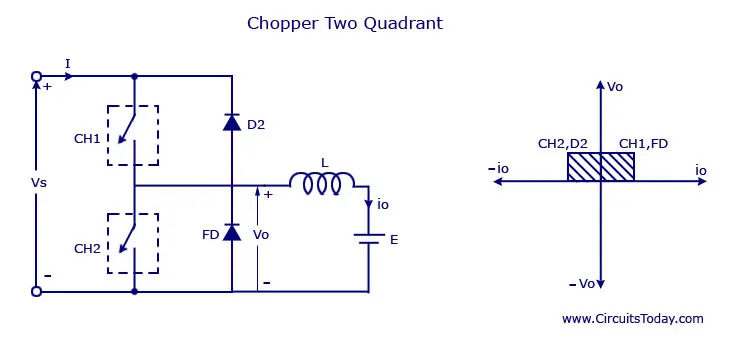
Type C chopper is obtained by connecting type –A and type –B choppers in parallel. We will always get a positive output voltage V0 as the freewheeling diode FD is present across the load. When the chopper is on the freewheeling diode starts conducting and the output voltage v0 will be equal to Vs . The direction of the load current i0 will be reversed. The current i0 will be flowing towards the source and it will be positive regardless the chopper is on or the FD conducts. The load current will be negative if the chopper is or the diode D2 conducts. We can say the chopper and FD operate together as type-A chopper in first quadrant. In the second quadrant, the chopper and D2 will operate together as type –B chopper. The average voltage will be always positive but the average load current might be positive or negative. The power flow may be life the first quadrant operation ie from source to load or from load to source like the second quadrant operation. The two choppers should not be turned on simultaneously as the combined action my cause a short circuit in supply lines. For regenerative braking and motoring these type of chopper configuration is used.
Class-D Chopper:
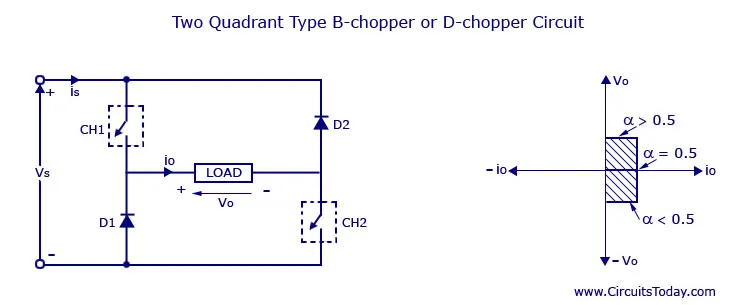
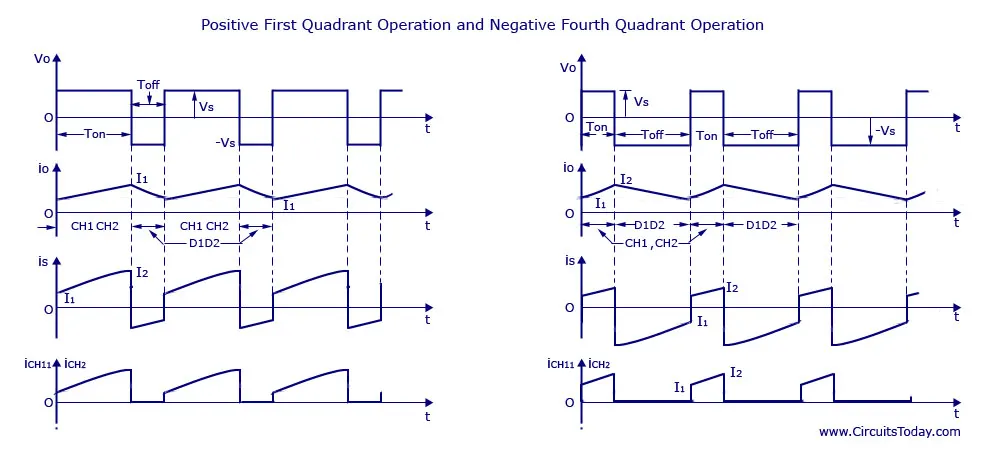
The circuit diagram of the type D chopper is shown in the above figure. When the two choppers are on the output voltage v0 will be equal to Vs . When v0 = – Vs the two choppers will be off but both the diodes D1 and D2 will start conducting. V0 the average output voltage will be positive when the choppers turn-on the time Ton will be more than the turn off time Toff its shown in the wave form below. As the diodes and choppers conduct current only in one direction the direction of load current will be always positive.
The power flows from source to load as the average values of both v0 and i0 is positive. From the wave form it is seen that the average value of V0 is positive thus the forth quadrant operation of type D chopper is obtained.
Simulink model of Class-D chopper:
1. Open MATLAB click on simulink model and click on library browser.
2. Select the blocks of the Mosfet, Diode, scope,pulse generator, inductor in series RLC branch, DC Voltage source and current,voltage measurements.
3. The blocks of simulink model can be arrenged in a passion that the class-D chopper.
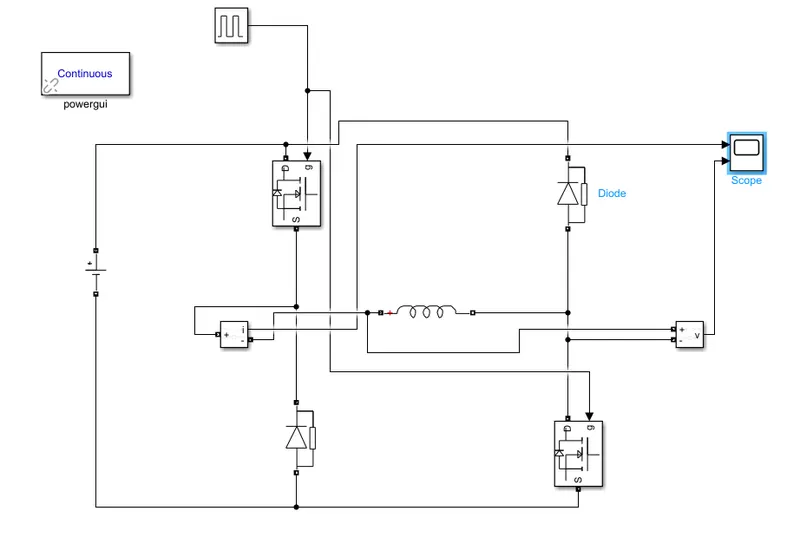
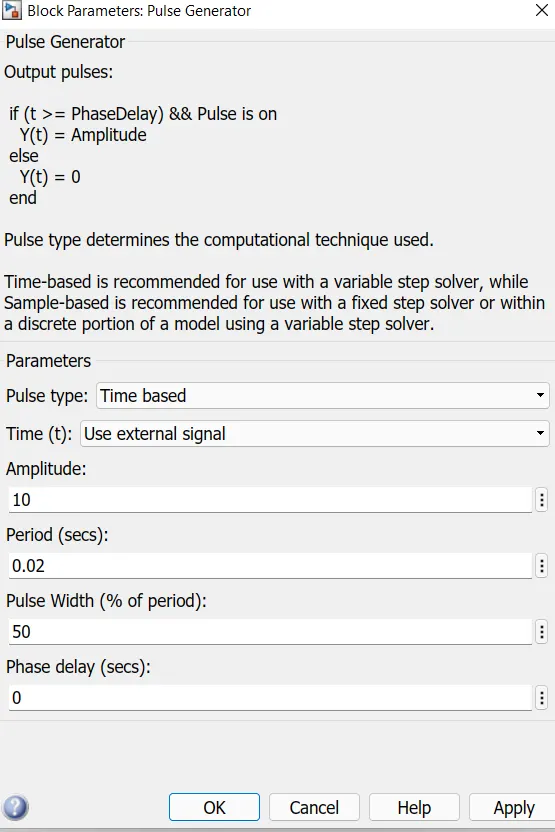
4. We will assign the pulse generator values and voltage supply is 24V DC.
5. The inductor load value had taken here is 5e-3.
The OUTPUT waveform of the voltage and current is shown below.
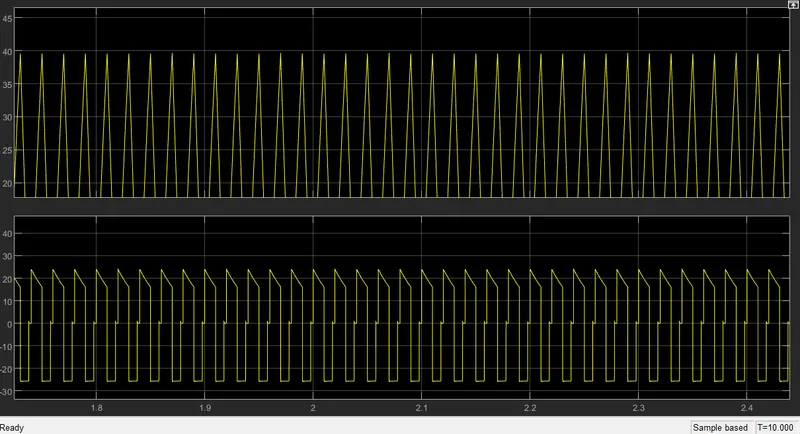
The output of the voltage waveform is positive and negative of half cycle and current waveformis in positive direction.
This is 2-quadrant operation chopper Class-D.
3. Explain in a brief about operation of BLDC motor.
What is BLDC Motor:
A brushless DC motor (also known as a BLDC motor or BL motor) is an electronically commuted DC motorwhich does not have brushes. The controller provides pulses of current to the motor windings which control the speed and torque of the synchronous motor
These types of motors are highly efficient in producing a large amount of torque over a vast speed range. In brushless motors, permanent magnets rotate around a fixed armature and overcome the problem of connecting current to the armature. Commutation with electronics has a large scope of capabilities and flexibility. They are known for smooth operation and holding torque when stationary.
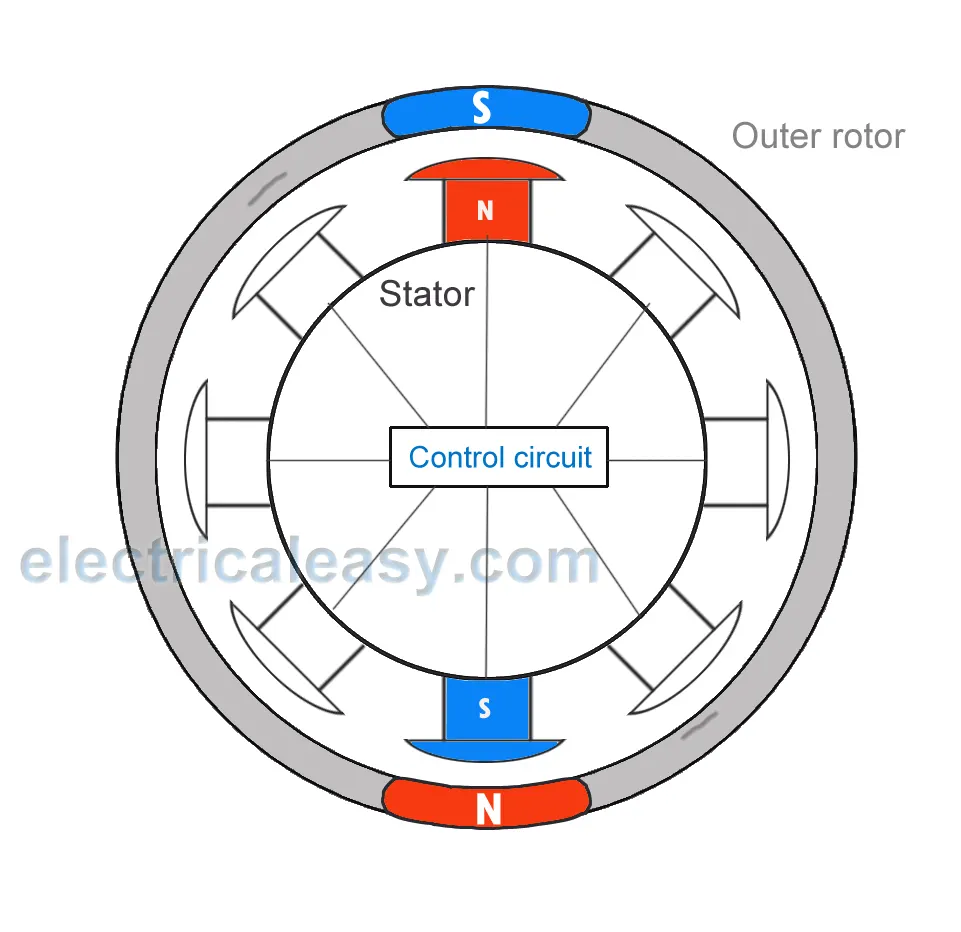
Working principle of BLDC motor:
Before explaining the working of a brushless DC motor, it is better to understand the function of a brushed motor. In brushes motors, there are permanent magnets on the outside and a spinning armature which contains electromagnet is inside. These electromagnets create a magnetic field in the armature when the power is switched on and help to rotate the armature.The brushes change the polarity of the pole to keep the rotation on of the armature. The basic working principle for the brushed DC motor and for brushless DC motor are same i.e. internal shaft position feedback.Brushless DC motor has only two basic parts: rotor and the stator. The rotor is the rotating part and has rotor magnets whereas stator is the stationary part and contains stator windings. In BLDC permanent magnets are attached in the rotor and move the electromagnets to the stator. The high power transistors are used to activate electromagnets for the shaft turns. The controller performs power distribution by using a solid-state circuit.
Types of BLDC motor:
Basically, BLDC are of two types, one is outer rotor motor and other is inner rotor motor. The basic difference between the two is only in designing, their working principles are same.
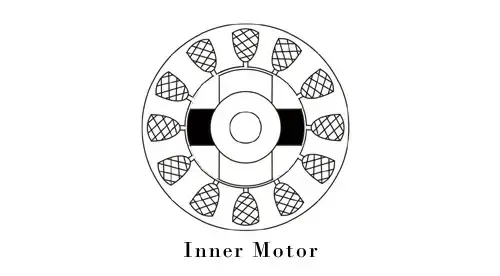
Inner Rotor Design
In an inner rotor design, the rotor is located in the centre of the motor and the stator winding surround the rotor. As the rotor is located in the core, rotor magnets do not insulate heat inside and heat get dissipated easily. Due to this reason, inner rotor designed motor produces a large amount of torque and validly used.
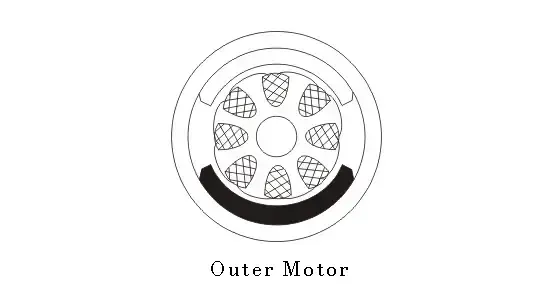
Outer Rotor Design
In outer rotor design, the rotor surrounds the winding which is located in the core of the motor. The magnets in the rotor trap the heat of the motor inside and do not allow to dissipate from the motor. Such type of designed motor operates at lower rated current and has low cogging torque.
Brushless Vs. Brushed DC Motor:
Brushes require frequent replacement due to mechanical wear, hence, a brushed DC motor requires periodic maintenance. Also, as brushes transfer current to the commutator, sparking occurs. Brushes limit the maximum speed and number of poles the armature can have. These all drawbacks are removed in a brushless DC motor. Electronic control circuit is required in a brushless DC motor for switching stator magnets to keep the motor running. This makes a BLDC motor potentially less rugged.
Benefits of BLDC motor over brushed motors:
benefits of BLDC motor over brushed motors are listed below,
1.Increased efficiency
2.Reliability
3.longer lifetime
4.No sparking and less noise more torque per weight etc.
Advantages of BLDC motor:
The advantages of a BLDC motor are:
1.Brushless motors are more efficient as its velocity is determined by the frequency at which current is supplied, not the voltage.
2.As brushes are absent, the mechanical energy loss due to friction is less which enhanced efficiency.
3.BLDC motor can operate at high-speed under any condition.
4.There is no sparking and much less noise during operation.
5.More electromagnets could be used on the stator for more precise control.
Applications :
These are variety of applications requirements such as varriying loads, constant loads and positioning applications in the fields of industerial control, automotive, aviation,automation systems,etc.
1. Electric vehicles, hybrid vehicles and electric bicycles.
2. Industrial robots, CNC machine tools, and simple belt drive systems.
3. Washing machines, compressors and dryers and pumps.