Week-7 Challenge: DC Motor Control
AIM:
1. A. To Modifying The MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
B. Comment on the armature current shoot-up from the scope results.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
2. To implement the 2-quadrant chopper using simulink & explain the working of the same with the relevant results. (Refer to article - Multiquadrant operation of motor )
3. To give the detali operation of BLDC motor.
STUDY -1:
A. In MATLAB, Open "Speed Control of a dc motor BJTH-bridge model" by using Help section.
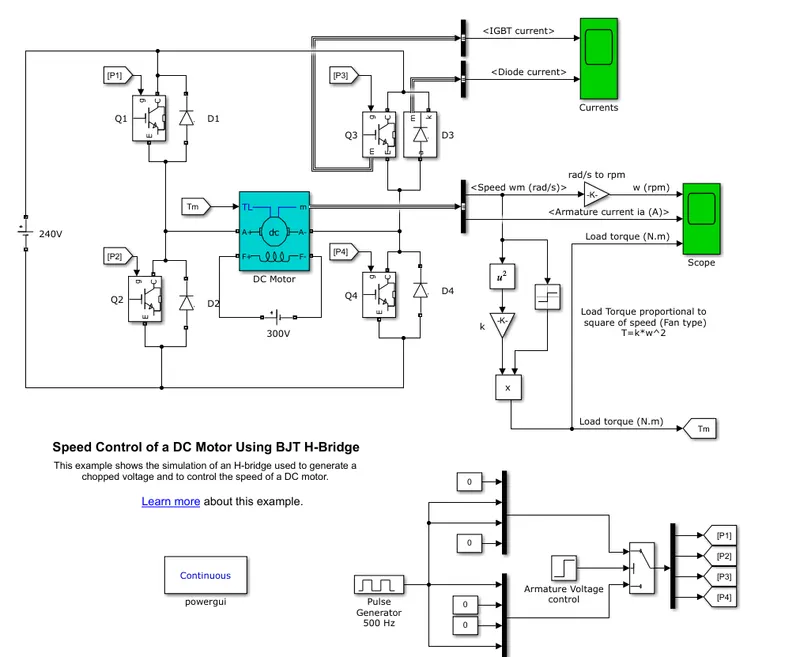
"Speed Control of aDC motor BJI H- bridge model" has shown in above figure. H-bridge consists of four BJT/Diode pairs. Duty cycle and step time are input given fom 'pluse Generator Block' and Armature Voltage Control Block' Block' to Bipolar junction transistor H- brigde.
Bipolar junction Transistor H- bridge:
The basic operating mode of an H-bridge is fairly simple. if Q1 AND Q4 are turned on, the left lead of the motor will be connected to the power supply ,while the right lead is connected to ground. current starts flowing through the motor which energizes the motor in (lets say) the forward direction the motor shaft starts spinning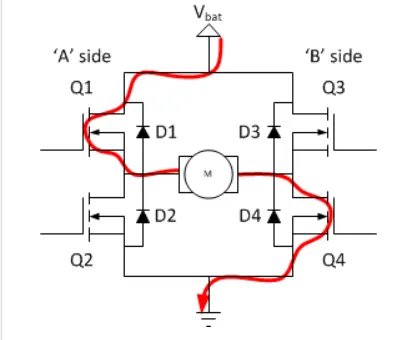
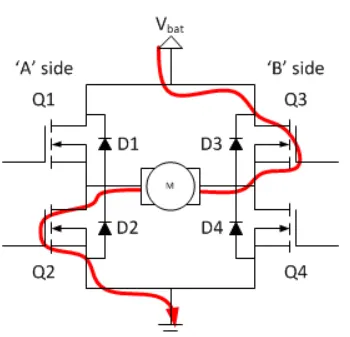
If Q2 and Q3 are turned on, the reverse will happen, the motor gets energized in the reverse direction and the shaft will start spinning backwards.
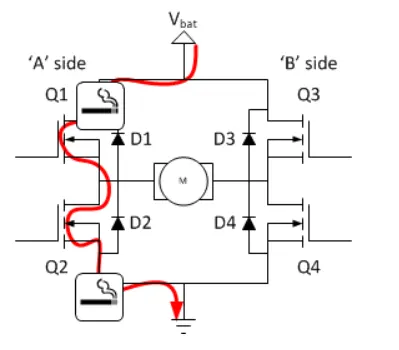
In a bridge, you should never ever close both Q1 and Q2 (or Q3 and Q4 ) at the same time . if you did that ,you just have created a really low resistance path between power and GND , effectively short -circuiting your power supply. This condition is called 'shoot-through' and is an almost guaranted way to quickly destroy bridge ,or something else in you circuit.
working principle or operation of speed control of dc motor using BJT H-bridge Model:
The motor starts in the positive direction with a duty cycle of 75% ( mean DC voltage of 180v). at t=0.5 sec , the armature
voltage is suddenly reversed and the motor runs in the negative direction.
'current 'shows currents flowing in Bipolar junction Transistor Q3.Adding of diodes in the Forward direction for the transistor, to give a path for the current to take to release this energy . Without diodes, it risk that the voltage rises and damages the transistors.
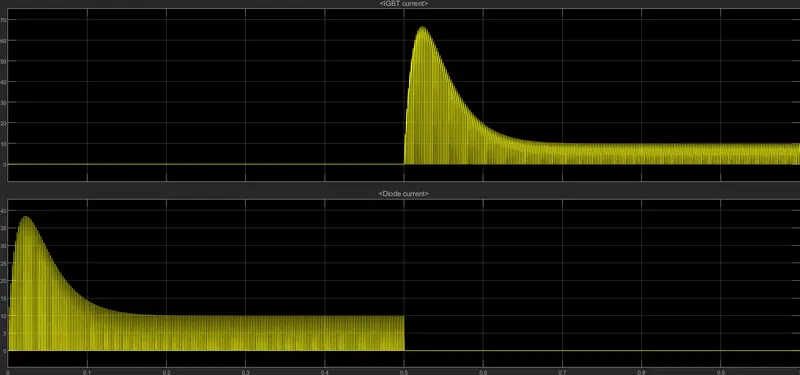
From the above plot, observed that '0s-0.5 s' Current flow Tgrough'Diode D3' and '0 .5s-1s'Current will flow through 'BJI Q3'.
The Ouput from the DC motor is speed ("rad/s" is coverterd into "rmp )and Armature Current (A) is connected with Scope'. Where,Load Torque (T) is directly proportional to Square of speed
T ∝ ω2
T=Kw^2
Ouput from the speed(w) is multiplied with constant(k) gives Load Torque (T) and it is also connected with 'Scope'.'scope' shows motor speed armature and load torque.
B.
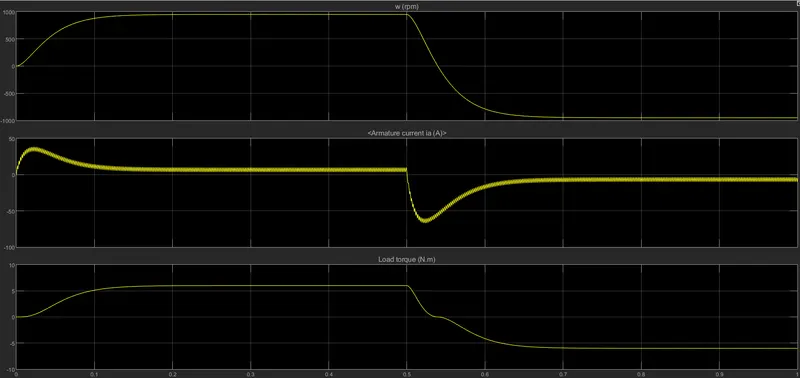
In the above plot, Armature current has sudden rise and drop when the motor changes direction from forward to reverse motion.
PLUSE WIDTH MODULATION
The average value of voltage (and Current) fed to the load is controlled by turning the switch between supply and load on and off at a fast rate. The PWM switching frequency has to be high enough not to affect the load.which is to say that the resultant wavefrom perceived by the load must be as smooth as possible.
Here Duty Cycle is reffered as Pulse width .In pulse generator block,decrease the pulse width to stop the fluctuation of armature current during forward and reverse motion.
Decreasing the pulse width 45 and run the model to test the scope results until the armature current flow without any fluctuations by trial and error method.
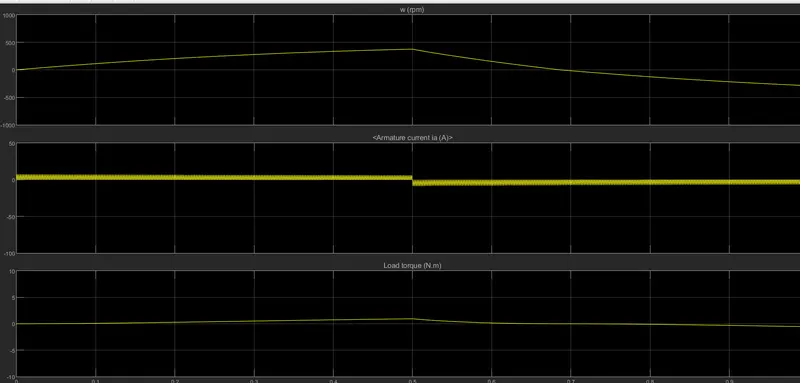
Here pulse width is refered as Duty cycle.Duty cycle is directly proportional to voltage.while changing the Duty cycle it change the voltage.By reducing the Duty cycle from 75% to 45%, means average voltage and current will be produced.there is no sudden rise and drop occur and constant current will be produced. therefore armature current does from fprward to reverse.
C. Four-Quadrant Chopper DC Drive (DC7) block:
In above Four-Quadrant Chopper DC Drive (DC7) block model using Help section.
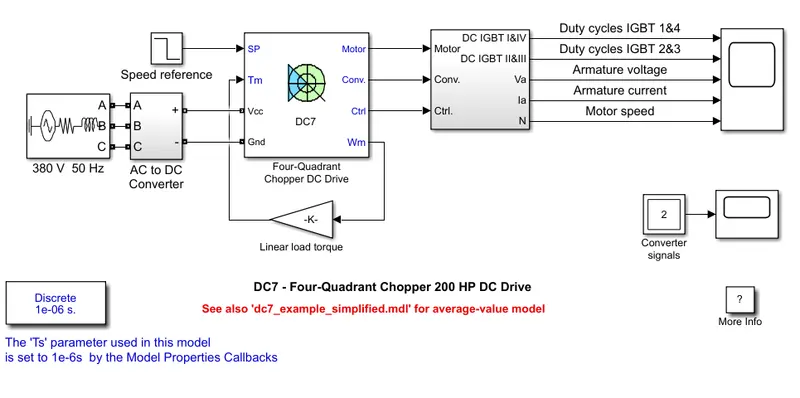
In above Four-Quadrant CHopper DC drive DC7 block model,3phase voltage source and AC to DC Converter contains Rectifer bridge and Braking chopper is added to Four-Quadrant Chopper DC drive DC7 block. The Armature voltage is provided by IGBT converter controlled by two pl regulator followed by current regulator.
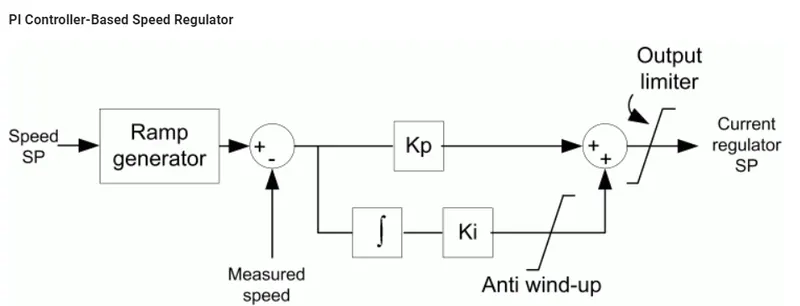
The Speed Regulator output the armature current reference used by the current controlled in order to obtain the electromagnetic torque needed to reach the desired speed. the speed reference change rate follows acceleration and deceleration ramps in oder to avoid sudden reference changes that could cause armature over- current and destabilze the system.
Current controller:
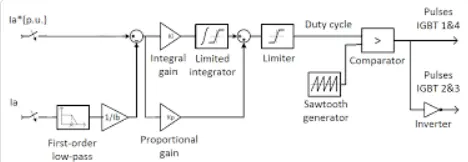
The current regulator controls the armature current by computing the armature current by computing the appropriate duty ratio of the 5KHz pulses of the four IGBT devices (pules width modulation).
WORKING OF FOUR QUARDRANT CHOPPER:
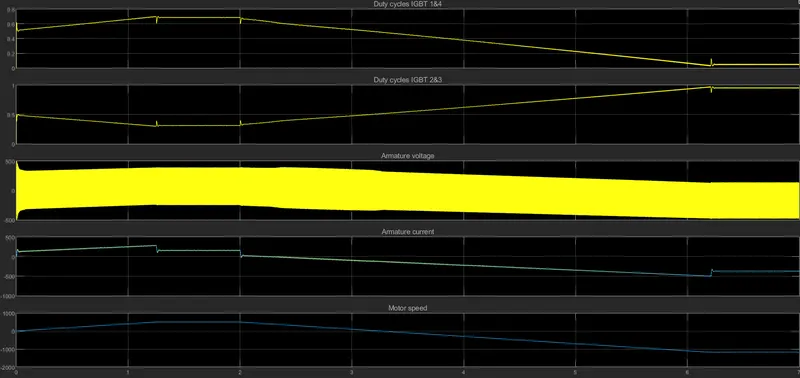
The operation of a four quadrant chopper or class-E chopper is summarized in the figure below.
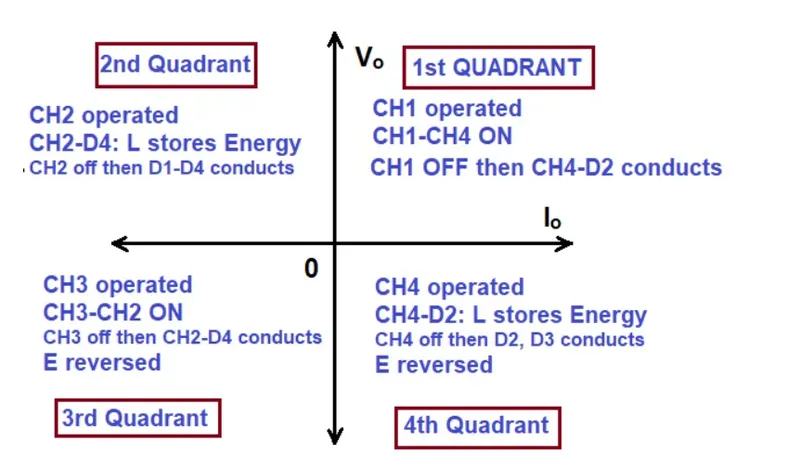
The circuit of a four quadrant chopper or class -E chopper basically consists of four semiconductor switches CH1 to CH4 and four diodies D1 to D4.The four diodes are connected in anti- parallel. The circuit diagram of this type of chopper is shown below.
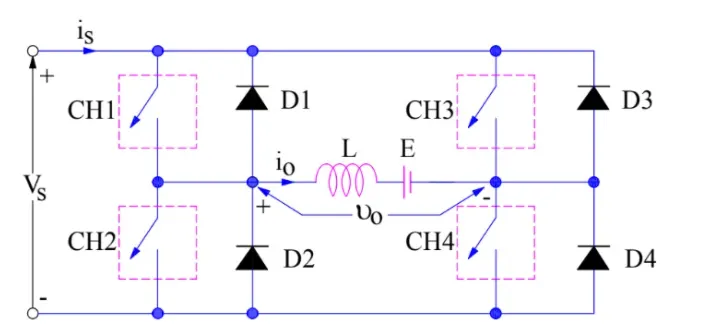
In the above circuit diagram, the chopper are numbered CH1 to CH4. for first quadrant operation CH1 is made ON , for second quadrant operation CH2 is made ON and so on. To better understand the working of four quadrant chopper ,we will discuss its operation separately for each quadrant.
First Quadrant :
For first quadrant operation, thyristor CH4 is kept on, thyristor CH3 is kept off and thyristorswitch CH1 is operated. With CH1, CH4 ON, armature voltage (Vo=vs) and armature control I0 begins flow. Here both Va and Ia are positive giving first quadrant operation,
when CH1 is turned off, positive current freewheels through CH4, D2. In this manner, Vo, Io
can be controlled in this first quadrant, and Motor rotates in the forward driection, sonit is called forward Motoring.
Second Quadrant :
Here thyristor CH2 is operated and CH1 , CH3 and CH4 are kept off. With CH4 on, reverse or negative current flows through L, CH2, D4 and E. During the operation time of CH2, the armature inductance ‘L’ stores energy during the time CH2 is on.
When CH2 is turned off,current is fed back to source through diodes D1 , D4 . Note that here ( E+L(di/dt)) is more
than the source voltage Vo. As the Vs is positive and Io is negative, it is a second quadrant operation gives forward braking mode. In that power is fed back from armature to source.it is called forward regenerative Braking.
Third Quadrant :
For third quadrant operation, thyristor CH1 is kept off, CH2 is kept on and CH3 is operated, polarity of armature back emf E must be reversed for this quadrant operation. With thyristor CH3 is on, armature gets connected to source V. so that both Vo, Io are negative, leading to third quadrant operation.
When CH3 is turned off,negative current freewheels through CH2,D4. In this manner only Vo and Io can be controlled in the third quadrant.Motor rotates in reverse direction and it is called Reverse Motoring.
Fourth Quadrant :
Here thyristor CH4 is operated and other devices kept off, back emf E must have its polarity reversed as in third quadrant operation. With CH4 on, positive current flows through CH4,D2 ,L and E (armature). Armature inductance L stores energy during the time CH4 is on.
When CH4 is turned off, current is fed back to source through diodes D2, D3.Here armature voltage Va is negative, but Io is positive, leading to the chopper drive operation in the fourth quadrant. Also power is fed back from armature to source.this is known as Reverse Regenerative Braking.
Result:
Scope Result:
STUDY-2:
2.CIRCUIT DIAGRAM FOR TWO QUADRANT CHOPPER:
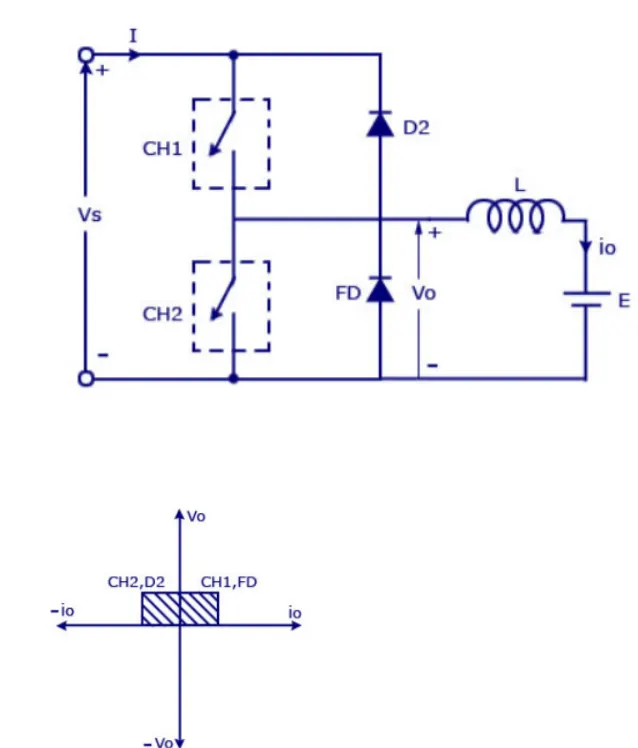
Two quadrant chopper is also called as type c chopper. Type C chopper is obtained by connecting type -A and type-B chopper in parallel.we will alwalys get a postive output voltage Vo as the free wheeling diode FD is present across the load.when the chopper is on the freewheeling diode start conducting and the output voltage Vo will be equal to Vs.The direction of the load current io will be reversed. The current io will be flowing towards the source and it will be positive regardless the chopper is on or the FD conducts. The load current will be negative if the choppernand FD operate together as type-A chopper in first quadrant. In the second quadrant ,the chopper and D2 will operate tpgether as type -B chopper.
The average voltage will be always positive but the average load current might be positive or negative. The power flow may be life the first quardrant operation ie from source to load or from load to source like the second quadrant operation. the two chopper should not be turned on simultaneously as the combined action my cause a short circuit in supply lines. for regenerative braking and motoring these type of chopper configuration is used.
TWO QUADRANT CHOPPER MODEL USING SIMULINK:
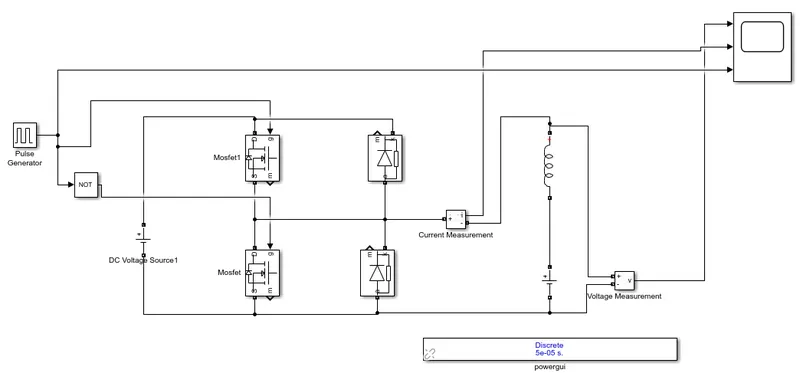
let us take two mosfet block and diodes and connect it as shown in circuit diagram.
the dc voltage source is connected as shown.
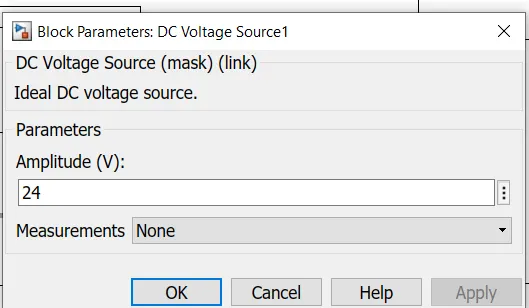
let the voltage of dc voltage source is connected be 24 volts.
let us consider an series RLC branch block and select inductor L. thus block works as a load.
To consider LE load ie motor load,and dc voltage source of 12 volts is also connected in series with inductor.
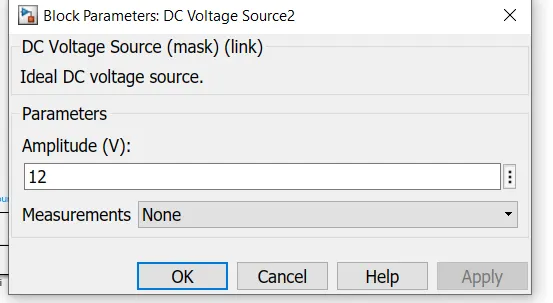
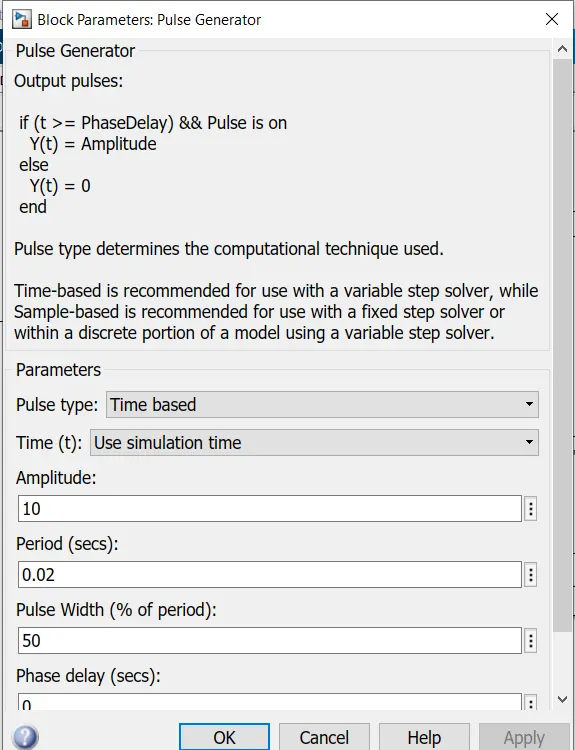
The pulse generator block is used to create gate pulse.
the not gate is used in the model so that the two mosfet will not get closed at the same time otherwise short circuit will occur.due to use of not gate, when one mosfet is ON the other mosfet will get off and when other mosfet is ON the first mosfet will get off.
The amplitude of pulse generator is kept 10 so that we can clearly see the pulse at scope and let period be 0.02 second and let pulse width be 50%
SCOPE :
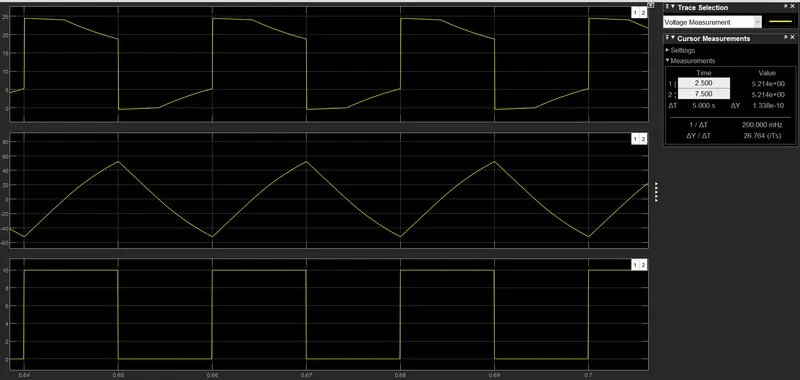
the voltage wavefrom is not going less then zero. the minimum value of voltage is zero and maximum value is always in the positive direction.
however in current waveform , the current increase and decreases. the current may be positive as well as negative.and the pulse amplitude is 10 thus from pulse wave form we can see that the pulse amplitude is 10.
STUDY-3:
detali operation of BLDC motor
WHAT IS A BRUSHLESS DC MOTOR:
A brushless DC motor (also known as a BLDC motor or BL motor) is an electronically commuted DC MOTOR which does not have brushes. The controller provides pulses of CURRENT to the motor windings which CONTROL THE SPEED and torque of the SYSCHORNOUS MOTOR.
These types of motors are highly efficient in producing a large amount of torque over a vast speed range. In brushless motors, permanent magnets rotate around a fixed armature and overcome the problem of connecting current to the armature. Commutation with electronics has a large scope of capabilities and flexibility. They are known for smooth operation and holding torque when stationary.
CONTRUCTION OF BRUSHLESS DC MOTOR:
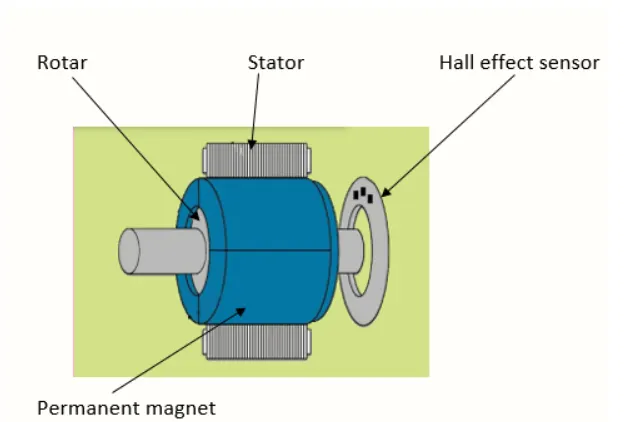
In this motor, the permanent magnets attach to the rotor. The current-carrying conductors or ARMATURE WINDINGS are located on the stator. They use electrical commutation to convert electrical energy into mechanical energy.
The main design difference between a brushed and brushless motors is the replacement of mechanical commutator with an electric switch circuit. A BLDC Motor is a type of synchronous motor in the sense that the magnetic field generated by the stator and the rotor revolve at the same frequency.
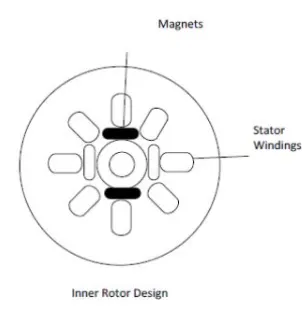
2. BLDC Outer rotor Design:
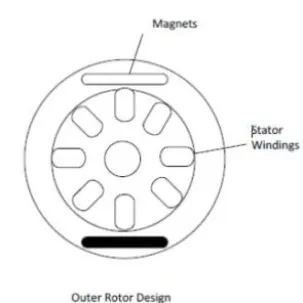
In this design, the rotor is external. i.e. stator windings are located at the core while the rotor, carrying permanent magnets, surrounds the stator.
position sensors(hall sensor):
Since there are no brushes in a BLDC Motor, the commutation is controlled electronically. In order to rotate the motor, the windings of the stator must be energized in a sequence and the position of the rotor (i.e. the North and South poles of the rotor) must be known to precisely energize a particular set of stator windings.
A Position Sensor, which is usually a Hall Sensor (that works on the principle of Hall Effect) is generally used to detect the position of the rotor and transform it into an electrical signal. Most BLDC Motors use three Hall Sensors that are embedded into the stator to sense the rotor’s position.
The output of the Hall Sensor will be either HIGH or LOW depending on whether the North or South pole of the rotor passes near it. By combining the results from the three sensors, the exact sequence of energizing can be determined.
working principle:
BLDC motor works on the principle similar to that of a BRUSHLESS DC MOTOR. The Lorentz force law which states that whenever a current carrying conductor placed in a magnetic field it experiences a force. As a consequence of reaction force, the magnet will experience an equal and opposite force. In the BLDC motor, the current carrying conductor is stationary and the permanent magnet is mov
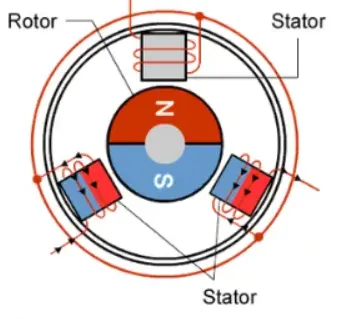
When the stator coils get a supply from source, it becomes electromagnet and starts producing the uniform field in the air gap. Though the source of supply is DC, switching makes to generate an AC voltage waveform with trapezoidal shape. Due to the force of interaction between electromagnet stator and permanent magnet rotor, the rotor continues to rotate.
With the switching of windings as High and Low signals, corresponding winding energized as North and South poles. The permanent magnet rotor with North and South poles align with stator poles which causes the motor to rotate.
ing.
STATOR:
There are three types of the BLDC motor:
- Single-phase
- Two-phase
- Three-phase.
Stator for each type has the same number of windings. The single-phase and three-phase motors are the most widely used. The simplified cross section of a single-phase and a three-phase BLDC motor is shown in figure below. The rotor has permanent magnets to form two magnetic pole pairs, and surrounds the stator, which has the windings.
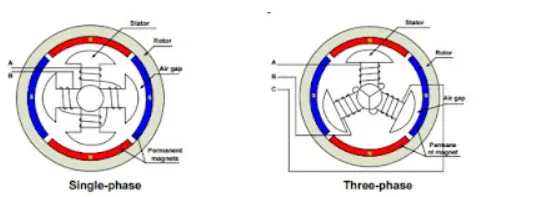
A single-phase motor has one stator winding wound either clockwise or counter-clockwise along each arm of the stator to produce four magnetic poles as shown in above figure.
A three phase BLDC motor has three windings. Each phase turns on sequentially to make the rotor revolve.
ROTOR:
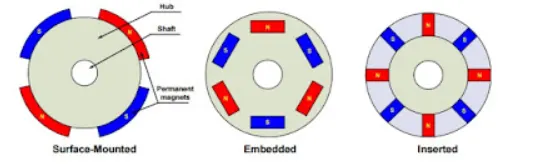
A rotor consists of a shaft and a hub with permanent magnets arranged to form between two to eight pole pairs that alternate between north and south poles. Figure below shows cross sections of three kinds of magnets arrangements in a rotor.
- It has no mechanical commutator and associated problems
- High efficiency due to the use of permanent magnet rotor
- High speed of operation even in loaded and unloaded conditions due to the absence of brushes that limits the speed
- Smaller motor geometry and lighter in weight than both brushed type DC and induction AC motors
- Long life as no inspection and maintenance is required for commutator system
- Higher dynamic response due to low inertia and carrying windings in the stator
- Less electromagnetic interference
- Quite operation (or low noise) due to absence of brushes
DISADVANTAGES OF BRUSHLESS DC MOTOR:
- These motors are costly
- Electronic controller required control this motor is expensive
- Not much availability of many integrated electronic control solutions, especially for tiny BLDC motors
- Requires complex drive circuitry
- Need of additional sensors.
APPLICATION OF BRUSHLESS DC MOTOR:
- Computer hard drives and DVD/CD players
- Electric vehicles, hybrid vehicles, and electric bicycles
- Industrial robots, CNC machine tools, and simple belt driven systems
- Washing machines, compressors and dryers
- Fans, pumps and blowers