Week 7 Challenge
The first step in vehicle performance modelling is to produce an equation for the tractive effort. This is the force propelling the vehicle forward, transmitted to the ground through the drive wheels.
Consider a vehicle of mass m, proceeding at a velocity v, up a slope of angle ψ, as in below figure.
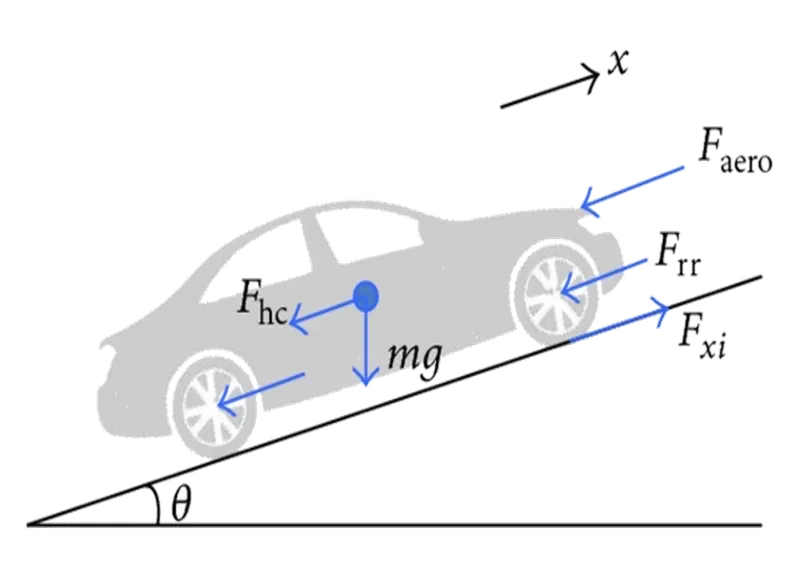
The force propelling the vehicle forward, the tractive effort, has to accomplish the following:
Rolling resistance force
The rolling resistance is primarily due to the friction of the vehicle tyre on the road.
Friction in bearings and the gearing system also play their part. The rolling resistance is
approximately constant, and hardly depends on vehicle speed. The equation is:
Frr = µrr m g
Where µrr is the coefficient of rolling resistance.
The main factors controlling µrr are the type of tyre and the tyre pressure. .
Typical values of μrr are 0.015 for a radial ply tyre, down to about 0.005 for tyres developed especially for electric vehicles.
Aerodynamic drag
This part of the force is due to the friction of the vehicle body moving through the air. It is a function of the frontal area, shape, protrusions such as side mirrors, ducts and air passages, spoilers, and many other factors.
The formula for this component is:
Fad = ½ ρACdv2
where ρ is the density of the air, A is the frontal area, and v is the velocity. Cd is a constant called the drag coefficient.
The drag coefficient Cd can be reduced by good vehicle design. A typical value for a saloon car is 0.3, but some electric vehicle designs have achieved values as low as 0.19.
Hill climbing force
The force needed to drive the vehicle up a slope is the most straightforward to find. It is simply the component of the vehicle weight that acts along the slope. By simple resolution of forces we see that:
Fhc = m g sin(Ψ)
Total tractive effort
The total tractive effort is the sum of all these forces:
Fte = Frr + Fad + Fhc
Simulink Model of Vehicle:
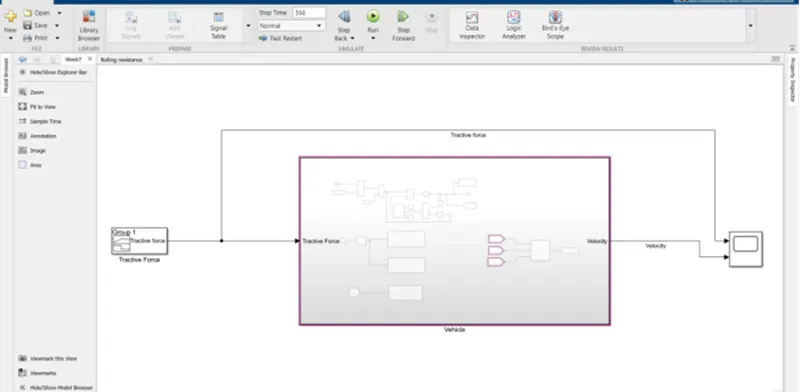
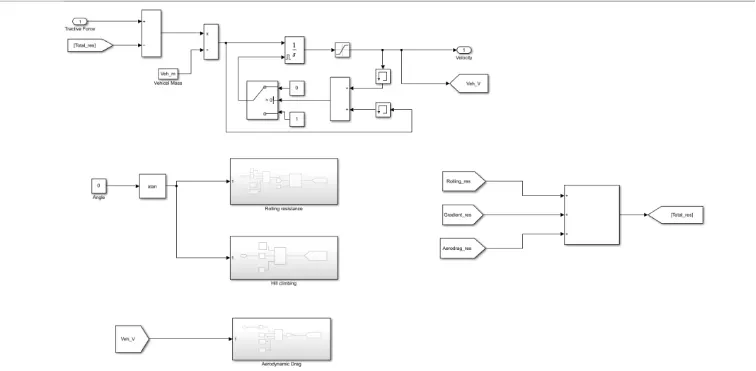
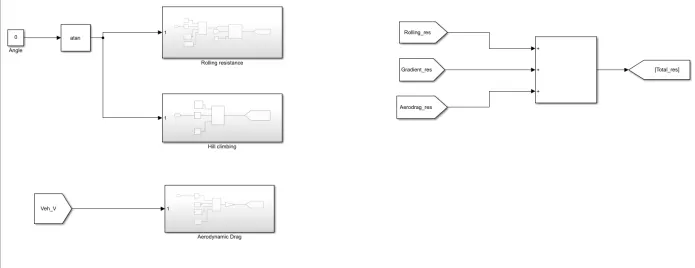
This is model with all the vehicle forces and dynamics with traction force as input and velocity as output. Inside subsystem we can observe all the blocks connected according vehicle equations.
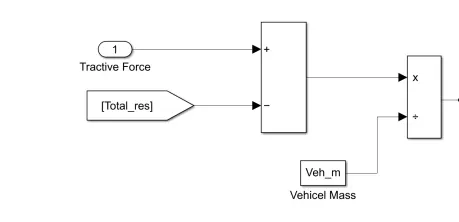
The top part model is to calculate resultant tractive force according to the equation by subtracting resistance forces from the tractive force. Then this is force is divided by mass to convert it into acceleration which is further integrated to get the velocity.
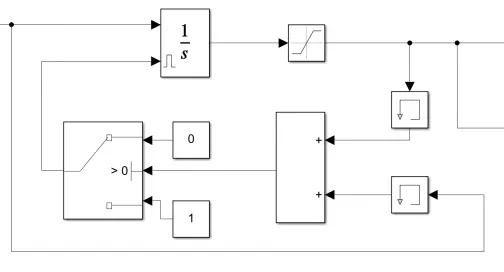
Here at Integrator, due to the integral windup the overshoot occurs. This windup can be overcome by using anti windup. This is obtained by using external reset by using switch and set reset values.
When the acceleration and velocity is not equal to zero, then external reset is set. When the acceleration and velocity is zero, then the external reset is reset.
By considering the initial condition of vehicle which is zero, in order to reject the unwanted errors, the memory is used.
Then the saturation block is used to get the forward velocity from zero to infinity.
Resistance forces subsystems:
Rolling Resistance force:
Rolling resistance force is the force due to the friction of tyre and surface. Factors that contribute to rolling resistance are deformation of the wheels, the deformation of the roadbed surface, and movement below the surface Rolling resistance force can be formulated by multiplying the weight of the vehicle and coefficient of rolling resistance.
Frr=Veh_mass* g * Rolling resitance coeff * cos(alpha)
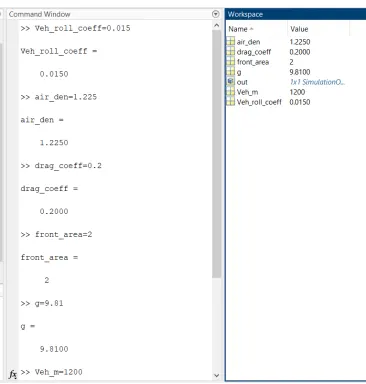
Veh_mass= 1200 kg
Roll reistance coeff = 0.015
G = 9.81 m/s
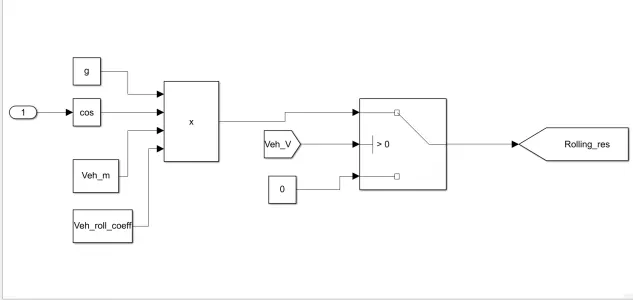
Here from the subsystem we can abserve that it is built according to the equation mentioned above. Here the switch block is used for considering the rolling resistance only when velocity is greater than 0 such that when vehicle is moving.
And it output Roll_Res taken as goto block which connects at the additions of all the reistance forces.
Aerodynamic Drag force:
Air Drag force is the force due to wind velocity opposing the vehicle on the frontal area. Air drag force on the vehicle is minimum when the vehicle is moving slowly. If the speed increases, the air drag force also increases. This creates the opposing force on the vehicle. Air drag force can be identified by using the formula.
Faero = (1/2)*Cd*Af* delta*Veh_V^2
Cd = Drag coefficient = 0.2
Af = Frontal area = 1.97 m^2
Delta = Air density = 1.225 kg/m^3
V = Velocity of vehicle in m/s
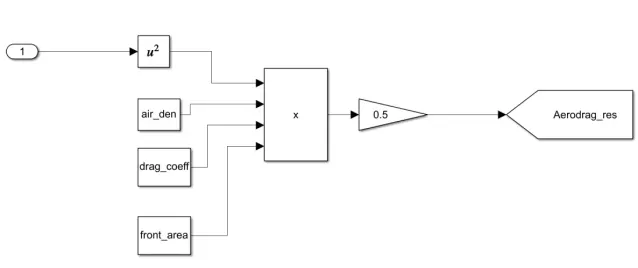
This is the Aerodynamic drag force subsystem which is according to the Faero equation.
Hill Climbing force:
Hill climbing force (grade resistance) is the force acting against the direction of acceleration of vehicle when the vehicle moving at a certain angle (slope). This force is acting in opposite due to gravity.
Fhc=Veh_mass * g * sin (alpha)
Veh_mass = Mass of the vehicle =1200 kg
g = gravity = 9.81 m/s
alpha = angle in radians
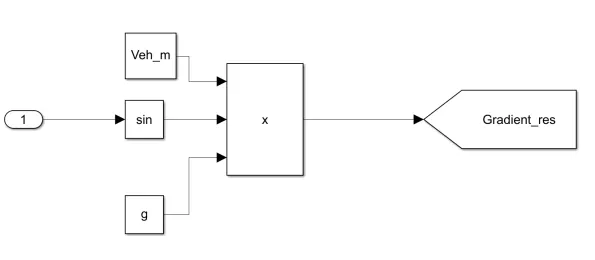
This is the Hill climbing force subsystem which is according to the Fhc equation.
All these forces are added to get the Total resistance forces as shown below.
The parameters are initialised in the command window, thus saved to the workspace as shown.
Result:
Here the scope is connected to the input tractive force and the output Velocity and simulation is run for 598 sec.
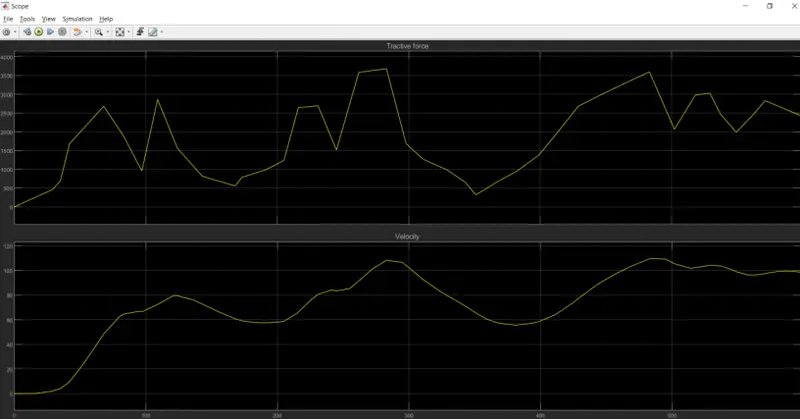
From the plot we can observe the tractive force and velocity graphs.
We can observe that whenever the tractive force is increasing then the velocity of the vehicle is increasing and when traction force is decreasing then velocity is decreasing.
And we can also observe that for first few seconds the velocity is still even when the traction force is increasing and this is due to resistance forces that opposing the vehicle velocity.