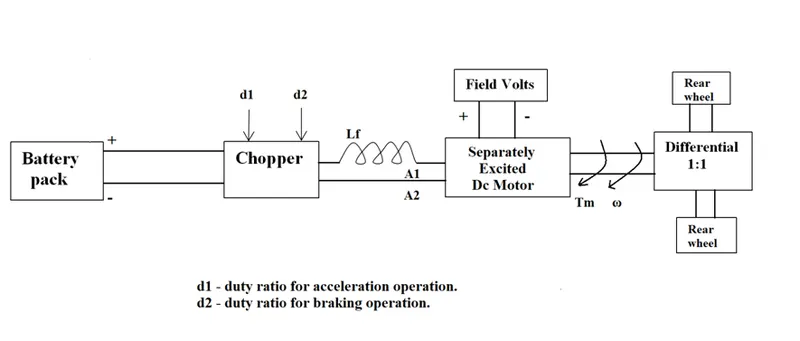
| The other parameters of the electric vehicle is given below, |
| |
|
|
|
|
| Motor and Controller Parameters: |
|
| |
|
|
|
|
| Rated Armature voltage= 72 V |
| |
|
|
|
|
| Rated armature current= 400 A |
| |
|
|
|
|
| Ra= 0.5Ω, KΦ= 0.7 Volt second |
| |
|
|
|
|
| Chopper Switching frequency= 400 Hz |
| |
|
|
|
|
| The vehicle speed-torque characteristics are given by the below equation |
|
|
|
|
|
|
| |
|
|
|
|
| |
|
|
|
|
| |
|
|
|
|
| What is EV steady state speed if duty cycle is 70%? |
| Ans |
|
|
|
|
| |
Given values |
|
|
| |
|
|
|
|
| |
Armature voltage= 72 V |
|
| |
|
|
|
|
| |
Rated armature current= 400 A |
| |
|
|
|
|
| |
Ra= 0.5Ω, KΦ= 0.7 Volt second |
| |
|
|
|
|
| |
Chopper Switching frequency= 400 Hz |
| |
|
|
|
|
| |
|
Vv = Battery Voltage (V) * Duty Cycle |
| |
|
|
|
|
| |
|
Vv = 72 * 0.70 |
|
| |
|
|
|
|
| |
|
Vehicle voltage = 50.4V |
| |
|
|
|
|
| Now, Equation for Vehicle torque is given by: - |
| |
|
|
|
|
| |
`T_v= ((V_v- ω.K_∅ )*K_∅)/R_a` |
| |
|
|
|
|
| |
Where; |
|
|
|
| |
|
|
|
|
| |
`T_v`= Vehicle Torque (N-m) |
| |
|
|
|
|
| |
`V_v` = Vehicle voltage (Volts) |
| |
|
|
|
|
| |
`ω`= steady state speed of vehicle (rps) |
| |
|
|
|
|
| |
`K_∅`= Motor constant |
|
| |
|
|
|
|
| |
`R_a`= Armature Resistance |
|
| |
|
|
|
|
| |
`T_v= ((50.04 - 0.7*ω)*0.7)/0.5` |
| |
|
|
|
|
| |
`T_v=70.56-0.98*ω` |
|
| |
|
|
|
|
| |
`T_v=24.7+0.0051*ω^2` |
|
| |
|
|
|
|
| |
Solving these two equations, |
|
| |
|
|
|
|
| |
`70.56-0.98*ω =24.7+0.0051*ω^2` |
| |
|
|
|
|
| |
We get a quadratic equation: |
|
| |
|
|
|
|
| |
`0.0051*ω^2+0.98*ω-46.94=0` |
| |
|
|
|
|
| |
Since quadratic equation, we get two values of ; |
| |
|
|
|
|
| |
`ω`= 38.85 rad/s and `ω` = -230.95 rad/s |
| |
|
|
|
|
| |
We take the positive value; |
|
| |
|
|
|
|
| |
Steady state speed of vehicle = = 38.85 rad/s |