Week-6 Challenge: EV Drivetrain
Aim:
1. To describe the types of power converter circuits are employed in electric and hybrid electric vehicle
2. To find the speed using the torque-speed characteristics equation.
3. To develop a mathematical model of a DC Motor using Simulink.
4. To know briefly about Induction and Brushless DC motors.
Model:
1. Types of Power Converters
Power electronic converters are used everywhere in normal daily routines in our environment. Due to the high power handling with higher efficiencies, these converters become an integral part of industrial electric drives, high electric power supplies, electric traction systems, and automobile control equipment.
A power electronic converter uses power electronic components such as SCRs, TRIACs, IGBTs, etc. to control and convert the electric power. The main aim of the converter is to produce conditioning power with respect to a certain application.
The power electronic circuit consists of both the power part and the control part. The power part transfers the energy from source to load and it consists of power electronic switches (SCR or TRIAC), transformers, electric choke, capacitors, fuses, and sometimes resistors.
Power electronic converters perform various basic power conversion functions. This converter is a single power conversion stage that can perform any of the functions in AC and DC power conversion systems.
Depending on the type of function performed, power electronic converters are categorized into the following types:
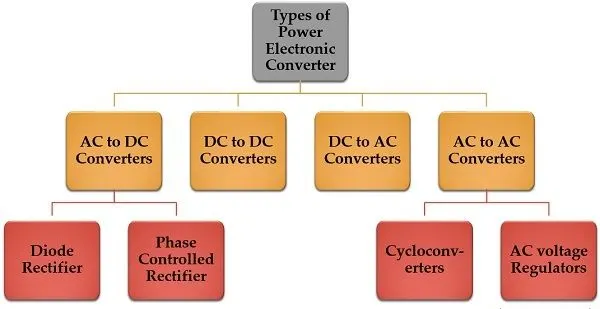
AC to DC Converters:
An AC to DC converter is also called a rectifier, which converts AC supply from main lines to DC supply for the load.
An AC to DC converter will prevent the current from changing direction so that it only follows unidirectionally. in the circuit of an AC to DC converter, there is a step-down transformer, a diode, a capacitor, and a low drop out voltage (LDO) regulator.
The step-down transformer takes the high-level 230V from the main supply and steps it down to a lower level. eg. 12 or 13 v for our use, but it is still in AC form. Then a diode or group of diodes is implemented to restrict the current to flow in just one direction.
In the case of EVS or HEVS, the battery pack which operates with a DC power supply is charged at home or at a charging station both of which are supplied power in AC form from the electric grid. So, the chargers for these vehicles are an example of the AC to DC power converter.
DC to DC Converter:
The converters that convert the dc signal of fixed frequency present at the input into a variable dc signal at the output are also known as choppers.
In the case of EVs and HEVS, the battery pack will supply its power to the inverter. The inverter contains a transformer that consists of a primary and secondary winding. The current from the battery is first supplied to the primary winding where the electronic switches will repeatedly reverse the direction of the current to create an AC waveform. This current will return back the way it came from. The AC current in the primary winding will induce an AC current in the secondary winding which then supplies this current to an AC load e.g. the AC traction motor.
DC to AC Converter:
A DC to AC converter is also called an inverter, which converts DC supply from main lines to AC supply for the load.
By taking the DC supply and passing it through a switching element which converts the waveform to a square wave which is actually AC in nature. Then this AC is passed through a filter which will turn it back into a DC supply for use in a load.
In EVS, HEVs, and conventional vehicles, this type of converter is used for various purposes. E.g. In the case of stepping down the voltage, the car radio may require a stepped-down voltage of 12V to operate and would not need the full voltage of the car battery. In the case of stepping up the voltage, the motor of a car may require 500V to operate, but the vehicle may need more voltage than the battery pack can provide.
There are 2 main types of DC to DC converters which are isolated and non-isolated types. The non-isolated type can be subdivided into 5 types:
- Buck - to step down the voltage
- Boost - to step up the voltage Buck/Boost can do both step-up and step-down operations but is mainly used to reverse polarity
- Buck/Boost - this can do both step-up and step-down operations but is mainly used to reverse polarity
- Cuk - similar to the Buck/Boost type
- Charge Pump - to step up/step down the voltage for low power sources
The isolated type can be subdivided into 2 types:
- Flyback converter - similar to the Buck-Boost converter except it uses a transformer instead of an inductor to store energy
- Forward converter - this type will use a transformer to send energy between the input and output in a single step
AC to AC Converter:
AC to AC converters connect an AC source to AC loads by controlling the amount of power supplied to the load. This converter converts the AC voltage from one level to the other by varying its magnitude as well as the frequency of the supply voltage.
This type of converter takes an input AC waveform with a particular voltage and frequency and outputs a different AC waveform with another voltage and frequency. The output voltage and/or frequency can be changed or maintained depending on the application. This converter has many applications in our daily life e.g. lamp dimming, and motor speed control. There are 4 main types of AC to AC converters:
- Cycloconverters
- AC to AC convert with DC Link
- Matrix Converter
- Hybrid Matrix Converter
2. EV steady State Speed
Input:
Rated Armature voltage= 72 V
Rated armature current= 400 A
Ra= 0.5, KΦ= 0.7 Volt second
Chopper Switching frequency=400 Hz
The vehicle speed-torque characteristics are given by the below equation
Tv=24.7+ ((0.0051)w^2)
Formulae:
As the torque formula is given, we need to find the speed in rad/sec. Use the other expression available which is given below:
T = (V*kΦ)/R - (((KΦ^2)/R)*w)
Where,
T = torque
V = armature voltage
R = resistance
w = speed rad/sec
Calculation:
Duty cycle =70% = 0.7
Voltage at 70% = 0.7*72= 50.4V
Torque speed characteristics of DC motor:
T= (V*kΦ)/R - (((KΦ^2)/R)*w)
= ((50.4*0.7)/0.5)-(((0.7^2)/0.5)*w)
= (35.28/0.5)-((0.49/0.5)*w)
T= 70.56- (0.98*w)
Equating both T,
24.7+ ((0.0051)w^2) = 70.56- (0.98*w)
(0.0051*(w^2))+(0.98*w)-45.86=0
Divide by 0.0051
(w^2)+(192.156*w)-8992.156 = 0
The roots of above equation are
w= 38.915 rad/sec or w = -231.0718 rad/sec
As the speed value of a vehicle can not be negative.
so w=38.915 rad/sec
3. A Mathematical Model Of DC Motor
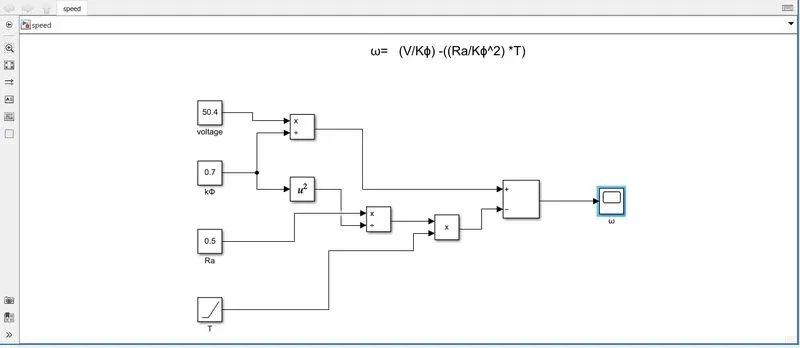
Let us create a model for the given equation ω= (V/Kϕ) -((Ra/Kϕ^2) *T)
For the above equation, I have created a model of a DC motor using the previous questions inputs:
Rated Armature voltage= 72 V
Rated armature current= 400 A
Ra= 0.5, KΦ= 0.7 Volt second
Result:
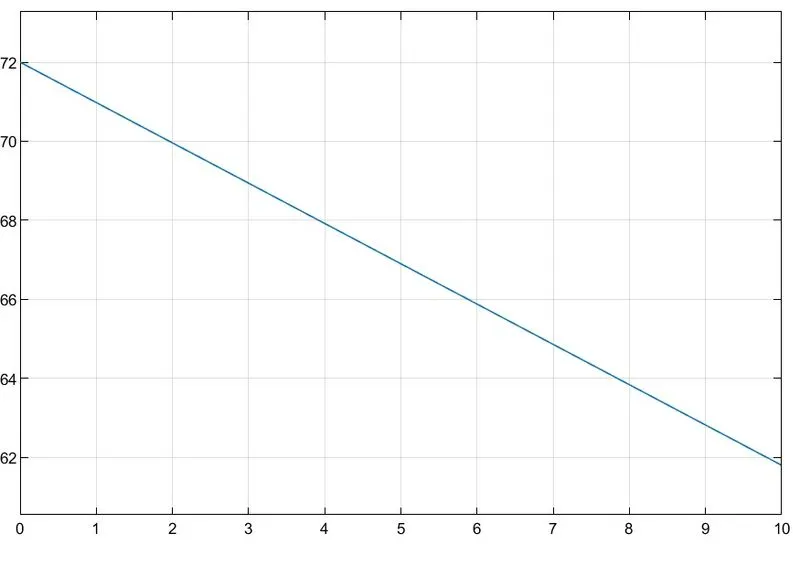
The above graph represents the output of the given equation. hence we have created the model of the DC motor in Simulink using the given equation.
4. Brief about Induction and DC Brushless Motor
Wally Ripple is a long-time proponent of electric vehicles. Prior to joining Tesla Motors, he was an engineer at AeroVironment, where he helped develop the EV1 for General Motors and was featured in the documentary movie, Who Killed the Electric Car? Wally has also worked for the Jet Propulsion Laboratory on electric vehicle battery research, among other projects. In 1968, as a Caltech undergraduate student, he built an electric car (a converted 1958 Volkswagen microbus) and won the Great Transcontinental Electric Car Race against MIT.
In the beginning, the author describes the dominance of Internal Combustion Engines (ICE) in the world of the automobile industry. He explains that all engines were similar and it was up to the user to select according to their requirement. Next, the author highlights topics related to EV technology especially related to DC Brushless Motor and Induction Motor.
According to him, DC Brush Motors was replaced by either DC Brushless Motor or Induction Motor. Also, the Lead Acid Battery is replaced by lithium-ion batteries for EVs. He also quoted that there will be the future of both the technology depending upon their demands and uses.
Induction Motor:
- The technology behind the induction motor is that it basically uses a 3-phase induction motor which was invented by Nikola Tesla sometime before 1889.
- Unlike the DC brushless rotor, the induction rotor has no magnets - just stacked steel laminations with buried peripheral conductors that form a "shorted structure." Currents flowing in the stator windings produce a rotating magnetic field that enters the rotor.
- In an Induction, motor current interacts with the Magnetic field generated by the stator to produce a force that is required for rotor torque.
- When a 3-phase induction motor is connected to utility type 3-phase power, torque is produced at the outset. The fact that induction motors are directly compatible with conventional utility power is the main reason for their success.
Advantage:
- The induction motor does not have any magnets and in this the B field is adjustable.
- The motor has the ability to start under load and there is no need for an inverter. In an induction, motor B field is proportionate to v/f.
- This technology is used to reduce the magnetic losses and conduction losses, due to which efficiency will remain at its maximum peak.
- This leads to increasing the performance, induction motor is very useful and efficient for high performance.
Disadvantage:
- An induction motor cannot operate from DC Voltage it always requires an AC voltage supply.
- In an induction motor, the Shaft speed is proportionate to line frequency. Hence, when used with utility power they are constant speed machines.
- When operated from utility power, they have limited starting torque and somewhat limited running peak torque capabilities, when compared to DC-type machines.
DC Brushless Motor:
- With brushless machines, the rotor includes two or more permanent magnets that generate a DC magnetic field.
- In turn, this magnetic field enters the stator core and interacts with currents flowing within the windings to produce a torque interaction between the rotor and stator.
- As the rotor rotates, it is necessary that the magnitude and polarity of the stator currents be continuously varied - and in just the right way - such that the torque remains constant and the conversion of electrical to mechanical energy is optimally efficient.
- The device that provides this current control is called an inverter. Without it, brushless motors are useless motors.
- The author also said that a brushless DC motor produces no starting torque when directly connected to fixed frequency utility power. They really need the aid of an inverter whose "phase" is maintained in step with the angular position of the rotor.
Advantage:
- There is low heat generation in the rotor and its cooling capacity is better as compared to Induction Motor.
- Peak point efficiency is generally higher for this drive.
- The DC brushless drive can also operate at a unity power factor, whereas the best power factor for the induction drive is about 85%.
Disadvantage:
- As Machine size grows, the magnetic losses increase proportionately and part load efficiency drops.
- Permanent magnets are expensive and difficult to handle due to very large forces.
Inference:
In the end, the author couldn't choose which drive is better than the other but makes it clear that DC Brushless motor drives will likely continue to dominate in the Hybrid and upcoming Plug-in hybrid markets and induction motor drives will likely maintain dominance for the high-performance pure electric.
Conclusion:
- We have discussed and studied the different types of power converter circuits employed in electric and hybrid electric vehicles.
- EV Steady-state speed of an EV Drivetrain was determined with the given input conditions.
- The Mathematical model for DC motor is developed.