Week-7 Challenge: DC Motor Control
1. A. Speed Control Of DC Motor
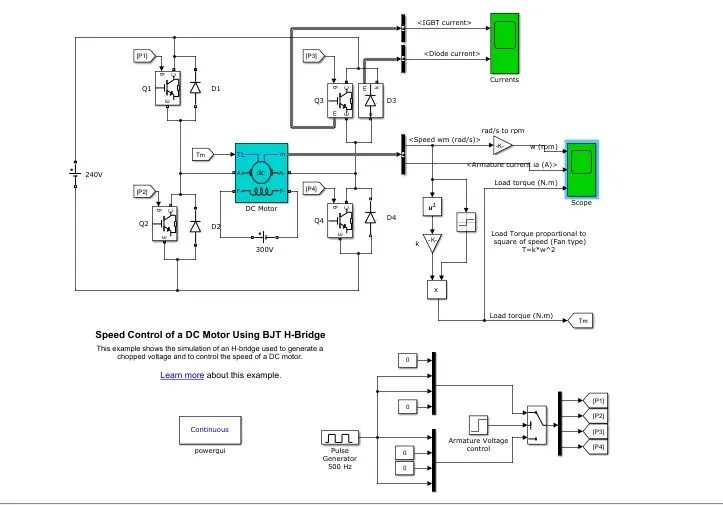
This model shows the simulation of an H bridge used to generate a chopped voltage and to control the speed of a DC motor.
The Bipolar Junction Transistor (BJT) when used for power switching applications, operates as an IGBT. When it is conducting (BJT operating in the saturated region), a forward voltage Vf is developed between collector and emitter (in the range of 1 V). Therefore, the IGBT block can be used to model the BJT device.
The IGBT block does not simulate the gate current controlling the BJT or IGBT. The switch is controlled by a Simulink® signal (1/0). The DC motor uses the preset model (5 HP 24V 1750 rpm). It simulates a fan type load (where Load torque is proportional to the square of speed). The armature means voltage can be varied from 0 to 240 V when the duty cycle (specified in the Pulse Generator block) is varied from 0 to 100%.
The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models). Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3. When QI and Q4 are fired, a positive voltage is applied to the motor, and diodes D2-D3 operate as free-wheeling diodes when QI and Q4 are switched off. When Q2 and Q3 are fired, a negative voltage is applied to fire, a negative voltage is applied to the motor, and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
The motor starts in the positive direction with a duty cycle of 75%(mean DC voltage of 180V). At t= 0.5 sec., the armature voltage is suddenly reversed and the motor runs in the negative direction.
Model results:
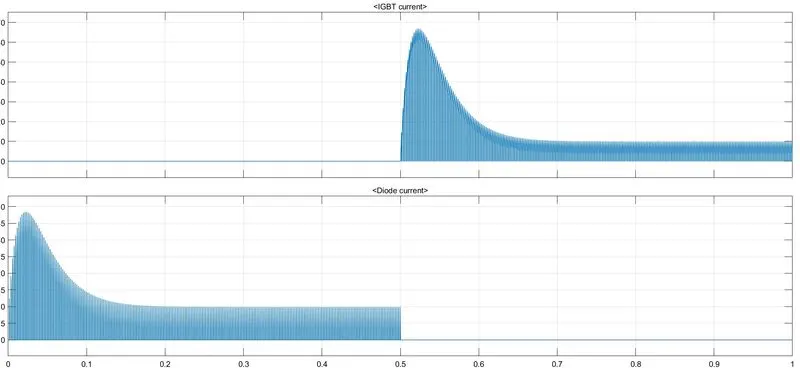
- In the scope of the results, we can observe that after 0.5 seconds the IGBT current starts flowing.
- The current starts flowing in the diode initially up to 0.5 seconds.
- There is no passage of diode current which indicates that the current may pass in the reverse direction.
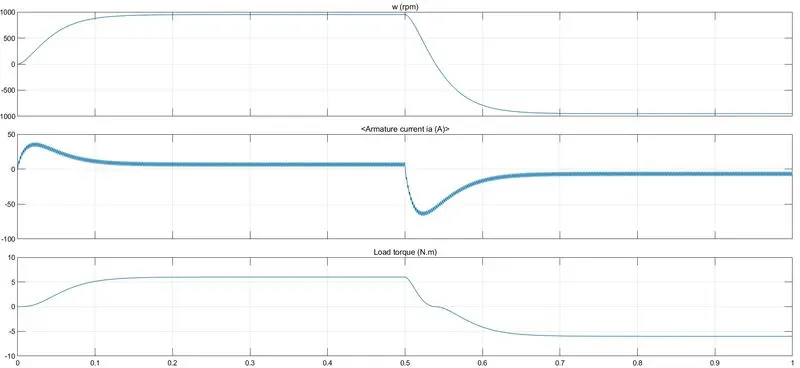
- We can observe initially the speed is increased to the top and maintained up to 0.5 seconds. After that, it is reduced and goes to negative.
- After 0.5 seconds we can observe armature current shoots up.
- The load also decreases after 0.5 seconds.
1. B. Armature current shoot-up
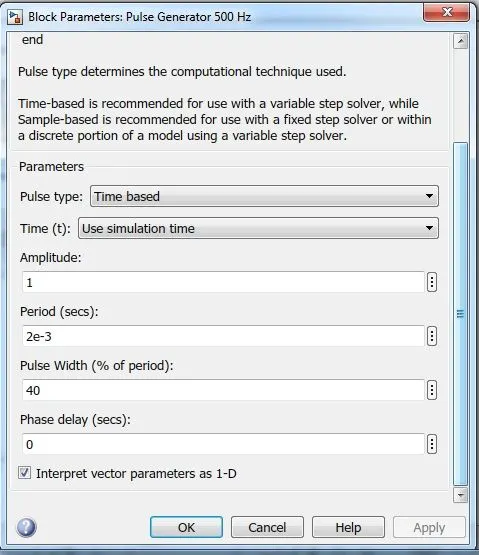
Change the duty cycle, So that the motor changes its direction from forward to reverse and the armature current doesn't shoot up. Change pulse width from 75% to 40%.
Results:
- We can observe switching for 40% pulse width.
- We can observe that the armature current doesn't shoot up.
- Instead of a sudden decrease, there is a slow decrease in speed and load torque after 0.5 seconds.
- The variations are less when compared with the high duty cycle.
C. Compare DC Four Quadrant Chopper and H-Bridge
| DC Four Quadrant Chopper | H-Bridge |
|
It consists of four-quadrant motoring, forward motoring, Regenerative forward braking, reverse motoring, and Regenerative reverse braking. |
It consists of two operations forward motoring and reverse motoring. |
|
PID controller is used in the DC7 model. |
PID controllers are not used in this model. |
|
It operates in 4 quadrants. |
It operates in 2 quadrants. |
| A four-quadrant controlled chopper is used for converting a fixed DC input to a variable DC output. | H-bridge arrangement is generally used to reverse the polarity/direction of the motor |
| This model contains speed and current regulators. | This model contains speed and current Controller. |
2. Two Quadrant Chopper
A two-quadrant chopper is also called a type c chopper. Type C chopper is obtained by connecting type -A and type -B choppers in parallel. We will always get a positive output voltage Vo as the freewheeling diode FD is present across the load. When the chopper is on the freewheeling diode starts conducting and the output voltage vo will be equal to Vs. The direction of the load current io will be reversed. The current io will be flowing towards the source and it will be positive regardless of whether the chopper is on or the FD conducts. The load current will be negative if the chopper or the diode D2 conducts. We can say the chopper and FD operate together as a type-A chopper in the first quadrant. In the second quadrant, the chopper and D2 will operate together as type -B choppers.
The average voltage will be always positive but the average load current might be positive or negative. The power flow may be living the first quadrant operation ie from source to load or from load to source like the second quadrant operation. The two choppers should not be turned on simultaneously as the combined action may cause a short circuit in supply lines. For regenerative braking and motoring, this type of chopper configuration is used.
TWO QUADRANT CHOPPER MODEL USING SIMULINK:
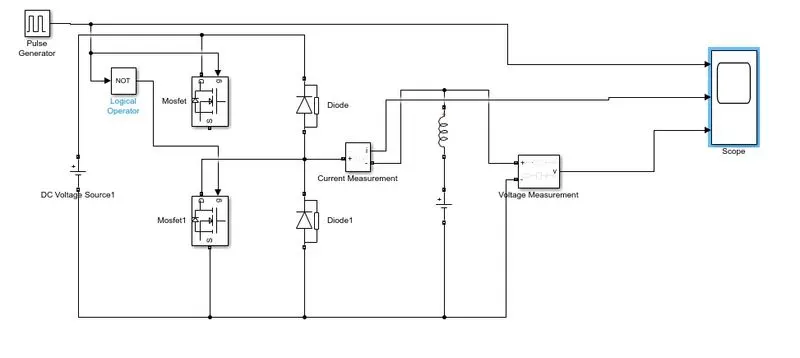
Let us take two MOSFET blocks and diodes blocks and connect them as shown in the circuit diagram.
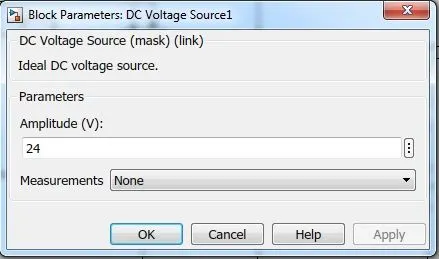
The dc voltage source is connected as shown and let the voltage of the dc voltage source be 24 volts.
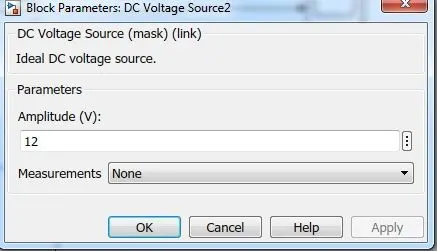
Let us consider a series RLC branch block and select inductor L. thus block works as a load and a dc voltage source of 12 volts is also connected in series with the inductor.
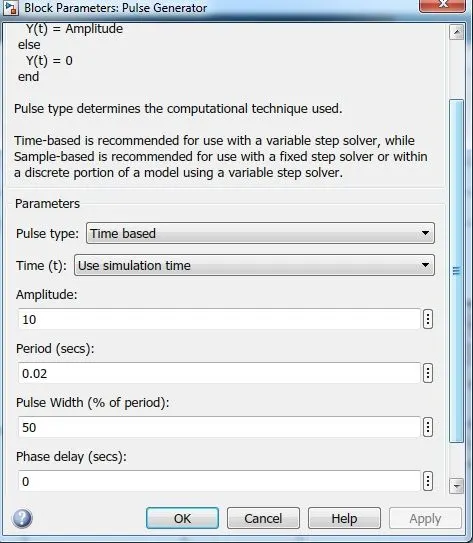
The pulse generator block is used to create a gate pulse.
The not gate is used in the model so that the two MOSFET will not get closed at the same time otherwise short circuit will occur .due to the use of the not gate, when one MOSFET is ON the other MOSFET will get off and when another MOSFET is ON the first MOSFET will get off.
The amplitude of the pulse generator is kept at 10 so that we can clearly see the pulses at the scope. Let the period be 0.02 seconds and let the pulse width be 50%.
Result:
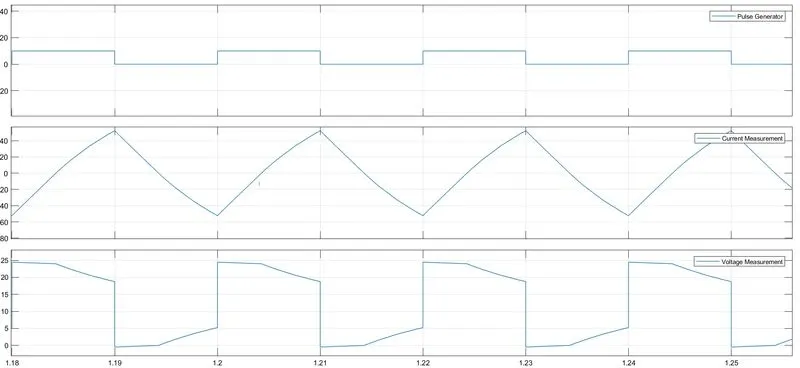
The voltage waveform is not going less than zero. the minimum value of voltage is zero and the maximum value is always in the positive direction.
However in the current waveform, the current increases, and decreases. the current may be positive as well as negative and the pulse amplitude is 10 thus from the pulse waveform we can see that the pulse amplitude is 10.
3. BLDC MOTOR
Brushless DC electric motors are also known as electronically commutated motors. A brushless DC motor (known as BLDC) is a permanent magnet synchronous electric motor which is driven by direct current (DC) electricity and it accomplishes an electronically controlled commutation system(commutation is the process of producing rotational torque in the motor by changing phase currents through it at appropriate times) instead of a mechanical commutation system. BLDC motors are also referred to as trapezoidal permanent magnet motors.
This electronic commutation arrangement eliminates the commutator arrangement and brushes in a DC motor and hence more reliable and less noisy operation is achieved. Due to the absence of brushes BLDC motors are capable to run at high speeds. The efficiency of BLDC motors is typically 85 to 90 percent, whereas brushed type DC motors are 75 to 80 percent efficient. There are wide varieties of BLDC motors available ranging from small power range to fractional horsepower, integral horsepower, and large power ranges.
BLDC motors can be constructed in different physical configurations. Depending on the stator windings, these can be configured as single-phase, two-phase, or three-phase motors. However, three-phase BLDC motors with permanent magnet rotors are most commonly used.
The construction of this motor has many similarities to a three-phase induction motor as well as a conventional DC motor. This motor has stator and rotor parts like all other motors.
WORKING OF BLDC MOTOR:
The underlying principles for the working of a BLDC motor are the same as for a brushed DC motor; i.e., internal shaft position feedback. In the case of a brushed DC motor, feedback is implemented using a mechanical commutator and brushes. With a BLDC motor, it is achieved using multiple feedback sensors. The most commonly used sensors are hall sensors and optical encoders. Hall sensors work on the hall effect principle that when a current-carrying conductor is exposed to the magnetic field, charge carriers experience a force based on the voltage developed across the two sides of the conductor.
If the direction of the magnetic field is reversed, the voltage developed will reverse as well. For Hall-effect sensors used in BLDC motors, whenever rotor magnetic poles (N or S) pass near the hall sensor, they generate a HIGH or LOW-level signal, which can be used to determine the position of the shaft.
In a commutation system - one that is based on the position of the motor identified using feedback sensors - two of the three electrical windings are energized at a time.
This torque is at its maximum when the rotor starts to move, but it reduces as the two fields align with each other. Thus, to preserve the torque or to build up the rotation, the magnetic field generated by the stator should keep switching. To catch up with the field generated by the stator, the rotor will keep rotating. Since the magnetic field of the stator and rotor both rotate at the same frequency, they come under the category of synchronous motor.
This switching of the stator to build up the rotation is known as commutation. For 3 phase windings, there are 6 steps in the commutation; i.e., 6 unique combinations in which motor windings will be energized.
ADVANTAGES OF BLDC MOTOR:
- Less overall maintenance due to the absence of brushes.
- Reduced size with far superior thermal characteristics Higher speed range and lower electric noise generation.
- It has no mechanical commutator and associated problems.
- High efficiency and high output power to size ratio due to the use of permanent magnet rotor.
- High speed of operation even in loaded and unloaded conditions due to the absence of brushes that limits the speed.
- Smaller motor geometry and lighter in weight than both brushed type DC and induction AC motors.
- Long-life as no inspection and maintenance is required for commutator system.
- Higher dynamic response due to low inertia and carrying windings in the stator.
- Less electromagnetic interference.
- Low noise due to the absence of brushes.
DISADVANTAGES OF BLDC MOTOR:
- These motors are costly.
- The electronic controller required to control this motor is expensive.
- Requires complex drive circuitry.
- Need for additional sensors.
APPLICATION OF BLDC MOTOR:
- Brushless DC motors (BLDC) are used for a wide variety of application requirements such as varying loads, constant loads, and positioning applications in the fields of industrial control, automotive, aviation, automation systems, and health care types of equipment, etc.
- Computer hard drives and DVD/CD players
- Electric vehicles, hybrid vehicles, and electric bicycles
- Industrial robots, CNC machine tools, and simple belt-driven systems Washing machines, compressors, and dryers.
- Fans, pumps, and blowers.
CONCLUSION:
- MATLAB demo model named 'Speed control of a DC motor using BJT H bridge is studied and the armature current shoot-up is studied and 'The Four-Quadrant Chopper DC Drive (DC7) block is also studied and Compared with the H-bridge model.
- Two-quadrant chopper using the Simulink model is made and the various results obtained are studied.
- The operation of the BLDC motor is studied.