Week-6 Challenge: EV Drivetrain
Question-1:- Which types of power converter circuits are employed in electric and hybrid electric vehicle?
Answer:- 3 types of power converters are mostly use in electric & hybrid EV-
1) AC to DC converters (rectifiers) - these coverters are use in plugin EV & HEV for charging DC battery from AC source.
2) DC to DC converters (chopper)- chopper are use where vehicle has DC motors, DC supply from battery is converted in to variable DC to control the speed of motor. they are called DC drives.
3) DC to AC converters (inverters)- these converters are use if EV or HEV has AC induction motor , DC supply from battery is converted into variable AC to run the motor in variable speed, this device is known as VFD.
Question-2:- An Electric Vehicle's powertrain with 72V battery pack in shown in the diagram below. The duty ratio for acceleration operation is 'd1' and for the braking operation the duty ratio is 'd2'.
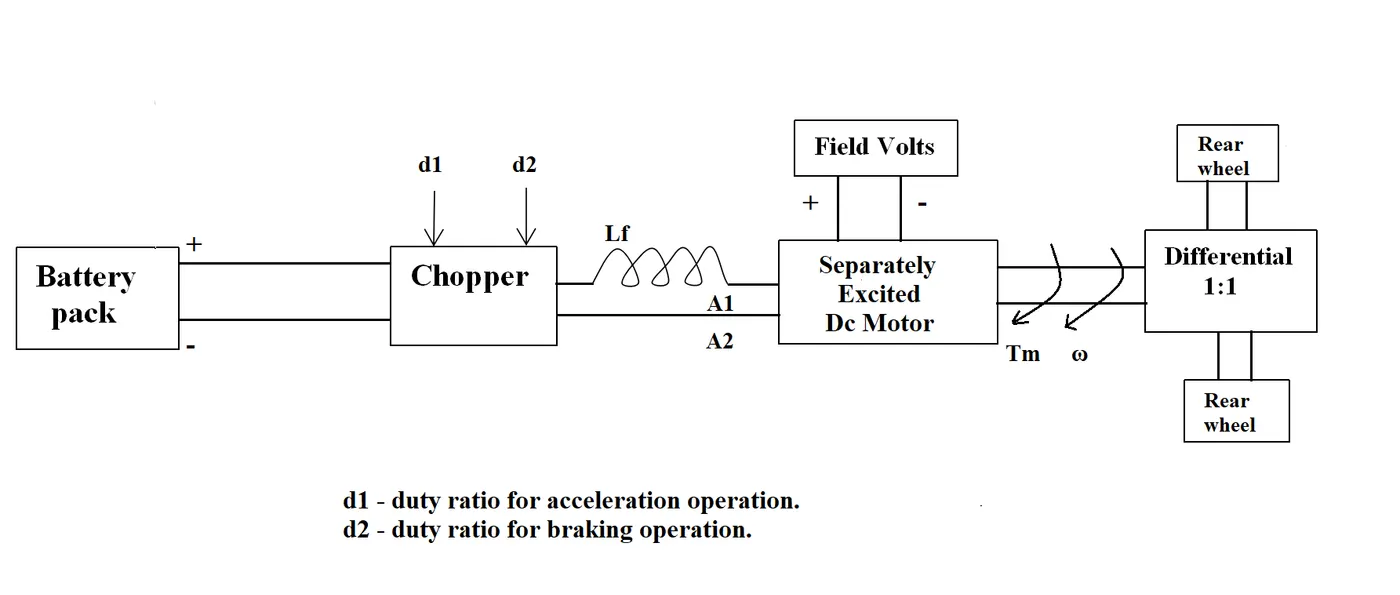
The other parameters of the electric vehicle is given below,
Motor and Controller Parameters:
Rated Armature voltage= 72 V
Rated armature current= 400 A
Ra= 0.5Ω, KΦ= 0.7 Volt second
Chopper Switching frequency= 400 Hz
The vehicle speed-torque characteristics are given by the below equation
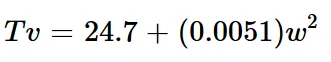
What is EV steady state speed if duty cycle is 70%?
Answer:- given, Rated Armature voltage= 72 V, Rated armature current= 400 A, Ra= 0.5Ω, KΦ= 0.7 Volt second, Chopper Switching frequency= 400 Hz, duty cycle =70%
vehicle output voltage(Vv)= battery voltage * duty cycle= 72* 70/100= 50.4
ω= steady state speed of vehicle (rps)
vehicle torque(Tv)= (Vv-ωKΦ)* KΦ/Ra= (50.4-ω*0.7)0.7/0.5= 70.56-0.98ω
, equating both eqn.
70.56-0.98ω= 24.7+ (0.0051)ω^2
(0.0051)ω^2 + 0.98ω-45.86=0
solving this equation we get ω1= 38.91 & ω2= -231.071
as ω2 is in negative, we will consider ω1, so steady state speed of vehicle is 38.91 rps
Question-3:- Develop a mathematical model of a DC Motor for the below equation using Simulink.
ω= V/Kϕ -Ra/Kϕ^2 .T
Solution:- block used in this model are- constant block, ramp block, product, divide, scope, square block
math model-
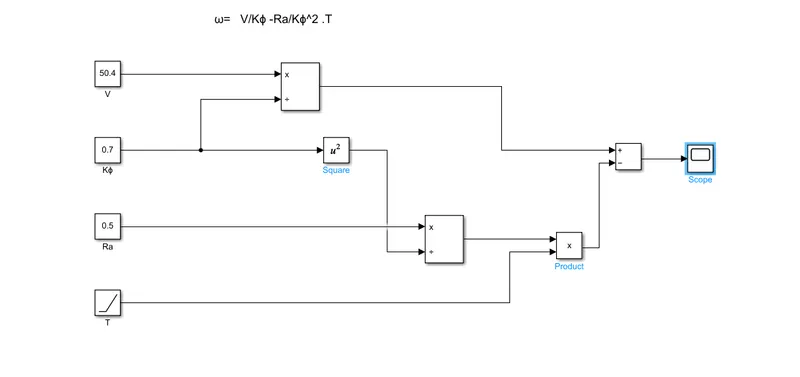
values of vehicle voltage(V), motor constant(Kϕ), armature resistance(Ra) are take from Question-2 data.
after making math model for eqn, ω= V/Kϕ -Ra/Kϕ^2 .T we have given run time 100sec, then run the model, we will get result as shown below.
result-
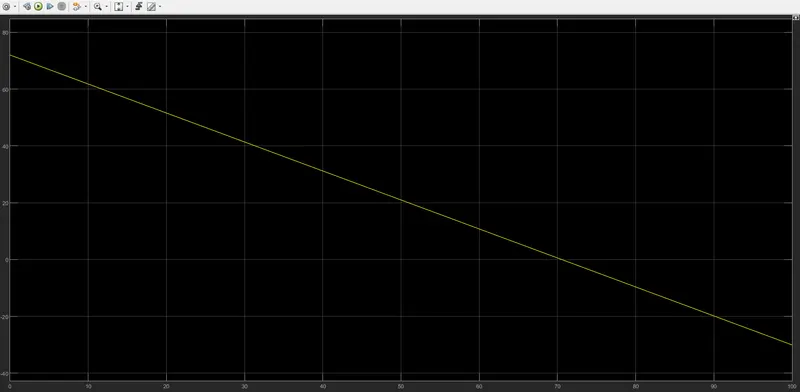
this is the speed torque characteristic of dc motor, it shows starting torque is about 71Nm, torque become zero when speed is 70.5
Link:- https://drive.google.com/file/d/1tK2XcuFA0xu91vJ1f9W9rZl5q9yXSdY-/view?usp=sharing
Question-4:- Refer to the blog on below topic:
Induction Versus DC brushless motors by Wally Rippel, Tesla
Explain in brief about author’s perspective.
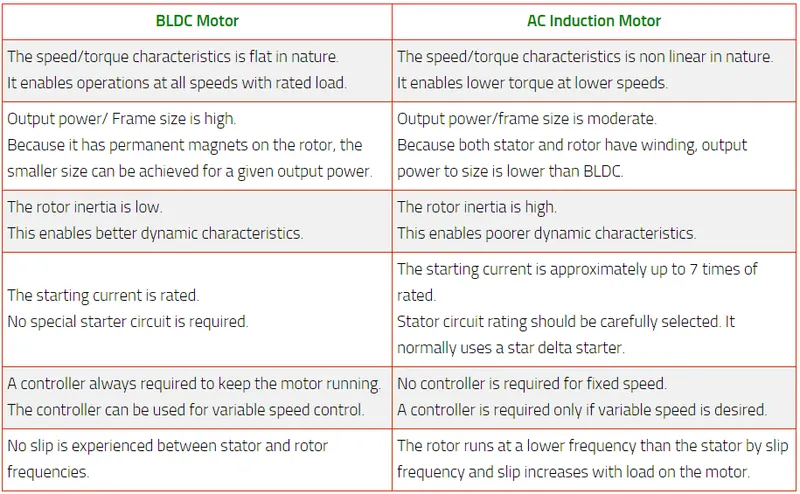
Answer:- Wally rippel first explain working of brushless DC motor & AC induction motor.
brushless DC motor, the rotor includes two or more permanent magnets that generate a DC magnetic field (as seen from the vantage point of the rotor). In turn, this magnetic field enters the stator core (a core made up of thin, stacked laminations) and interacts with currents flowing within the windings to produce a torque interaction between the rotor and stator. As the rotor rotates, it is necessary that the magnitude and polarity of the stator currents be continuously varied – and in just the right way - such that the torque remains constant and the conversion of electrical to mechanical energy is optimally efficient. The device that provides this current control is called an inverter. Without it, brushless motors are useless motors.
induction motors has stator winding, but its rotor does not have permanent magnets like DC motors, rotors conatain laminated steels stacks, its a self starting motor , doesnt require inverter for starting, In contrast, a brushless DC motor produces no starting torque when directly connected to fixed frequency utility power.they have limited starting torque and somewhat limited running peak torque capabilities, when compared to DC type machines.DC brushless drives require an absolute position sensor, while induction drives require only a speed sensor; these differences are relatively small.brushless drive, the strength of the magnetic field produced by the permanent magnets would be adjustable. When maximum torque is required, especially at low speeds, the magnetic field strength (B) should be maximum – so that inverter and motor currents are maintained at their lowest possible values. This minimizes the I² R (current² resistance) losses and thereby optimizes efficiency. Likewise, when torque levels are low, the B field should be reduced such that eddy and hysteresis losses due to B are also reduced. Ideally, B should be adjusted such that the sum of the eddy, hysteresis, and I² losses is minimized. Unfortunately, there is no easy way of changing B with permanent magnets.In contrast, induction machines have no magnets and B fields are “adjustable,” since B is proportionate to V/f (voltage to frequency).With DC brushless, as machine size grows, the magnetic losses increase proportionately and part load efficiency drops. With induction, as machine size grows, losses do not necessarily grow.
His conclusion is that DC brushless drives will likely continue to dominate in the hybrid and coming plug-in hybrid markets, and that induction drives will likely maintain dominance for the high-performance pure electrics. the hardware is common for both drives could mean that we will see induction and DC brushless live and work side by side during the coming golden era of hybrid and electric vehicles.