Week-4 Challenge WOT Condition Part-2
Aim 1) What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
Ans -
Mapped engines represent macro engine behaviour as a set of lookup tables (brake torque, fuel flow, air mass flow, exhaust temperature, efficiency, and emissions) as functions of commanded load and measured engine speed.
Mapped Model can be simply referred to a Static System.
Dynamic engines decompose engine behaviour into individual component models that account for engine dynamics, most notably intake airflow and turbocharger dynamics.
One can switch between engine model types based on application.
Dynamic engine models are suitable for designing control, estimator, and diagnostic algorithms that depend on dynamic subsystem states, for example, in closed-loop AFR control algorithm development.
Mapped engine models are suitable for analysis and design activities that do not require engine subsystem dynamic characteristics, for example, in engine and transmission powertrain matching analysis for fuel economy, emissions, and performance trade-offs.
This Principle also remains same for Motor/Generator
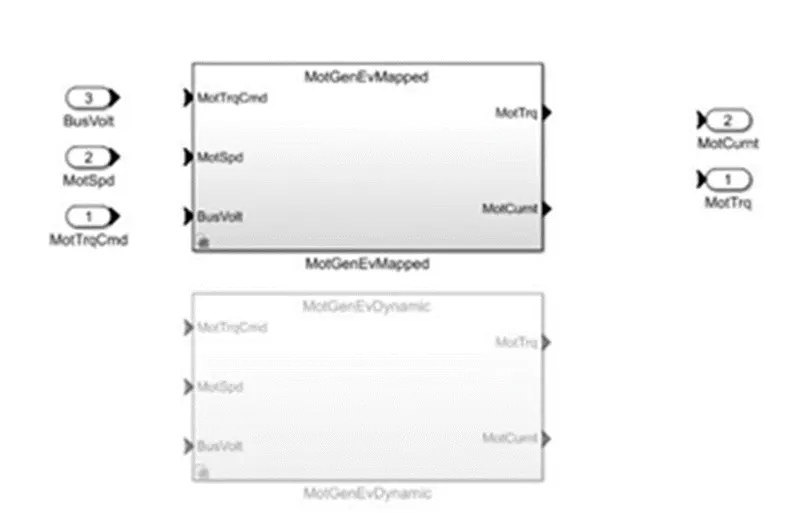
Mapped Model:
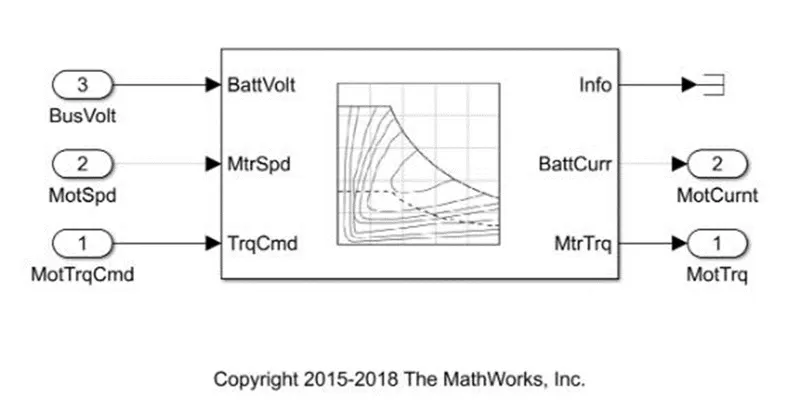
- The Mapped Model consists of Data Points which are assigned accordingly in Look-up table.
- This refers to kind of a Static Simulation which takes very less time and the accuracy of the results are not that Good.
- Mapped Model can be considered as Macro Level Solver, and does not evaluate for the real time scenarios.
Dynamic Model:
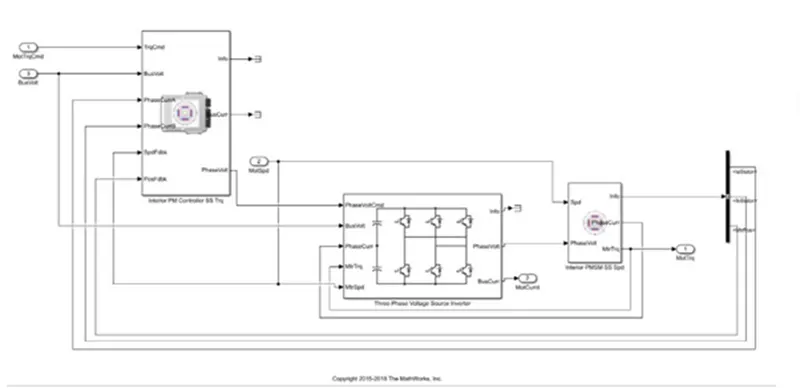
- Dynamic Model can be considered as Micro Level Solver which always evaluates for the Outputs from various Subsystem and combines together to form a dynamic effect.
- Considers Real Time Scenarios.
- Simulation checks for the Reference Inputs as well as the Feedback from the Output so as to balance between the Demand and Supply of Power/Torque.
- The accuracy of this Model is considered to be Good.
To Change b/w Mapped & Dynamic Model
- Open the Power Train Blockset Module for the desired type of Vehicle Model.
- Click on the Vehicle Block.
- Then Select the Electric Plant or Engine
- Click on EV Motor/Generator/Engine based on the Vehicle Model selected.
- Right Click on the Default Block available and then select Variant Manager.
- Now click on Override Variant and select the Model desired.
Aim 2) How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
Ans -
Miles per Gallon is a fuel economy rating determined by how far a car can travel on a gallon of Gasoline or Diesel for an Engine powered car.
In case of electric vehicles, this can be defined as the amount of distance travelled by the Engine powered car in a gallon of fuel and compared with the electric energy required by the Electric vehicle to travel the same distance i.e. the Equivalent Energy required to Propel the Car through same Distance.
The Powertrain Blocksets has the Built in Model for this,
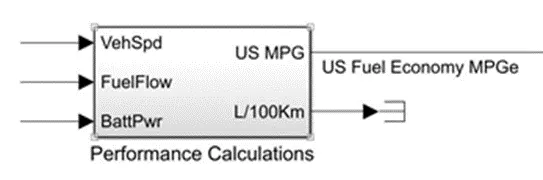
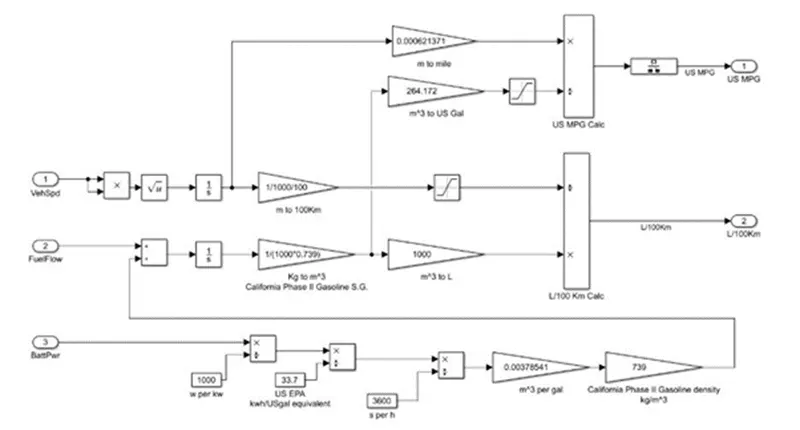
According to the Model, following 3 factors are involved in calculating the Fuel Economy rating
- Vehicle Speed
- Fuel Flow
- Battery Power
- Vehicle Speed is a critical criterion in evaluating the Fuel consumption/Fuel flow.
- Vehicle Speed is integrated with respect to time to obtain Distance Travelled later which is converted to Km Units. Saturation Block is used to bound Upper & Lower limits to the obtained value
- Total Battery Power required to Propel the vehicle is simulated along way, Battery Power is converted to “Kw” and Battery Rating is obtained in terms of “Kwh”. Several Gains Blocks with some constant Values are used to get the Mass flow rate of the fuel in (Kg/m^3).
- The above value is fed back as input in the Fuel flow block, using these values along with the Gain Blocks Fuel Consumption in “Litres” is Calculated
- By the Results obtained from Vehicle speed & Fuel Flow, the total amount of fuel to run Vehicle for 100 Km is obtained (L/100Km).
- To evaluate for MPG,
- Consider the Fuel Flow Value in m^3, and convert it into US Gal by multiplying with 264.172 in Gain Block and saturate the Limits.
- Simultaneously Consider the Distance travelled in Metre and convert to Miles using Gain Block.
- Now from above 2 values Miles per Gallon can be obtained.
Aim 3) Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
Ans -
The reference HEV Powertrain Blockset is extracted from MathWorks,
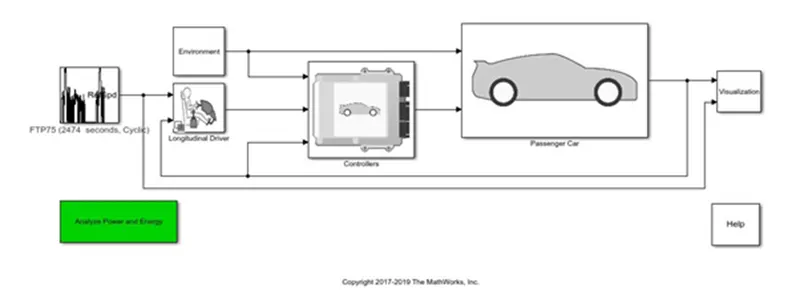
- Drive Cycle Sourceblock: Generates a standard or user-specified drive cycle velocity versus time profile. In this Simulation we are evaluating for WOT.
- Environmentsubsystem: Creates environment variables, including road grade, wind velocity, and atmospheric temperature and pressure.
- Longitudinal Driversubsystem: Uses the Longitudinal Driver or Open Loop variant to generate normalized acceleration and braking commands.
- Longitudinal Drivervariant implements a driver model that uses vehicle target and reference velocities.
- Open Loop variant allows you to configure the acceleration, deceleration, gear, and clutch commands with constant or signal-based inputs.
- Controllerssubsystem: Implements a powertrain control module (PCM) containing an input power-split hybrid control module (HCM) and an engine control module (ECM).
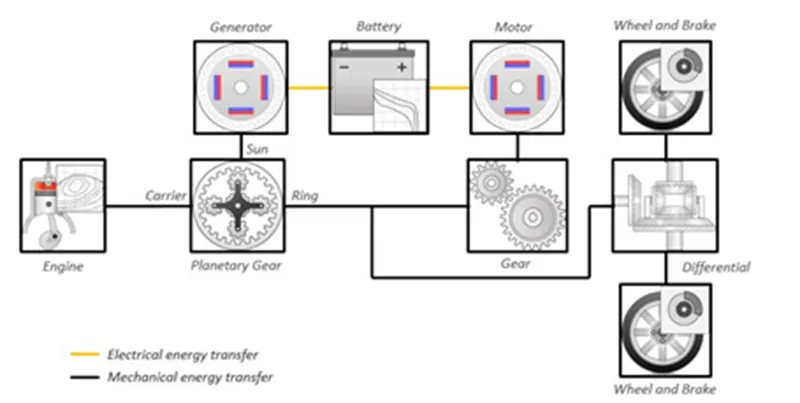
- Passenger Carsubsystem: Implements a hybrid passenger car that contains drivetrain, electric plant, and engine subsystems.
- Visualizationsubsystem: Displays vehicle-level performance, battery state of charge (SOC), fuel economy, and emission results that are useful for powertrain matching and component selection analysis.
Simulation for WOT_1
- Grade Angle = 0 Degrees
- Wind Velocity = 0 m/s
- Total Simulation Time =100s
- Nominal Speed = 50m/s (WOT Max Speed=180Kmph=112Mph)
- Time @ Deceleration = 50s
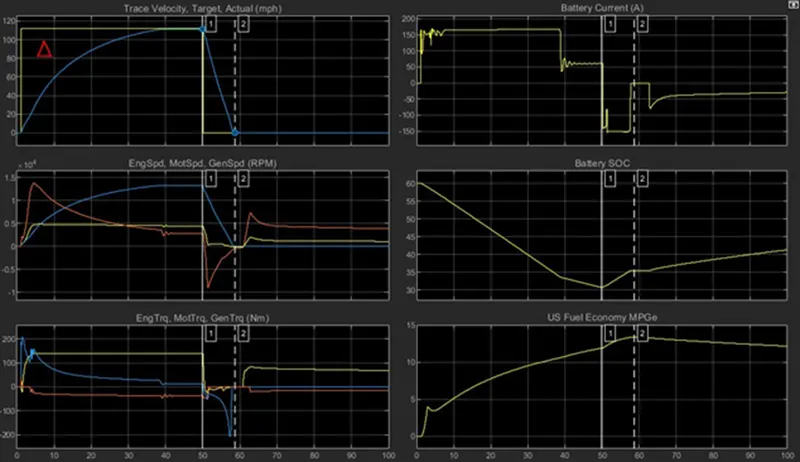
Trace Velocity: A Shift/Delta exists between Actual & Target WOT condition. This is due to the Limitation on the Maximum Power availability from Energy Sources @ that instant.
- Max Velocity is attained at t=40s
- Deceleration Time to 0Mph = 8.765s
Speed (RPM): Displays the Speed of the Engine, Motor & Generator throughout the Simulation. This can be used to determine the Peak Speed and to corelate between the Engine and Generator RPM.
Torque (Nm): A useful Torque Characteristics Curve. To achieve the Top Speed (WOT),
- Max Engine Torque = 140Nm
- Peak Motor Torque = 200 Nm (Instantaneous during Start)
Battery Current (A):
- Max Current Drawn from Battery to achieve WOT = 168A
- Current Drawn after attaining Max Speed = 63A
- Current during Deceleration = -141A (Indicates Charging)
Battery SOC (%):
- The SOC of Battery Decreased from initial 60% to 33.5% Rapidly in Linear Fashion until Vehicle reaches Max Speed.
- The rate of SOC reduction reduced once the Vehicle attained the constant speed and SOC depleted slowly to 30%.
- During Deceleration, Battery SOC has increased to 36% which constitutes Regenerative Braking.
US Fuel Economy (MPG): Indicated Maximum Distance (Miles), Vehicle can run per Gallon of Fuel @ that Speed.
- @ 112MPH = 13.5MPG
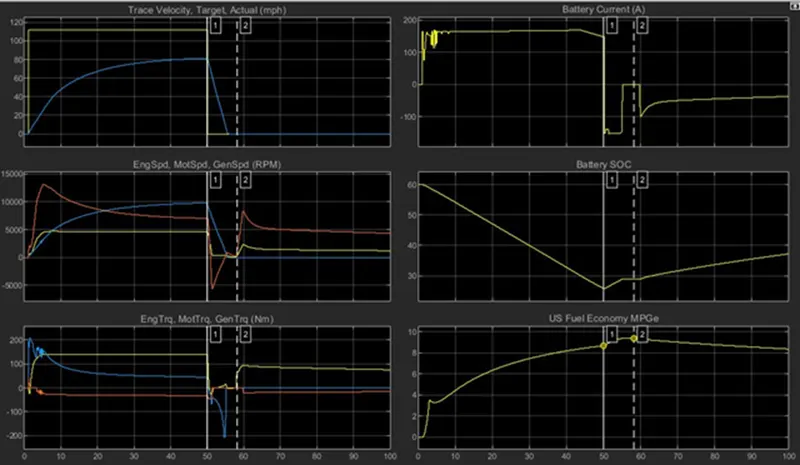
Simulation for WOT_2 (HEV)
- Grade Angle = 5 Degrees
- Wind Velocity = 10 m/s
- Total Simulation Time =100s
- Nominal Speed = 50m/s (WOT Max Speed=180Kmph=112Mph)
- Time @ Deceleration = 50s
Result Comparison
|
Simulation_1 |
Simulation_2 |
|
|
Grade (Deg) |
0 |
5 |
|
Wind Velocity (m/s) |
0 |
10 |
|
Maximum Speed (Mph) |
112 |
86.5 |
|
Deceleration Time (s) |
8.765 |
5.45 |
|
Max Engine Torque (Nm) |
140 |
140 |
|
Peak Motor Torque (Nm) |
200 |
200 |
|
Max Battery Current Drawn (A) |
168 |
168 |
|
Battery SOC |
60% to 30% |
60% to 25% |
|
Fuel Economy (MPG) |
13.5 |
9.2 |
Conclusion:
- There exists a difference between actual Velocity Curve and the Input Curve due to the limitation on maximum Power available from Propulsion/Energy sources.
- Limiting factors involves Current or the Battery Module.
- The Maximum Speed achieved in Simulation_2 is lesser compared with Simulation_1 because of the presence of Grade Angle and Opposing Wind Force.
- It can be observed from the Plots, With increase in Grade Angle,
- WOT Response Time increases.
- Velocity Decreases
- The Battery SOC also decreases considerably with increase in the Traction Forces.
- Fuel Economy falls to greater extent with increase in the Demanding Traction Power.
Aim 4) Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
Ans -
HEV
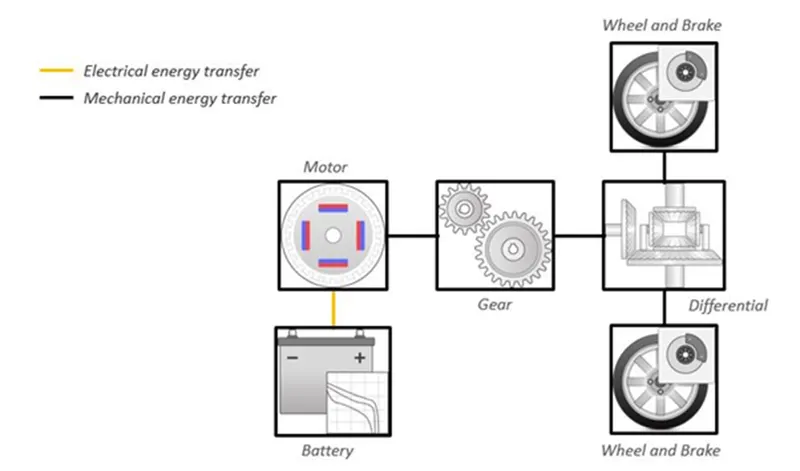
EV
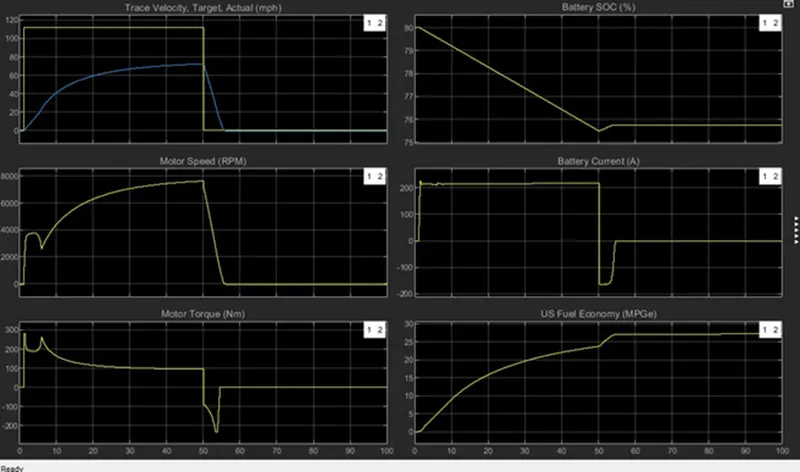
Simulation for WOT_3 (EV)
- Grade Angle = 5 Degrees
- Wind Velocity = 10 m/s
- Total Simulation Time =100s
- Nominal Speed = 50m/s (WOT Max Speed=180Kmph=112Mph)
- Time @ Deceleration = 50s
|
HEV |
EV |
|
|
Grade (Deg) |
5 |
5 |
|
Wind Velocity (m/s) |
10 |
10 |
|
Maximum Speed (Mph) |
86.5 |
72 |
|
Deceleration Time (s) |
5.45 |
5.8 |
|
Max Engine Torque (Nm) |
140 |
- |
|
Peak Motor Torque (Nm) |
200 |
280 |
|
Max Battery Current Drawn (A) |
168 |
217 |
|
Battery SOC |
60% to 25% |
80% to 75.5% |
|
Fuel Economy (MPG) |
9.2 |
27 |
Conclusion:
- The Pure EV drive achieves less Top Speed Compared with HEV.
- Motor used in EV must be of more Capacity than the one used in HEV.
- EV derives all power from Motor alone and hence Torque developed by EV motor is greater, Whereas in HEV Combined Torque from Motor and Engine Propels the System.
- The conventional HEV uses Lead Acid Battery whereas EV uses Lithium ion Battery which is more Potential.
- Instantaneous Torque at the start is more in EV compared with HEV or conventional Vehicles.