Week-4 Challenge WOT Condition Part-2
Q 1. What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
solution :-
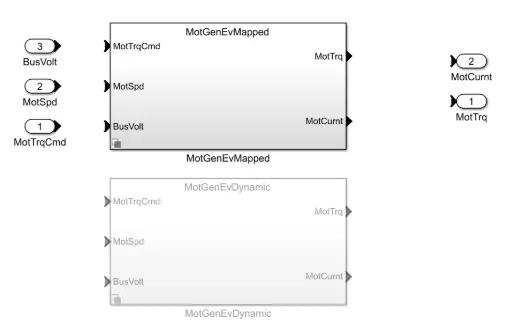
- Mapped and Dynamic subsystem of Electric Motor/Generator
1) Mapped Model:
- One form of model where the data points have already been assigned in lookup tables is the mapped model.
- The required engine or motor torque is detected, and the motor or engine block produces the needed torque output exactly as needed without taking into account the real-time motor or engine parameters.
- The output values are saved for the corresponding provided engine motor and generator input values.
- Although the level of realism is not very great, the simulation will be completed much more quickly because it is not powered by real time parameters.
2) Dyanamic Model:
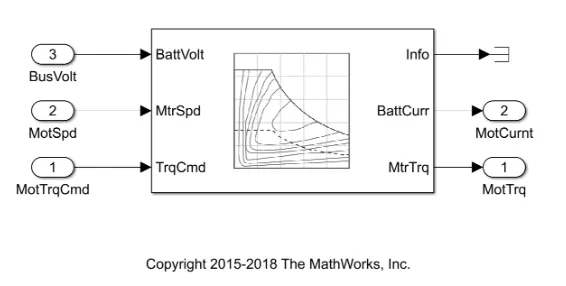
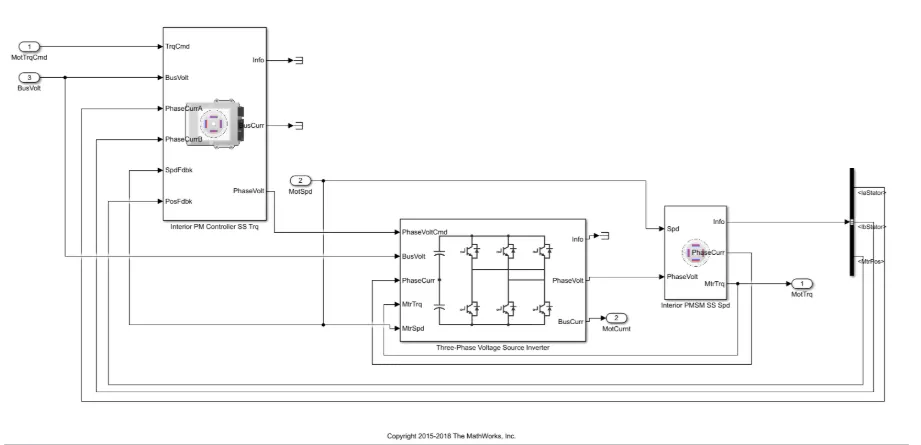
*On the other hand, the dynamic model produces its output by combining the outputs from numerous subsystems.
* It operates through real-time simulation, where the necessary input from the drive cycle is received, for which a separate real-time simulation is carried out, and for which the output for the simulation is obtained by adding together all the results of the subsystem.
* The initial Bus voltage, current, and vehicle feedback are provided in accordance with the drive cycle requirements so that the simulation is executed at that specific point during the drive cycle.
* Because it takes into account the actual outputs from every subsystem while generating the output, this model has a very high level of accuracy.
* Due to the simulation's length, it will take a very long time to finish.
3) Steps to select the Model Type:
i.We must first choose the type of car in the powertrain blockset module, whether it is a hybrid, completely electric, or full engine vehicle.
ii. Following that, the Simulink model is displayed together with its work flow blocks.
iii. We must travel to the EV Motor/Generator Block at the Passenger Block Electric Plant.
iv.
After that, simply select Variance Label mode with a right-click. MotorGenEV Mapped or Dynamic is an active option.
Q 2) . How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
solution :-
i ) Miles per gallon
-
Miles per Gallon is a fuel efficiency rating based on how far an engine-powered car can go on a gallon of gasoline or diesel.
-
In the case of an electric vehicle, it informs us of the amount of energy required to move the vehicle over a given distance in comparison to an engine-powered vehicle.
-
In order to calculate the miles per gallon, the quantity of fuel energy needed to move an engine-powered vehicle over a given distance is first calculated. This amount is then contrasted with the equivalent amount of electric energy needed to move the vehicle over the same distance.
-
A model that determines the miles per gallon for all types of vehicles is part of the powertrain blockset.
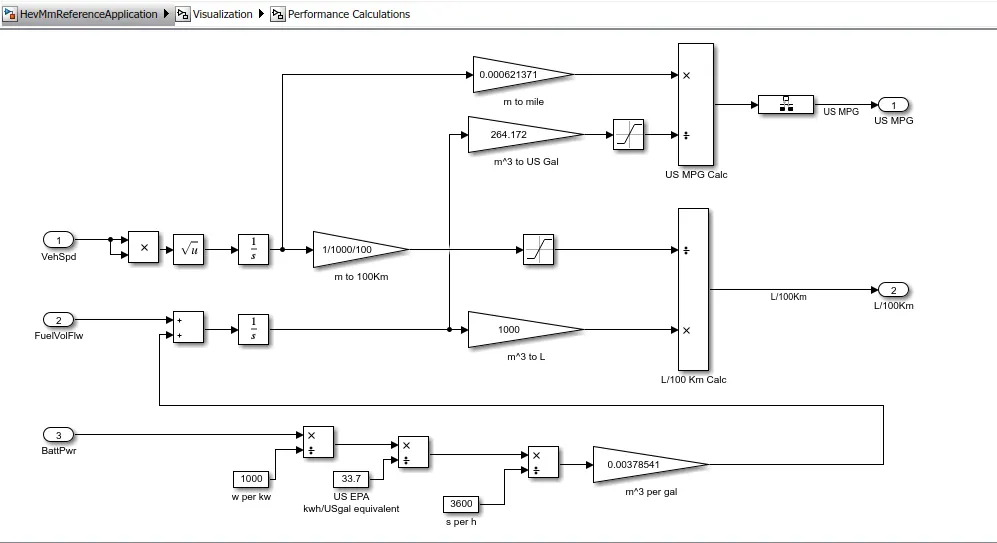
- The above model takes the input of the Vehicle speed , Fuel flow and Battery power to calculate the fuel consumption and the equivalent battery consumption and calculates the miles per gallon.
ii ) Vehicle Speed And Fuel Flow:
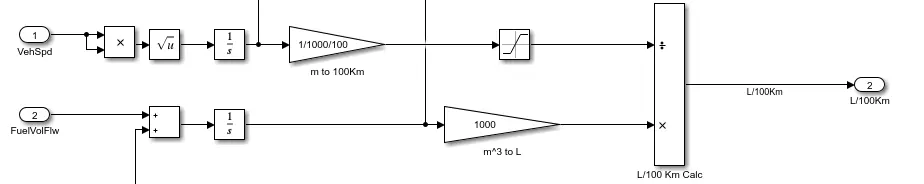
-
In order to calculate the fuel consumption during the course of the drive cycle, it is crucial to take the vehicle's speed into account.
-
We can integrate over time to translate speed to distance, which is equivalent to converting velocity to distance travelled.
-
The fuel flow is then quantified in kilogrammes per second (Kg/Sec), which is the mass flow rate. Now that this has been integrated, the fuel's mass is obtained. Using this one, we convert the fuel's mass to volume, which we then multiply by 1000 to obtain in litres.
-
We can determine how many litres are needed to run 100 kilometres by comparing the two results.
iii ) Battery Power:
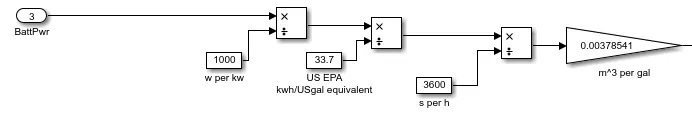
-
Here, the amount of battery energy needed to propel the vehicle at an engine-equivalent speed is computed.When supplied in watts, the battery power is converted to Kw by dividing by 1000.
-
The power is then multiplied by time to create KWh, which is then converted into energy.
-
After that, we divide the energy in kWh by 33.7 to get the equivalent energy in a US gallon of gasoline for cars. Since the energy in US Gallons and KWh are identical, we are attempting to calculate the energy in equivalent LIS Gallons per second. To do this, we divide the result by 3600 and change the hour into seconds.
-
Next, we multiply the US gallons per second by 0.00378541 to get the volume of fuel flowing in (mA3/s), and then by 739 (the California Phase I gasoline density), giving us the mass flow rate in kilogrammes.
-
Finally, the fuel flow parameter is given the battery energy equivalent in kg/s in order to calculate the equivalent US gallons of energy and get the miles per gallon.
iv ) Calculating Miles Per Gallon :
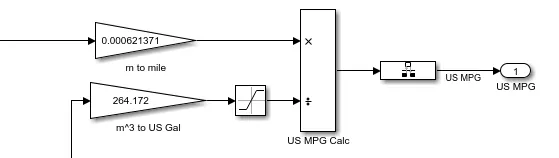
-
The distance we determined (in metres) is then added to the formula as an input along with the vehicle speed, and it is translated to miles by multiplying by 0.000621371.
-
The inputs from the fuel flow (Battery energy + Fuel energy) are then multiplied by 264.172 to convert them into equivalent US gallons.
-
The value is obtained in miles per gallon after further dividing the two inputs, miles travelled and an equivalent US gallon.
Q 3) . Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
solution :-
i ) Hybrid Electric Vehicle:
- A hybrid electric vehicle (HEV) is a type of hybrid type that combines a conventional Internal combustion engine (ICE) system with an electric propulsion system
- The presence of the electric powertrain is intended to achieve either better fuel economy than a conventional vehicle or better performance.
- Example of HEV is Toyota Prius.
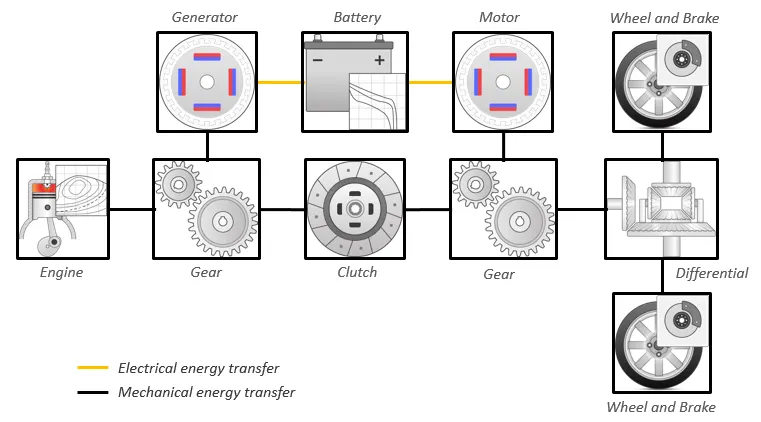
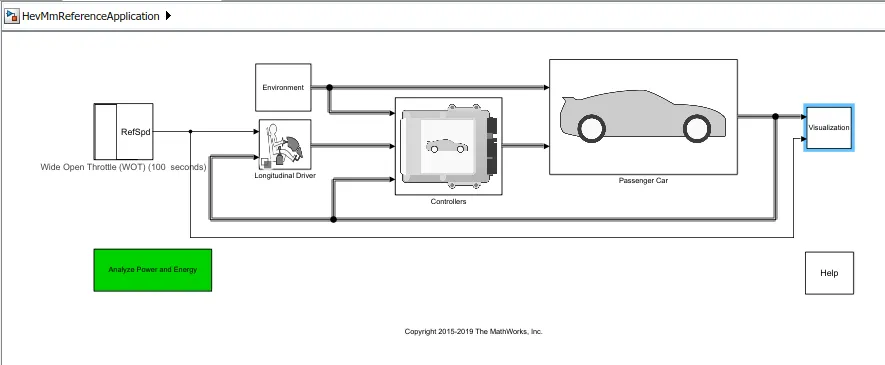
- In the powertrain blockset we have selected the hybrid electric vehicle and this is the simulink model .
- Here we can select the input parameters as we wish and we can Run the simulation to check the results.
Case1
i ) Simulation condition:
The simulation is done for Hybrid electric vehicle with Wide open Throttle Drive cycle.The Total cycle time = 100 seconds
The Top speed of this cycle = 80 mph
Time to start deceleration = 50seconds
The Grade angle = 0 degrees
The wind velocity = 0 m/s
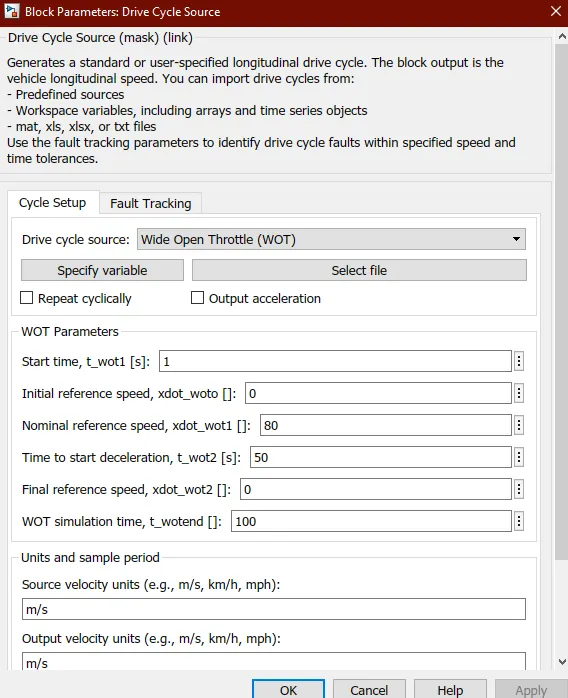
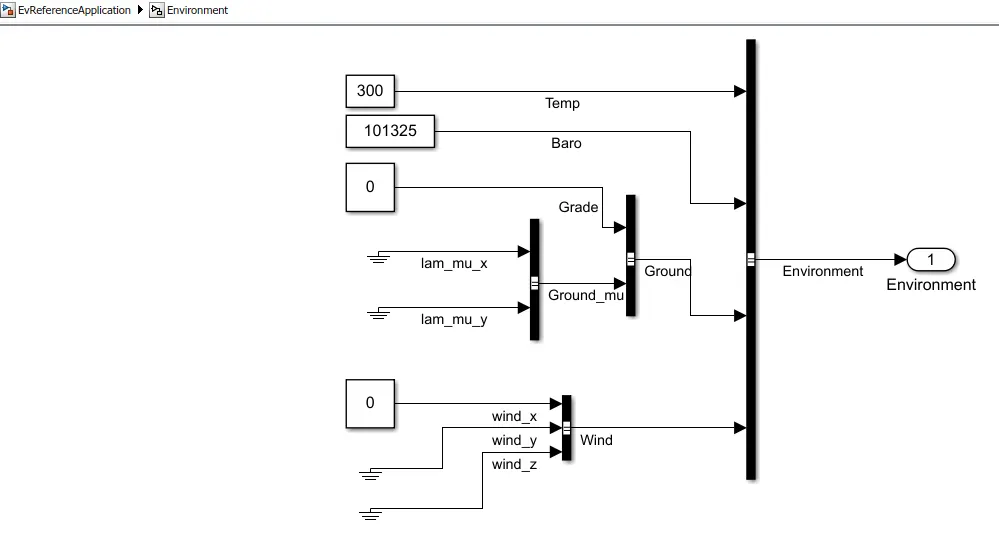
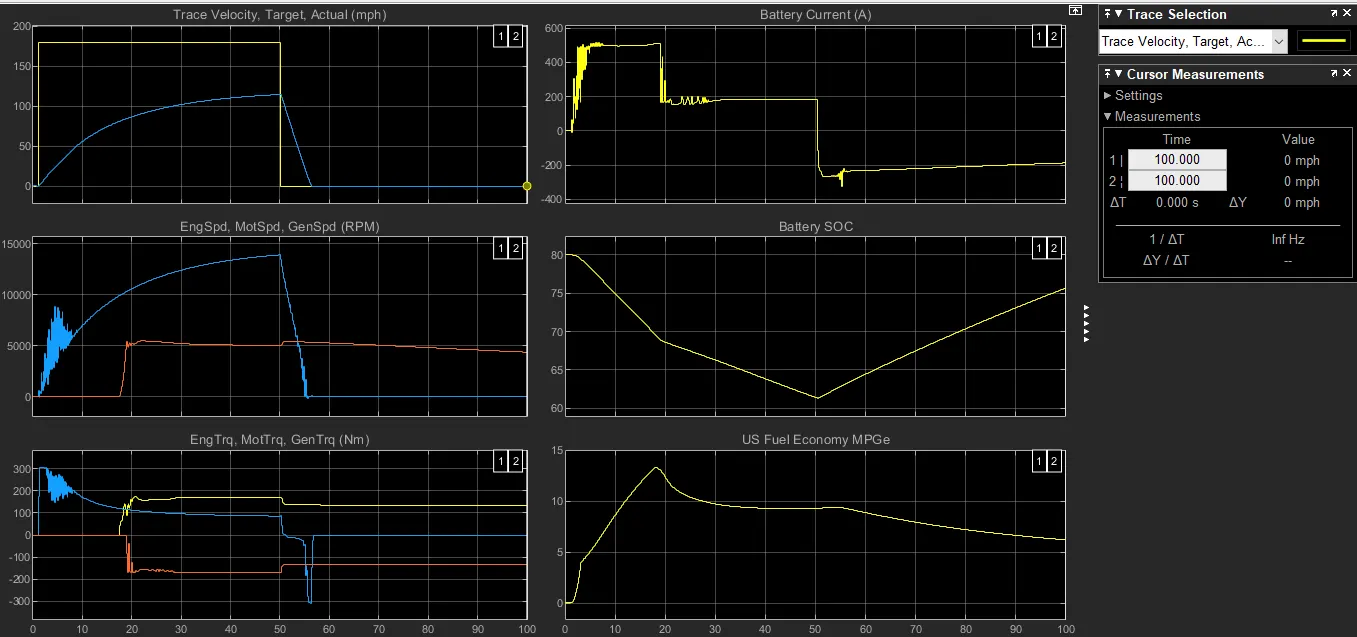
-
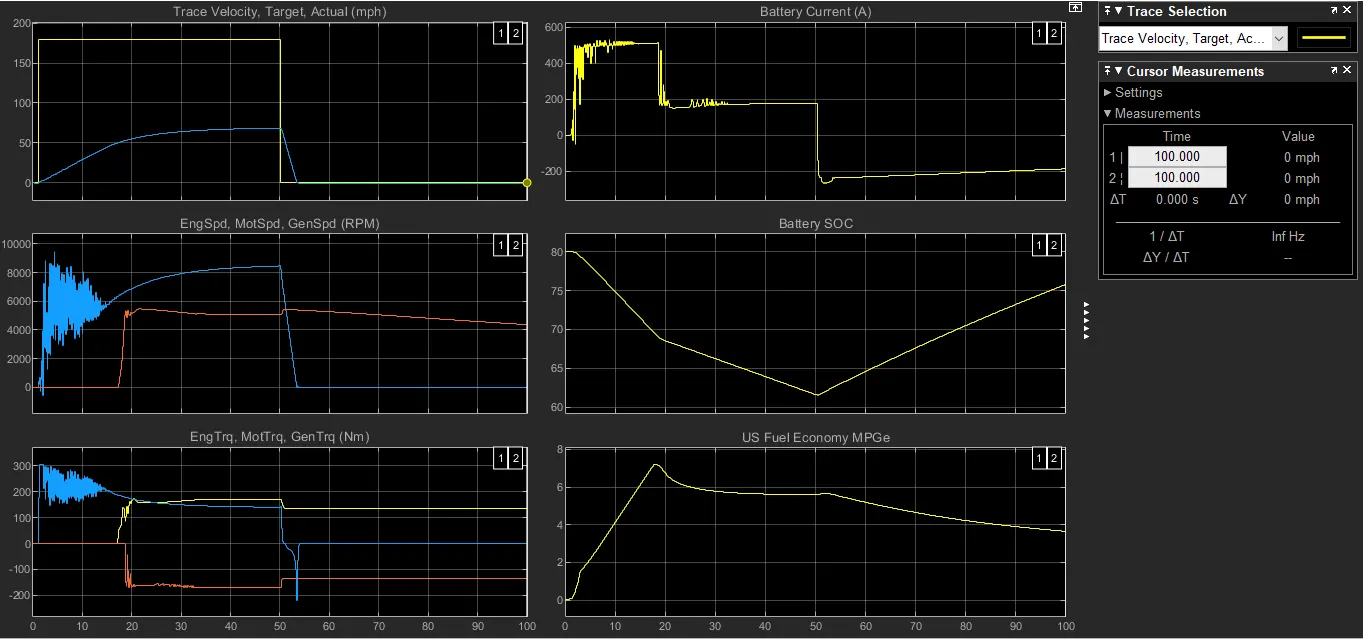
There are a total of six plots in the picture above that displays the simulation's results.
-
There is a cursor measurement on each plot, and if we move the cursor on one plot, the cursor moves on the other plots as well, allowing us to explore the results more thoroughly. Each plot displays a specific result.
-
The cursor allows us to observe how other result parameters behave in relation to the vehicle's acceleration.
ii )plot 1:
Shows the velocity of the vehicle with respect to the Drive cycle data with the Time scale on the x axis.
The acceleration time to reach 80 mph - 16.7 seconds
The deceleration time from 80 to minimum = 6.2 seconds
iii ) plot 2:
Shows the changes in speed of the Engine,motor and Generator in Rpm throughout the drive cycle.
Peak Engine speed = 4780 Rpm
Peak Motor speed = 9497 Rpm
Peak Generator speed = 13690 Rpm
iii ) plot 3:
Shows the Torque characteristics and its changes of engine,motor and generator in (Nm) throughout the drive cycle.
Peak Engine torque = 138.7 Nm
Peak Motor torque = 206.7 Nm
Peak Generator torque = 42.2 Nm
iv) plot 4:
Shows the Battery Current values (A) and its changes for various acceleration inputs as per the Drive cycle.
The peak current discharge from the battery = 163.5A
The peak current charging to the battery = -150.86 A
v) Plot 5:
Shows the Battery state of charge SOC (%) and its changes corresponding to the driving inputs.
The state of charge decreased from 60% to 39.8% of charge in a time period of 49.3 seconds , for the specified driving conditions.
vi) Plot 6:
Shows the Fuel Economy as Mile per Gallons for the corresponding input driving conditions.
The maximum miles that the car can run per gallon of fuel equivalent = 46 Miles,for the given vehicle at the specified driving conditions.
Case2
i) Simulation Condition:
The simulation is done for Hybrid electric vehicle with Wide open Throttle Drive cycle.
The Total cycle time = 100 seconds
The Top speed of this cycle = 80 mph
Time to start deceleration = 50seconds
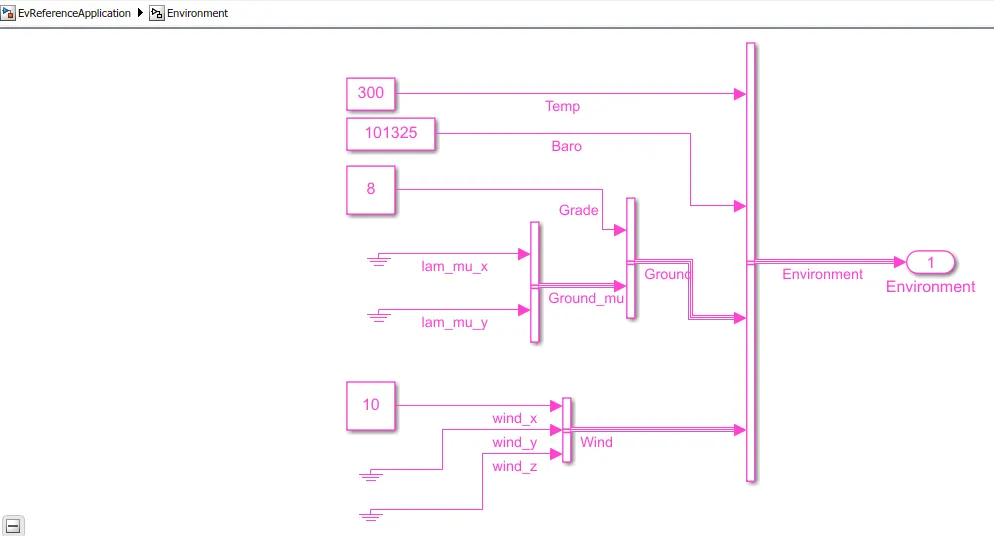
The Grade angle - 8 Degrees
The wind velocity = 10 m/s.
-
We can see some differences from the prior scenario in all of the data.
-
Even though the drive cycle and vehicle parameters are the same, we have included certain hill climb angles and wind velocity to account for some changes in the environment blocks.
-
Below is a list of the results' modifications.
ii )plot 1:
Shows the velocity of the vehicle with respect to the Drive cycle data with the Time scale on the x axis.
The top speed of 80 mph cannot be achieved as we have some additional forces acting and so the car can only run upto 67.2 mph
The acceleration time to reach top speed of 67.2 mph = 44.5 seconds
The deceleration time from 80 to minimum = 5.06 seconds
iii ) plot 2:
Shows the changes in speed of the Engine,motor and Generator in Rpm throughout the drive cycle.
Peak Engine speed = 4676 Rpm
Peak Motor speed = 8103.5 Rpm
Peak Generator speed = 12858.5 Rpm
iii) plot 3:
Shows the Torque characteristics and its changes of engine,motor and generator in (Nm) throughout the drive cycle.
Peak Engine torque = 139.6 Nm ; Peak Motor torque = 206.4 Nm
Peak Generator torque = 48.2 Nm
iv) plot 4:
Shows the Battery Current values (A) and its changes for various acceleration inputs as per the Drive cycle.
The peak current discharge from the battery = 167.6A
The peak current charging to the battery = -152.46 A
v )Plot 5:
Shows the Battery state of charge SOC (%) and its changes corresponding to the driving inputs.
The state of charge decreased from 60% to 25.98 % of charge in a time period of 49.3 seconds , for the specified driving conditions.
vi) Plot 6:
Shows the Fuel Economy as Mile per Gallons for the corresponding input driving conditions.
The maximum miles that the car can run per gallon of fuel equivalent = 17.93 Miles,for the given vehicle at the specified driving conditions.
Observation:
- The simulation results for both the cases is found and we can see that the simulation 1 without the inclusion of hill climbing conditions and the wind drag velocity is much more efficient when compared to the simulation which includes the hill climbing conditions and the wind drag velocity.
- The vehicle was not able to achieve the required top speed though using the highest possible current discharge of that same battery used before.
- The state of charge also shows that the discharge is also high compared to the simulation 1
- The Fuel Economy is also down to half of the previous simulation.
- So one can say, it is evident that the efficiency of no load vehicle is high compared to the vehicle with additional loads acting on them and also we have visualized this using the Powertrain blockset.
Q 4 ) . Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
solution :-
i )Pure Electric Vehicle:
-
A battery electric vehicle, also known as a pure electric vehicle, is an electric vehicle (EV) that solely relies on chemical energy stored in rechargeable battery packs and does not employ any other propulsion sources, such as internal combustion engines or hydrogen fuel cells.
-
BEVs don't use conventional internal combustion engines for propulsion; instead, they employ electric motors and motor controllers. All of their energy comes from battery packs.
-
So they are environmentally friendly and don't emit any waste gas.
-
Additionally, they have their own restrictions, such as range, etc.
Nissan Leaf is a prime example of a pure EV.
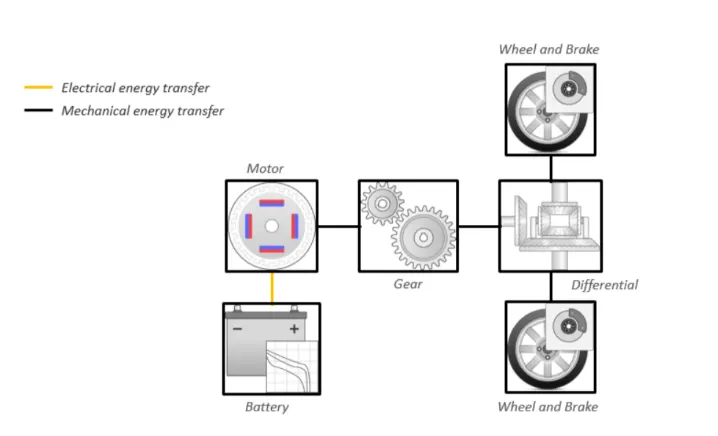
- Now comparing both the Pure electric and Hybrid electric vehicle with the given conditions in a simulation to observe the behaviour of both the type.
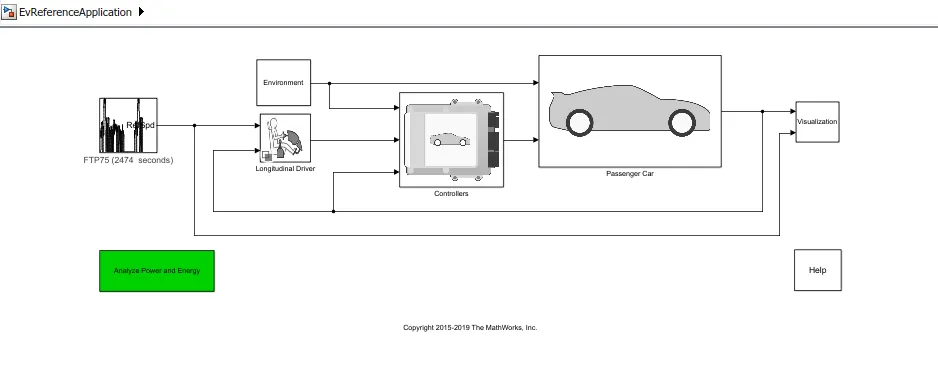
Case1
i) Simulation Condition:
The simulation is done for pure electric & Hybrid electric vehicle with Wide open Throttle (WOT) Drive cycle.
The Total cycle time = 100 seconds
The Top speed of this cycle = 80 mph
Time to start deceleration = 50 seconds
The Grade angle = 0 Degrees
The wind velocity = 0 m/s.
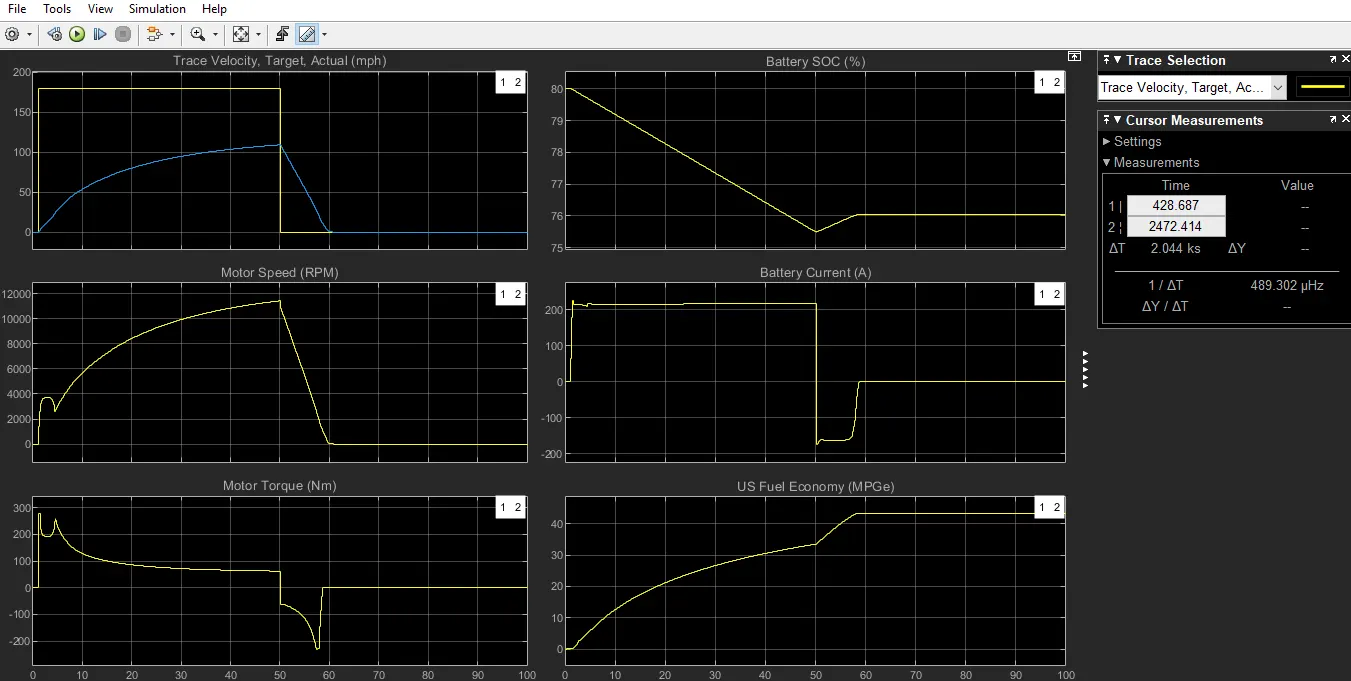
ii) plot 1:
Shows the velocity of the vehicle with respect to the Drive cycle data with the Time scale on the x axis.
The top speed of 80 mph cannot be achieved as we have some additional forces acting and so the car can only run upto 108.9mph
The acceleration time to reach top speed of 108.9 mph = 50.2 seconds
The deceleration time from 80 to minimum = 9.8 seconds
iii) plot 2:
Shows the changes in speed of the Motor in Rpm throughout the drive cycle.
Peak Motor speed = 1123 Rpm
iv) plot 3:
Shows the Torque characteristics and its changes of Motor in (Nm) throughout the drive cycle.
Peak Motor torque = 260 Nm
v)plot 4:
Shows the Battery Current values (A) and its changes for various acceleration inputs as per the Drive cycle.
The peak current discharge from the battery = 216.8 A
The peak current charging to the battery = -173.7 A
vi) Plot 5:
Shows the Battery state of charge SOC (%) and its changes corresponding to the driving inputs.
The state of charge decreased from 80% to 75.5% of charge in a time period of 50.3 seconds , for the specified driving conditions.
vii) Plot 6:
Shows the Equivalent Fuel Economy as Mile per Gallons for the corresponding input driving conditions.Here there is no fuel in pure electric vehicle however this gives equivalent battery energy required that of the fuel energy,and calculates the Fuel efficiency.The maximum miles that the car can run per gallon of fuel equivalent = 20.45 Miles,for the given vehicle at the specified driving conditions.
Case2
i)Simulation Condition:
The simulation is done for pure electric & Hybrid electric vehicle with Wide open Throttle (WOT) Drive cycle.
The Total cycle time = 100 seconds
The Top speed of this cycle = 80 mph
Time to start deceleration = 50 seconds
The Grade angle = 8 Degrees
The wind velocity = 10 m/s.
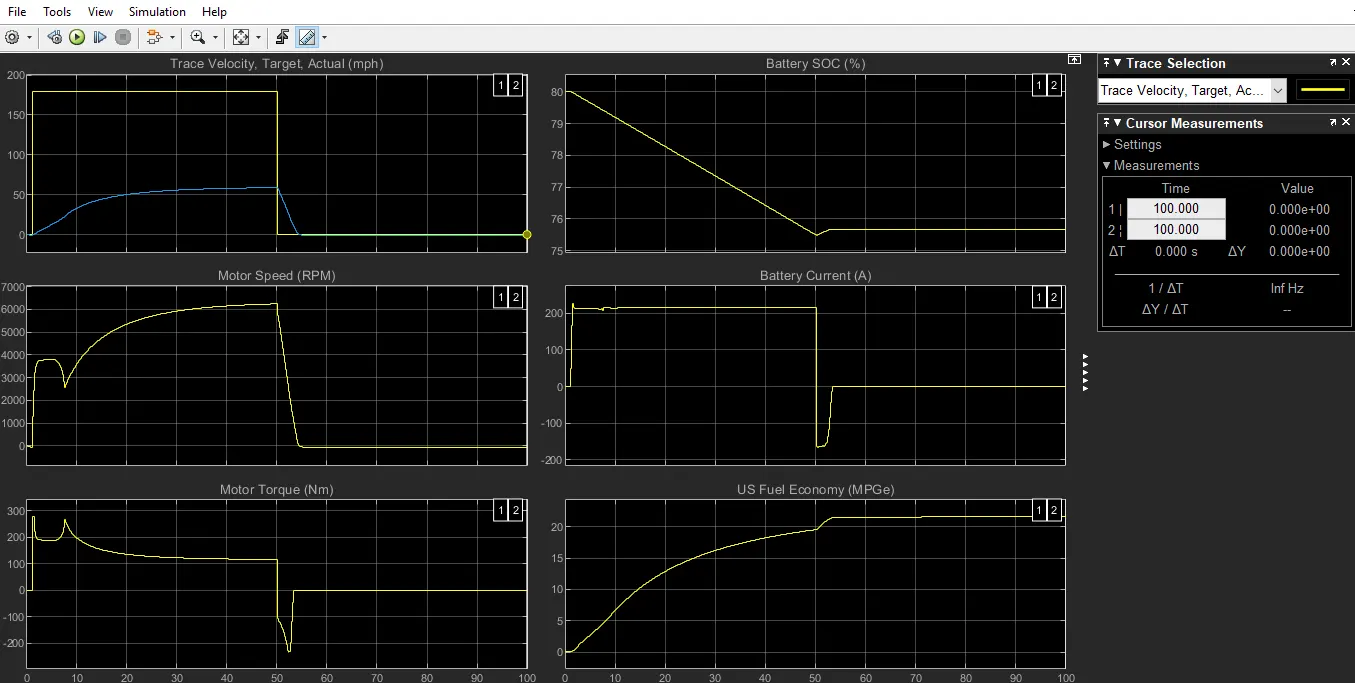
ii)plot 1:
Shows the velocity of the vehicle with respect to the Drive cycle data with the Time scale on the x axis.
The top speed of 80 mph cannot be achieved as we have some additional forces acting and so the car can only run upto 58.9mph
The acceleration time to reach top speed of 58.9 mph = 48.8 seconds
The deceleration time from 80 to minimum = 4.63 seconds
iii) plot 2:
Shows the changes in speed of the Motor in Rpm throughout the drive cycle.
Peak Motor speed = 6254 Rpm
iv) plot 3:
Shows the Torque characteristics and its changes of Motor in (Nm) throughout the drive cycle.
Peak Motor torque = 280 Nm
v) plot 4:
Shows the Battery Current values (A) and its changes for various acceleration inputs as per the Drive cycle.
The peak current discharge from the battery = 225.8 A
The peak current charging to the battery = -163.7 A
vi) Plot 5:
Shows the Battery state of charge SOC (%) and its changes corresponding to the driving inputs.
The state of charge decreased from 80% to 75.5% of charge in a time period of 49 seconds , for the specified driving conditions.
vii )Plot 6:
for the appropriate input driving conditions, displays the equivalent fuel economy in miles per gallon. In pure electric vehicles, there is no fuel present, yet this still provides the battery energy needed to calculate fuel efficiency. The maximum number of miles per equivalent gallon of gasoline that the provided vehicle can travel under the given driving circumstances is 21.45 miles.
Observation(Pure Electric VS Hybrid Vehicle With Same Load Conditions):
1. The highest speed achieved by an electric car is lower than that of a hybrid electric vehicle under identical environmental and drive cycle circumstances. When the hybrid car's motor and engine are combined, the torque produced by the hybrid vehicle is higher than that of the electric vehicle. The electric vehicle produces higher values of motor speed and torque than the hybrid vehicle's motor alone. This is what allows the hybrid vehicle to reach a higher peak speed than the pure electric vehicle.
2. The pure electric car's discharge capacity and charging rate are better since it employs a lithium-ion battery rather than a nickel metal hydride battery in this instance. In contrast to a hybrid car, the motor can produce a great amount of torque instantaneously since it can discharge at a quick rate. Additionally, the level of charge indicates that the pure electric vehicle's battery efficiency is higher than that of the hybrid vehicle, and this is also because of the type of battery utilised in both vehicles.
3. The miles per gallon figures for both of these cars show that the electric car is more efficient than the hybrid car.
4. Compared to hybrid vehicles, electric vehicles emit no emissions, only waste gases.
These are a few findings from the comparison of the simulations performed above using the Powertrain Blockset.