Week-4 Challenge WOT Condition Part-2
1.What is the difference between mapped and dynamic model of engine , motor and generator? How can you change model type?
Ans: A mapped model basically refers to a model with precalculated dataset for which the output values are readily available for the corresponding inputs. This basically means we get a fixed output value for a fixed input value. The values here are mapped and stored as data points that are calculated using an actual dynamic model in practice.
But a dynamic model performs a real time simulation of components that actually takes place in original system to generate an output depending upon random input situation. In short , both the mapped and dynamic models take the same input variable and give the same output variable , but the only difference lies in the way how the output data generated in each case.
Mapped Engine:- is the default settings in powertrain blockset , used to measure performance parameters of the vehicle by using standard lookup tables which are preferred to the system. This type of modelling is less accurate . The lookup table values are based on the values of brake torque , command torque and engine speed. If any other parameter like input engine temperature is selected then lookup table values are also a function of the temperature parameter. The data extracted from lookup tables are : air mass flow , fuel flow , emission data , exhaust temperature and efficiency. This data is used to find out other parameters which are needed by end user.
Dynamic Engine:- This type of engines uses real time data fed by user at run time for modelling. This model engines are more accurate than mapped engine model. This type of model is used when the data of sub systems of a vehicle is required . We can calculate : Brake torque , fuel flow , port gas mass flow , exhaust temperature , exhaust mass flow rate and exhaust emissions.
Mapped Motor:The mapped motor works in torque control mode. This type of motor is used when the user requires a faster simulation and doesn’t have the knowledge of motor parameters. The output torque and reference torque is compared and changes are made. Input torque or speed can be specified , electrical losses and maximum motor power and torque can be defined.
Dynamic Motor:- In the dynamic motor a three phase interior permanent magnet synchronous motor(PMSM) is used. The block uses three phase input voltages to regulate the individual phase currents, allowing control of the motor torque or speed. This block is used when the user knows what parameters are to be used in that particular simulation. This motor is more accurate.
Mapped generator:- The mapped generator block is also similar like other blocks. Most of the data require is taken from the lookup tables corresponding to the given input parameters. Its simulation time is less.
Dynamic Generator: The dynamic generator involves user entering the parameters manually during the run time for their particular applications. The results take time and are more accurate.
We can switch between mapped and dynamic engines by following below procedures:
1.Open the EV model I Simulink.
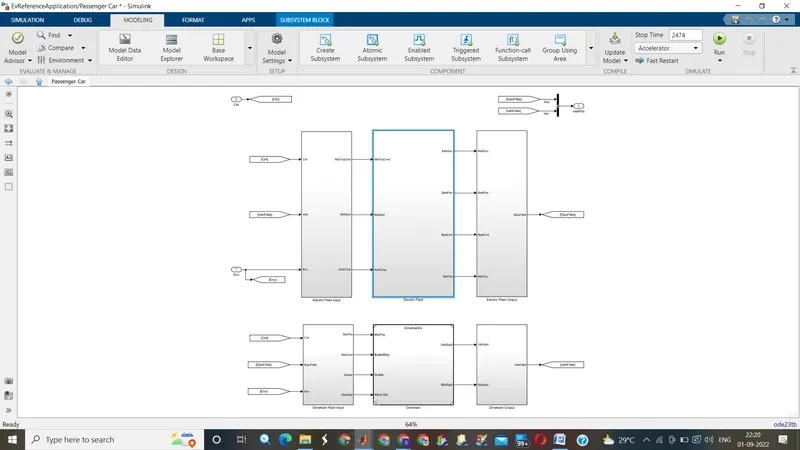
2.Enter the passenger car block by double clicking it.
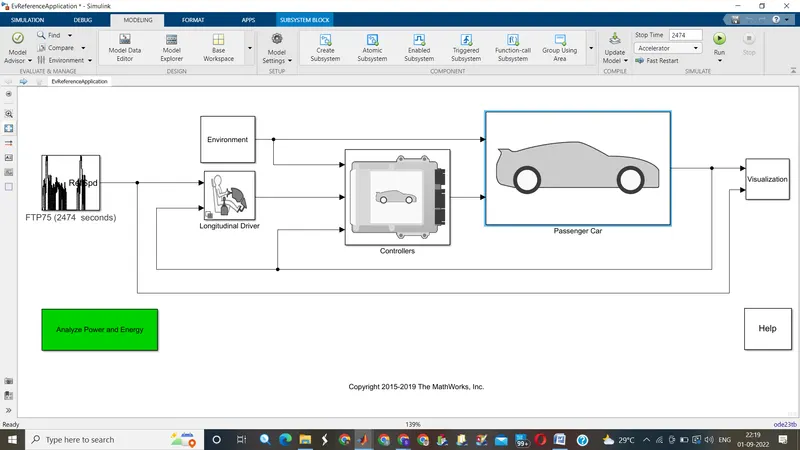
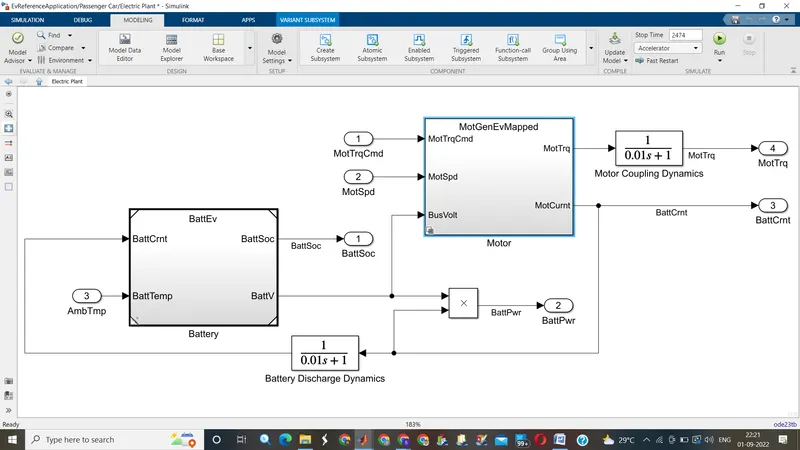
3.Then go to the electric plant block.
4.Inside the motor block right click to find the variant option.
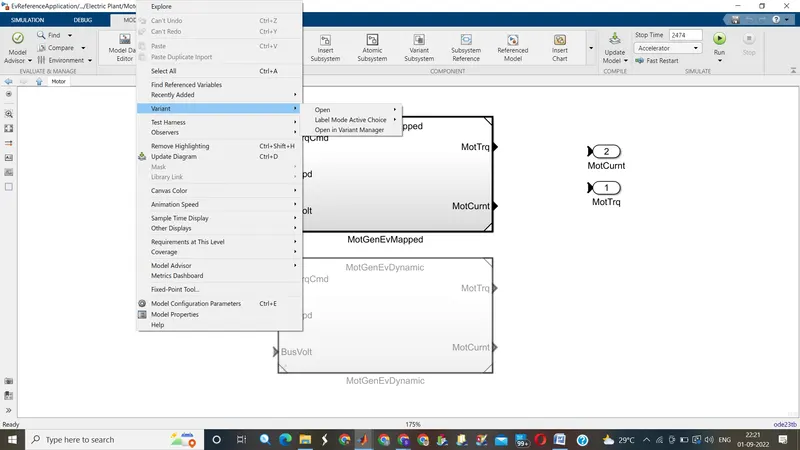
5.Then select ‘label Mode Active Choice’.
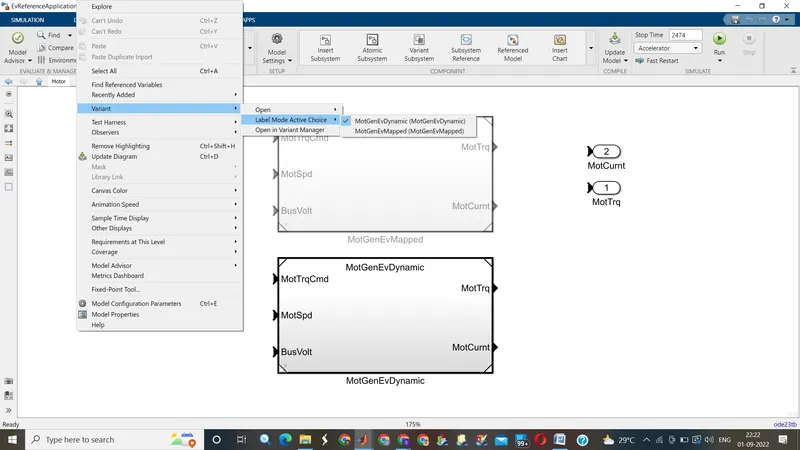
6.Then double click ‘MotGenEvDynamic’.
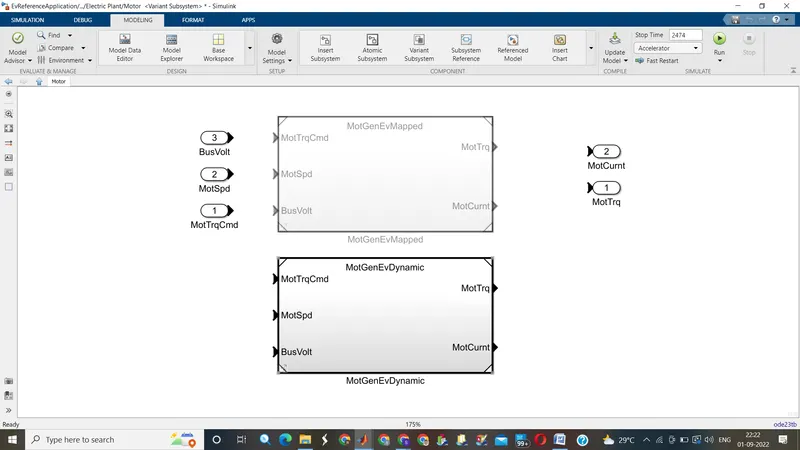
The same process can be repeated for motor and Engine.
Q2. How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
Ans: Miles per Gallon(MPG) & Miles per gallon equivalent(MPGE).:
For a conventional gasoline vehicle , the fuel efficiency is calculated via miles per gallon(MPG). However fuel efficiency for hybrid electric vehicles is calculated via miles per gallon equivalent(MPGE). MPG is the number of miles your car can drive per gallon of gas. Figuring out an MPGE rating is a little more complicated. Since engines that can use an alternative source of fuel can’t be measured by liquid gallons of fuel , the MPGE rating is calculated by figuring out the number of miles a vehicle can go using the same energy content as gallon of gas. The EPA calculated that 33.7 kilowatt hours of electricity is equivalent to one gallon of gas.
We should go inside EV reference block that is performance calculations:
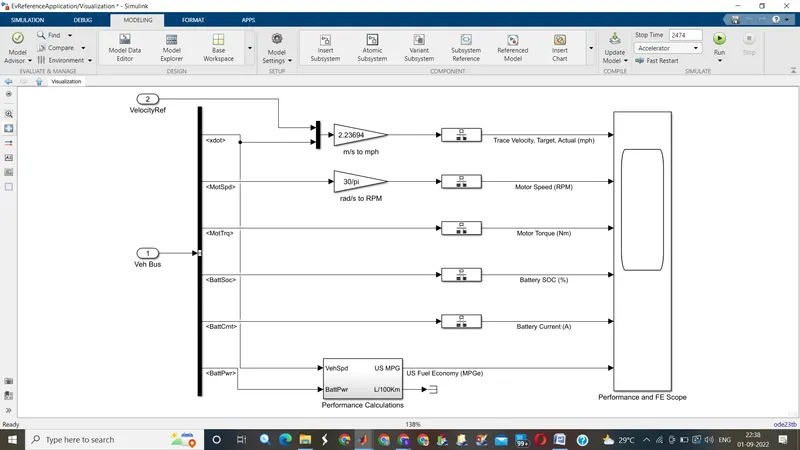
Inside the block will get actual MPG calculations:
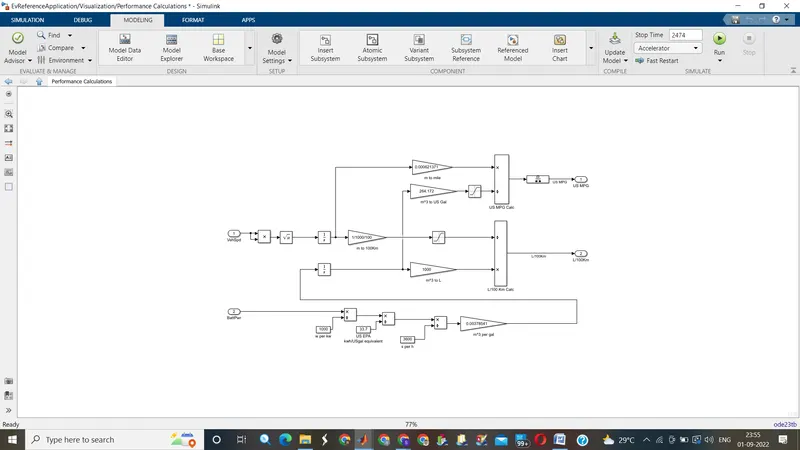
Here , three different inputs are taken in to considerations:
- Vehicle Speed.
- Fuel flow.
- Battery Power.
The vehicle speed inputs in m/s which is converted into miles by multiplying with 0.000621371.
Similarly the kilogram of fuel is converted in to cubic meter by multiplying by 1/(1000*0.739).
This cubic meter value is then converted in to gallons by multiplying it with 264.172. The mile value and gallon value is used to find MPG of the vehicle.
Now the battery value is initially converted from watts to kwh by dividing with 1000 and then to gallon equivalent by again dividing it with 33.7 (since 33.7 kwh=1 gallon)
Then divide the value by 3600 to get in per seconds and multiply by 0.00378541 into get the value in cubic meter per gallons.
3.Run the HEV reference application with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
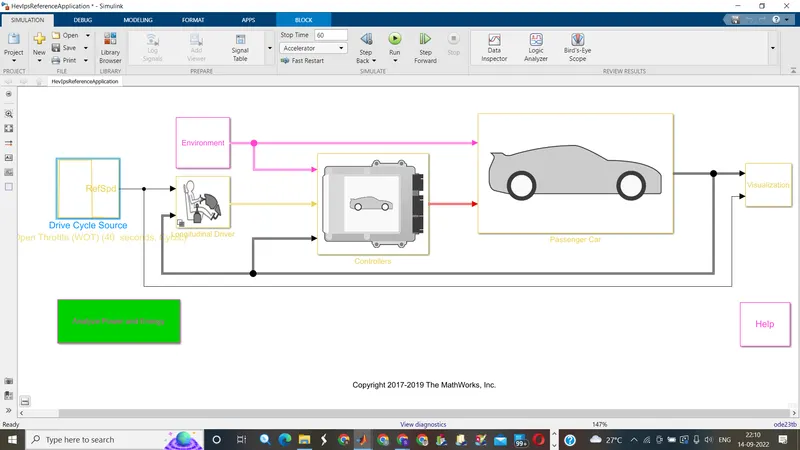
Here we have changed drive cycle to WOT with a sample time 40 seconds.
We have also altered environment block and changed wind speed to 25 m/s & grade to 10.
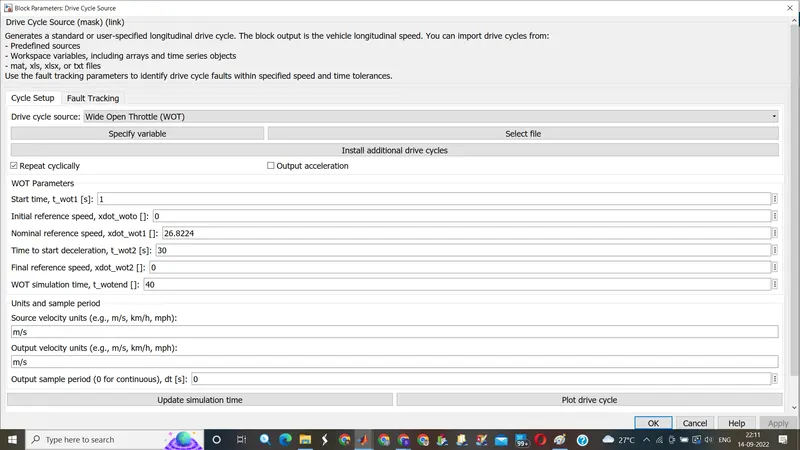
Enviroment Block:
Results:
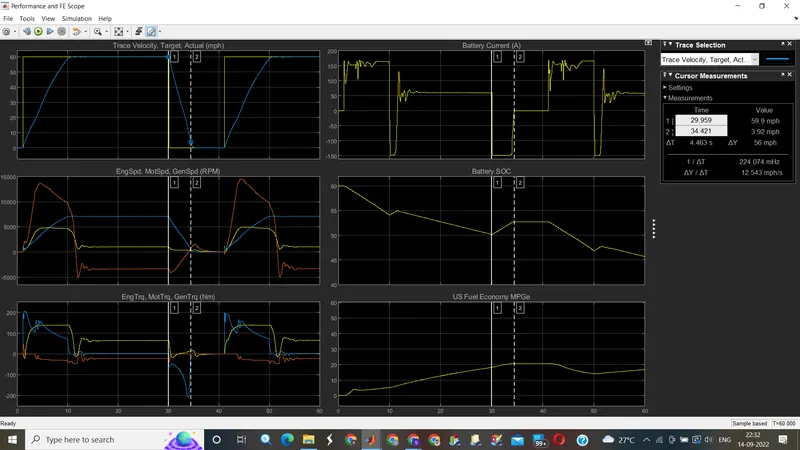
1.grade at "0" & Wind Speed at "0" the result is shown below .
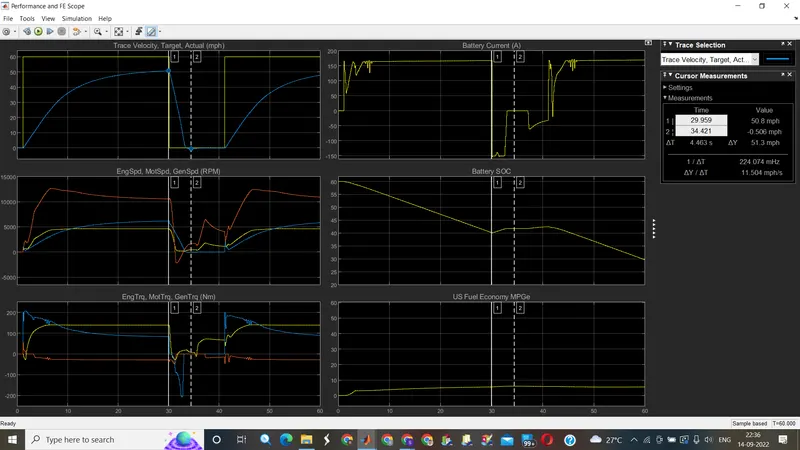
2.Result after changing grade to "10" & Wind speed to "25 m/s"
Conclusion:
Plot1: Trace velocity , target , actual:
Top velocity achieved=50.9 mph.
Time taken to acclearate=29.051 sec.
Time taken to deacclearate=3.384 sec.
Plot2:Motor& Engine RPM:
Top motor rpm=4626 rpm.
Top engine rpm = 6177.691 rpm.
Plot3: motor& engine torque:
Maximum motor torque=139.06 N-m.
Maximum engine torque = 83.448 N-m.
Plot4: Battery current:
The battery supply current is at its maximum value of 167 ampere when full throttle is applied by the user it reduces drastically to the value of negative 150 during deacceleration of the vehicle.
Plot5: Battery SOC:
The battery SOC will falls from 60 to 40% during acceleration of vehicle and it increases slightly to 40 to 42% during deacceleration due to regenerative braking.
Plot6: Fuel Economy :
Maximum Fuel economy achieved =2.971.
Q4. Keeping all the parameters same , compare the simulated results op pure and hybrid electric powertrains.
Ans:
Simulated results of HEV:
Simulated results of EV:
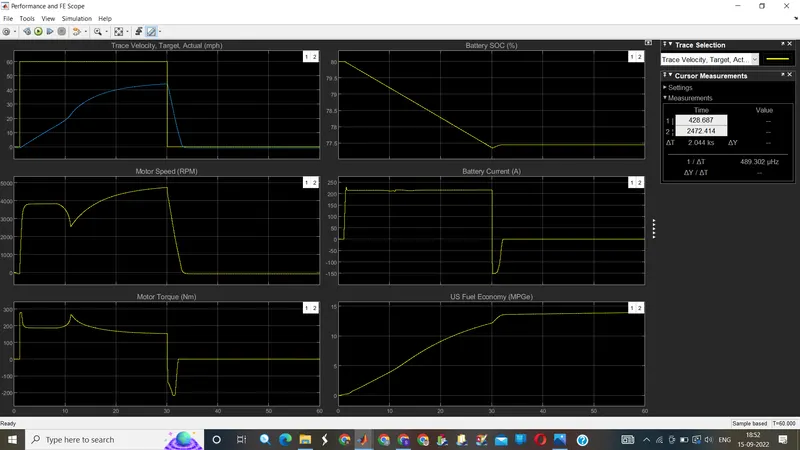
Conclusion:
- The top speed is achieved by hybrid electric vehicle is more than that of EV.
- The battery current drawn by hev initially high but later decreases as during starting Hev will start only by battery so motor takes all the load initially and later engine kicks in so load is distributed bet ween motor and engine.
- The battery current capacity of pure EV is much higher compared to that of HEV since in EV battery is the only driving but motor torque and motor speed keep changing a lot in Hev.
- Higher fuel economy is achieved in case of Pure EV.
- SOC improvement in HEV is effective than the pure ev during regeneration.