Week-4 Challenge WOT Condition Part-2
Answer:
WOT Condition Part-2 ( Wide open Throttle)
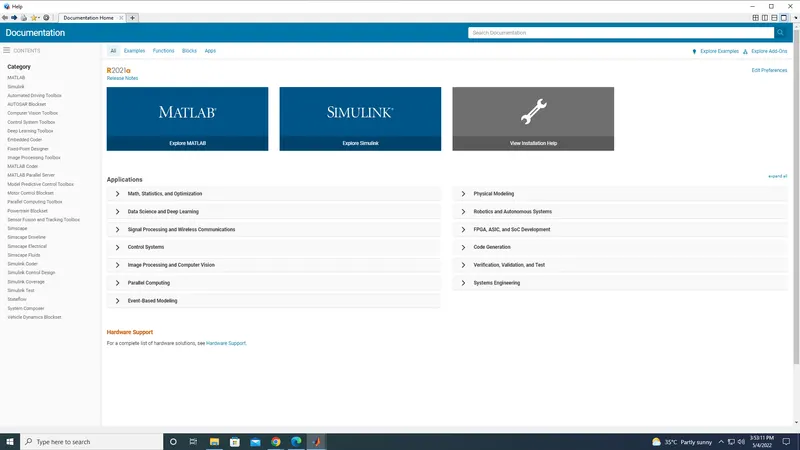
At first open the MATLAB then click on the option help which was placed on the top of the Matlab window
After that Help tab will be open
In that we need to search "Geting started with powertrain blockset"
Then the screen will be open like this
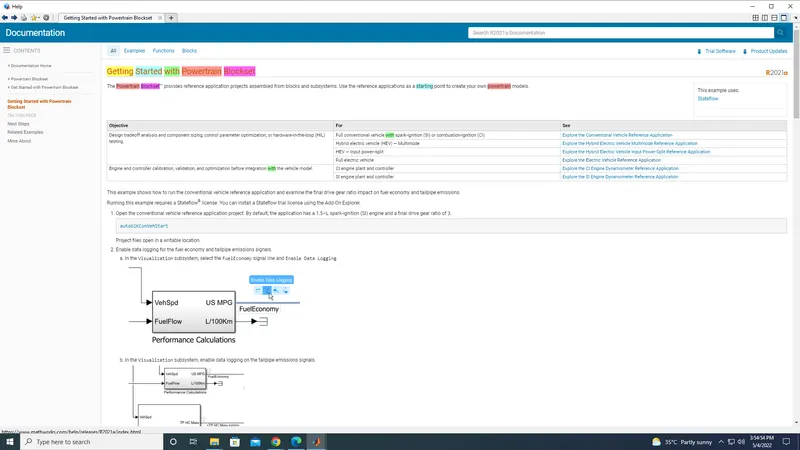
thus we get in to powertrain blockset
Now we need to select "Explore the Electric Vehicle Reference Application" full electric vechile
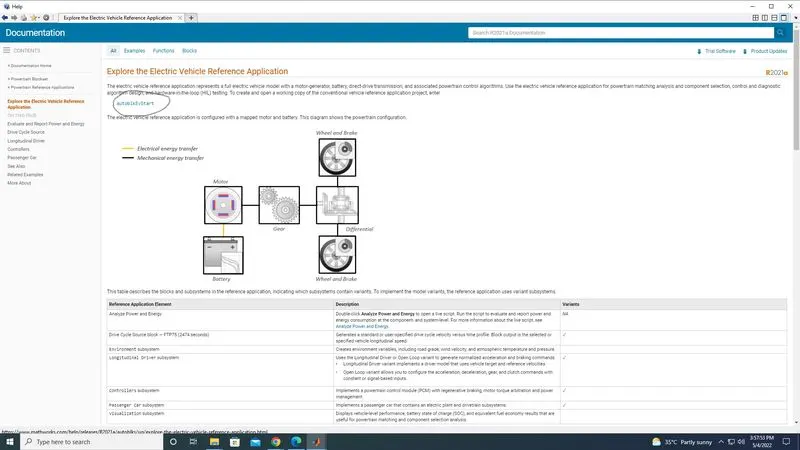
after clciking on the link we will get into a new screen, and need to click on the link
like this a default model will be open
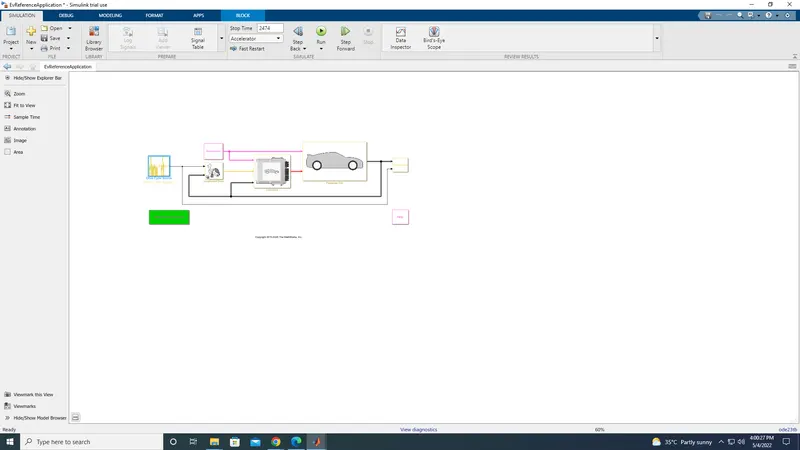
like this we need to get the powertrain blocks by using Help
1. What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
mapped model
The Mapped Motor block implements a mapped motor and drive electronics operating in torque-control mode. The output torque tracks the torque reference demand and includes a motor-response and drive-response time constant. Use the block for fast system-level simulations when you do not know detailed motor parameters, for example, for motor power and torque tradeoff studies. The block assumes that the speed fluctuations due to mechanical load do not affect the motor torque tracking.
You can specify
Port configuration — Input torque or speed.
Electrical torque range — Torque speed envelope or maximum motor power and torque.
Electrical loss — Single operating point, measured efficiency, or measured loss. If you have Model-Based Calibration Toolbox™, you can virtually calibrate the measured loss tables
dynamic model.
Dynamic engine decompose engine behaviors into individual component models that account for engine dynamics, most notably intake airflow and turbo charger dynamics.
Dynamics engine models are suitable for desiging control, estimator and diagnostic, algorthims that depend on dynamic subsysytem states, for example in closed loop AFR (air fuel ratio) control algorithm development.
for changing the system into a Mapped model or a Dynamic model, need to
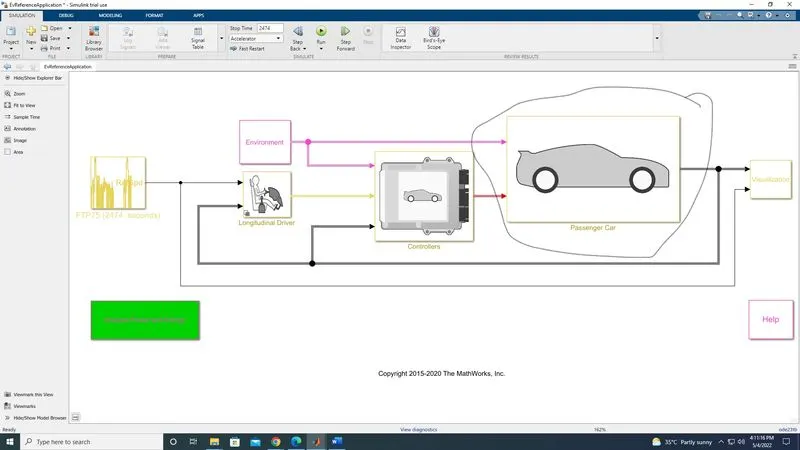
we need to double click on the passenger car block , which was in the main model
in that again double click on electric plant subsystem
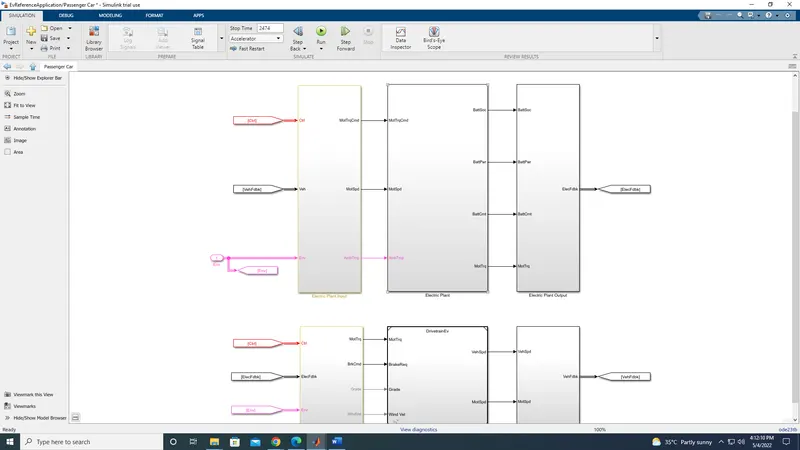
after double on the electric plant,it will seems like
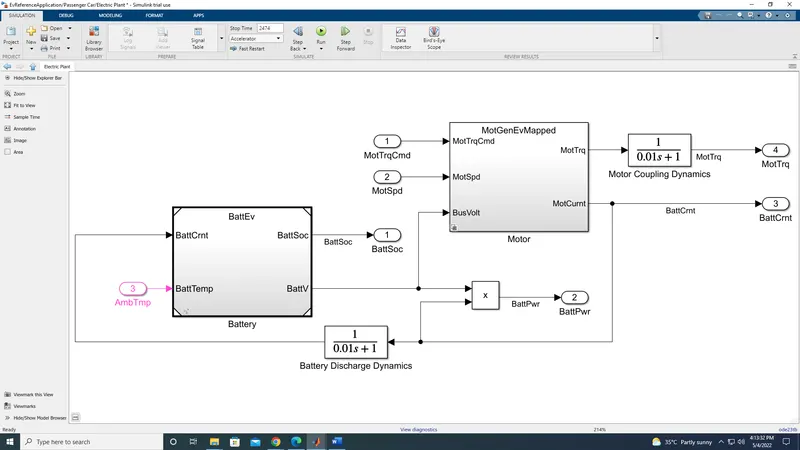
now right click on the motor
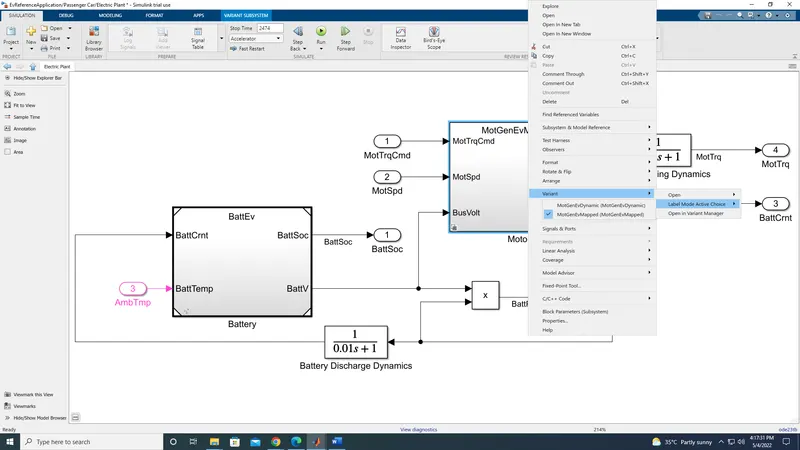
in that we need to select weather the model run through dynamic or Mapped,like this we need to change
inside the motor it will seems like this
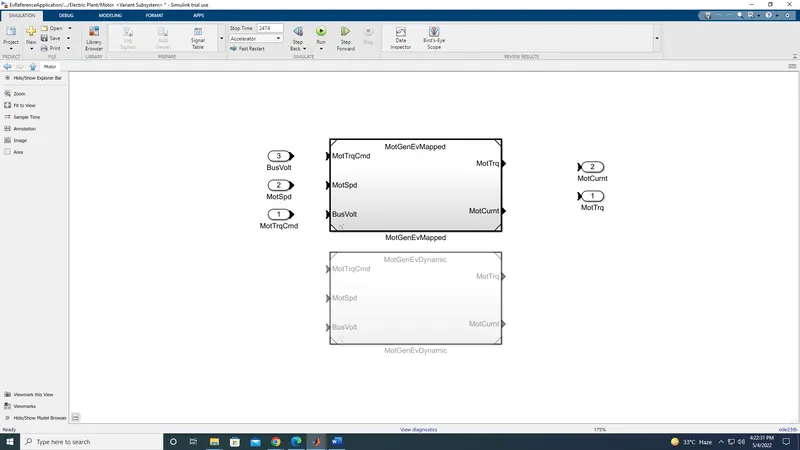
if we change the model to dynamic means it will change to Dynamic and Mapped model will uncomment default
2. How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
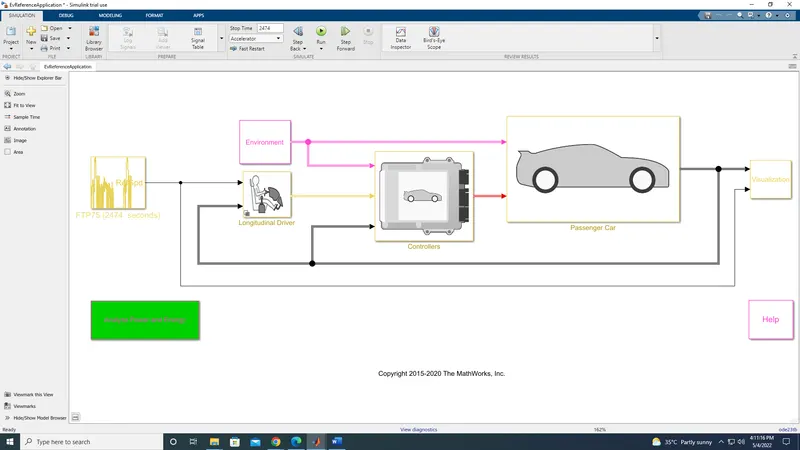
this is the default model, in that need to double on the Visualization block
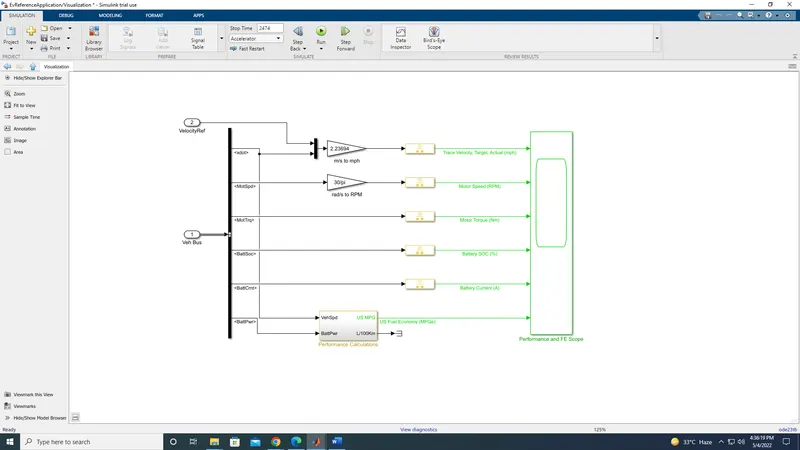
it will shows like this
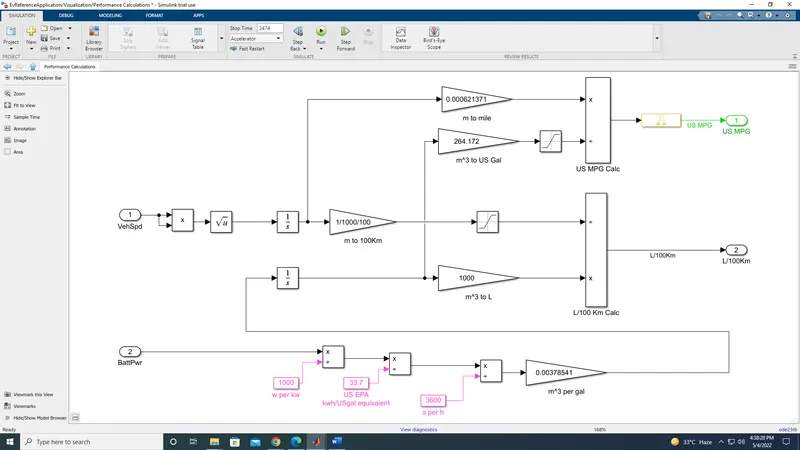
In transportation, the unit of energy is usually kilowatt-hour. The energy consumption per unit distance in KWh/Km is used to evaluate the vehicle energy consumption.
In the U. S., the distance per unit volume of fuel is expressed in miles per gallon (mpg). Energy consumption is an integration of the power output at the battery terminals.
The factors to be considered are vehicle speed, Battery Power, and fuel volume flow. The vehicle speed is multiplied by time and then integrated to get the range of distance.
This value is multiplied by factor 0.0000621371 to convert into distance, mile. Both the battery cell fuel and FuelVolFlw are then integrated. The total volume value is multiplied by factor 264.172 to convert the volume from m3 to US Gallon. Then the distance is divided by total Fuelvolflw to get miles per Gallon, US MPG
And the performance and efficiency as been given in the scope
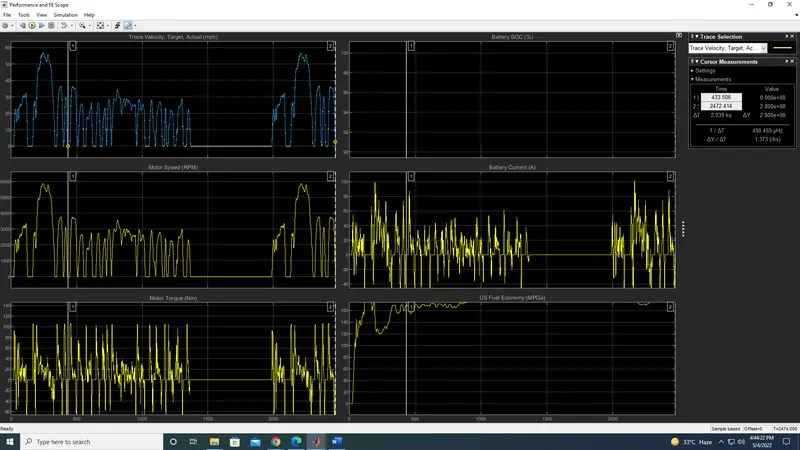
3. Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
For this we need to change the drive cycle mode into a Wide open throttle (WOT), for that double click on the drive cycle block
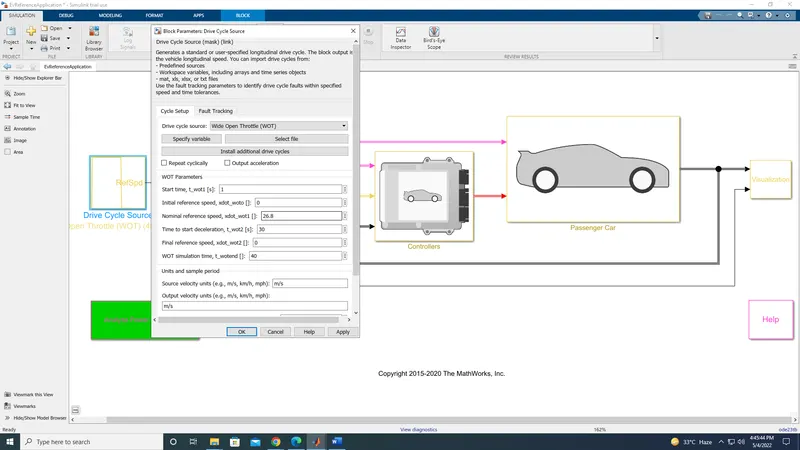
in that change the drive cycle source into wide open throttle( WOT) and default values has been give inthat and select ok
Now the WOT as been applied on the drive cycle mode
and the run time will defaultly changes in to 40 as we given in the WOT condition
And now we need to change the grade value and Wind value
For that we need to double on Environment block
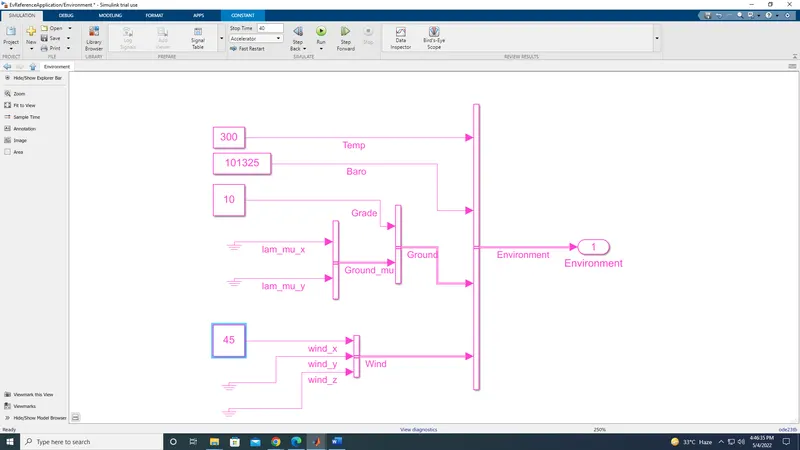
in that change the grade value and wind vlue
now run the model
and the output has been shown in the scope
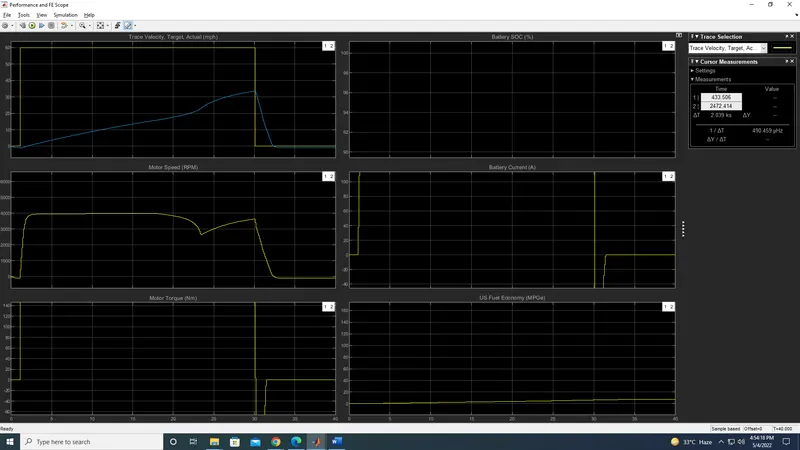
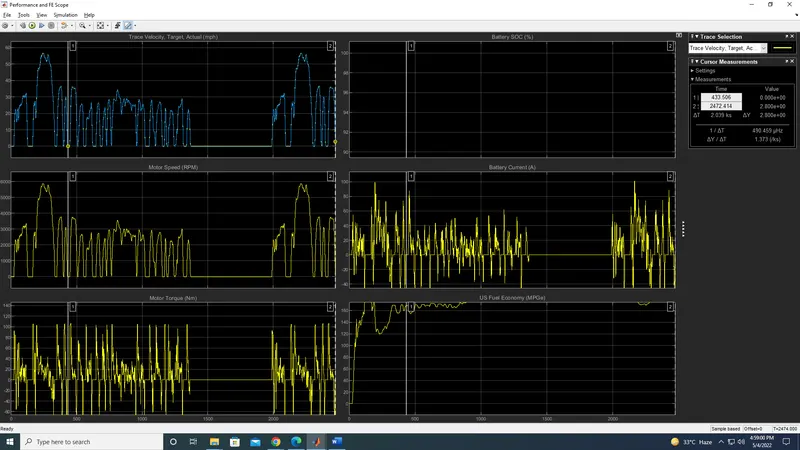
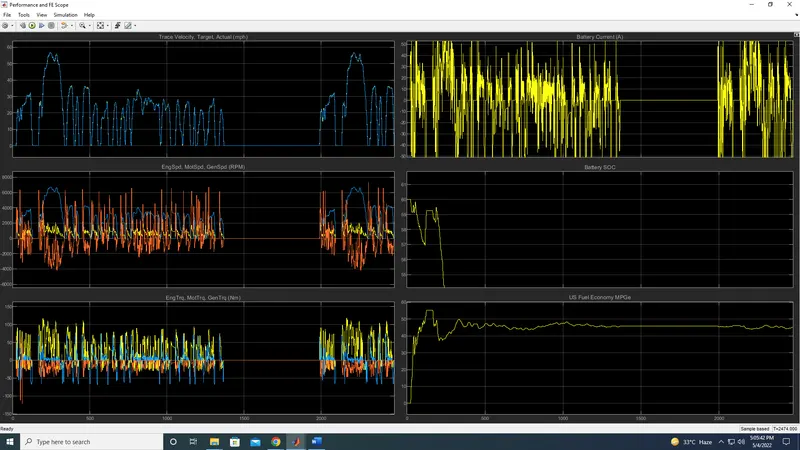
4. Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
pure electric powertrains
HEV — Input power-split
Performance calculation
Emission Calculations
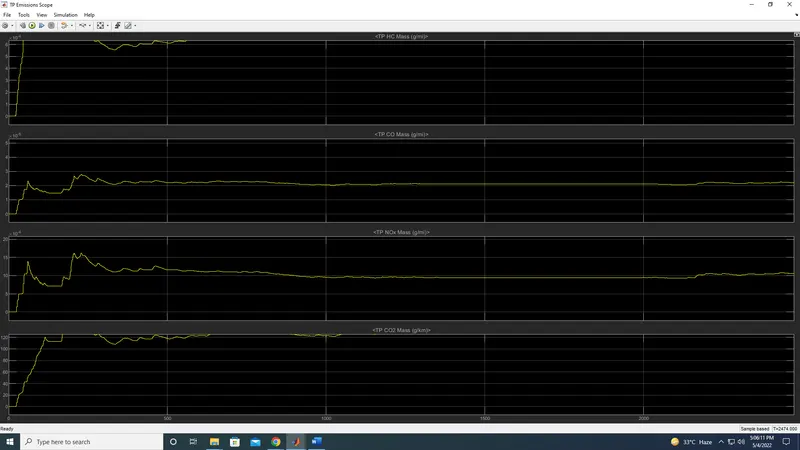
Thus the both model been of EV model and HEV model has been run with default values and parameter
and the putput has been shown inthe scope