Week-4 Challenge WOT Condition Part-2
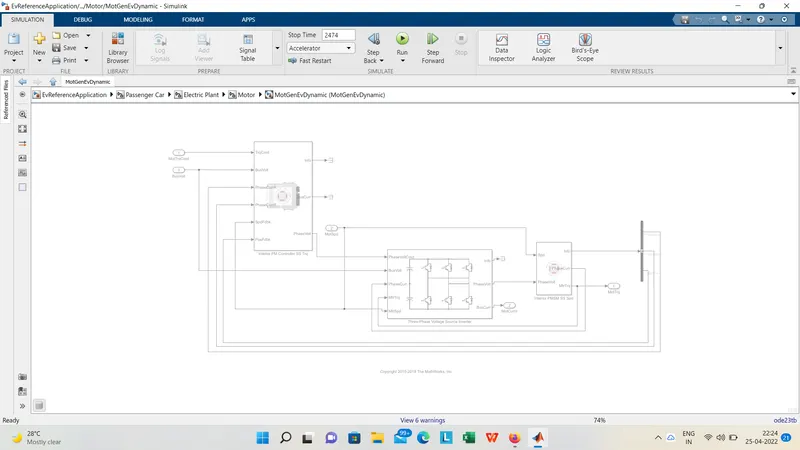
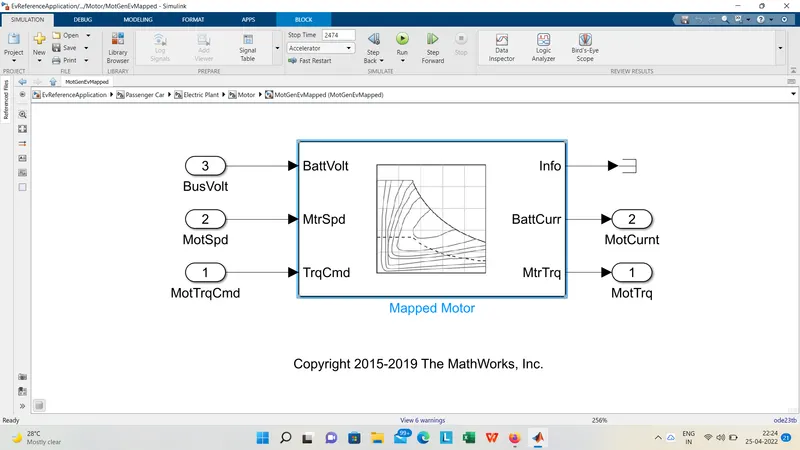
1.the difference between mapped and dynamic model of engine, motor and generator is
in the mapped model the input and output parameters are already saved and then simulated
1.battery volt
2.motor current
3.motor cmd
the above mentioned inputs are mapped and created in the look up table
the output is also mapped and values are created
1.motor torque
2.battery current
where as in the dynamic
the model is being created in the real time and the it will run ,
as per the driving cycle inputs the phase voltage and current feedback is given along the voltage feedback and the the real time simulation is taken
the accuracy of the subsystem is very high compared to mapped as it has real time parameters
the photos has been attached 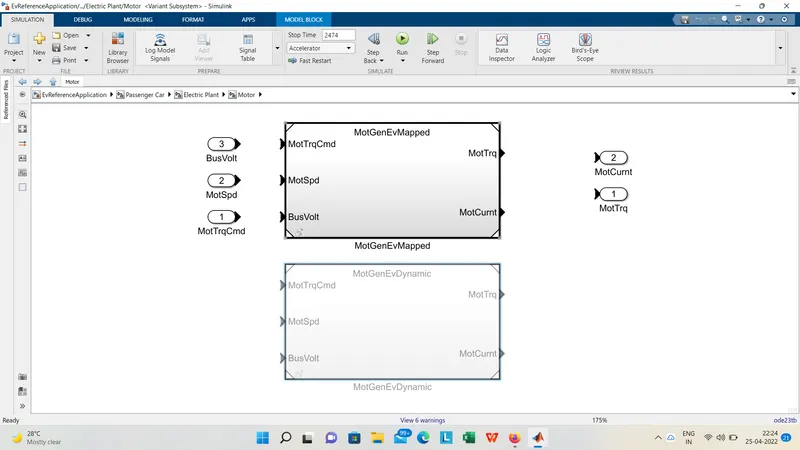
2. 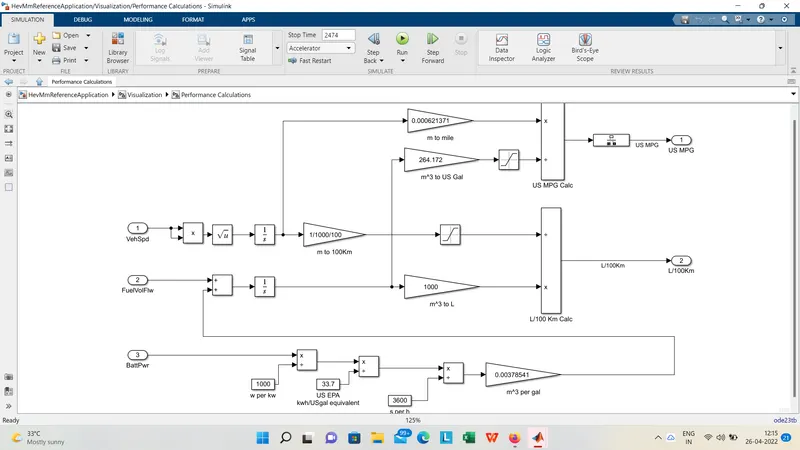
to caluclate the miles/gallon
the vehicle speed input is connected with product block from their it goes to sqroot from there the value is integrated and then multiplied by 1000
the fuel flow is connected to add block and the value is divide to convert and the value is further integrated and multiplied by 1000
battery poer is connected to divide block didvide by 1000 then divide by 33.7 and then multiplied with 0.0037 value so we will get the gallons/mile
further the fule flow value and vehicle speed value is taken then multiplied by 0.00062 &264.172
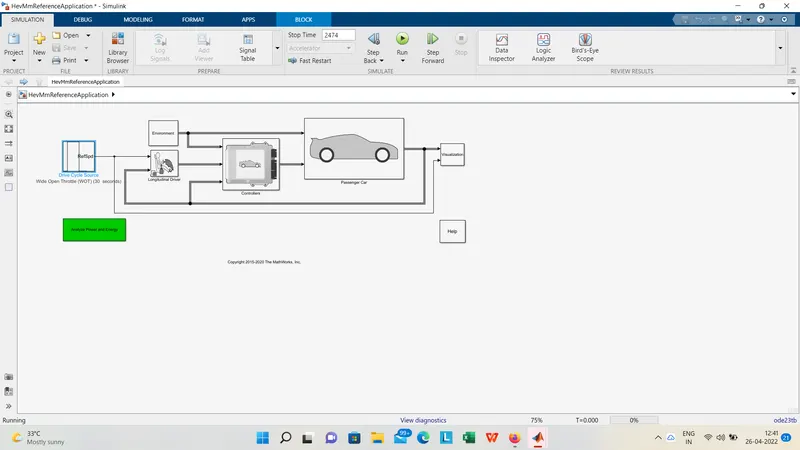
3.the hev refrnce application is run with WOT driving cycle
in this we havce to open the HEV model and then simulate the model .
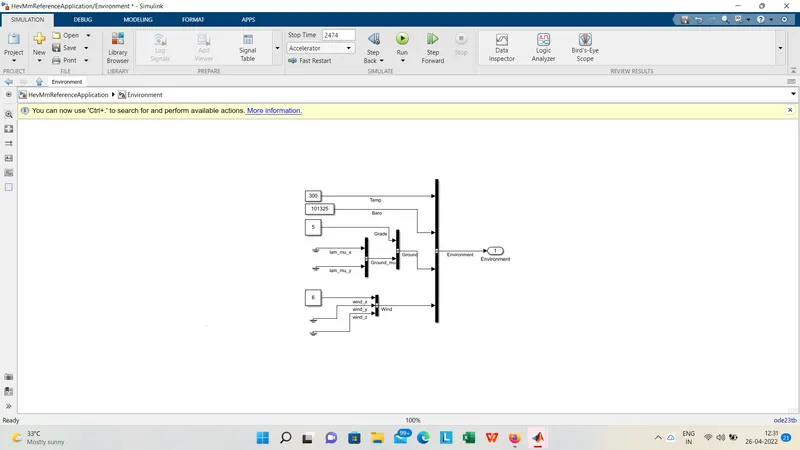
the wind vel=6 , grade = 5 the simulation timer is 30 sec
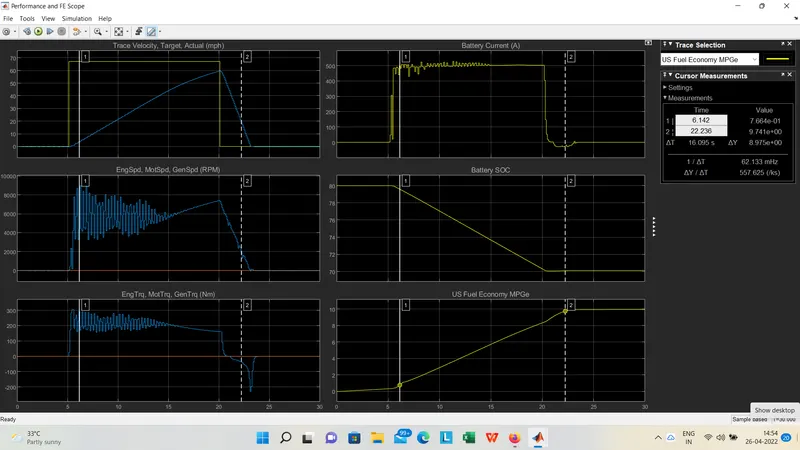
after running the model we have to go to visualisation block and then open the scope , in the scope the vehicle parameters is shown accordingly with plotted graphs
plot1: tyrace velocityt: the top speed for reaching 60mph is 15.124sec
plot2:motor,gen,engine RPM: the peak rpm is 9000rpm
plot3:motor torque: the max torque is 300n=Nm
plot4:battery current: the peak current to discharge battery is 510A , the peak battery current to charge for regen is -100A
plot5:battery SOC: the battery SOC has come down from 80%-70% with in 14.78sec
plot6: us fueleconomy: the
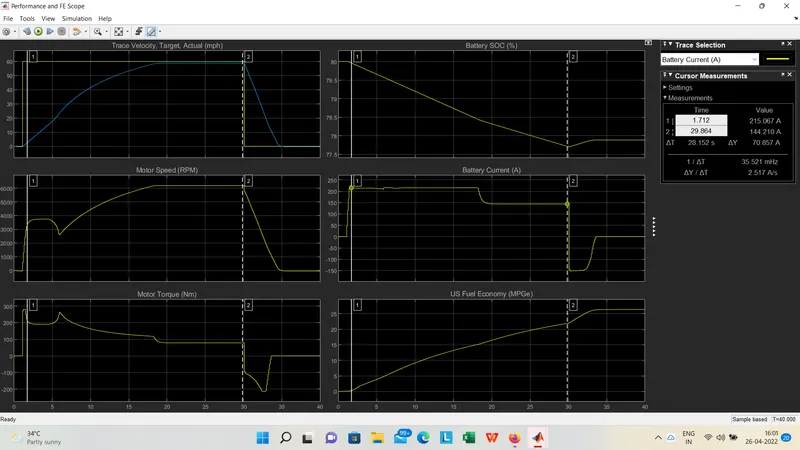
4.comparing to pure electric vehicle keeping all parameters same is shown below
plot1: the max speed achived is 58mph in 18.12sec
plot2:motor speed: the max motor speed is 6100RPM
plot3:motor torque:the motor torque is 290Nm
plot4:battery SOC: the battery SOC has came dowm from 80%-77.1%
plot5:battery current: max discharge current is 220A , the charger current is -150A
plot6: fuel economy: the vehicvle can run upto 27gallon/ltr.
the difference betwwen HEV and pure electric vehicle is
1. the motor torque is high in HEV compared to pure electric
2.the BATTERY SOC in pure electric vehicle is good compared to HEV
3. the efficiency of pure electric vehicle is good
3. zero emmission is in pure electric