Project 1 (Mini Project on Vehicle Direction Detection
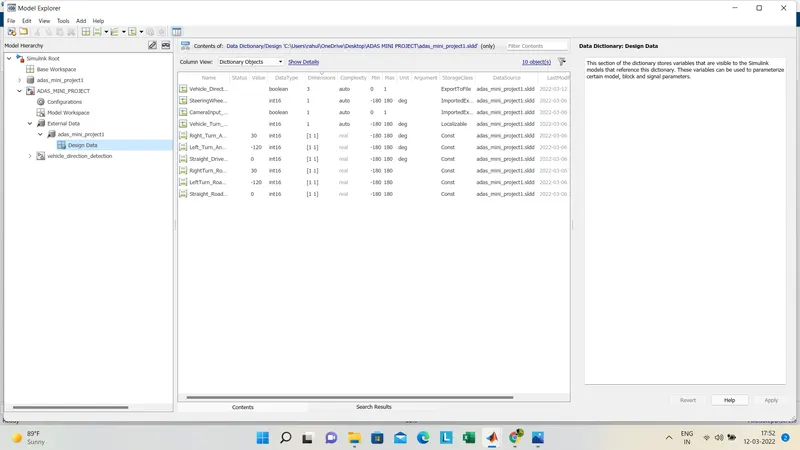
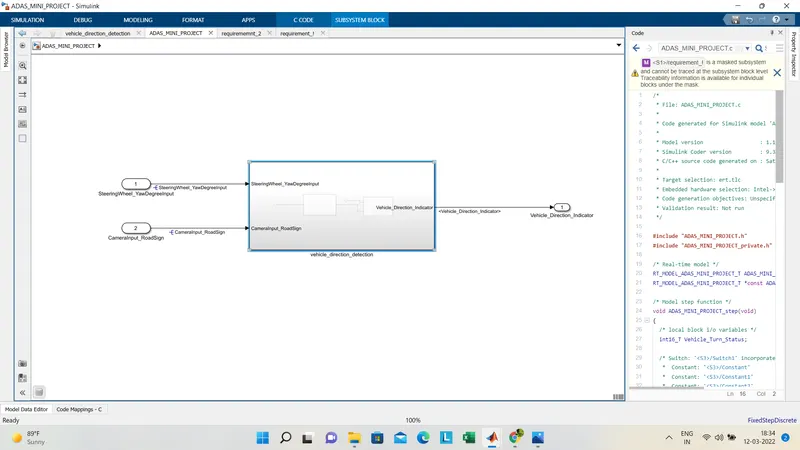
the mini project is based on vehicle direction detection , the process which the priject has been built is shown as below
1. as per the requirement given we have to bvuild the model
2. in the requirement 1 we have to analyse it nd create the blocks and resolve , propagate the blocks the subsystem is created
3.then we have to name the blocks as per the MAB rules the susbsytem should be linked with the requirement details which we sholud create in a word document and thn highlight it and link it.
if the input is 30 for steering wheel yawrate then it will compare with the right turn value if the both are same then it will go to switch block and if the condition is true the value goes to vehicle turn status as boolean output else if it is false it goes to next switch input and compares for that value
4. in requirement 2 the input is taken from requirement subsystem and then other seprate camera road sign input is also given
then the particular blocks is placed and devloped and as per MAB the signals and nbames are given
5. the SLDD is ctreated for the blocks in for the two requiremnents as per the values and other details given in project overview
6. then the main subsystem is created then the names and sighnals are resolved
7. then we have run the simulation if there is no errors then we have to go to model advisor and run the task
8. in the model advisor we have to go to MAB coloumn and run our files so if we run it checks for the warrining and errors
if error is there we have to go to the particular folder then it showsa where and what exact the erro is there then if we clear that we have to run the file again so the generates the report we have to save it
9.next we have top genberate the code , so that we have to go to appas in that embedde coder c then we have to check our configuratuion settings if it is okay then we can click on build option so that it will create the C code for the same so thats our final output as c code