Week-4 Challenge WOT Condition Part-2
1.
DIFFERENCE BETWEEN MAPPED AND DYNAMIC MODEL :-
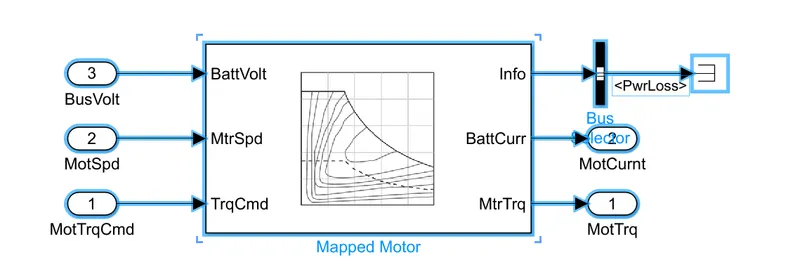
Mapped model :
i.This type of model basically run on the based of lookup tables or some predrfined inputs.
ii.Not efficient for giving exact output , some error may occur.
iii.Take less simulation time
iv.Don't depends upon the real time simualtion.
v.More suitable for analysis and testing.
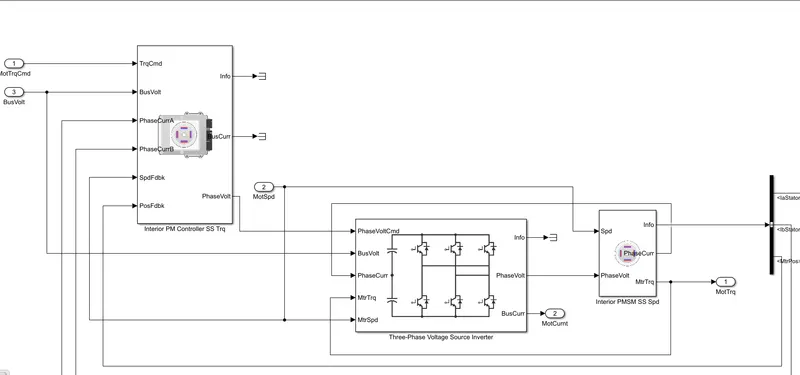
Dynamic model :
i.In this model it needs actual components like motor , generator , engine and its accesories.
ii.Accurate in providing outputs.
iii.More time require for simulation
iv.Depends upon real time simulation.
v.More suitable for designing control.
CHANGING MODEL TYPE:-
we can change the model by simply going to the modelling of simulation , their we found the varient manager in design part then by clicking it we go the motor and initially in motor it allowed 'mapped model' there by left clicking it and by setting "set as level mode active " choice we can get the 'dynamic model' of it.
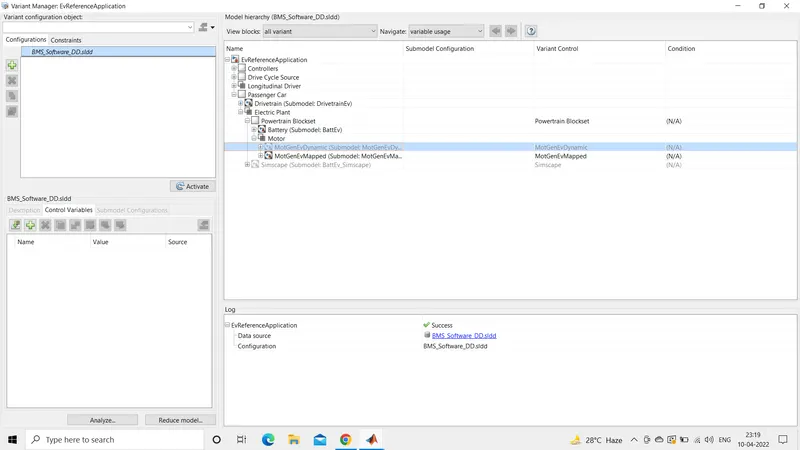
Hence, here we refered a model of EV and by looking in to it we conclude some typs of modelling in system part which have both pros and cons.
Some modelling of models are mentioned above that how we change to different models like dynamic and mapped .
2.
Here we refered a model of EV system where its shows how the parameters are converted like kilometer to mile and power to gallon.
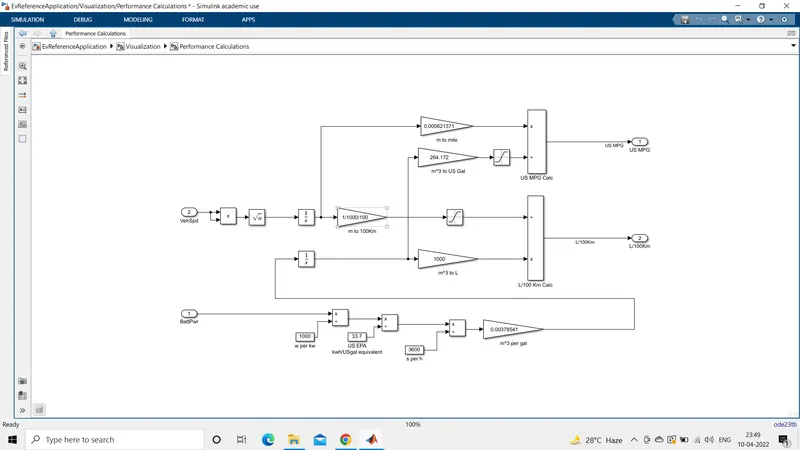
In the above picture we can see that the input speed unit is in km/h and by forwarding this by some blocks it changes to miles .
similarly for second input the battery unit is in kwh and by simulating this by some blocks it changes to gallon.
Conversion to Miles per gallon done by this way.
FACTORS LEADS TO FULL FLOW:-
i.Road condition
ii.weather condition
iii.Weight of the vehicle.
iv.By not properly driving.
Therefore,In foreign countries like UK/US they measure their distance by miles and gasolines(petrol/disel) by gallons , so to convert to that we tested above and the fuel flow depends upon the vehicle and natural factors.
3.
Open the HEV referenece model with input as drive cycle (WOT) wide open throttle.
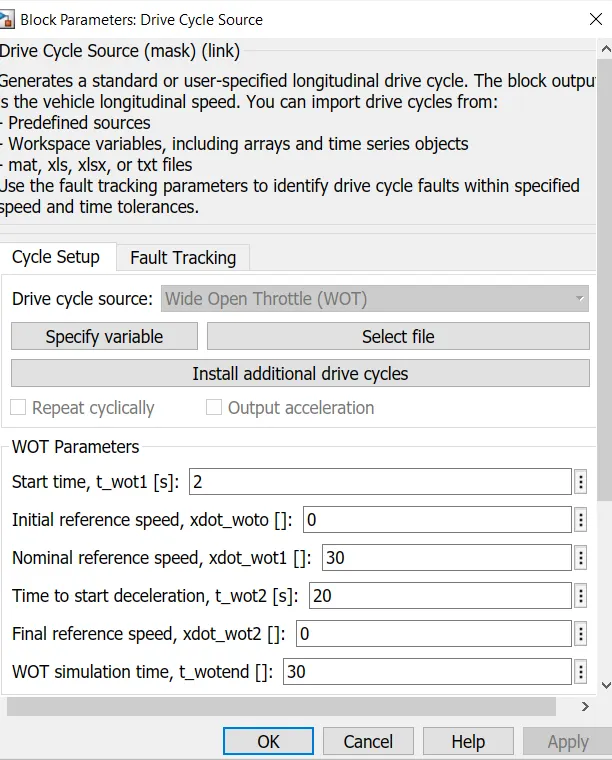
Case 1:-
Here grade=0
wind velocity=0 m/s
Case 2:-
Here grade =20
Wind velocity=10 m/s
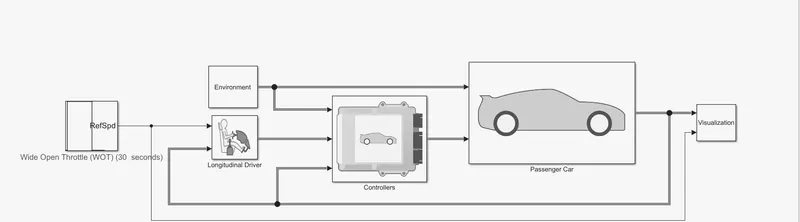
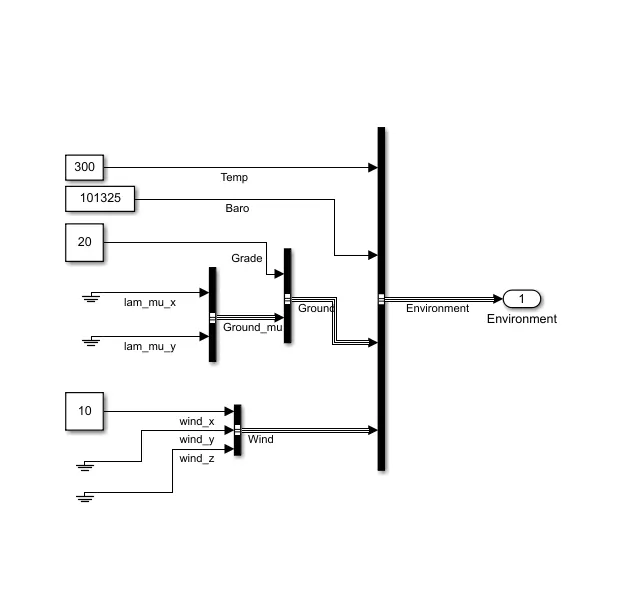
Grade and wind velocity are changed in environmental block of HEV model.
We conclude that giving grade to system decreaes its speed and efficiency while wind veloity is a factor of inverse force to the motion of vehicle. So, by increasing the gradebility and wind velocity maximum speed of the vehicle decreases , fuel ecomomy , battery efficiency etc are decreases which will affect the vehicle and the vehicle person.
In declaration of vehicle at no grade case battery pack recharge less than in grade case as here battery can charge more.
4.
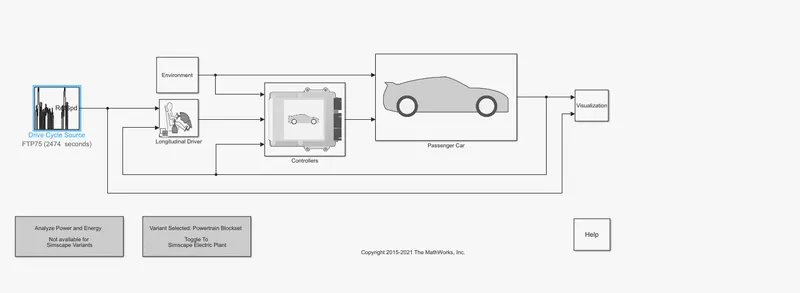
Keeping all other parameters same as previous case here we discuss the variations between HEV and EV.
Like above case first we go the ev reference model and by opening it model is revealed and simuntaniously we distinguish two vehicles.
EV MODEL:-
HEV MODEL:-
Outputs are uploaded below.
Therefore,here we studied the following:-
1.the basic differnence between EV and HEV where we found that the torque produced by an EV model is better but the torque produced by a HEV is more because its a combination of both motor ans engine.
2.EV is more efficient than HEV in case of miles per gallons.
3.By motor in HEV its gives a good torque as in case battery might low in both EV and HEV.
4.EV is more ecofriendly than HEV.
5.EV has one power source while as in HEV it has two no of sources.