Week 4.1 - Genetic Algorithm
Aim:
To optimise the stalagmite function and find the global maxima of the function using genetic algorithm.
Objective:
The main objective of this report is to optimiste the stalagmite function and find the global maxima of the function using genetic algorithm in MatLab.To expalin the concept of genetic algorithm and also explain the syntax for ga.
Stalagmite:
A stalagmite is a type of rock formation that rises from the floor of a cave due to the accumulation of material deposited on the floor from ceiling drippings. Stalagmites are typically composed of calcium carbonate, but may consist of lava, mud, peat, pitch, sand, sinter, and amberat. Since our function gives us a shape of stalagmite it is named as stalagmite function. The stalagmite function consist of local maxima and minima.A stalagmite function generally refers to the function with which we are generating values over a stalagmite kind of surface for finding out the local and global maxima and minima of that particular given function.
Genetic Algorithm:
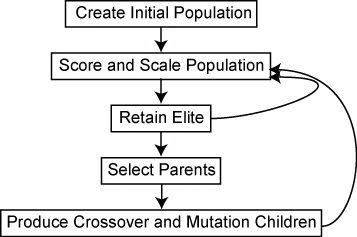
A genetic algorithm is a search heuristic that is inspired by Charles Darwin’s theory of natural evolution. This algorithm reflects the process of natural selection where the fittest individuals are selected for reproduction in order to produce offspring of the next generation.The genetic algorithm is a method for solving both constrained and unconstrained optimization problems that is based on natural selection, the process that drives biological evolution. The genetic algorithm repeatedly modifies a population of individual solutions. At each step, the genetic algorithm selects individuals from the current population to be parents and uses them to produce the children for the next generation. Over successive generations, the population "evolves" toward an optimal solution. You can apply the genetic algorithm to solve a variety of optimization problems that are not well suited for standard optimization algorithms, including problems in which the objective function is discontinuous, nondifferentiable, stochastic, or highly nonlinear.
Notion of Natural Selection:
The process of natural selection starts with the selection of fittest individuals from a population. They produce offspring which inherit the characteristics of the parents and will be added to the next generation. If parents have better fitness, their offspring will be better than parents and have a better chance at surviving. This process keeps on iterating and at the end, a generation with the fittest individuals will be found.
This notion can be applied for a search problem. We consider a set of solutions for a problem and select the set of best ones out of them.
Five phases are considered in a genetic algorithm.
- Initial population
- Fitness function
- Selection
- Crossover
- Mutation
Initial Population:
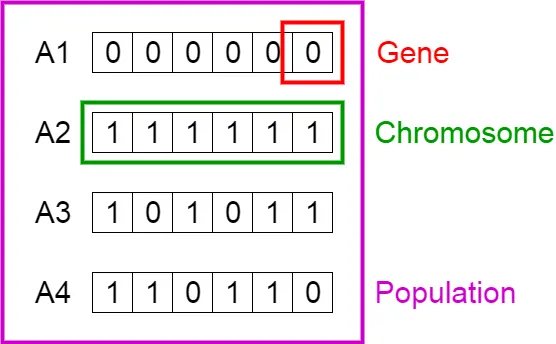
The process begins with a set of individuals which is called a Population. Each individual is a solution to the problem you want to solve.
An individual is characterized by a set of parameters (variables) known as Genes. Genes are joined into a string to form a Chromosome (solution).
In a genetic algorithm, the set of genes of an individual is represented using a string, in terms of an alphabet. Usually, binary values are used (string of 1s and 0s). We say that we encode the genes in a chromosome.
Fitness Function:
The fitness function determines how fit an individual is (the ability of an individual to compete with other individuals). It gives a fitness score to each individual. The probability that an individual will be selected for reproduction is based on its fitness score.
Selection:
The idea of selection phase is to select the fittest individuals and let them pass their genes to the next generation.
Two pairs of individuals (parents) are selected based on their fitness scores. Individuals with high fitness have more chance to be selected for reproduction.
Crossover:
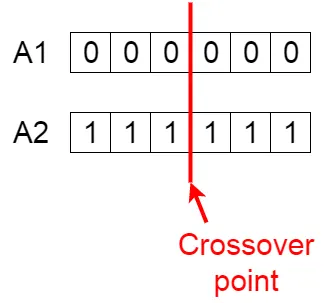
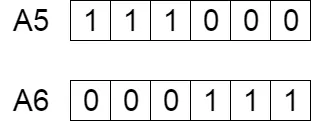
Crossover is the most significant phase in a genetic algorithm. For each pair of parents to be mated, a crossover point is chosen at random from within the genes.
For example, consider the crossover point to be 3 as shown below.
Offspring are created by exchanging the genes of parents among themselves until the crossover point is reached.
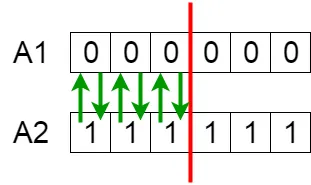
The new offspring are added to the population.
Mutation:
In certain new offspring formed, some of their genes can be subjected to a mutation with a low random probability. This implies that some of the bits in the bit string can be flipped.
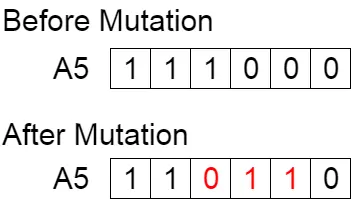
Mutation occurs to maintain diversity within the population and prevent premature convergence.
Syntax for Genetic Algorithm:
x = ga(fun,nvars)
x = ga(fun,nvars,A,b)
x = ga(fun,nvars,A,b,Aeq,beq)
x = ga(fun,nvars,A,b,Aeq,beq,lb,ub)
x = ga(fun,nvars,A,b,Aeq,beq,lb,ub,nonlcon)
x = ga(fun,nvars,A,b,Aeq,beq,lb,ub,nonlcon,options)
x = ga(fun,nvars,A,b,Aeq,beq,lb,ub,nonlcon,intcon)
x = ga(fun,nvars,A,b,Aeq,beq,lb,ub,nonlcon,intcon,options)
x = ga(problem)
[x,fval] = ga(___)
[x,fval,exitflag,output] = ga(___)
[x,fval,exitflag,output,population,scores] = ga(___)
Description:
x = ga(fun,nvars) finds a local unconstrained minimum, x, to the objective function, fun. nvars is the dimension (number of design variables) of fun.
Passing Extra Parameters explains how to pass extra parameters to the objective function and nonlinear constraint functions, if necessary.
x = ga(fun,nvars,A,b) finds a local minimum x to fun, subject to the linear inequalities A*x ≤ b. ga evaluates the matrix product A*x as if x is transposed (A*x').
x = ga(fun,nvars,A,b,Aeq,beq) finds a local minimum x to fun, subject to the linear equalities Aeq*x = beq and A*x ≤ b. (Set A=[] and b=[] if no linear inequalities exist.) ga evaluates the matrix product Aeq*x as if x is transposed (Aeq*x').
x = ga(fun,nvars,A,b,Aeq,beq,lb,ub) defines a set of lower and upper bounds on the design variables, x, so that a solution is found in the range lb ≤ x ≤ ub. (Set Aeq=[] and beq=[] if no linear equalities exist.)
x = ga(fun,nvars,A,b,Aeq,beq,lb,ub,nonlcon) subjects the minimization to the constraints defined in nonlcon. The function nonlcon accepts x and returns vectors C and Ceq, representing the nonlinear inequalities and equalities respectively. ga minimizes the fun such that C(x) ≤ 0 and Ceq(x) = 0. (Set lb=[] and ub=[] if no bounds exist.)
x = ga(fun,nvars,A,b,Aeq,beq,lb,ub,nonlcon,options) minimizes with the default optimization parameters replaced by values in options. (Set nonlcon=[] if no nonlinear constraints exist.) Create options using optimoptions.
x = ga(fun,nvars,A,b,Aeq,beq,lb,ub,nonlcon,intcon) or x = ga(fun,nvars,A,b,Aeq,beq,lb,ub,nonlcon,intcon,options) requires that the variables listed in intcon take integer values.
x = ga(problem) finds the minimum for problem, a structure described in problem.
[x,fval] = ga(___), for any previous input arguments, also returns fval, the value of the fitness function at x.
[x,fval,exitflag,output] = ga(___) also returns exitflag, an integer identifying the reason the algorithm terminated, and output, a structure that contains output from each generation and other information about the performance of the algorithm.
[x,fval,exitflag,output,population,scores] = ga(___) also returns a matrix population, whose rows are the final population, and a vector scores, the scores of the final population.
Program:
%Code for Finding Global Maxima

clear all
close all
clc

%Defining our search space
x = linspace(0,0.6,150);
y = linspace(0,0.6,150);
num_spaces = 50;

%Creating 2-d array
[xx,yy] = meshgrid(x,y)

%Calculating the Stalagmite Function
for i = 1:length(xx)
    for j = 1:length(yy)
        input_vector(1) = xx(i,j);
        input_vector(2) = yy(i,j);
        f(i,j) = stalagmite(input_vector);
    end
end

%For unbounded conditions
tic
for i=1:num_spaces
    [results,fopt(i)]=ga(@stalamite,2)
    xopt(i)=results(1)
    yopt(i)=results(2)
end
study_time1=toc
figure(1)
subplot(2,1,1)
surf(x,y,-f)
shading interp
hold on
plot3(xopt,yopt,-fopt,'marker','o')
subplot(2,1,2)
plot(-fopt)
xlabel('iteration')
ylabel('function maximum')

%For bounded conditions
tic
for i = 1:num_spaces
    [results,fopt(i)]= ga(@stalagmite,2,[],[],[],[],[0;0],[0.6;0.6])
    xopt(i)=results(1)
    yopt(i)=results(2)
end
study_time2=toc
figure(2)
subplot(2,1,1)
surf(x,y,-f)
shading interp
hold on
plot3(xopt,yopt,-fopt,'Marker','o')
subplot(2,1,2)
plot(-fopt)
xlabel('iteration')
ylabel('function maximum')

%Study based on increased initial population
tic
options = optimoptions('ga')
options = optimoptions(options,'populationsize',250)
for i = 1:num_spaces
    [results,fopt(i)]= ga(@stalagmite,2,[],[],[],[],[0,0],[0.6;0.6],[],[],options)
    xopt(i)=results(1)
    yopt(i)=results(2)
end
study_time3=toc
figure(3)
subplot(2,1,1)
surf(x,y,-f)
shading interp
hold on
plot3(xopt,yopt,-fopt,'marker','o')
subplot(2,1,2)
plot(-fopt)
xlabel('iteration')
ylabel('function maximum')
Program Explanation:
Code Explanation:
clear all
close all
clc
%Defining our search space
x = linspace(0,0.6,150);
y = linspace(0,0.6,150);
num_spaces = 50;
The value of x and y are given using the linspace command form 0 to 0.6. The number of iterations are given using the linspace command.
%Creating 2-d array
[xx,yy] = meshgrid(x,y)
%Calculating the Stalagmite Function
for i = 1:length(xx)
for j = 1:length(yy)
input_vector(1) = xx(i,j);
input_vector(2) = yy(i,j);
f(i,j) = stalagmite(input_vector);
end
end
For plotting a 3-d surface we need the 2-d variables of x and y. For that meshgrid command is used. The values are stored in a variable called input_vector which can be used when calling the function. The function file for the stalagmite in created seperately and the function is called.Here we take the output as -f since ga only minimizes the given function so if -f is considered it gives us the maxima.
tic
for i=1:num_spaces
[results,fopt(i)]=ga(@stalamite,2)
xopt(i)=results(1)
yopt(i)=results(2)
end
study_time1=toc
figure(1)
subplot(2,1,1)
surf(x,y,-f)
shading interp
hold on
plot3(xopt,yopt,-fopt,'marker','o')
subplot(2,1,2)
plot(-fopt)
xlabel('iteration')
ylabel('function maximum')
Now for our first study using unbounded initial conditions the number of iterations is given using the num_spaces the ga is used to calculate the maxima of the function. We store the maxima into results and fopt which contain the value at which the maxima is obtained.The results were stored in xopt and yopt. Now we need to plot the surface of x,y,-f to obtain the 3-d plot.The plot 3 command is used to plot the optimum maximas.The fopt function is also being plotted to visualize the function at each iteration. The tic and toc command is used to record the time taken to complete the cycle.
tic
for i = 1:num_spaces
[results,fopt(i)]= ga(@stalagmite,2,[],[],[],[],[0;0],[0.6;0.6])
xopt(i)=results(1)
yopt(i)=results(2)
end
study_time2=toc
figure(2)
subplot(2,1,1)
surf(x,y,-f)
shading interp
hold on
plot3(xopt,yopt,-fopt,'Marker','o')
subplot(2,1,2)
plot(-fopt)
xlabel('iteration')
ylabel('function maximum')
Now for our second study using bounded initial conditions the number of iterations is given using the num_spaces the ga is used to calculate the maxima of the function. We store the maxima into results and fopt which contain the value at which the maxima is obtained.The results were stored in xopt and yopt. Now we need to plot the surface of x,y,-f to obtain the 3-d plot.The plot 3 command is used to plot the optimum maximas.The fopt function is also being plotted to visualize the function at each iteration. The tic and toc command is used to record the time taken to complete the cycle.
tic
options = optimoptions('ga')
options = optimoptions(options,'populationsize',250)
for i = 1:num_spaces
[results,fopt(i)]= ga(@stalagmite,2,[],[],[],[],[0,0],[0.6;0.6],[],[],options)
xopt(i)=results(1)
yopt(i)=results(2)
end
study_time3=toc
figure(3)
subplot(2,1,1)
surf(x,y,-f)
shading interp
hold on
plot3(xopt,yopt,-fopt,'marker','o')
subplot(2,1,2)
plot(-fopt)
xlabel('iteration')
ylabel('function maximum')
To set a initial population we need to use a command called optimum option to increase our population size from 50 to 250.Now for our third study we are increasing out initial conditions of the population and the number of iterations is given using the num_spaces the ga is used to calculate the maxima of the function. We store the maxima into results and fopt which contain the value at which the maxima is obtained.The results were stored in xopt and yopt. Now we need to plot the surface of x,y,-f to obtain the 3-d plot.The plot 3 command is used to plot the optimum maximas.The fopt function is also being plotted to visualize the function at each iteration. The tic and toc command is used to record the time taken to complete the cycle.
Stalagmite function:
function A = stalagmite(input_vector)
x = input_vector(1);
y = input_vector(2);
f1 = (sin(5.1*pi*x+0.5)).^6;
f2 = exp((-4*log(2)*((x-0.0667).^2))/0.64);
f3 = (sin(5.1*pi*y+0.5)).^6;
f4 = exp((-4*log(2))*((y-0.0667).^2)/0.64);
A =-(f1*f2*f3*f4);
end
The function is stored under a varaible called A . The x and y are assigned as input vectors. The f1,f2,f3 and f4 are governing equations for the stalagmite function.
Output:
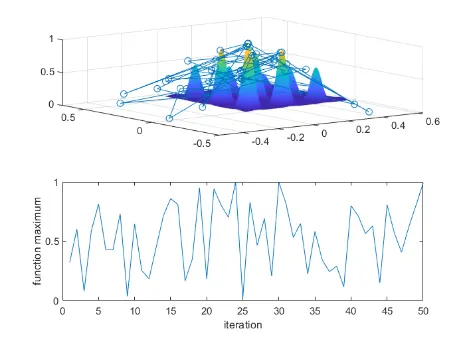
From the graph we can see that the optimal values of x and y falling away from the stalagmite surface. In this case we failed to reach the global maxima and the total time taken to complete the cycle was about 2.50sec.
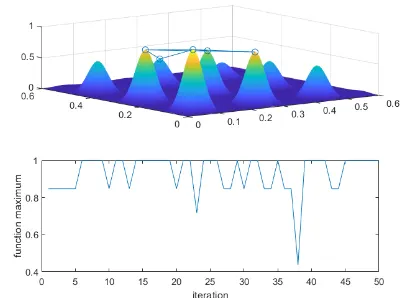
From the output obtained we can see that the optimum values falls within the limits but it could not give us the exact optimum value and the time it took was longer than the previous study(3.46sec).
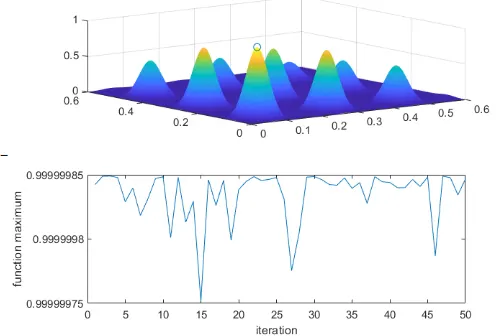
In this plot we were able to achieve the global maxima. So we know that when the population is increased the accuracy of the ga gets better. But the study was more than the previous two conditions(11.986sec).
Errors:
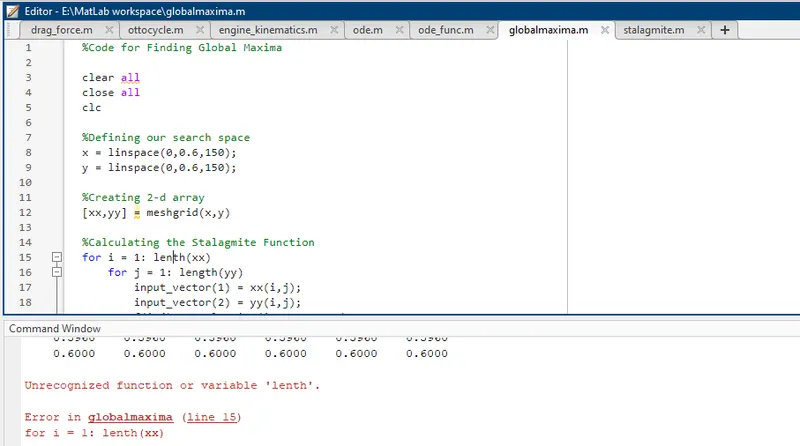
Did a typeover here and got the displayed errror.
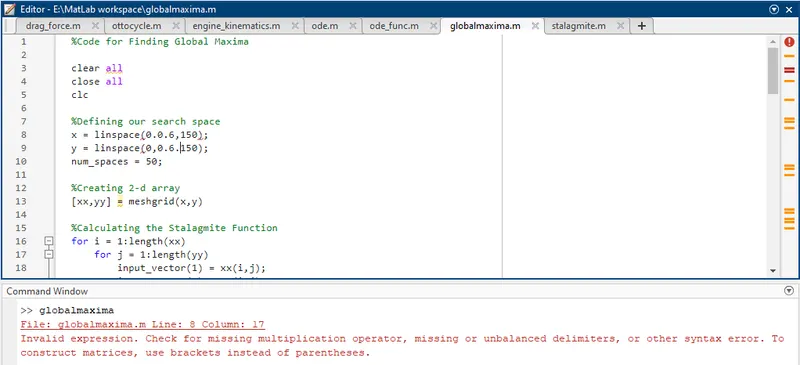
Usage of dot(.) instead of comma(,) in the linspace command and got the following error and then rectified it.
Conclusion:
Thus we have optimised the stalagmite function and found out the global maxima of the function using genetic algorithm.