Week 3 - Solving second order ODEs
AIM: To write a program in MATLAB that solves the following ODE. This ODE represents the equation of motion of a simple pendulum with damping
In the above equation,
g = gravity in m/s2,
L = length of the pendulum in m,
m = mass of the ball in kg,
b=damping coefficient.
INPUTS
L=1 metre,
m=1 kg,
b=0.05.
g=9.81 m/s2.
time = 0-20 sec,
for angular displacement=0,angular velocity=3 rad/sec at time t=0.
Procedure:
- Since the given problem represents a second order differential equation, converting this 2nd order ODE into 1st order ODE by following below steps
theta = theta1
`(d theta)/ dt` = `(d theta_1)/dt`
`(d theta_1^2)/dt^2 = (d theta_2)/dt`
CODE:
clear all
close all
clc

%INPUTS
b = 0.05; %damping coefficient
g = 9.81; %gravity
l = 1; %length of pendulum
m = 1;  %mass of pendulum

%intial condition
theta_t = [0;3];

%time points
t_span = linspace(0,20,100);
%---------------------------------------------------------------------------------------------------------
%solving ode
[t, results] = ode45(@(t,theta) ode_func(t,theta,b,g,l,m), t_span, theta_t);

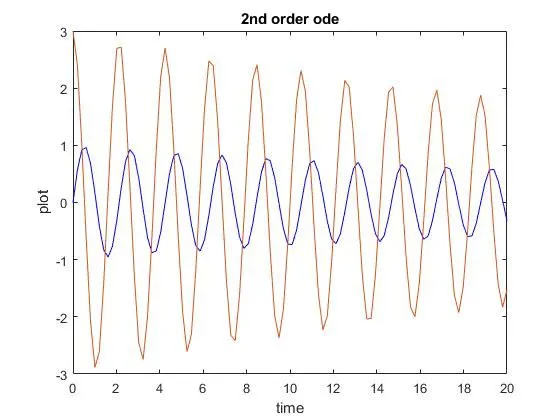
plot(t,results(:,1),'b')
hold on
plot(t,results(:,2))
ylabel ('plot')
xlabel('time')
title('2nd order ode')

%--------------------------------------------------------------------------------------------------------------
%animation
ct =1;
theta_1 = results(:,1);
for i =1:length(theta_1)
   %starting co-ordinates
    x0 = 0 ;
    y0 = 0;

    %end co-ordinates
    theta_2 = theta_1(i);
    x1 = l*sin(theta_2);
    y1 = -1*cos(theta_2);

    %------------------------------------------------------------------------------------------------------
    figure(2)
   %Pendulum bob
    plot([x0 x1], [y0 y1], 'o','MarkerSize',10,'MarkerFaceColor','r','MarkerEdgeColor','b','linewidth',5)
    hold on


   %defining axis
    axis([-2 2 -2 2])


   %string of pendulum
    line([x0 x1], [y0 y1], 'linewidth',4,'color','r')
    hold on


    %Support for pendulum / base for pendulum
    plot([-1 1], [0 0], 'linewidth',5,'color','[0 0.3 0]')
    title ('Pendulum')
    M(ct) = getframe(gcf)
    hold off
    ct =ct+1;

end
%-------------------------------------------------------------------------------------------------------------
%Creating movie
movie(M)
video_file= VideoWriter('Pendulum_challenge.avi', 'uncompressed AVI');
open(video_file)
writeVideo(video_file,M)
close(video_file)- Here we make use of inbuilt ode45 function to convert the 2nd order ODE into 1st otder ode
Program for ODE function:
function [dtheta_dt] = ode_func(t,theta,b,g,l,m)

theta1 = theta(1)
theta2 = theta(2)
dtheta1_dt = theta2;
dtheta2_dt = -(b/m)*theta2-(g/l)*sin(theta1);
dtheta_dt = [dtheta1_dt; dtheta2_dt];
end
RESULTS:
- The animation video is uploaded in google drive and link to acces it is attached below.
https://drive.google.com/file/d/15MeQ9VDthU0M0rfZ-pPG2HzUd6DEFQEG/view?usp=sharing
ERRORS FACED:
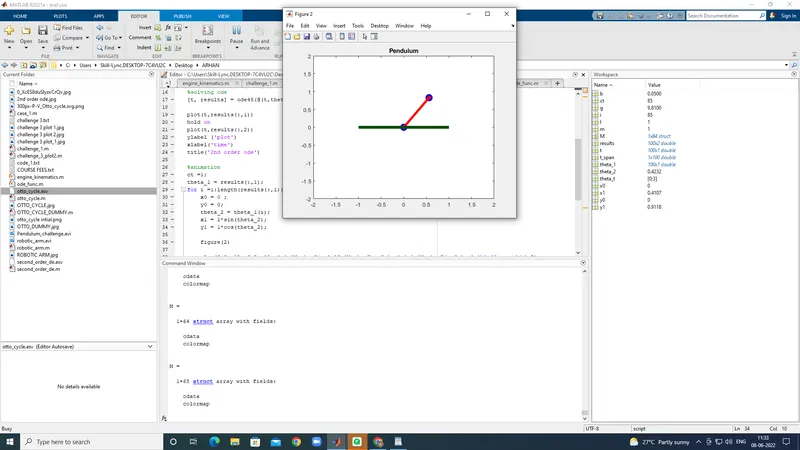
- Pendulum was moving in opposite direction, this error was corrected by including negative sign in y1
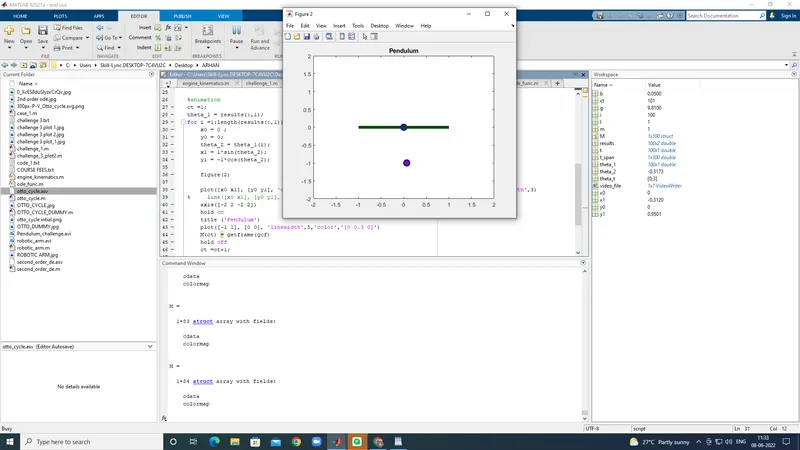
- Forgot to add the string this error was corrected by including command plot for string of pendulum
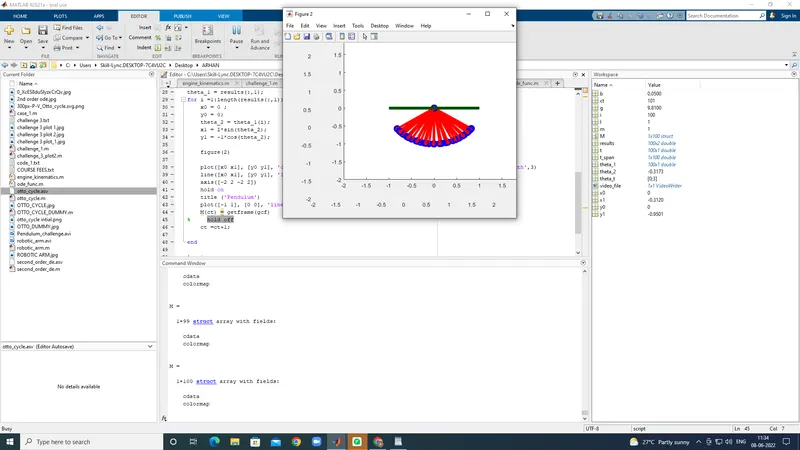
- Pendulum was continuosly swinging , this error was corrected by including hold off command.
Conclusion:
- MATLAB code to solve the ODE is succesfully compiled.
- This ODE represents the equation of motion of a simple pendulum with damping and the animation is succesfully created