Week 3 - Solving second order ODEs
%inputs
clear all
close all
clc

%length
L=1 ;
%mass
m=1 ;
%damping coefficient
b=0.05;
%gravity
g=9.81

%initial
theta_0=[0;3];
t_span = linspace(0,20,500);

[t,results] = ode45(@(t,theta) ode_func(t, theta,b,g,L,m),t_span, theta_0);

%plot
plot(t, results(:,1))
hold on
plot(t, results(:,2))
xlabel('time')
ylabel('plot')

%create animation
ct =1 ;
theta_1 = results(:,1)

for i=1:length(results(:,1))
    theta_2 = theta_1(i);
    x0=0
    y0=0

    %pendulum side coordinates
    x1= 1*sin(theta_2);
    y1= -1*cos(theta_2);

    %plotting
    figure(2)
    plot([-1,1],[0,0],'LineWidth',4,'Color','r');
    hold on
    line([x0,x1],[y0,y1],'linewidth',3,'Color','g');
    hold on
    plot(x1,y1,'Marker','o','markersize', 20,'markerfaceColor','b');
    axis([-2 2 -2 2]);
    pause(0.03)
    hold off
    M(ct)= getframe(gcf);
    ct=ct+1
end

%movie
movie(M)
videofile= VideoWriter('Pendulum.AVI','Uncompressed AVI');
open(videofile)
writeVideo(videofile,M)
close(videofile)

FUNCTION CODE-
function [dtheta_dt] = ode_func(t,theta,b,g,L,m)
         theta1= theta(1)
         theta2= theta(2)
         dtheta1_dt = theta2
         dtheta2_dt = -(b/m)*theta2 - (g/L)*sind(theta1)
         dtheta_dt = [dtheta1_dt; dtheta2_dt]
end
Graph-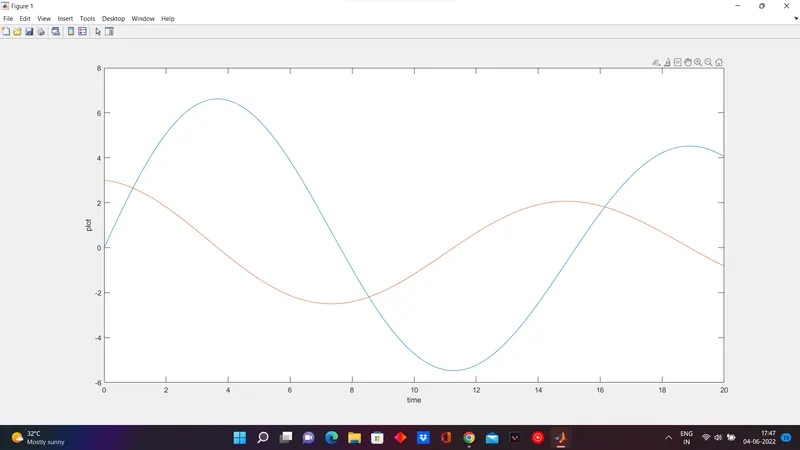
Code explanation
determine initial conditions
use function code for dtheta_dt and using ode45
plotting the results of 20 seconds
determine start and end length of pendulum in the for loop for creating the animation
plotting the pendulum
using getframe to capture each frame
creating the animation in movie form.
youtube link-https://youtu.be/2PydxoBi6QI
errors faced
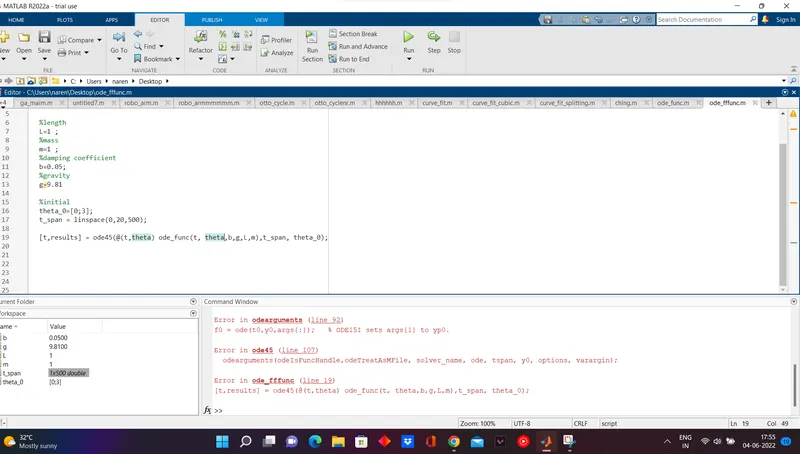
defined wrong variable name in function file, then corrected
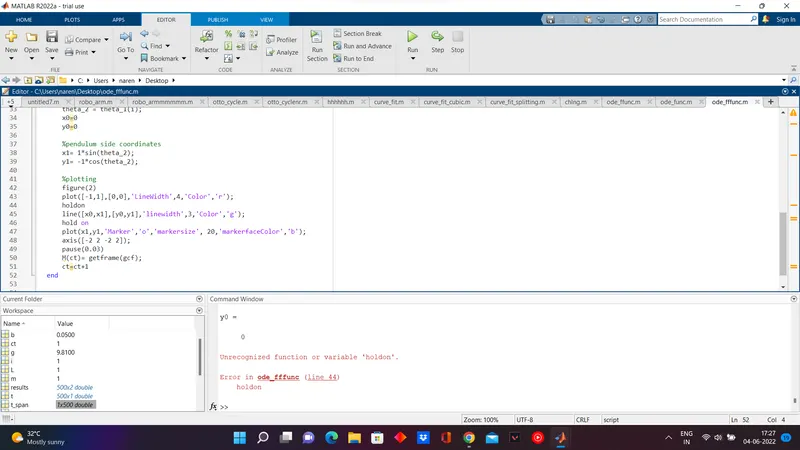
space between holdon