Week 2- 2R Robotic Arm Challenge
Report- ANIMATION LINK-https://youtu.be/hLYBvvchNIY
CODE EXPLANATION
1) using linspace for getting 10 values of theta1 and theta2 between angles 0-90
2)using for loop and providing i with values 1 to 10 as theta has 10 values
3)using another for loop so we get 10 values for both thetas and hence get a combination of 100 positions of the manipulator.
4)getting values for x0 y0 x1 y1 x2 y2
5) plotting on graph
6)saving each frame in M
7)making the animation smooth like a movie.
ERRORS-
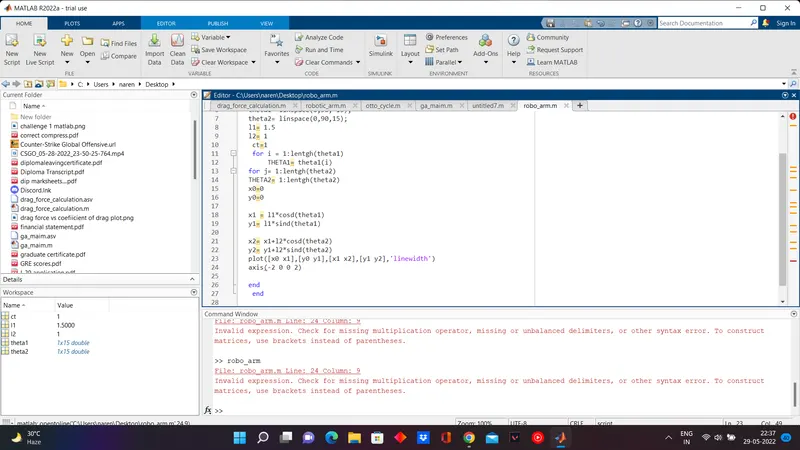
used brackets instead of parentheses
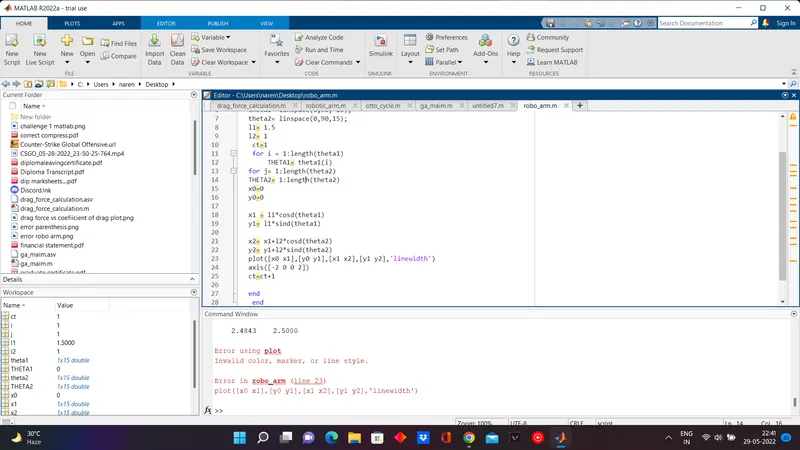
specified linewidth.
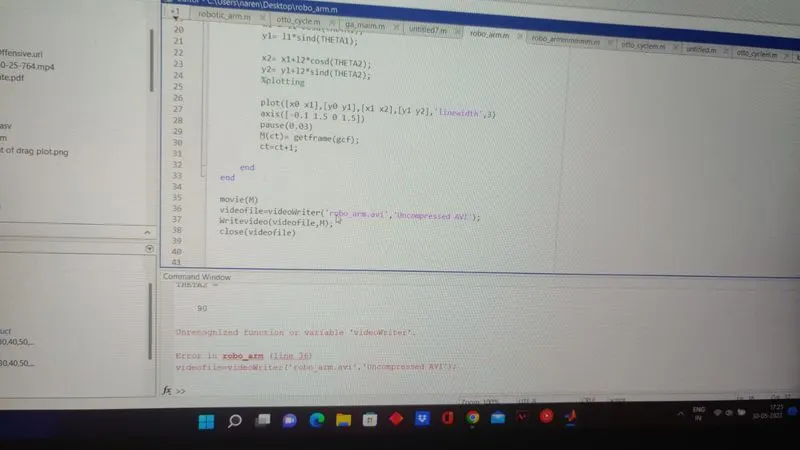
used capital V in videowriter.
clear all
close all
clc

%inputs
theta1= linspace(0,90, 10);
theta2= linspace(0,90,10);
l1= 1;
l2=0.5;
ct=1;

for i = 1:length(theta1)
    THETA1= theta1(i);
    for j= 1:length(theta2)
        THETA2= theta2(j);
        x0=0;
        y0=0;

        x1 = l1*cosd(THETA1);
        y1= l1*sind(THETA1);

        x2= x1+l2*cosd(THETA2);
        y2= y1+l2*sind(THETA2);
        %plotting

        plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
        axis([-0.1 1.5 0 1.5])
        pause(0.03)
        M(ct)= getframe(gcf);
        ct=ct+1;

    end
end

movie(M)
videofile= VideoWriter('forward_kinematics.avi','Uncompressed AVI');
open(videofile)
writeVideo(videofile,M);
close(videofile)