Week 3 - Solving second order ODEs
AIM
To write a program to solve second order differential equation(ODE) for simple pendulum using ODE45 solver in Matlab
OBJECTIVES
1) To define intial conditions for initial displacement and velocity
2) To specify the time limits for calculus derrivations
3) To create a seperate program for defining derrivative equations calling out in ODE syntax
4) Calling a loop for tracing out a frames of every instance of a pendulum for a given limit of time
EQUATION & SOLVING
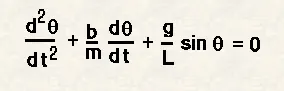
Where,
g= Gravity in m/s²
l=length of Pendulum in m
m=mass of the ball in kg
b=damping coefficient
INPUTS
Damping coefficients,b=0.005
Gravity,g=9.81m/s²
Mass of the Pendulum = 1kg
Length of Pendulum = 1m
SIMULATIONAL PARAMETERS
Time limits = 0 to 20 sec
Angular Displacement = 0
Angular Velocity = 3 rad/sec at 0th second
EQUATION BREAKDOWN AND SUPPORT FUNCTION
function [dtheta_dt] = ode_func(t,theta,b,g,l,m)

theta1=theta(1)
theta2=theta(2)
dtheta1_dt=theta2
dtheta2_dt=-(b/m)*theta2-(g/l)*sin(theta1)
dtheta_dt=[dtheta1_dt; dtheta2_dt]

end
SYNTAX OF THE PROGRAM
clear all
close all
clc

%Inputs
b=0.05;
g=9.81;
l=1;
m=1;

%initial condition
theta_0=[0;3];

%time points
t_span=linspace(0,20,500);

%ODE Solver
[t, results] = ode45(@(t,theta) ode_func(t, theta, b,g,l,m),t_span,theta_0);

a=results(:,1)
ct=1

for c=1:length(a)
    k=a(c)
%coordinates
x0=0
y0=0
%formula for locating pendulum ball position polar coordinate system
x=l*sin(k)
y=l*cos(k)

%As the pendulum swings downwards, converting from positive to negative
%values for graphical representation
x1=-x
y1=-y

%plotting
figure(1)
plot([x0 x1],[y0 y1],'linewidth',3)
hold on %to hold the pendulum line
plot(x1,y1,'marker','.','markersize',25) %to represent Pendulum Ball
axis([-2 2 -2 2])
pause(0.03)

M(ct)=getframe(gcf); %to get current frame in M(ct)
ct=ct+1; %incrementing to avoid overwritting the frame in same variable

hold off %to ensure the position of the Ball is not carry forwarded to next frame
end

movie(M) %for creating film using frames stored in M(ct)
videofile = VideoWriter('Pendulum.avi','uncompressed AVI') %defining the format to be stored
open(videofile) %opening the video file
writeVideo(videofile,M) %writting the frames
close(videofile)
OUTPUT OF THE PROGRAM
Video Link - https://youtu.be/g20yGfehG4U
While Running
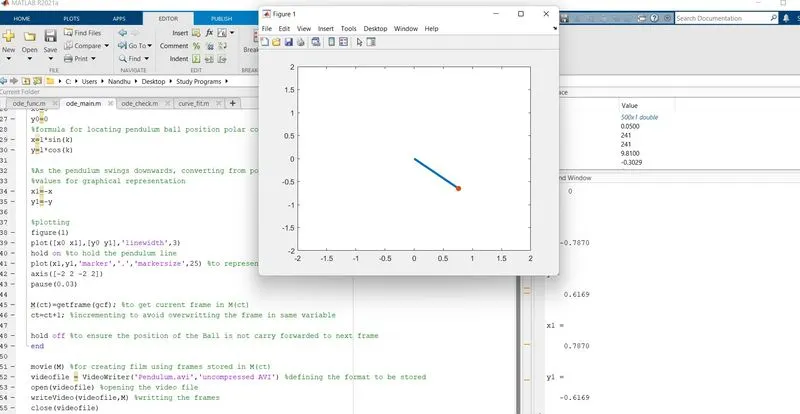
CONCLUSION
Here we had found how to breakdown and solve Differential equation.