Week 3.2 - 2R Robotic Arm Challenge
Report on 2R Robotic Arm
Aim:
- To write a program in Matlab to simulate the forward kinematics of a 2R Robotic Arm.
- To create an animation file of the plot.
Software used: MATLAB.
Code:
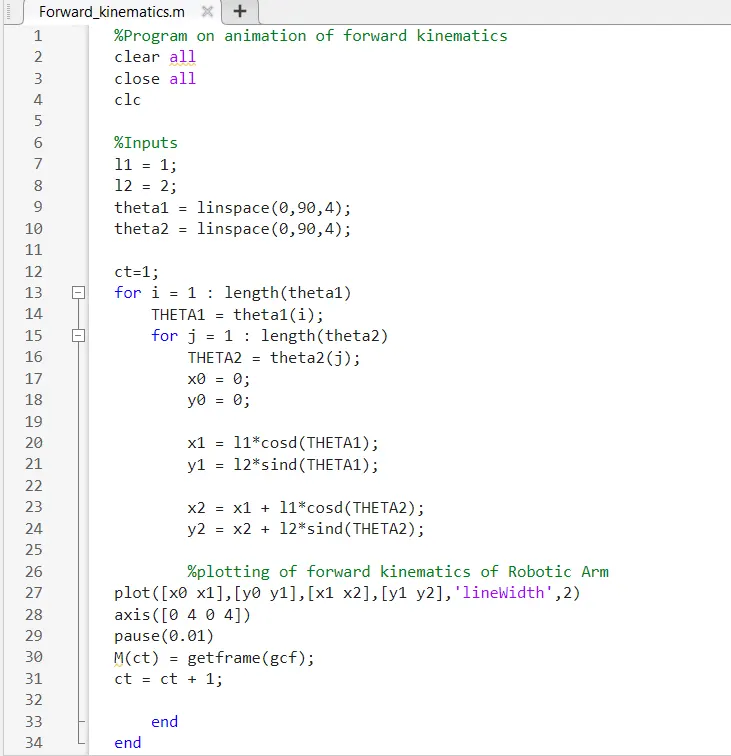
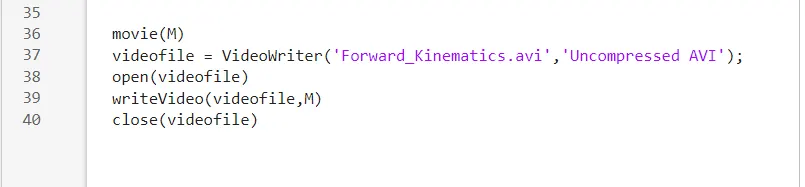
Explanation:
- l1 and l2 define the lengths of the two robotic arm segments.
- Theta 1 and Theta 2 are the joint angles.
- ct is frames.
- For Loop is used for different values of joint angles.
- x0,y0 are robot arm is at the origin.
- x1,y1 are the first position of the link.
- x2,y2 are the second position of the link.
- plot the graph of links using plot() command.
- axis() command used to limit the axeses.
- speed of the robotic arm is controlled using pause command.
- frame is captured using getframe(gcf) command.
- movie(M) command is used to play the movie.
- video file named Forward_Kinematics.avi is created.
Result:
You tube link for an animation - https://youtu.be/hV59rqGAAaE?si=YqZnc7jMFvPwnfRY .