Week 2:- BiW Fixture Basics Challenge
1. What is the process of project execution activity?
Project activities are those basically being processed or being practiced in general projects of BIW begins. Project activities are tasks from the start to the end of the project. There are various steps involved in the project. Below fig. shows a flow chart of project activities.
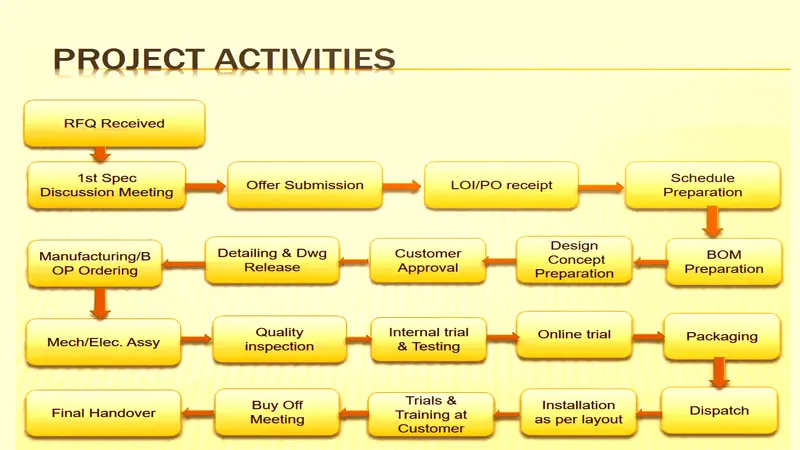
1)RFQ received: This is the first step in any project. RFQ stands for Request for Quotation. In this customer specifies his requirements, specifications, etc. in the form of documents or data. Also, the customer specifies its Technical offer, commercial offer, how the project will be executed & timeline to complete the project in it.
2) 1st spec discussion & offer submission: In this the documents related to the technical offer, commercial offer, project execution, and Timeline required to complete the project are prepared. The time required for 3D design, Analysis of design, drawing & detailing, manufacturing, Assembly & commissioning, etc. is considered. Then the cost of all the operations is also considered. By considering these kinds of things the offer is prepared & submitted to the customer.
3) LOI/PO Receipt: The customer will study the offer submitted. He will also take quotations from others. The customer will study all the offers, compare offers & then select one offer which suits him best. The customer will generate po means a Purchase order to start the work.
4) Schedule preparation: After receiving the PO the project officially starts. The timeline is fixed so there should be a plan to beat the deadline & to complete the project. All the activities step by step are taken into account like po receipt, 1st meeting, design date analysis, 3D design preparation & simulation, etc. The time required to finish the individual activity is calculated. By calculating all the steps the total time required is calculated. It should beat the timeline & if not then modifications are done in a schedule to beat the timeline of the project. We should have some backup plan for this Because due for some reason our tasks are not completed on a fixed date or the next task is dependent on the previous task.
5)BOM preparation: Bill of material is prepared for the project like the BO parts, grippers, cylinders, motors, etc. which are required.
6) Design concept preparation: The customer gives data or the specifications for the design. Based on that data design process is started which fulfills all the customer requirements.
7) Customer approval: After designing the concept the approval of the customer is required. The customer checks whether the design fulfills the requirements or not according to the technical offer. If yes the customer gives approval for the design or the customer will also ask for some addition or changes in the design. By doing the necessary changes final approval is taken from the customer.
8) Detailing & DWG release: After the approval from the customer DWG is released which shows the detailed specifications of all the parts required. Like dimensions, Qty, Specifications, etc.
9) Manufacturing BOP ordering: The BO parts like motors, cylinders, sensors, grippers, etc. required for manufacturing are ordered as per the design specifications.
10) Mechanical/ Electrical assembly: Once the parts are received they go for the prior Quality control checking. In this, all the parts are checked as per the specification. After QC checking the Mechanical or electrical assemblies are prepared as per the design.
11)Quality inspection: After the assembly again the quality is checked. In this, all the dimensions, positional accuracy, and Coordinates are checked by using a CMM machine.
12) Internal trial & testing & online trial: After the QC check internal trials are taken to check whether the fixture can do the operation or not for what it is designed. The simulation is done for this purpose at an early stage. In this, the fixture is checked for the clamping of the part, welding, proper loading & unloading of the part, etc.
After this online trial is taken in which all the operations are done in automated mode by using electrical connections. The process sequence is checked as per the defined way in design in automated mode. The customer is also involved in the online trial for taking approval.
13) Packaging & dispatch: The assemblies are packed in a proper manner. Because in transportation the fixture will be damaged hence it distorts the geometry of the fixture & also the functionality of the fixture. Hence proper packaging is very important. Once the packaging is done the fixture is dispatched to the customer's address.
14) Installation as per layout: The layout is the space defined for the parts like fixtures, robots, etc, according to the functionality, application, process sequence, etc. The layout is done at a very initial level & according to that installation is done.
15) Trials & training at the customer: Production trials are taken at the customer's end. In the technical offer, we have specified the quality benchmarks for the fixture, the capability of the fixture for production, etc. The trials are taken to check the capability of the fixture. Once it is done then training is given to the operator, staff & engineer for the process sequence, how the fixture works, loading & unloading of the part, etc.
16) Buy-off meeting & Final handover: After production trial & training Customer checks whether all the prescribed things in the offer are done or not. Sometimes customers want some additional work also, so according to the requirement all the points are closed & after that project is finally handovers to the customer.
2. What are the types of joining processes?
Joining Processes are the processes that are used for joining metal parts. Also defined as the joining of two metal parts either temporarily or permanently with or without the application of heat or pressure.
There are many joining processes used in BIW like welding, and gluing.
The durability and performance of any structure largely depend on the quality & design of component joints. The whole structure can’t be made in one piece. Two fundamental options for joining material & components.
- Metallurgical joining
- Mechanical joining.
1. Metallurgical joining: In welding two or more parts are heated & melted or forced together, causing the joined parts to function as one. In some welding methods, filler material is added to make the merging of materials easier.
Metallurgical joining includes fusion welding, pressure welding, and brazing/soldering which use different energies. There are also methods of chemical joining that use adhesives.
Different types of metallurgical joining are described below
A) Welding:
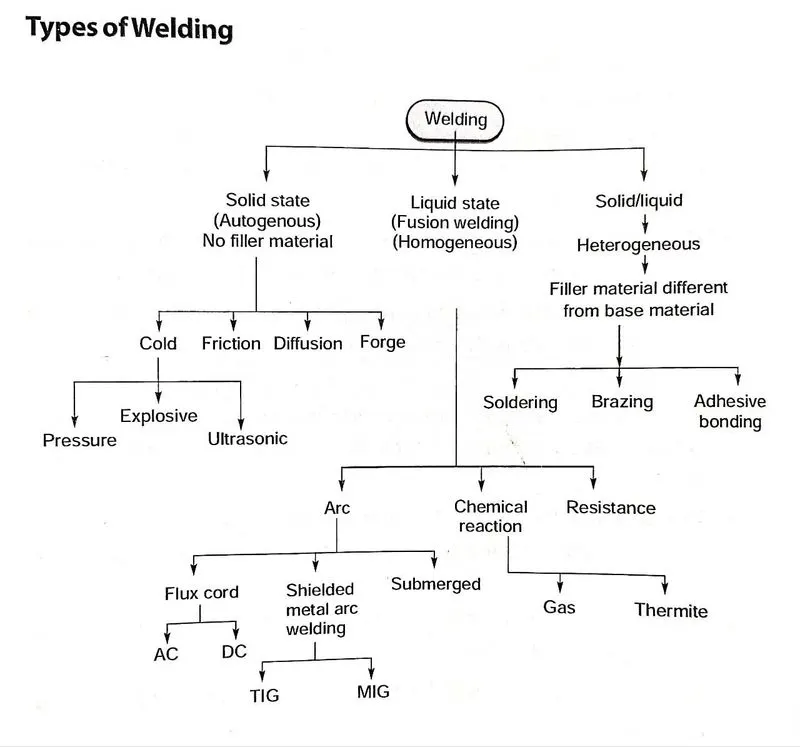
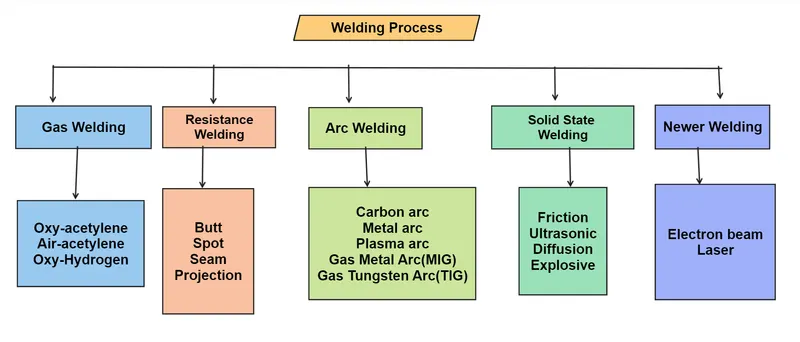
Welding is a joining process for metals wherein the workpieces to be joined as well as the welding or filler material used experience some melting. A common method for welding, known as arc welding, consists of generating an electric arc between an electrode (which contains the welding or filler material) and the workpieces to be welded together. The arc generates enough heat to melt the electrode and the areas of the workpieces where the welding is performed.
As the electrode passes over a region while the arc is present, molten metal from the electrode and molten base metal from the workpieces all get mixed together, solidifying to form a strong joint upon cooldown. The electrode contains some flux material, the purpose of which is to stabilize the arc formed by generating gases (carbon dioxide, carbon monoxide, water vapor) that shield the arc from the surrounding atmosphere.
The high temperature of the welding process alters the microstructure of the welded areas of the workpieces, i.e., these areas (known as the 'heat-affected zone' or HAZ) undergo grain coarsening at the very least. This results in a reduction of the tensile strength and toughness of the metal. Residual stresses that develop as the metal cools down also reduce the strength of the welded joints. Thus, the welding process must be optimized (by optimizing heat generation, metal compositions, and cooling rates) in order to minimize microstructural changes and residual stresses in the welded joints. Post-welding treatments are also often performed to relieve residual stresses and make the microstructure of the welds more uniform.
B) Brazing:
Brazing is a process for joining two work pieces together with a filler metal that is sandwiched between them, wherein only this filler metal undergoes melting, i.e., the workpieces do not experience any melting. The temperature at which brazing is done must therefore be high enough to melt the filler material, but not the work pieces. Materials used as fillers for brazing are those that melt above 450 deg C. Flux is also used during brazing for the purpose of eliminating oxide films from the surfaces of the workpieces and preventing oxidation. This would ensure a good metallurgical bond between the workpieces and the filler once the brazing process is completed. Once melted, the brazing material fills up the spaces between the surfaces being joined and even manages to get into tight spaces by capillary action. A strong joint is obtained after the brazing material has cooled down.
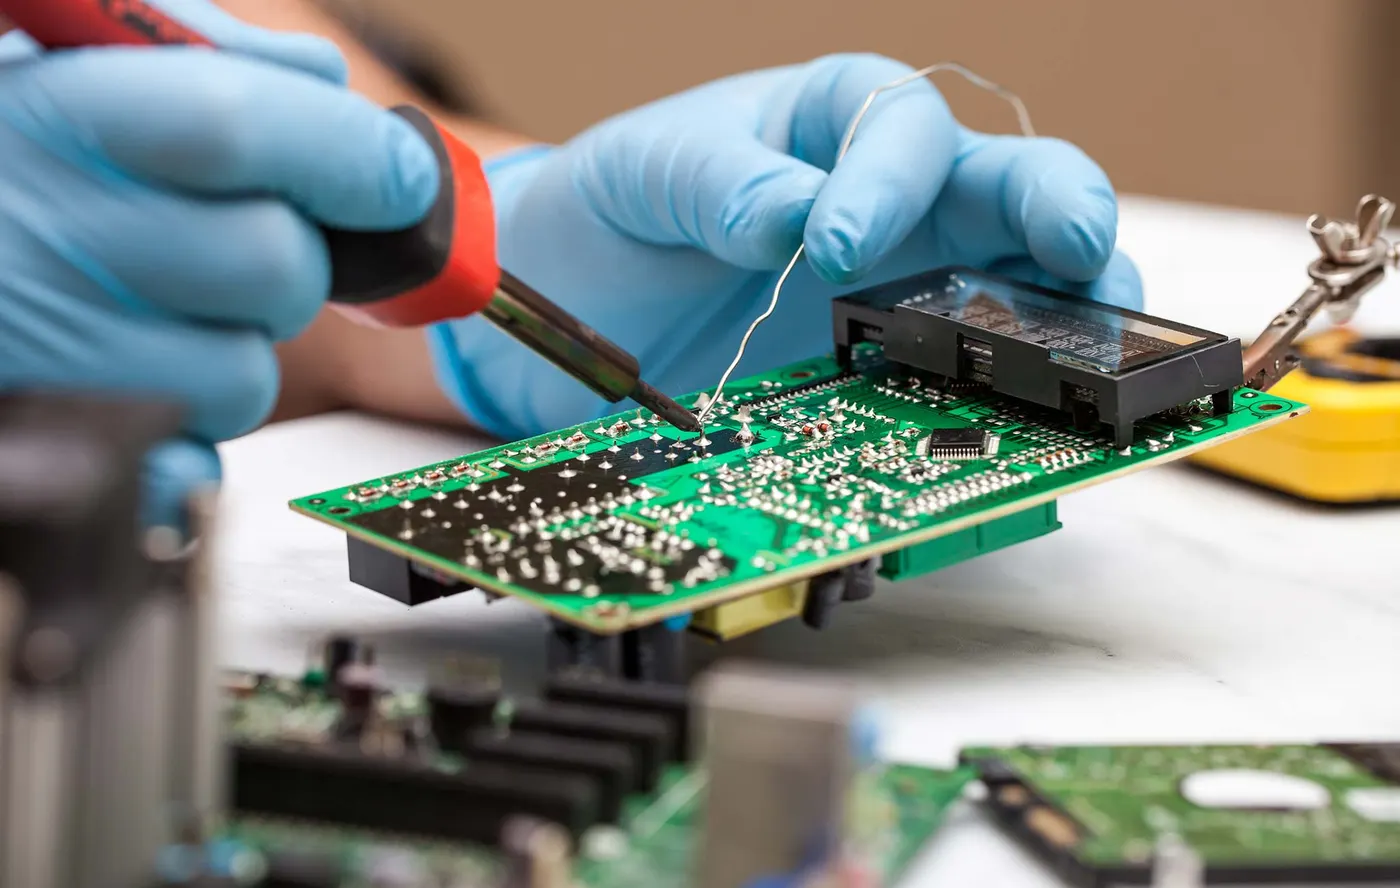
C) Soldering:
Soldering is a joining process that's similar to brazing, except that it is performed at much lower temperatures than brazing. Thus, soldering is also a process of joining two work pieces together with a filler metal, such that only this filler metal undergoes melting, i.e., the workpieces do not experience any melting. Brazing materials are those that melt above 450 deg C, so soldering materials would be those that melt at less than 450 deg C.
Common soldering materials include tin-lead, tin-zinc, lead-silver, and cadmium-silver alloys. Like welding and brazing, soldering also employs flux materials to clean the surface to be soldered and improve metallurgical bonding. Residues from fluxes, however, must be removed after soldering to reduce the risk of the occurrence of corrosion.
D) Adhesive Bonding:
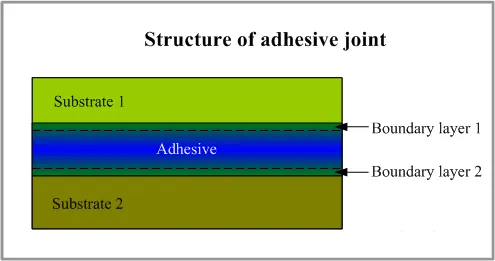
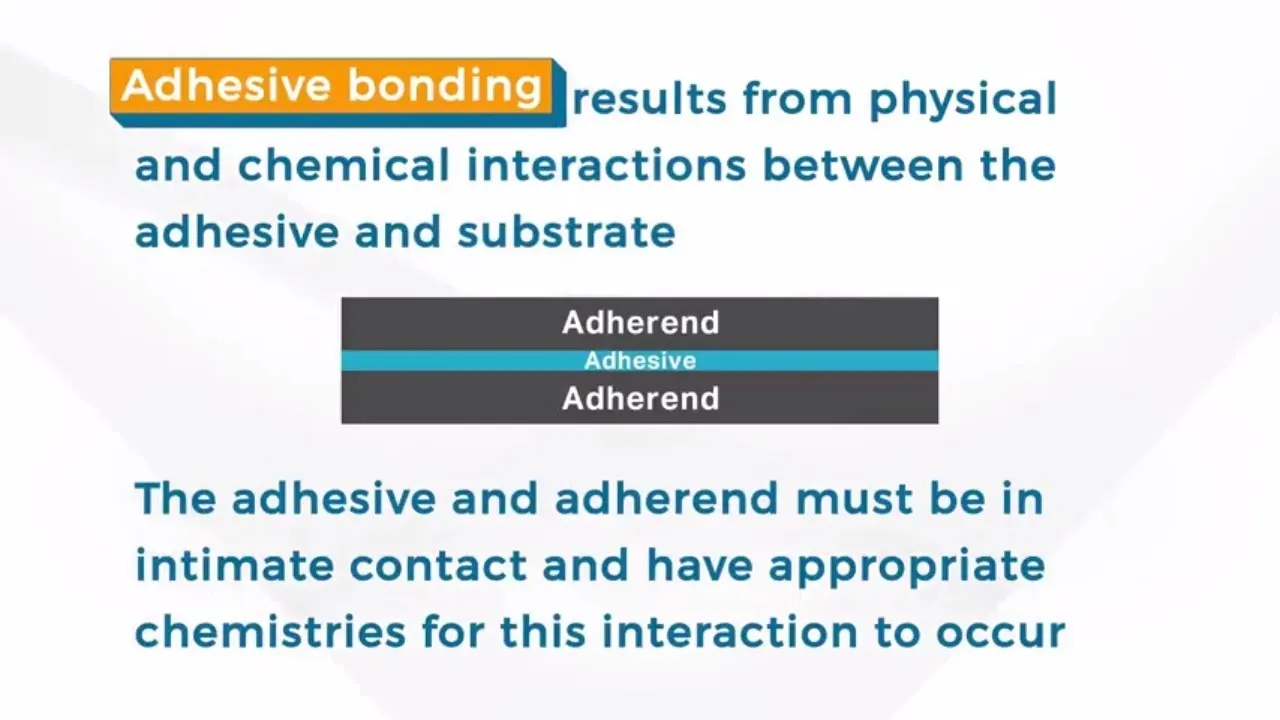
Adhesive Bonding is a process for joining parts using bonding chemicals or materials known as adhesives. It is employed to join polymers and polymer-matrix composites, as well as polymers to metals, metals to metals, and ceramics to metals. Adhesive-bonded joints can withstand shear, tensile, and compressive stresses, but they do not exhibit good resistance against peeling. To overcome the weakness of adhesive bonding against peeling, joints mated together by adhesives must have a good design, i.e., the adhesion area is maximized and mechanical interlocking is employed.
High adhesive bond strength is achieved if chemical bonds are formed between the adhesive and the base material, or adherent. However, compared to welding, brazing, and soldering, it is not easy to achieve primary bonding (ionic, covalent, and metallic) in adhesive bonds because of the relatively larger interfacial gaps between the adhesive and the adherent. Secondary bonds, which do not involve electron transfer or electron sharing but instead rely on coulombic forces of attraction, are therefore more likely to form in adhesive bonding.
To maximize adhesive bonding strength, surfaces to be joined by adhesives must be cleaned thoroughly. This, in essence, minimizes the interfacial gap between the adhesive and the adherent. Making the surfaces 'rough' also improves adhesive bond strength because of the mechanical interlocking that the 'roughness' provides.
E) Diffusion Bonding:
Diffusion Bonding, or diffusion welding, is a solid-state joining process wherein the joined parts undergo no more than a few percent macroscopic deformation. It can be accomplished at temperatures higher than half the absolute melting point of the base material. Diffusion bonding generally occurs in two stages: 1) deformation processes that result in the surfaces to be joined coming into intimate contact; and 2) formation of bonds by diffusion-controlled mechanisms such as grain boundary diffusion and power law creep. Diffusion bonding is capable of joining a vast array of combinations and sizes of metal and ceramic parts.
2) Mechanical joining:
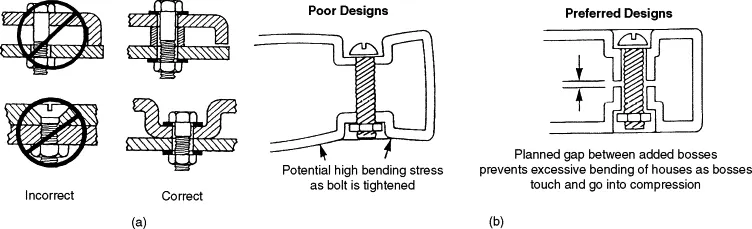
Mechanical Joining is a process of joining parts through mechanical methods, which often involve threaded holes. Joining parts using screws or nuts and bolts are common example of mechanical joining. The threaded holes employed for mechanical joining are vulnerable to fractures. In ductile materials, the fracture can come from fatigue, while in brittle materials, the fracture can simply result from mechanical overloading. Thus, mechanical joints must be designed with fatigue failure and brittle fracture in mind. Another issue to be considered when designing mechanical joints is galvanic corrosion, which is a type of corrosion that affects different types of metals that are in contact with each other.
Mechanical joining – also called joining by forming – has become interesting for the automotive industry due to the request to reduce fuel consumption and thereby emissions. In order to reduce weight on the car body, the usage of lightweight materials in the body-in-white application has increased. This includes aluminum, high-strength steel alloys, polymers, and composites. Here the different type of mechanical joining becomes important. All mechanical joining methods are cold forming techniques. One general benefit of all mechanical joining methods is the mobility of the material after joining. At the same time mechanical joining offers an impressive strength.
A)Mechanical fastening:
The joining of material combinations that cannot be easily welded such as pre-painted steel or very dissimilar metal. Ex. AI application in autobody makes use of mechanical fastening to overcome the poor inherent weldability of AI.
The joining of materials in applications where high fatigue life is critically compared to static strength.
The joining of materials where high tool life is of relative importance
E.g. screws, bolts, etc
B) Self-piercing riveting:
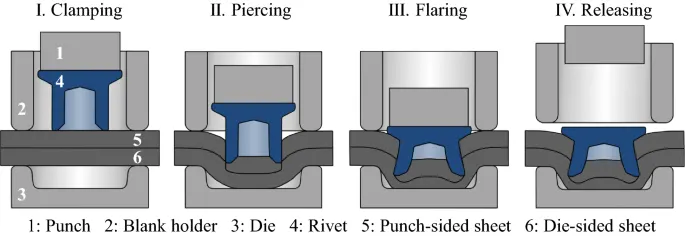
Self-piercing riveting is high-speed mechanical fastening for point-joining sheet material, typically steel & aluminum alloys. It is a single-step technique generally using a semi-tubular rivet to clinch the sheet in the mechanical joint. There is also a process variant that utilizes solid rivets.
As the name suggests pre-drilled holes are not required, allowing the joint to be made rapidly in one operation. The process cycle is shown below.
C) Hemming & seaming process:
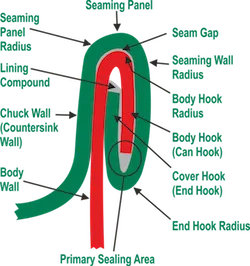
Hemming & seaming are two similar metalworking processes in which a sheet metal edge is rolled over onto itself. Hemming is a process in which the edge is rolled flush to itself, while the seam joins the edges of two materials. Hems are commonly used to reinforce an edge, hide burrs and rough edges, and improve appearance. Seams are commonly used in the food industry on canned goods, amusement cars, in metal roofing (with a roof seamer), and in the automotive industry. The process for both hemming and seaming are the same, except that the tonnage requirement is greater for seaming. The process starts by bending the edge to an acute angle. A flattening die is then used to flatten the hem. The below figure illustrates hem formation.
3. What is Resistance Welding & its application in the automotive sector?
Resistance welding:
Resistance welding is the joining of metals by applying pressure and passing current for a length of time through the metal area which is to be joined. The key advantage of resistance welding is that no other materials are needed to create the bond, which makes this process extremely cost-effective.
There are several different forms of resistance welding (e.g. spot and seam, projection, flash, and upset welding) which differ primarily by the types and shapes of weld electrodes that are used to apply the pressure and conduct the current. The electrodes, typically manufactured from copper-based alloys due to superior conductive properties, are cooled by water flowing through cavities inside the electrode and the other conductive tooling of the resistance welding machine.
Resistance welding machines are designed and built for a wide range of automotive, aerospace, and industrial applications. Through automation, the action of these machines is highly controlled and repeatable allowing manufacturers to staff production readily.
Types of Resistance Welding:
A) Spot Welding:
Resistance spot welding is widely used in BIW joining processes. The process is used for joining sheet materials & uses shaped copper chromium or zirconium alloy electrode to apply pressure & convey electrical current through the workpiece. Heat is developed mainly at the interface between two sheets, eventually causing the material being welded to melt, forming a molten pool & weld nugget. The molten pool is contained by the pressure applied by the electrode tip & surrounding solid metal. When the circuit is completed current will flow from that panel or sheet metal which will generate the amount of heat that is sufficient enough to melt that will be melted & get welded together. The molten pool should not move outside of that zone to ensure that proper pressure is applied through the electrode tip & surrounding sheet metal. Forcing a large current through the spot will melt the metal and form the weld. The attractive feature of spot welding is that much energy can be delivered to the spot in a very short time (approximately 10–100 milliseconds). That permits the welding to occur without excessive heating of the remainder of the sheet. Strength & durability largely depends on the quality of RSW. The below figure illustrates the principle of resistance welding.
The following are the advantages of resistance spot welding.
- Short weld time & hence high weld speed
- Highly adaptable to automation & robotic technique. The below figure shows a robot used in the automotive industry for spot welding. A typical BIW contains 500 welds. RSW is automated and used in the form of robotic spot welding in automotive industries to weld the sheet metals to form the car body. The below figure illustrates a typical application of spot welding using robots.
B) Seam Welding:
Resistance seam welding is a welding process for joining metal sheets in continuous, often leak-tight, seam joints by directly applying opposing forces with electrodes consisting of the rotary wheel. It differs from flash welding in that flash welding typically welds the entire joint at once and seam welding forms the weld progressively, starting at one end. The current & the heat generation are localized by peripheral shapes of the electrode wheel Seam welding is mostly applied in the manufacturing of containers radiators & heat exchangers etc. Resistance seam welding is used where leakage-proof continuous welding is required. Like spot welding, seam welding relies on two electrodes, usually made from copper, to apply pressure and current. The electrodes are often disc-shaped and rotate as the material passes between them. This allows the electrodes to stay in constant contact with the material to make long continuous welds. The electrodes may also move or assist the movement of the material. Seam welding produces an extremely durable weld because the joint is forged due to the heat and pressure applied. A properly welded joint formed by resistance welding can easily be stronger than the material from which it is formed. A common use of seam welding is during the manufacture of round or rectangular steel tubing. Seam welding has been used to manufacture steel beverage cans but is no longer used for this as modern beverage cans are seamless aluminum. In automobile industries, this welding process is used to produce leak-proof fuel tanks.
C) Projection Welding:
Like other Resistance Welding Processes, Projection Welding uses heat generated by resistance to the flow of welding current, as well as force to push the workpieces together, applied over a defined period of time. Projection Welding localizes the welds at predetermined points by using projections, embossment, or intersections, all of which focus on heat generation at the point of contact. Once the weld current generates sufficient resistance at the point of contact, the projections collapse, forming the weld nugget.
Solid Projections are often used when welding fasteners to parts. Embossments are often used when joining sheet or plate material. An example of Projection Welding using material Intersections is cross-wire welding. In this case, the intersection of the wires themselves localizes heat generation, and therefore resistance. The wires set down into one another, forming a weld nugget in the process.
It is used for mechanical fixing of Autobody structures eg. weld nut
4. What is fusion welding & types of fusion welding with its application in the automotive sector?
Fusion welding is a process that uses heat to join or fuse two or more materials by heating them to the melting point. The process may or may not require the use of a filler material. External application of pressure is not required for fusion welding processes, except for resistance welding, where substantial contact pressure is required during welding for sound joining.
Fusion welding processes can be grouped according to the source of the heat, for example, electric arc, gas, electrical resistance, and high energy.
A) Shielded Metal Arc Welding (SMAW):
Also known as manual metal arc welding (MMA or MMAW), flux-shielded arc welding, or stick welding.is a manual arc welding process that uses a consumable electrode covered with a flux to lay the weld.
An electric current, in the form of either AC or DC from a welding power supply, is used to form an electric arc between the electrode and the metal to be joined. The workpiece and the electrode melts forming a pool of molten metal that cools to form a joint. As the weld is laid, the flux coating of the electrode disintegrates, giving off vapors that serve as a shielding gas and providing a layer of slag, both of which protect the weld area from atmospheric contamination.
Because of the versatility of the process and the simplicity of its equipment and operation, shielded metal arc welding is one of the world's first and most popular welding processes. It dominates other welding processes in the maintenance and repair industry, and though flux-cored arc welding is growing in popularity, SMAW continues to be used extensively in the construction of heavy steel structures and in industrial fabrication. The process is used primarily to weld steel (including stainless steel).
B) Metal Inert Gas Welding (MIG)/ Metal Active Gas Welding (MAG):
Also known as Gas Metal Arc Welding (GMAW). MIG and MAG welding is the most common arc welding processes, in which an electric arc forms between a consumable wire electrode and the workpiece leading them to melt and join. Both use a shielding gas to protect the weld from airborne contaminants, or oxidation in the case of MIG welding.
The process can be semi-automatic or automatic. A constant voltage, Direct current power source is most commonly used with GMAW, but constant current systems, as well as AC, can be used. There are four primary methods of metal transfer in GMAW, called globular, short-circuiting, spray, and pulsed spray, each of which has distinct properties and corresponding advantages and limitations.
C) Tungsten Inert Gas Welding (TIG):
Also known as Gas Tungsten Arc Welding (GTAW). This arc process uses a non-consumable tungsten electrode to create the arc between the electrode and the base plate. An inert shielding gas is used to protect from oxidation or other atmospheric contamination.
This process can be used autogenously on thin parts but will require the addition of a wire, rod, or consumable to be added for thicker parts.
A Constant current welding power supply produces electrical energy, which is conducted across the arc through a column of highly ionized gas and metal vapors known as Plasma.
GTAW is most commonly used to weld thin sections of stainless steel and non-ferrous metals such as aluminum.
D) Plasma arc welding:
This process uses an electric arc created between an electrode and the torch nozzle. The electric arc ionizes the gas (usually argon) in the chamber creating what is called a 'plasma.' It is then forced through a fine-bore copper nozzle that constricts the arc and directs it to the workpiece, allowing the plasma arc to be separated from the shielding gas (which is usually made from a mixture of argon and hydrogen).
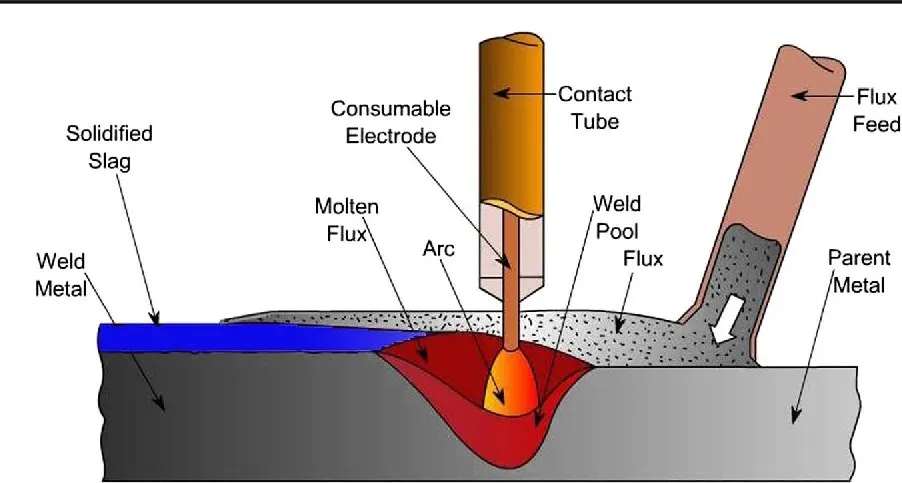
E) Submerged Arc Welding:
Submerged arc welding (SAW) can be extensively utilized within an automatic welding method. In this kind of welding process, an electrode is completely submerged by the granular coating of flux, and this flux can be an electric conductor which will not oppose the electric supply. The solid coating of flux stops the melted metal from ultra-violate radiation and the atmosphere.
Automotive application of arc welding technology:
- Arc welding is used to weld chassis parts in the automotive industry.
- Arc welding is used to weld body parts in the automotive industry. Low heat input welding of thin steel sheets prevention of burn through due to excessive heat input is important in the welding of car body parts of thin sheets. For this reason, thin welding wire with a diameter of 0.9 mm, enable welding at low currents & low heat input welding power source.
- TIG welding is used to join thin stainless steel parts & various piping parts in the automobile industry. TIG welding can work on both AC and DC power sources. One of the greatest strengths of TIG welding is that it can be used for welding non-ferrous metals like aluminum, copper, magnesium, copper, nickel, titanium, etc.
- Rebuilding: MIG welding is used for repairing work in the automobile industry. To repair especially to dismantle & reassemble with new parts. Example: to rebuild an old car. When it comes to fixing broken parts in the field, there are three steps to master: cutting & removal of the failed component, preparation of the new joint/ part, and welding & cleanup. Worn parts can be repaired using MIG welding in a variety of coatings (stainless steel, bronze, nickel, aluminum, or hard surfacing) & in a range of hardness, for a fraction of the cost of purchasing a new part.
5. What is the 3-2-1 principle?
A fundamental concern in metalworking is locating the part to be machined, punched, bent, or stamped relative to the work platform (fixture). For example, a CNC machine tool starts its process at a specific point relative to the fixture and proceeds from there. Hence, the accuracy with which a part is machined is quite dependent on the accuracy with which it is positioned in the fixture.
Accurate locating of not just one part, but each and every part that is loaded into the fixture is crucial. Any variation in part location on the fixture adds to the dimensional tolerance that must be assigned to the finished parts.
Additionally, the method of supporting and securing the part in the fixture affects not only dimensional tolerances but surface finishes as well. This is true because improper support or clamping can temporarily or permanently deform the part.
Techniques for supporting and clamping must be considered together with the method of locating in order to assure repeatability from part to part.
Locating a part to be machined is a three-step process:
1. Supporting
2. Locating (positioning)
3. Holding (clamping)
The Locating Process: Degrees of Freedom
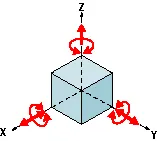
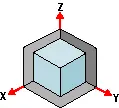
In order to completely specify the position in space of a three-dimensional
object (such as the cube that’s shown), we refer to six coordinates:
- Translational position along the X-axis
- Translational position along the Y-axis
- Translational position along the Z-axis
- Rotational position about the X-axis
- Rotational position about the Y-axis
- Rotational position about the Z-axis
These six coordinates are known as the six degrees of freedom of a three-dimensional object. As the double-headed arrows indicate, the translational and rotational positions can vary in either direction with respect to each of the three axes.
To completely prevent movement, all six degrees of freedom must be restricted.
The locating 3-2-1 Principle:
We have two objectives when mounting a part in a fixture for machining:
1. Accurately position the part at the desired coordinates.
2. Restrict all six degrees of freedom so that the part cannot move.
A widely used method of accomplishing these two objectives uses the 3-2-1 principle, so-called because it entails three steps that employ three, then two, then one fixed points of known location. Since that adds up to six fixed points, it’s also known as the six-point method.
In the three steps of the 3-2-1 method, three mutually perpendicular planes, called datum planes, are introduced, one at each step. These three planes define the workpiece position, and together with opposing clamping forces fully constrain the part. Let’s take a look at the details of the 3-2-1 method.
First Plane
Geometry tells us that three points are required to define a plane. This is the "3" in 3-2-1. So, three specific points are used to define the first plane.
Fewer than three points cannot define a plane, and in the real world dimensional tolerances mean that four or more points will not be coplanar. A real-world, less-than-ideally perfect part placed on four or more reference points will, in fact, rest on only three of the points due to its less-than-perfect surface.
Different parts may rest on different combinations of three points, resulting in variation between finished parts.
A stool can be used to illustrate this concept. A two-legged stool would certainly be unstable. A three-legged stool sits rock-solid. A four-legged stool is often found to rock.
In the illustration, a three-dimensional part, represented by a cube, is placed on a datum plane defined by three support points. The part’s six degrees of freedom have now been reduced to three. It can still move along the X or Y axes, and it can still be rotated about the Z axis. (The part cannot move along the Z axis because it is held against the plane by clamping force.
TIPS
- Use the largest surface of the part for the first ("primary") reference plane.
- Position the three support points as far apart as possible.
- If more than three support points are required to prevent deflection, make the additional points adjustable.
Second Plane
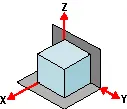
A second plane, if it is perpendicular to the first, can be defined by two points, the "2" in 3-2-1.
The part is now constrained to one degree of freedom: movement along the Y axis. (The part cannot move along the X or Z axes because it is held against the planes by clamping force.)
Third Plane
A third plane, if it is perpendicular to both of the first two planes, can be defined by one point, the "1" in 3-2-1. The part is now entirely constrained. It cannot move along or rotate about the X, Y, or Z axes. (Remember that the part is held against each of the three planes by clamping force.)
TIPS
- If more than one support point is required to prevent deflection, make the additional points adjustable.
Machined is Best
It’s best if the workpiece surfaces intended to contact the support points are machined. Cast surfaces are usable, but then tend to create tolerance problems. Machined holes are the number one choice. Two machined holes can be used to eliminate all but one degree of freedom.
Repeatability
Repeatability is a paramount concern. It means that each part should be nearly identical to the other part coming off the same fixture. "Nearly identical" actually has a specific, quantifiable meaning: key dimensions of all parts produced on the same fixture must fall within defined tolerances.
In order to stay within tolerances, it’s best if the workpiece surfaces intended to contact the support points are machined. Cast surfaces are usable, but they tend to create tolerance problems. Machined holes are the number one choice because two machined holes can be used to eliminate all but one degree of freedom.
The next best feature to use for consistent locating is machined surfaces at right angles. The "machined surface" desired here can simply be a tab or small flat specifically included for locating purposes.
Repeatability is achieved through the application of the 3-2-1 method to the three aspects of the locating process:
1. Supporting
2. Locating (positioning)
3. Holding
Supporting
- The part is supported from "below" with reference to the Z axis. (Introduction of the first reference plane.)
- Gravity positions the part against the support locator.
- Provide adjustable auxiliary support points as needed to prevent deflection.
- Vertical location with respect to the fixture is now established
- The part is positioned horizontally, in the X-Y plane. (Introduction of the second and third reference planes.)
Holding
- The part is clamped against fixed locators. Therefore, a known and unvarying position of the part is maintained with respect to the X, Y, and Z axes.
- One strap clamp or clamp arm will restrict the workpiece in three dimensions due to friction between the workpiece and clamp. However, friction alone may not be enough to prevent the workpiece from moving during machining.
- Cutting forces will not move a properly supported and clamped part.
Locating
- The part is positioned horizontally, in the X-Y plane. (Introduction of the second and third reference planes).
Summary: Clamping rules of thumb
- Define three reference planes on the workpiece and fixture.
- Provide one opposing clamping force opposite each plane to restrict movement.
- When in doubt, rely on additional cylinders to take up uncertainty.
6. Define the Body coordinate system?
BODY COORDINATE SYSTEM (Part Locating System):
The body coordinate system has been widely used in the automotive industry for drawing body parts, and product & process design. A coordinate system is a reference system consisting of a set of points, lines & surfaces, used to define the positions of points in space in either two or three dimensions. In general, BCS is also called a car line & body line.
Car lines are the (grid lines) shown on the fixture, which virtually represent the same location in BIW. All the car line on the fixture displays the coordinate at the corner for reference. With these lines, one can easily relate the location in BIW.
Sometimes a single coordinate hole is given in the fixture that also represents the car line coordinates, from that reference point fixture is made & can be inspected. Body coordinates are mentioned near the hole. The below figure shows the car line on the fixture.
Automotive sheet metal components are designed in CAD (Computer-aided Design) software e.g. CATIAv4-v5, UG, ProE, Ideas,
In any cad tool, there is a default axis system of X, Y, and Z.
Lets us consider if every designer starts the design of the BIW Door Assembly part with a default axis system, then it will be difficult to assemble or position the part with respect to each other.
Due to avoid this issue, BIW car panels are designed with reference to car axis means at their
The original position of the final car was built.
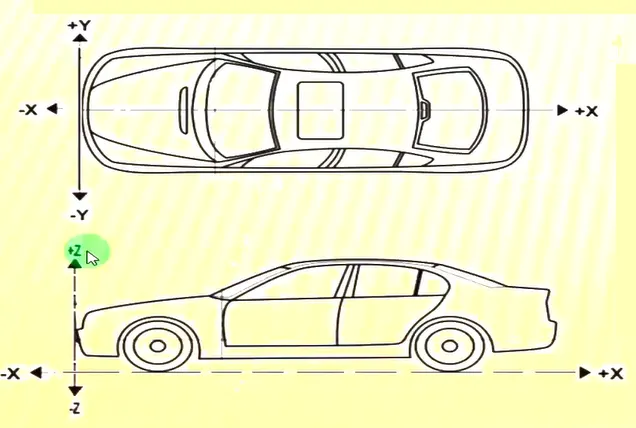
The reference axis system of the software is used for the design of the various features of the parts (e.g. hole, fillet, threads,) To correlate the position of all the automotive components during the final assembly the axis system of the vehicle is used. Most of the time vehicle axis systems and software axis systems are the same. e.g. In most European OEMs, The X-axis represents the length of the vehicle Y-axis represents the width of the vehicle Z-axis presents the height of the vehicle. Y-axis is considered to be located at the front axle. All BIW welding fixtures are designed with reference to the car line
These datum schemes provide a reference system for all part surfaces and features using body coordinates. The figure below illustrates a typical body coordinate system. This system replaces the traditional X, Y, and Z directional designations with fore/aft (X), in/out (Y), and up/down or high/low (Z). The 0,0,0 point of the car is the front, lower, and center position.
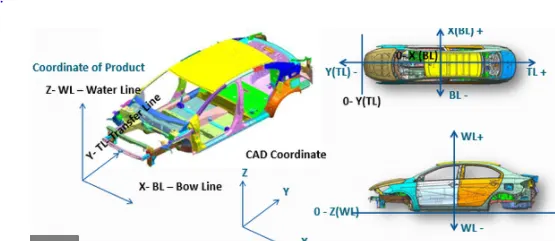
VEHICLE ORIENTATION: All vehicle product drawings are identified numerically relative to the three-vehicle planes described and shown below.
X= longitudinal direction (fore & after-F/A) or (Front O line-FOL).
Y= transverse direction (Cross car-C/C) or (Centre O line-COL).
Z= Vertical direction (Up & down- U/D) or (Bottom O Line-BOL).
The origin of the body coordinate system (OX) is defined at the front center of a vehicle. It indicates the length of the car & the coordinate system (OZ) is below its underbody indicates the height of the car & the coordinate system (OY) whose starting point is the center of the car's body indicates the width of the car.
Maintaining X, Y & Z coordinates in the fixture is a very important factor.
We should try that the coordinates of locating & clamping points should not be in three decimal (e.g. X=100.124, Y=245.127, Z=450.458)
They should be in the whole nos or max up to 1 decimal. Once these coordinates are maintained automatically the BIW base structure is maintained.
7. Elaborate Body plane system & its essentials.
Body planes are three mutually perpendicular imaginary planes. These are reference planes in automotive cars. These are used to define the GD & T of all parts in the automotive domain.
The measurement from the body plane to the parts is called body plane dimensions.
These body planes are called as
FOL Front “O” line.
COL Centre “O” line
BOL Body “O’ line
The measurement along FOL or X-axis is called F/A Front aft.
The measurement along COL or Y-axis is called a C/C Cross car.
The measurement along BOL or Z-axis is called U/DUP down.
In the below figure, the origin is somewhere below the driving sheet as it depends on or changes from customer to customer. But the axis system is commonly the same.
Bodyline dimensions are essential for below reasons
- It defines the exact position of each product in the vehicle w.r.t a fixed origin.
- It ensures flawless design for assembly.
- While designing lines, all the designs are carried out relative to the bodyline viz. fixtures, Turntables, etc.
- It assists in the easy location of different parts in the vehicle.
- It aims in creating a standardized system.
- It assists in quality checks.
These are basic essential things that body line dimension would help in BIW. It could help in designing lines like welding lines, assembly lines, or car bodies through fixtures & turntables,s, etc. This help in designing every tool. Particular assemblies or parts are designed w.r.t body lines or an axis system or car line also helps in quality while doing CMM of that system. CMM is basically done with the help of coordination. It has to relate a particular fixture with that car part because the dimension and coordinates of the hole & pin should match so it will help in quality check also. We just give coordinates that belong to that hole both coordinate should match. With this matching means quality is approved. The below figure shows some examples.
Some examples which show how we use the body plane to define the exact position of a part are shown below.
fig-shows the use of the X plane to define the length
fig-shows the use of the Z plane to define the height
fig-shows the use of the Y plane to define the width
Conclusion:
I answered all the given questions in the challenge and appropriate images are attached to it.