Week -2
Our Objective is:-
1) Make a Simulink model of Doorbell using solenoid block.
2) Use a thermistor to sense the temperature of a heater & turn on or turn off the fan.
Starting with first objective i.e doorbell using solenoid block
First of all I am showing the picture of objective then I will explain,
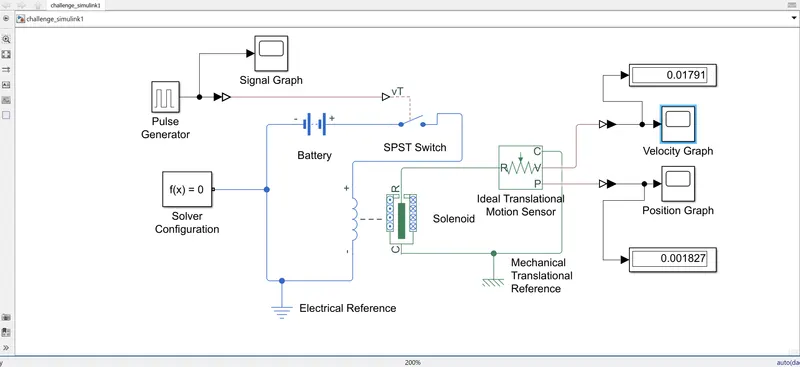
Here first of all Question tells us to run the programme for 2sec means the operation should performed in 2 secs,
thats why I changed the parameters for pulse generator as shown.
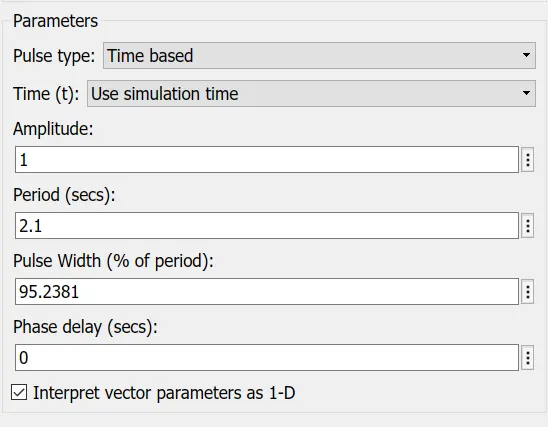
here period is 2.1 sec as set by me & also I have calculated the %age value of 2secs it came 95.2381. so basically it will generate pulse for 2secs & for 0.1 sec it will give 0 signal.
After that
I attached simulink PS converter and scope to it, to convert simulink signal to physical signal & scope helps us to see the signal.
then,
I used SPST switch to take signal coming from simulink ps port at "vT", this switch work by taking signal then switch on the circuit,else off position.
after that,
I used battery, solenoid & electric reference in SPST switch circuit & I have connected as shown above , here the value of battery is 50v and 2ohm internal resistance , I haven't change any value of solenoid.
Also attached solver configuration to it.
after that,
I attached ideal translation motion sensor & mechanical translation reference with the other side of solenoid circuit,
the sensor have output port named C, V, P here C is connected to reference V gives velocity & P gives position so, therefore I attached scope and display both to each port.
I attached ideal translation motion sensor & mechanical translation reference with the other side of solenoid circuit,
the sensor have output port named C, V, P here C is connected to reference V gives velocity & P gives position so, therefore I attached scope and display both to each port & named as velocity and position graph respectively.
\\Results and graph are attached plz find\\
-:SIMULATION OF PLUNGER:-
By observing the position & velocity graph we can conclude that plunger displacement is 5 mm & if bell disc is placed 4.8mm to 5mm then it will hit.
We can also observe that for 2 sec the position of plunger is maintained at 5mm & velocity at that time period is zero, definitely for position to attain 5 mm from zero is 0.039sec , in which the plunger accelerate as we can see in graph, at the end of 2sec the plunger again attain zero position, in this region of graph we can see some vibration type velocity i.e
0 - max at that time - 0 - min at that time - 0
this is because the plunger is attached to some spring type things which helps to ragain zero position & thus cause some vibrational graph when it was released from 5mm. (plz refer the velocity graph).
Confining our second objective i.e thermistor to sense the temperature
First of all I am showing the picture of objective then I will explain,
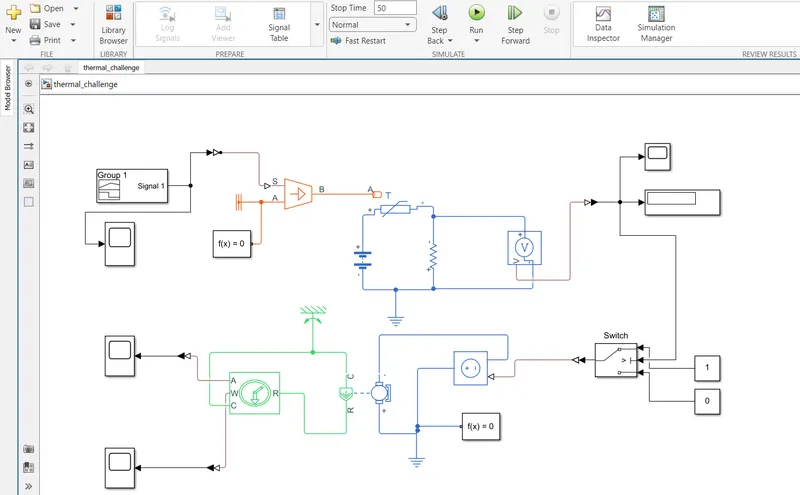
I started with signal builder then I attached simulink ps & a scope to it.
then
I attached controlled temp source with signal coming joined to S port , solver configuration and thermal reference to A port, & output B to thermistor.
Next
When we see diagram of thermistor battery and resistor , In that I connected battery with one terminal to thermistor & another terminal of battery is connected with resistor 1 ohm the circuit is completed and closed.
After that
I connected 2 more blocks that is electrical reference & voltmeter across the resistor to measure potential difference the data were recorded and shown in scope & display respectively attached with output port of voltmeter.
Next
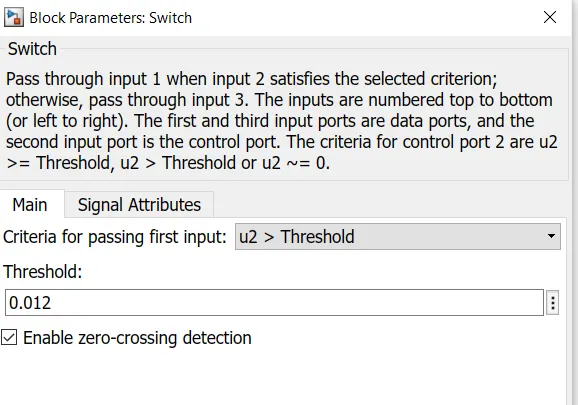
A link from the junction of display & scope is taken and attached to switch input, 3 more port is there in switch in which 2 are assigned with 1 & 0 with constant block remaining 1 is output.
Next
The output of voltage source is connected to controlled voltage source input & from that the potential difference is generated which goes to dc motor electric port.
After that
The mechanical port of dc motor is connected to ideal rottional motion sensor in the circuit & the circuit is also connected to mechanical rotational reference.
Finally
The remaining two port named A and W is connected to scopes saperately which records the angular position and angular velocity.
\\ plz find all graph with this project \\
By refering to graph attached in upload box we see that
above 25 deg cel the fan ramains on this is achieved by watching the region of graph which is above 25 and providing that data to thershold value of switch, In this way I am able to achieve the Objective.