[

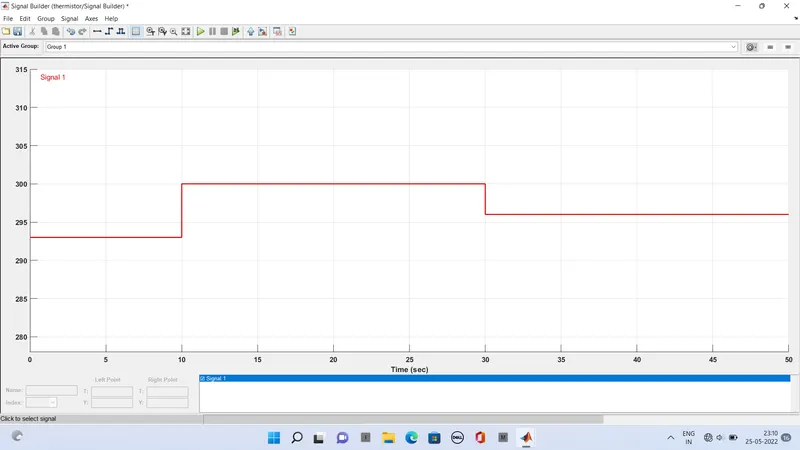
Signal Builder block is uded to input the values as per given conditions:

At point 1,Time=0 seconds,Temperature=293 K

At point 2,Time=10 seconds,Temperature=293 K

At point 3,Time=10 seconds, Temperature=300 K

At point 4, Time=30 seconds, Temperature=300 K

At point 5,Time=30 seconds, Temperature=296 K
[0:12 am, 26/05/2022] Gustavo: At point 5,Time=30 seconds, Temperature=296 K

At point 6,Time=50 seconds,Temperature=296 K

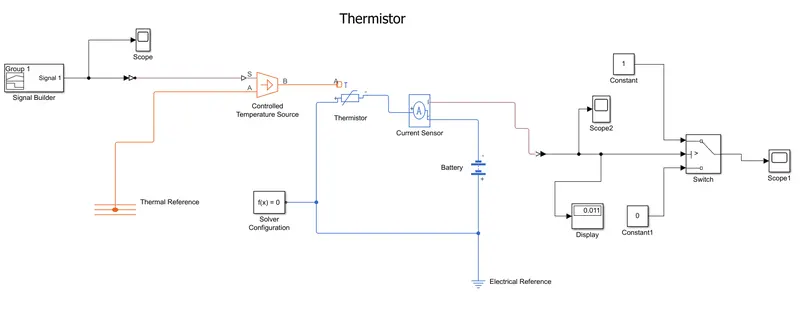
• Controlled Temperature source represents an ideal source of thermal energy.that can maintain a

temperature difference regardless of the heat flow rate. The temperature difference is set by the

port S. A positive temperature difference causes the temperature at port B to be greater than the

at port A.

• Thermistor is a type resistor whose resistanc eis based upon temperature.

• A linear resistor is used is used inorder to control the amount of current from thebattery.

• The voltage sensor is used to convert the voltage measured between two points into a physical s

Voltage source which represenrs dc or ac

• electrical reference block is given

• Solver Configuration:Each physical network represented by a connected simscape blocks require setting information for simulation.
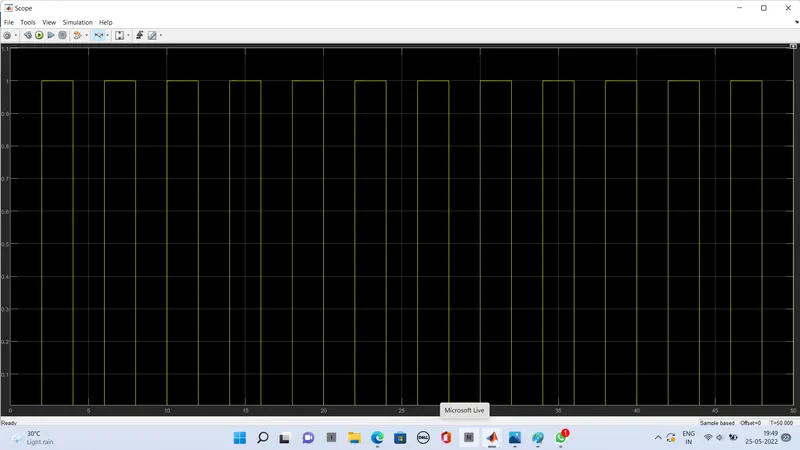
The pulse generator is used to create square wave pulses at regular intervals. The block waveform parameters Amplitude,pulse width period and phase delay,determine the shape of the output waveform.

Parameters

Pulse type: Time based

Time (t): Use simulation time

Amplitude:

1

Period (secs):

4

Pulse Width (% of period):

50

Phase delay (secs):

2

10

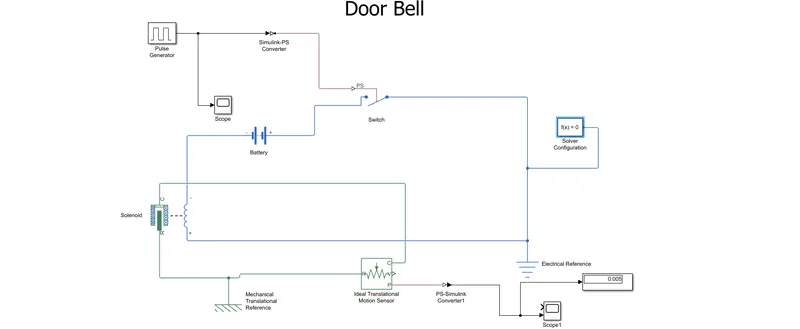
• The switch block used is controlled by external physical signal.if the external signal is greater than the thresold

parameter then the switch is closed, otherwise switch is open.

• The positive terminal of the switch is connected to switch and the negative terminal is connected to the

electrical reference.

• The Solenoid block is connected with switch and battery and we will get a complete electrical circuit.The port c

is connected with mechanical reference.

Interpret vector parameters as 1-D

10

• The ideal translational sensor is connected with solenoid block R to observe the movement of the plunger.

• Scope is connected with the ideal translational sensor to get the output.

• PS-Simulink converter is used to convert the physical signal to simulink signal.

Solver Configuration:Each physical network represented by a connected simscape blocks requires solver

setting information for simulation