Week -2
Aim: This challenge aims to make a Simulink model of a doorbell using a solenoid block and make another Simulin model where a thermistor will be used to sense the temperature of a heater & turn it on or turn it off the fan
Objective:
1. Make a Simulink model of Doorbell using a solenoid block with the following details: In the above arrangement, when the switch is closed the electromagnet receives electrical power from the battery and pulls the metal arm to hit the bell producing sound. Create a situation where the switch is closed for 2 seconds and then released. Observe the physical movement of the plunger. Assume remaining parameters
2. Use a thermistor to sense the temperature of a heater & turn on or turn off the fan as per the below conditions: Temperature source: 20 °C from 0 to 10 seconds, 27 °C from 10 to 30 seconds, 23 °C from 30 to 50 seconds
Fan conditions: ON if the temperature above 25 °C, OFF otherwise.
SIMULINK OBJECTIVE 1:
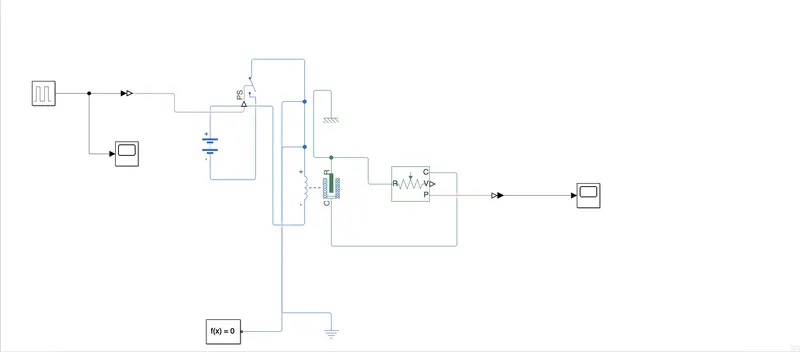
The figure above is the representation of "A doorbell operated on solenoid. In this model, some blocks are used to make the working model of the doorbell. These blocks are:
1. Pulse Generator: The Pulse Generator black generates square wave pulses at regular intervals. The block waveform parameters, Amplitude, Pulse Width, Period, and Phase delay, determine the shape of the output waveform.
2. Simulink-PS Converter: Converts the unitiess Simulink input signal to a Physical Signal.
3. Scope: Display signals generated during simulation
4. Switch: Switch controlled by an external physical signal.
5. Battery: The Battery block represents a simple battery model.
6. Solenoid: Model electrical characteristics and generated force of solenoid.
7. Ideal Translational Motion Sensor: The Ideal Translational Motion Sensor block represents a device that converts an across variable measured between two mechanical translational nodes into a control signal proportional to velocity or position. You can specify the initial position (offset) as a block parameter. The sensor is ideal since it does not account for inertia, friction, delays, energy consumption, and so on.
8. Mechanical Translational Reference: The Mechanical Translational Reference block represents a reference point, or frame, for all mechanical translational ports All translational ports that are rigidly clamped to the frame (ground) must be connected to a Mechanical Translational Reference block.
9. Electrical Reference: The Electrical Reference block represents an electrical ground. Electrical conserving ports of all the blocks that are directly connected to the ground must be connected to an Electrical Reference block. A model with electrical elements must contain at least one Electrical Reference block.
10. Solver Configuration: The Solver Configuration biock specifies the solver parameters that your model needs before you can begin the simulation
11. PS-Simulink Converter: Convert physical signal into Simulink output signal.
Model Explanation:
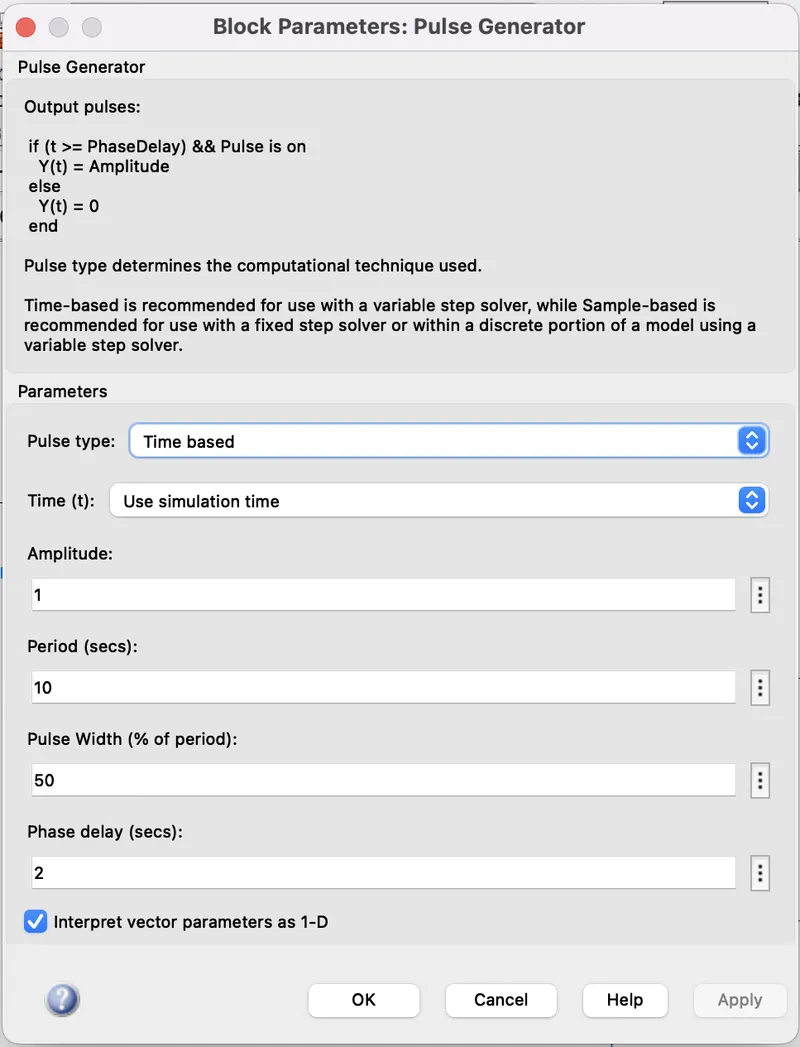
1. The pulse generator is used to give the signal input where, Amplitude 1 Period 4 sec, Puise width 50%, and Phase delay= 2 sec.
2. After that, the input signal is converted into physical form with the use of Simulink-PS Converter and further send to the switch of the electrical circuit.
3. The electrical circult consists of a salenoid, a battery, and a switch. One end of the solenoid is connected to the battery and its other end is connected to the switch. An electrical reference is provided in the electrical circuit.
4. The mechanical part of the solenoid is connected to an ideal translation motion sensor and mechanical translational reference.
5. The P-port of the sensor makes a connection with the PS-Simulink Converter to provide the output in signal form. Further, the converter is connected with scope to display our output signal
6. A solver configuration is connected to an electrical circuit to solve all parameters before the beginning of the simulation.
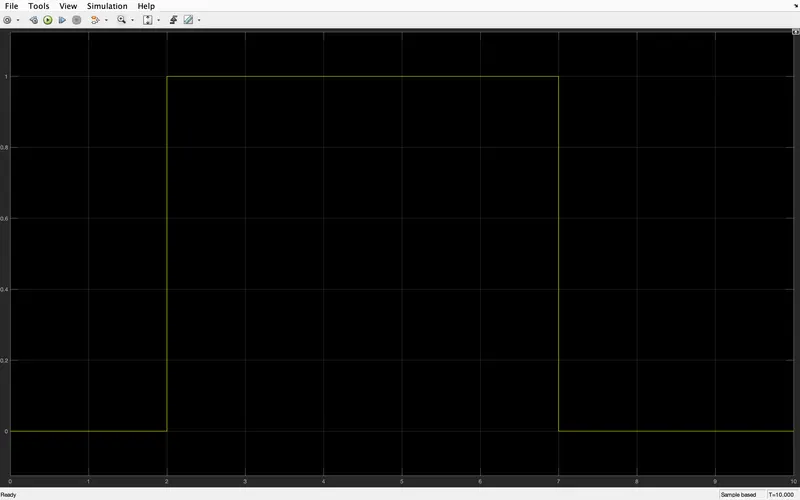
Output:
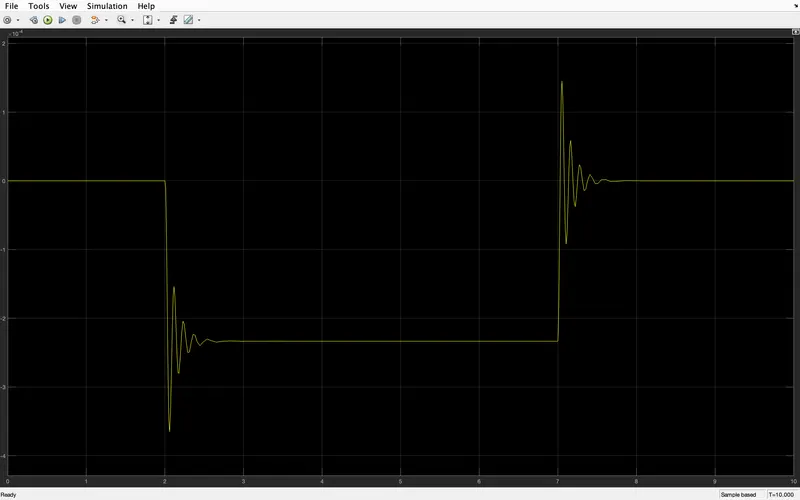
Here we can see that the switch is closed for 2 seconds and after that switch is open Amplitude= 0 means the switch is closed. It can also be seen that the plunger strikes after every 2 seconds. The motion of the plunger was simulated and recorded and plotted in scope.
SIMULINK OBJECTIVE 2:
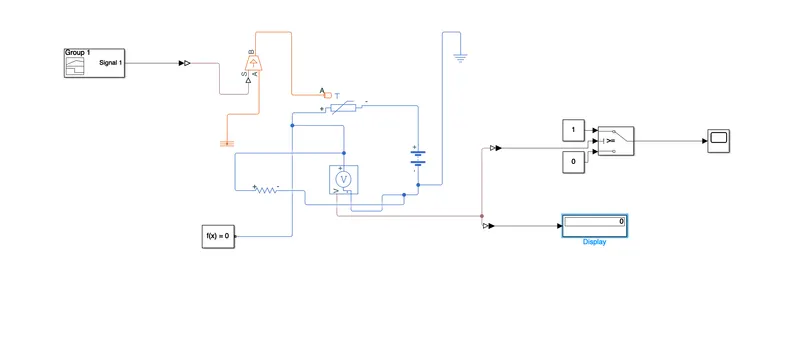
This figure shows the representation of thermistor connection which senses the temperature of a heater and passes the signal to a switch where a threshold limit is already set. If the temperature is above or equal to the threshold limit then it gives T as output which is "Switch On". If the temperature is below the threshold limit, then it will give "0" as output which means "Switch Off". The input signal is generated with the help of a "Signal Builder block (See Fig 9). This signal is created according to the conditions given in this challenge. The conditions are as following
Temperature source: 20 °C from 0 to 10 seconds
27°C from 10 to 30 seconds
23 °C from 30 to 50 seconds
Fan conditions: ON if the temperature above 25 °C, OFF otherwise. Here the temperature is converted in Kelvin from degree Celcius because the signal converter does not take "C value as input. also have to set the signal unit as "Kelvin in Simulink-PS Converter,
The formula for conversion: 1°C=27315 K
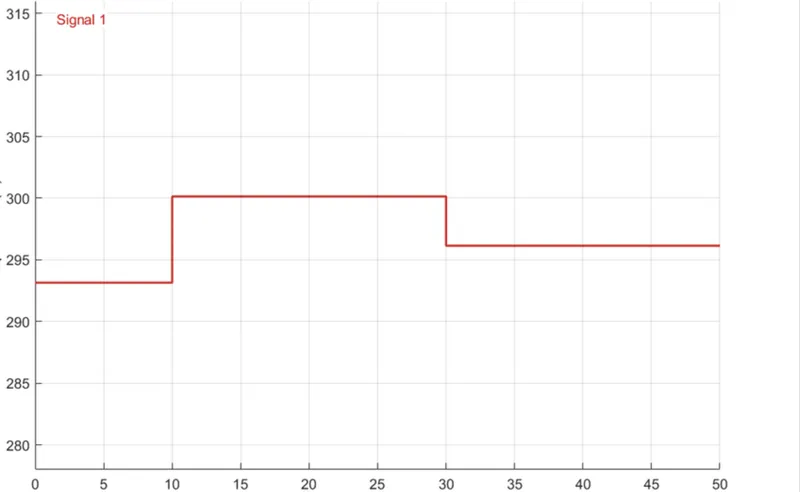
The Signal :
From 0-10 sec- Temperature is 293.15 K
From 10-30 sec- Temperature is 300.15K
From 30-50 sec-Temperature is 296.15 K
Model Explanation:
1.At first, the signal is created in "Signal Builder" and further passes to "Simulink-PS Converter" to convert the input signal into the physical signal.
2. This physical signal is connected to a block "Controlled Temperature Source". This block is connected to the thermistor and a Thermal Reference block.
3. The thermistor is a part of an electric circuit where a battery, a voltage sensor, a resistor connected parallel to av the voltage sensor, an electrical reference are connected to make a complete circuit. A solver configuration is connected to that electrical circuit to solve all parameters before the beginning of the simulation.
4. The voltage sensor senses the temperature in the form of voltage and sends the data to its port V
5. From this port, we get our output and send it to two different "PS-Simulink Converter".
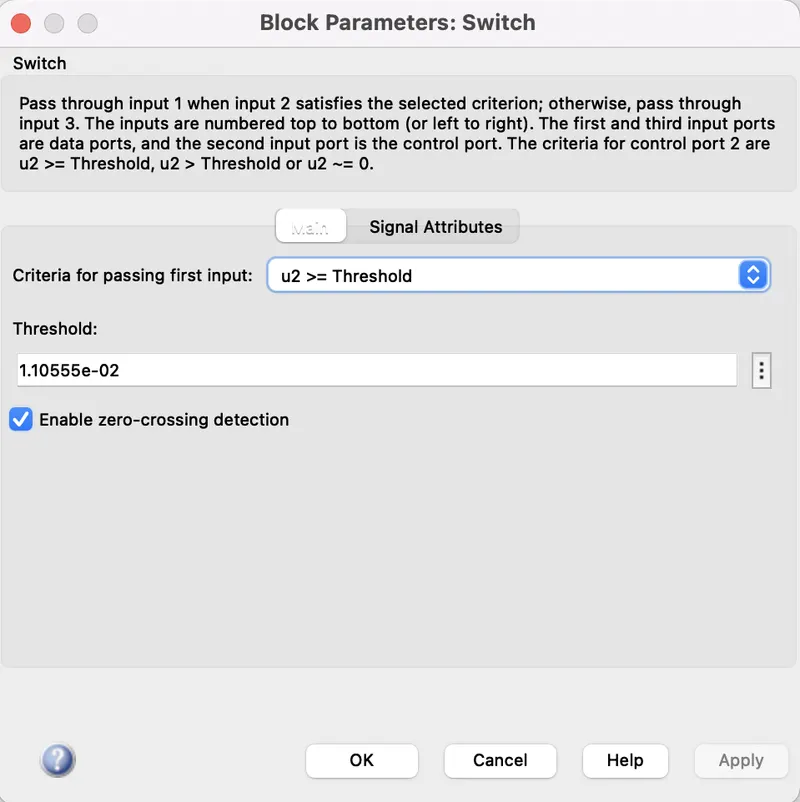
6. From converter-1, the signal is sent to the threshold switch in the switch, the threshold limit is set to 110555e-02. If the temperature is above or equal to the threshold limit, then it gives "T" as output which is "Switch On". If the temperature is below the threshold limit then it will give "0" as output which means "Switch Off". The input signal is generated with the help of a "Signal Builder block .
7. The switch is connected to the scope where we can see our output plot.
B. From converter-2, it converts the physical signal into a Simulink signal and sends the voltage data from the voltage Sensor to display. This display gives us the threshold value of voltage. This value is set in the switch
Output:
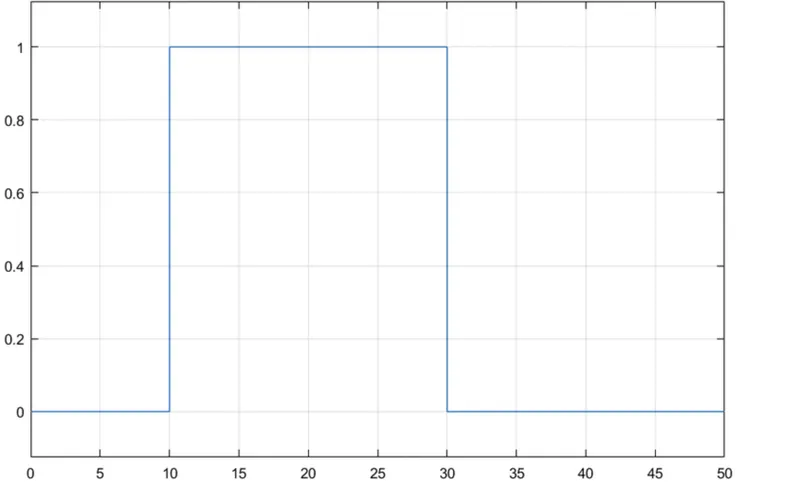
It can be seen that the value of the signal is "0" from 0-10 sec because in this time the temperature was 20°C which is below 25°C means "Switch off the fan". After that, the signal value gives Tas output from 10-30 sec because in this time the temperature was 27°C which is above 25°C means 'Switch on the fan'. The value of the signal is again goes to '0' from 30-50 sec because in this time the temperature was 23 °C which is below 25°C means "Switch off the fan".
Now it is clear that our model is correct and fulfills all the input conditions.
CONCLUSION: