Week 2- 2R Robotic Arm Challenge
Aim
To stimulate the 'Forward Kinematics' of a 2R Robotic Arm using MATLAB
Objective
1. Write a program to simulate forward kinematics of a 2R Robotic Arm
2. Animating and create a movie from the plots obtained fram the program
Theory
Robotic arm:- A robotic arm is a type of mechanical arm,usually programmable,with similar functions to
human arm. The arm may be sum total of the mechanism or may be of a more comlex robot. The links
of such a manipulator are connected by joints allowing either rotational motion(such as in an atriculated
robot) or translationaal(linear) displacement. The links of the manipulator can be considered to form a
kinematic chain. The terminus of a kinematic chain of the manipulator is called the end effector and it
is analogous to human hand.
Applications:- The robotic arm are used in various applications such as
1. Welding
2. Painting
3. Automotive Robotic Solution
4. Food,Beverage,Sanitation
5. Package industry
Schemaric Diagram
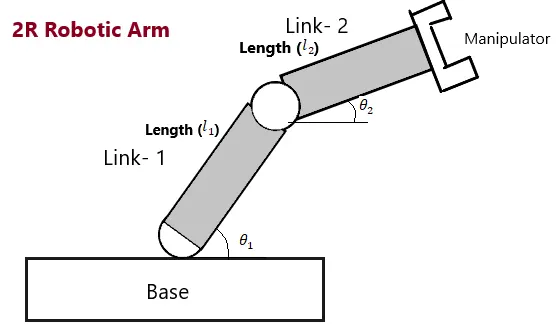
Inputs
l1 = length of link 1
l2 = length of link 2
theta1 = angle made by link 1 with horizontal
theta2 = angle made by link 2 with horizontal
Matlab Code
clear all
close all
clc

%Inputs
l1 = 1;
l2 = 0.5;

theta1 = linspace(90,0,10);
theta2 = linspace(90,0,10);

ct = 1;
for i = 1:length(theta1)
 THETA1 = theta1(i);
 for j = 1:length(theta2)
  THETA2 = theta2(j);
    x0 = 0
    y0 = 0

    x1 = l1*cosd(THETA1);
    y1 = l1*sind(THETA1);

    x2 = x1 + l2*cosd(THETA2);
    y2 = y1 + l2*sind(THETA2);

    %Ploting

    plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
    axis([-0.1 1.5 0  1.5])
    pause(0.03)

    M(ct) = getframe(gcf)
    ct = ct+1;

 end

end

movie(M)
videofile = VideoWriter('forward_kinematics.avi','Uncompressed AVI');
open(videofile)
writeVideo(videofile,M)
close(videofile)
Youtube Video LInk
https://youtu.be/B2mVHSExRgo
Googledrive link
https://drive.google.com/file/d/1Z_wvR1qFBNnx9HNTd9Lu4fGeYx321sBt/view?usp=sharing
Explanation
theta1 and theta2 arrays are initialized.A variable for frame counting 'ct' is intialized the value 1.Two for
loops are defined for controlling value of theta1 and theta2. For each value of theta1,the positions of the
two links are found out using each value of theta2.The value from theta1 and theta2 array are stored into
variables THETA1 and THETA2 for each iteration of loops.
The position of the end points for each of the links are calculated using the equations given below:-
Link 1
Start Point x0 =0,y0 = 0
End Points x1 = x0 + l1costheta1
y1 = y0 + l1sintheta1
Link 2
End Point x2 = x1 + l2costheta2
y2 = y1 + l2sintheta2
The graph is plotted using the plot command.The'getframe(gcf)'command is used insid the second loop
(controlling second link position) to get the current frame and store it as an image into the array'M'.
The videowriter command creates an empty video file by the name 'forward kinematics' in.avi format and
it is stored in the variable video file.
The writevideo command inserts the frames stored in the array'M' into the videofile.
Results
The video file was made and published.