Week 2- 2R Robotic Arm Challenge
AIM : A Program in Matlab To simulate the forward kinematics of a 2R robotic arm.
Theory : Robotic is a machine tool which work like human and work better than a human.
It works in his own motion that a person instruct it.
% forward kinematics of a 2R robotic arm maniulator

clear all
close all
clc

%inputs
l1=1;
l2=0.5;

theta1=45;
theta2=30;

%coordinates
x0=0;
y0=0;

x1=l1*cosd(theta1);
y1=l1*sind(theta1);

x2=x1+l2*cosd(theta2);
y2=y1+l2*sind(theta2);

%plotting
line([x0 x1],[y0 y1],'linewidth',3,'color','b')
line([x1 x2],[y1 y2],'linewidth',3,'color','r')
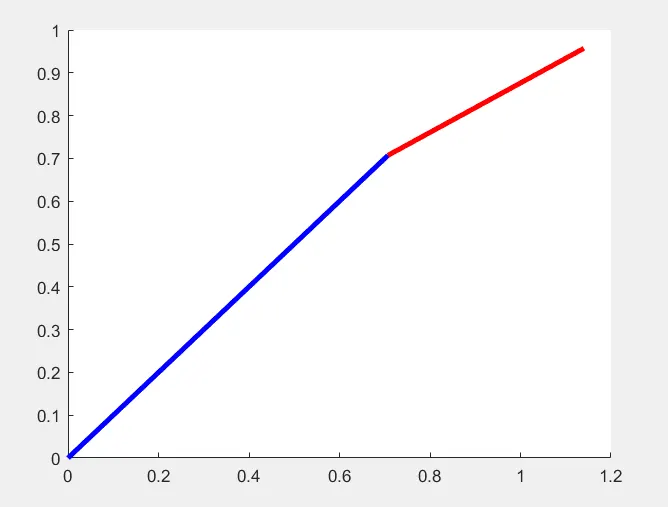
After putting this code the plot generate like this.
to creat this plot i was facing some error but i fixed it. so that i can get this
Then if i put this value -
clear all
close all
clc

%inputs
l1=1;
l2=0.5;
theta1 = linspace(0,90,4);
theta2 = linspace(0,90,4);
ct=1
for i = 1:length(theta1);
    THETA1 = theta1(i);
    for j = 1:length(theta2)
        THETA2 = theta2(j);
        x0=0;
y0=0;

x1=l1*cosd(THETA1);
y1=l1*sind(THETA1);

x2=x1+l2*cosd(THETA2);
y2=y1+l2*sind(THETA2);

%plotting
hold on
plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3);
axis([-0.1 1.5 0 1.5])
pause(0.03)
ct=ct+1;

    end
end
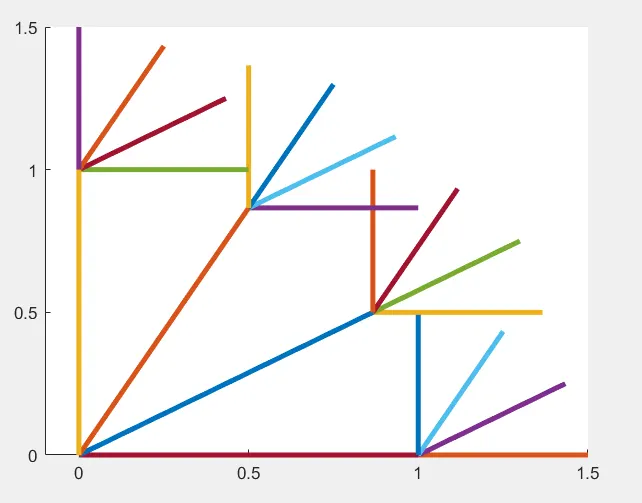
the the plot look like this
and if we put this value.
clear all
close all
clc

%inputs
l1=1;
l2=0.5;
theta1 = linspace(0,90,10);
theta2 = linspace(0,90,10);
ct=1
for i = 1:length(theta1);
    THETA1 = theta1(i);
    for j = 1:length(theta2)
        THETA2 = theta2(j);
        x0=0;
y0=0;

x1=l1*cosd(THETA1);
y1=l1*sind(THETA1);

x2=x1+l2*cosd(THETA2);
y2=y1+l2*sind(THETA2);

%plotting
hold on
plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3);
axis([-0.1 1.5 0 1.5])
pause(0.03)
ct=ct+1;
M(ct) = getframe(gcf);

    end
end
movie(M)
Videofile=VideoWriter('forward.kinematics.AVI','Uncompressed AVI');
open(Videofile)
writeVideo(Videofile,M)
close(Videofile)
then the plot look like this
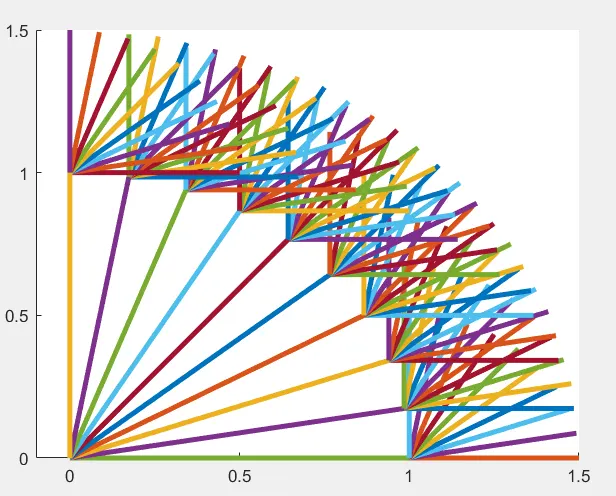
also you can check the video that appears through my work and this is the lnk :
https://drive.google.com/file/d/1JCguXc5q83DQPTpjZmasfkEaLdLup89b/view?usp=sharing
Result: Finally i get the result how to create a forward kinematic 2R robotics.
as you can see my report that i get using Matlab.
thank you