Week 2- 2R Robotic Arm Challenge
Click here to watch Animation of Final Result
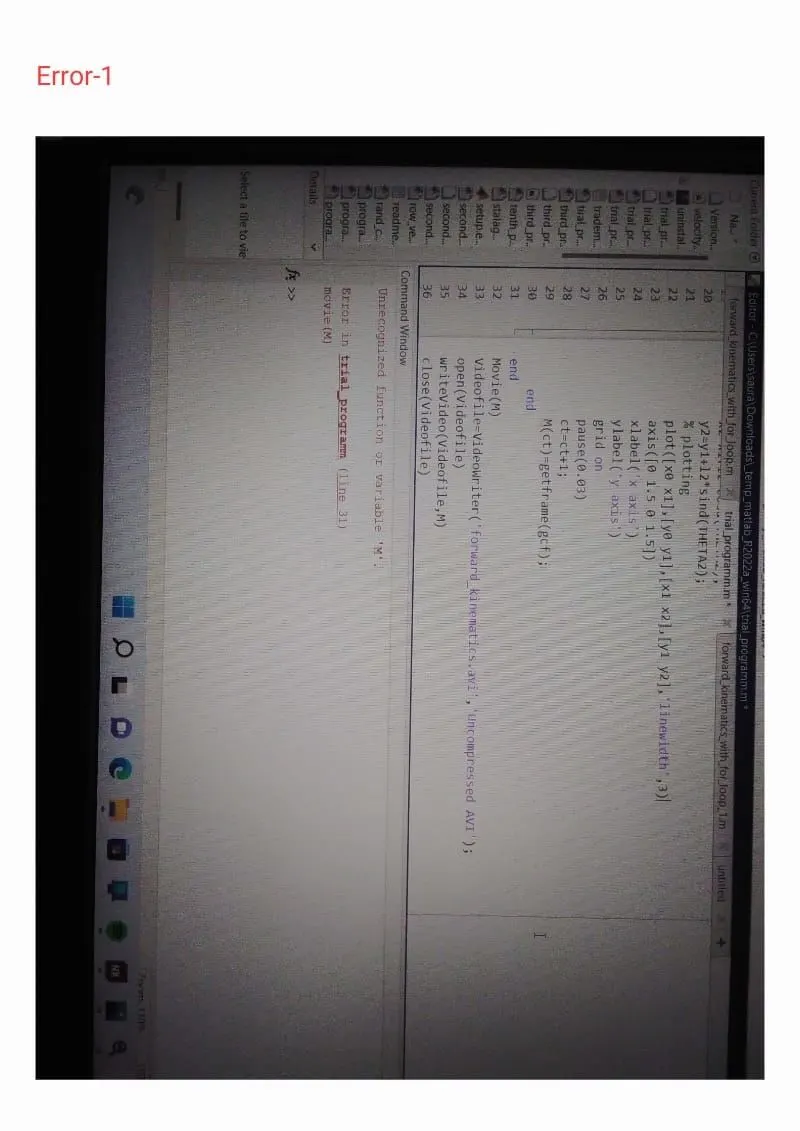
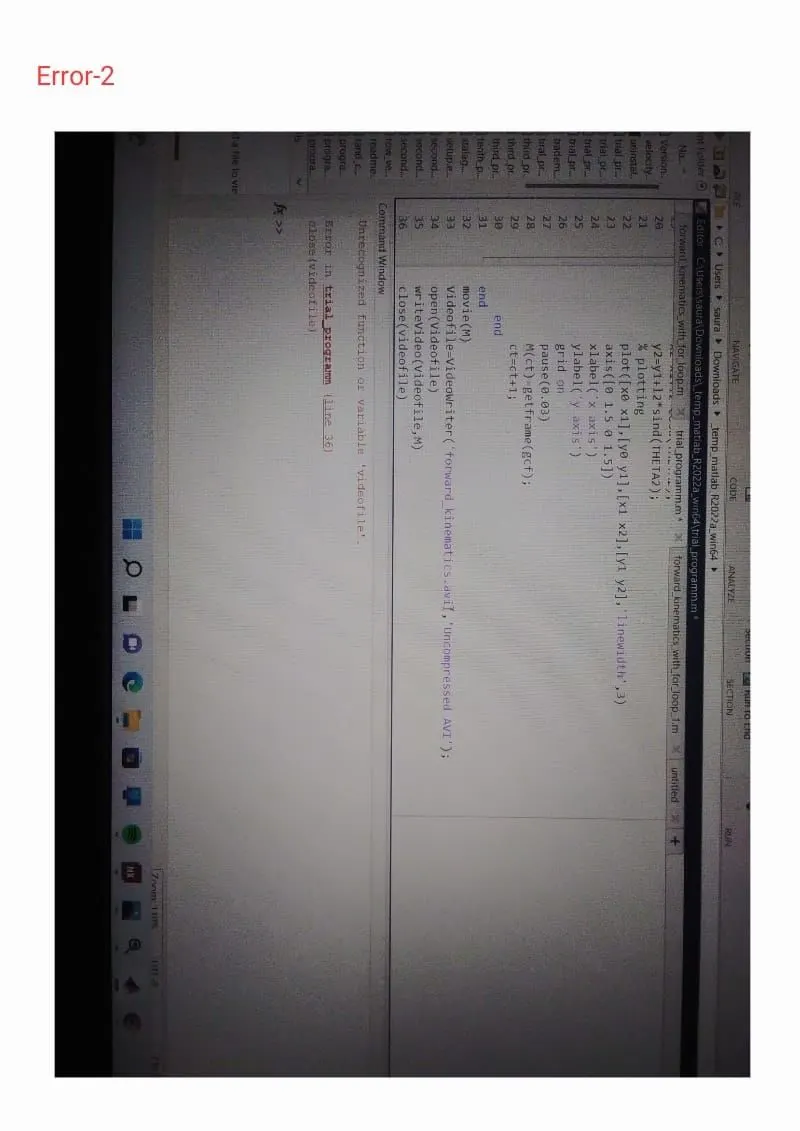
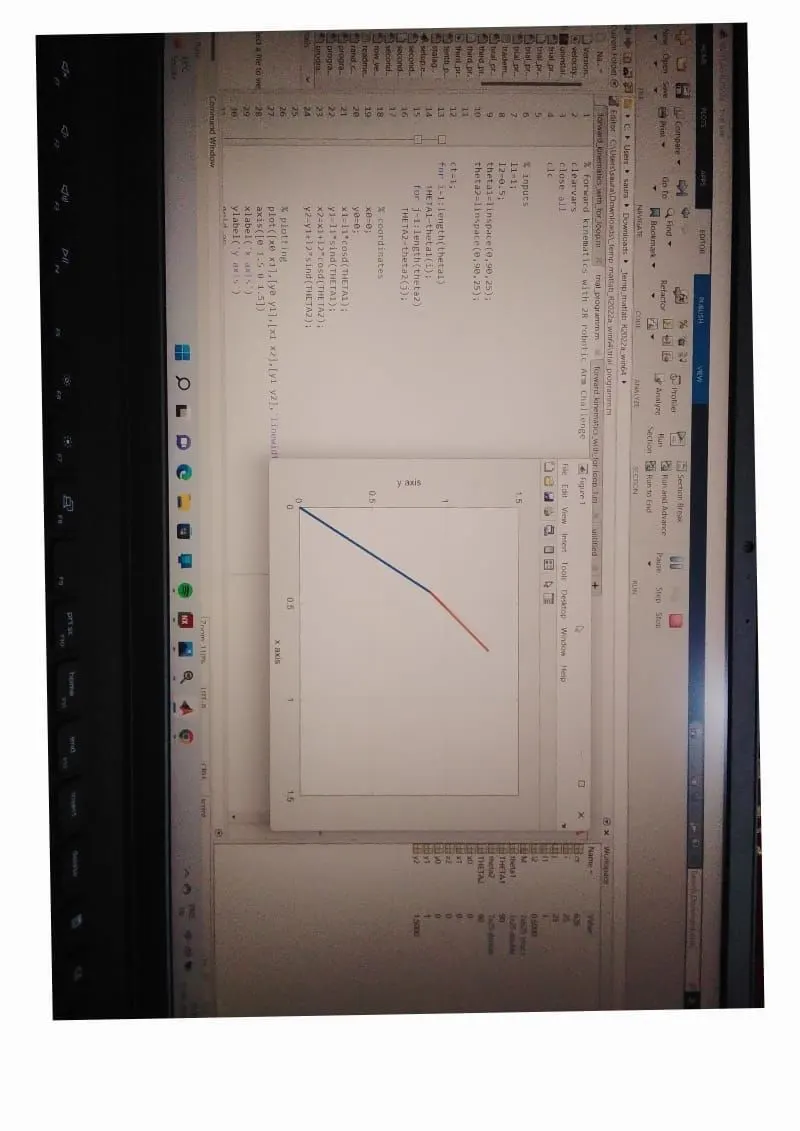
% forward kinematics with 2R robotic Arm Challenge
% step1
clearvars
close all
clc

% step2
% inputs
l1=1;
l2=0.5;
theta1=linspace(0,90,25);
theta2=linspace(0,90,25);

% step3
ct=1;
for i=1:length(theta1)
    THETA1=theta1(i);
    for j=1:length(theta2)
        THETA2=theta2(j);

        % step4
        % coordinates
        x0=0;
        y0=0;
        x1=l1*cosd(THETA1);
        y1=l1*sind(THETA1);
        x2=x1+l2*cosd(THETA2);
        y2=y1+l2*sind(THETA2);

        % step5
        % plotting
        plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
        axis([0 1.5 0 1.5])
        xlabel('x axis')
        ylabel('y axis')
        grid on
        pause(0.03)
        M(ct)=getframe(gcf);
        ct=ct+1;

    end
end
% step6
movie(M)
Videofile=VideoWriter('forward_kinematics.avi','Uncompressed AVI');
open(Videofile)
writeVideo(Videofile,M)
close(Videofile)