Week 2- 2R Robotic Arm Challenge
report:
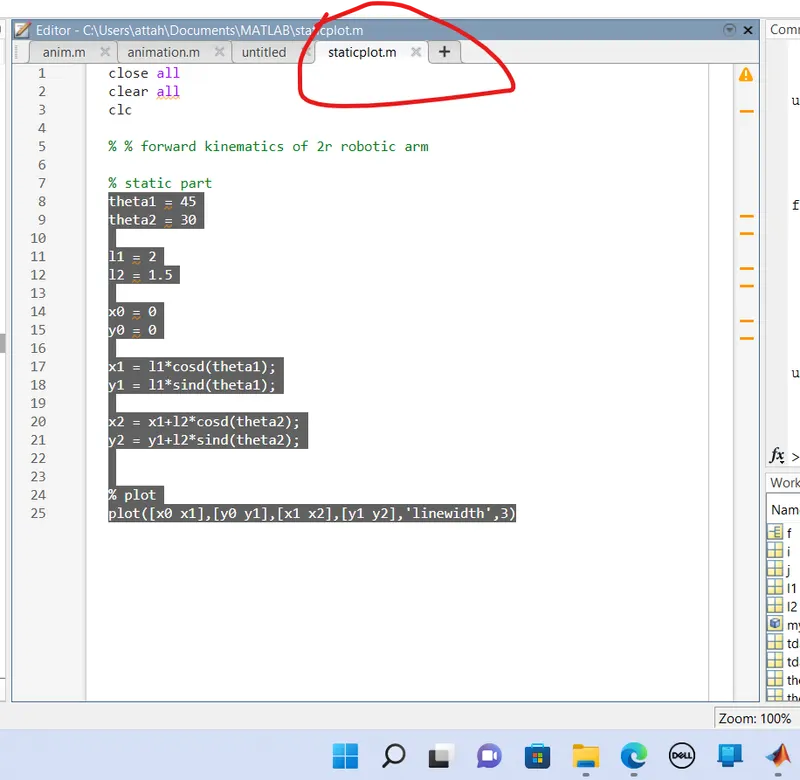
- First i separated the coding into two parts- 1. static part 2.animation part
- In static part i just program for static plot without animation in separate folder
- And why do separate folder because to alling the proper arrangement of coding and see the difference to understand clearly
- In animation part i have made a mistake, that when start the for loop i have forgotten to finish with 'end' command
-
- The major error in animation part is placing the axis command in right place, it takes time to find out that mistake
- That axis command should always under the plot command, but what i did is
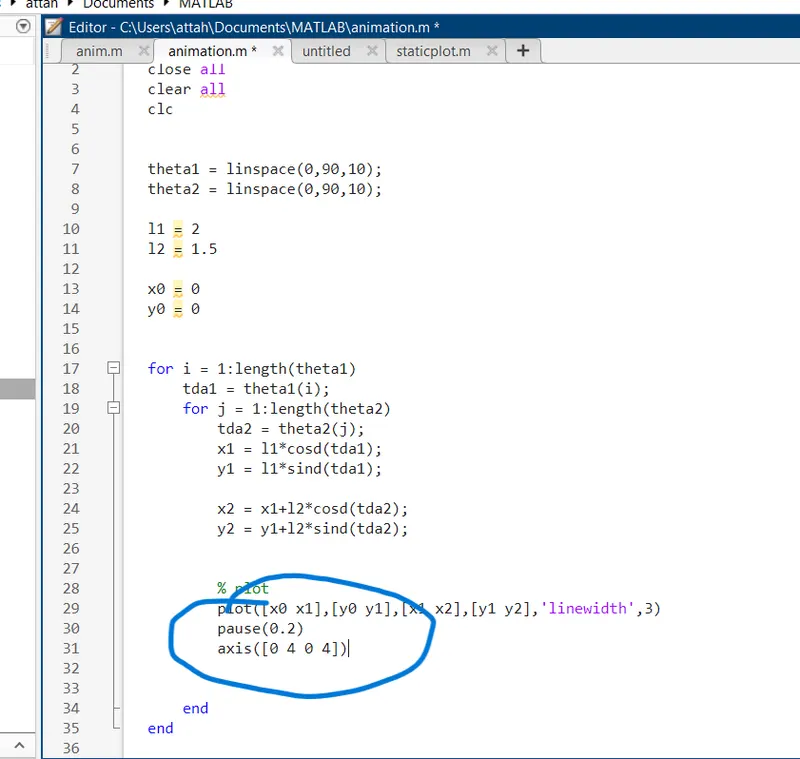 So when I did this axis also changing, after i found the mistake and fixed it.
%program for forward kinematics of 2r robotic arm
% static part
theta1 = 45
theta2 = 30
l1 = 2
l2 = 1.5
x0 = 0
y0 = 0
x1 = l1*cosd(theta1);
y1 = l1*sind(theta1);
x2 = x1+l2*cosd(theta2);
y2 = y1+l2*sind(theta2);
% plot
plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)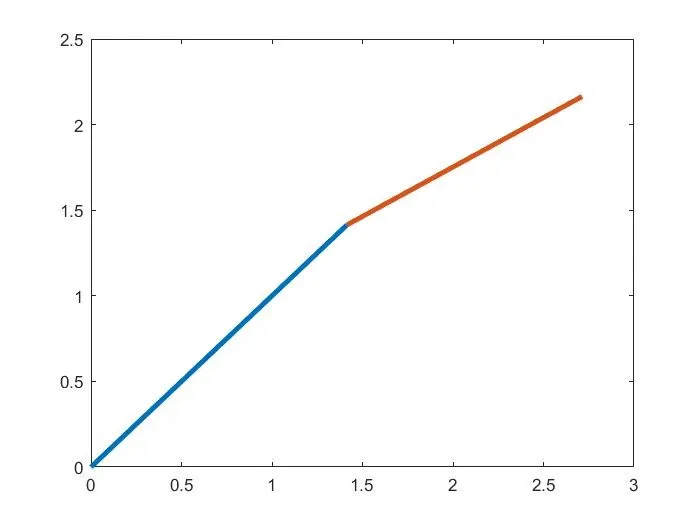
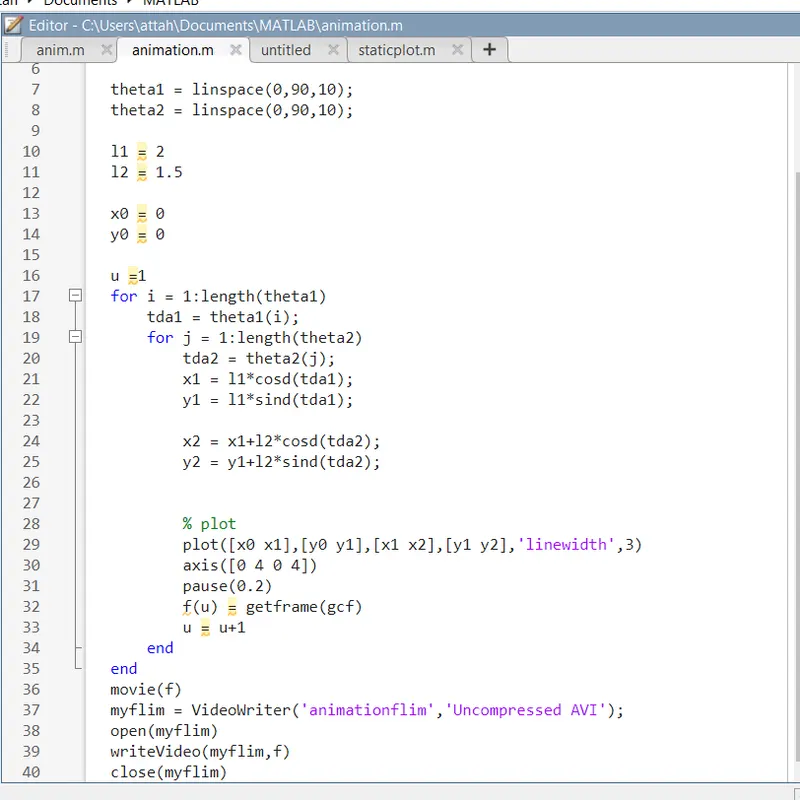
%then i open the new folder for animation and save the movie
% animation
close all
clear all
clc
theta1 = linspace(0,90,10);
theta2 = linspace(0,90,10);
l1 = 2
l2 = 1.5
x0 = 0
y0 = 0
u =1
for i = 1:length(theta1)
tda1 = theta1(i);
for j = 1:length(theta2)
tda2 = theta2(j);
x1 = l1*cosd(tda1);
y1 = l1*sind(tda1);
x2 = x1+l2*cosd(tda2);
y2 = y1+l2*sind(tda2);
% plot
plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
axis([0 4 0 4])
pause(0.2)
f(u) = getframe(gcf)
u = u+1
end
end
movie(f)
myflim = VideoWriter('animationflim','Uncompressed AVI');
open(myflim)
writeVideo(myflim,f)
close(myflim)