Week 2- 2R Robotic Arm Challenge
OBJECTIVE:
To write program and simulation of forward kinematics of a 2R Robotic arm.
INTRODUCTION:
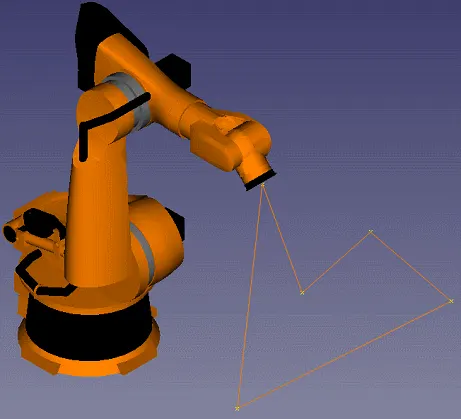
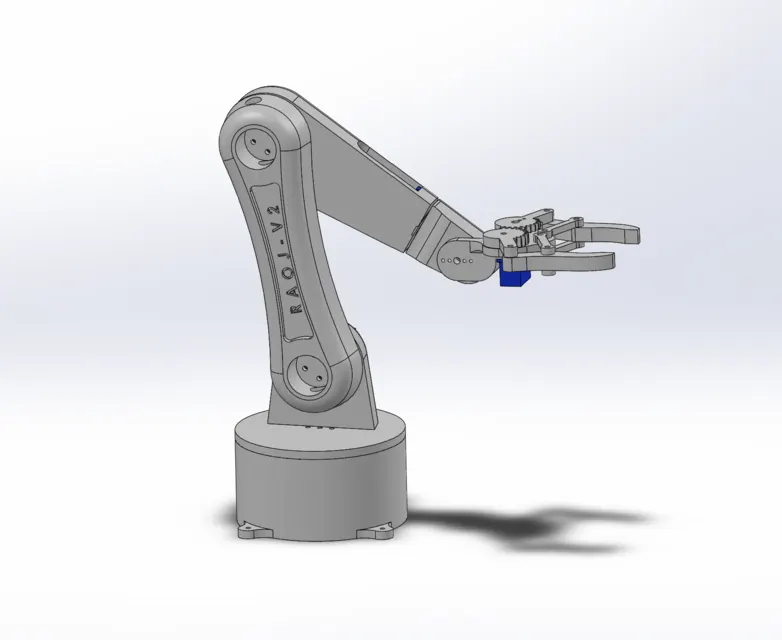
ROBOTIC ARM
A Robotic arm is a type of mechanical arm usually programmable with similar functions to human arm.The arm may be the sum of total of the mechanism or may be part of a more complex robot. The links such as manipulator are connected by joints allowing either rotational motion.The links A Robotic arm is a type of mechanical arm usually programmable with similar functions to human arm.The arm may be the sum of total of the mechanism or may be part of a more complex robot.The links such as manipulator are connected by joints allowing either rotational motion.The links of the manipulator can be considered to form a kinematic chain.
2R ROBOT
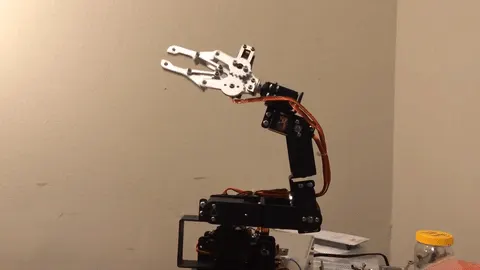
Robot use the basic arms of the robot to do that we are dealing with linkages known as forward kinematics of 2R where 2R means 2 rotating link 2 is the number of link & R is rotation.
INPUTS :
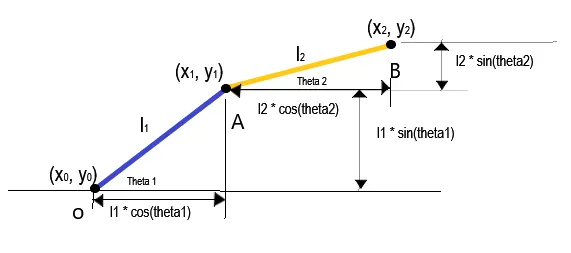
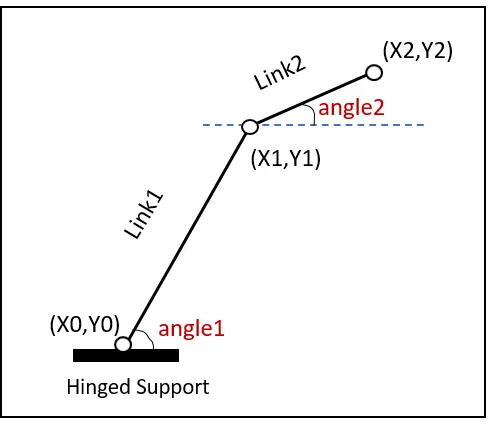
Link 1
From the fixed support the value of x and y for the link (x0 y0) and end value (x1 y1)
x0 = 0 x1 = l1* cosd(theta 1)
y0=0 y1= l2*sind(theta1)
Link 2
Link 2 starting piont is the ending point of link 1
x2= x1+l2*cosd(theta2)
y2=y1+l2*sind(theta2)
(x0 y0) - Starting point of Link1
(x1 y1) - Starting point of link2 / Ending Point of link 1
(x2 y2) - End point of link 2
l1 - Length of link attached to the base
l2 - Length of link between the first link & end link
(Theta 1) - Angle by Link 1 with x-axis
(Theta 2)- Angle by Link 2 with Y axis
Length of Robotics arms
L1=1.3M
L2=0.8M
Angles for movement of robotic arms
Theta1= linspace(0,180,20)
Theta2= linspace(0,180,20)
Counter staring vaule assigned as 1
ct=1
Program
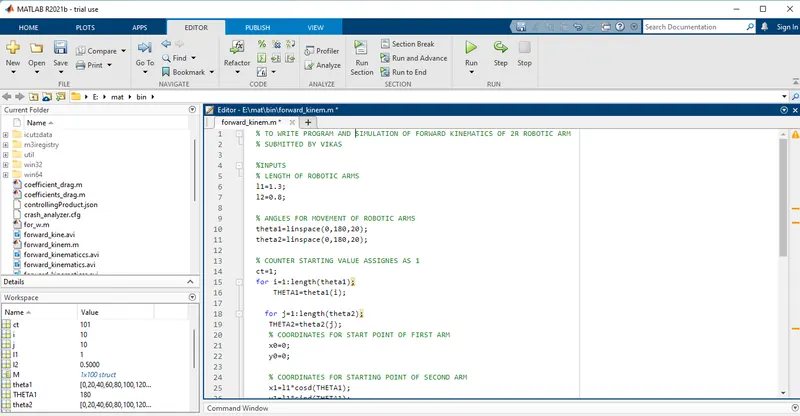
% TO WRITE PROGRAM AND SIMULATION OF FORWARD KINEMATICS OF 2R ROBOTIC ARM
% SUBMITTED BY VIKAS

%INPUTS
% LENGTH OF ROBOTIC ARMS
l1=1.3;
l2=0.8;

% ANGLES FOR MOVEMENT OF ROBOTIC ARMS
theta1=linspace(0,180,20);
theta2=linspace(0,180,20);

% COUNTER STARTING VALUE ASSIGNES AS 1
ct=1;
for i=1:length(theta1);
    THETA1=theta1(i);

  for j=1:length(theta2);
   THETA2=theta2(j);
   % COORDINATES FOR START POINT OF FIRST ARM
   x0=0;
   y0=0;

   % COORDINATES FOR STARTING POINT OF SECOND ARM
   x1=l1*cosd(THETA1);
   y1=l1*sind(THETA1);

   % COORDINATES FOR ENDING PIONT OF SECOND ARM
   x2=x1+l2*cosd(THETA2);
   y2=y1+l2*sind(THETA2);

   % PLOTTING
   % COORDINATES OF ARMS ASSIGNED FOR THETA1 AND THETA2
   plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'LineWidth',3,'marker','o')

   % LIMITS FOR X-AXIS AND Y-AXIS
   axis([-0.1 1.5 0 1.5])
   pause(0.1)

   % FRAMES OF FIGURES TO COMPRISE IN ANIMATION
   M(ct)=getframe(gcf);
   ct=ct+1;
  end
end


movie(M)
videofile=VideoWriter('forward_kinematiccs.avi','Uncompressed AVI');
open(videofile)
writeVideo(videofile,M)
close(videofile)
Results:
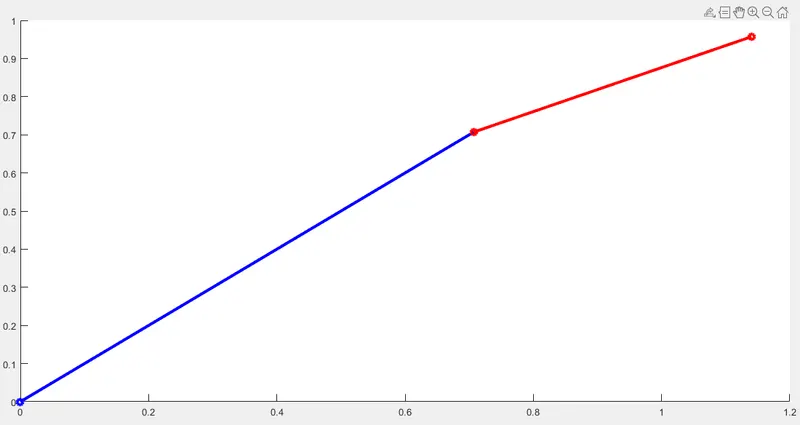
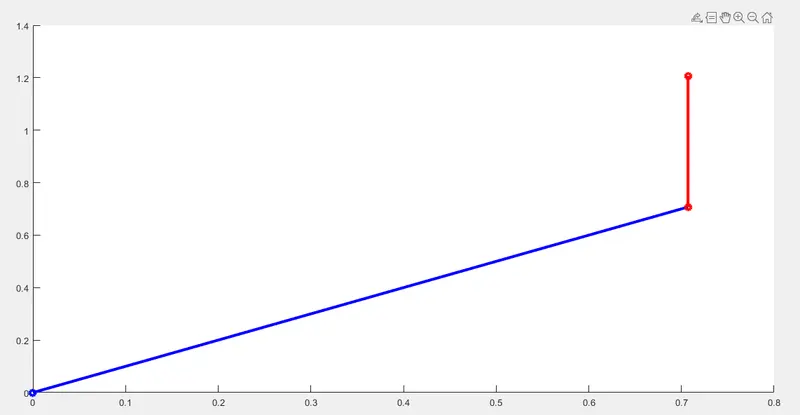
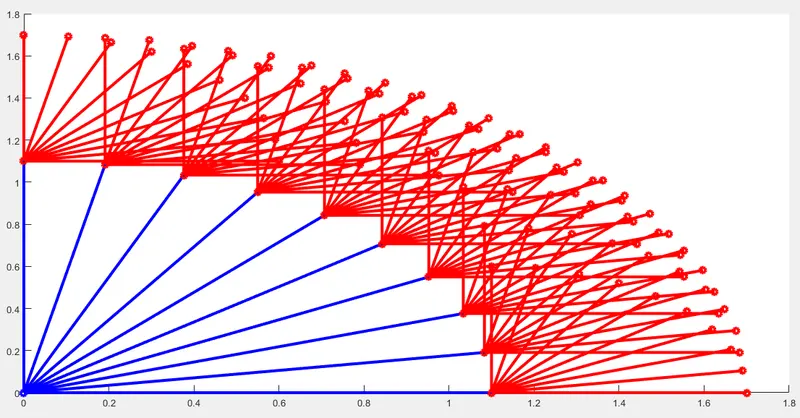
ERROR:
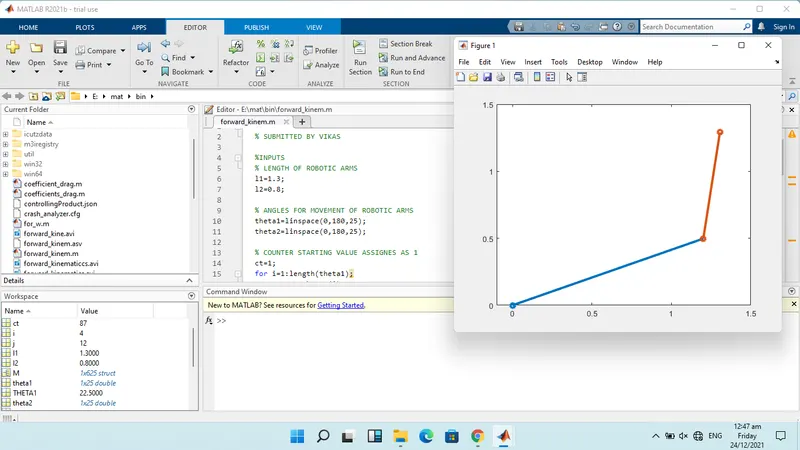
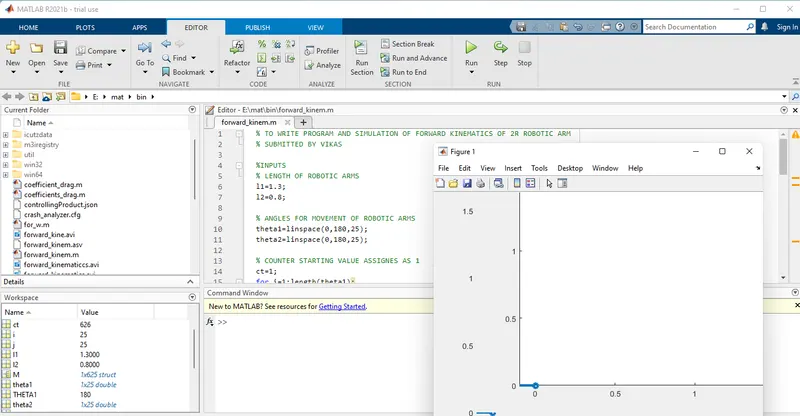
No error found during running the program.
CONCLUSION:
The simulation and Programming of 2R robotic arm is done in Matlab
The output and video of the program link is given below:
https://drive.google.com/file/d/1dsZUEj16BRxYJAsWonWOSaEFroqu96aS/view?usp=sharing