Week 2- 2R Robotic Arm Challenge
EXPLANATION
INTRODUCTION ABOUT FORWARD KINEMATICS OF A 2R ROBOTIC ARM
- Here the robotic arm contains the two links and one manipulator,Depends on requirement the manipulator may change like a welder,cutting tool,sprayer etc.,
- The robotic arm have l1,l2,consider as link 1&2,the angles are theta1 and theta2 respected to the x-axis
- Here we have three nodes , the 1st node is conected to the base ,second node between the link 1&2,3rd node is between the link2 and manipulator
- 1st step to calculate the coordinates
- 2nd step is to calculate the positions of link1 &link2
LINK
CODE

% Forward kinematics of a 2R Robotic arm manipulator


close all
clear all
clc


%inputs
l1 = 1;
l2 = 0.5;

theta1 = linspace(0,90,10);
theta2 = linspace(0,90,10);

ct=1

for i=1:length(theta1)
THETA1 = theta1(i);
for j=1:length(theta2)
THETA2 = theta2(j);
%coordinates
x0=0;
y0=0;

x1 = l1*cosd(THETA1);
y1 = l1*sind(THETA1);

x2 = x1 + l2*cosd(THETA2);
y2 = y1 + l2*sind(THETA2);

%plotting

plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
axis([-0.1 1.5 0 1.5])
pause(0.03)
M(ct) = getframe(gcf);
ct = ct+1;

end
end

movie(M)
videofile = VideoWriter('forward_kinematics.avi','Uncompressed AVI');
open(videofile)
WriteVideo(videofile,M)
close(videofile)
CODE
% Forward kinematics of a 2R Robotic arm manipulator
close all
clear all
clc
%inputs
l1 = 1;
l2 = 0.5;
theta1 = linspace(0,90,10);
theta2 = linspace(0,90,10);
ct=1
for i=1:length(theta1)
THETA1 = theta1(i);
for j=1:length(theta2)
THETA2 = theta2(j);
%coordinates
x0=0;
y0=0;
x1 = l1*cosd(THETA1);
y1 = l1*sind(THETA1);
x2 = x1 + l2*cosd(THETA2);
y2 = y1 + l2*sind(THETA2);
%plotting
plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
axis([-0.1 1.5 0 1.5])
pause(0.03)
M(ct) = getframe(gcf);
ct = ct+1;
end
end
movie(M)
videofile = VideoWriter('forward_kinematics.avi','Uncompressed AVI');
open(videofile)
WriteVideo(videofile,M)
close(videofile)
REPORT
- In the code the inputs stores the data of l1&l2,theta1&theta2
- With the help of 'for loop' concept the problem has going to be solved
- coordinates calculated in the foor loop
- results shown with the help of plotting
- animation has created with the help of videofile array
ERROS
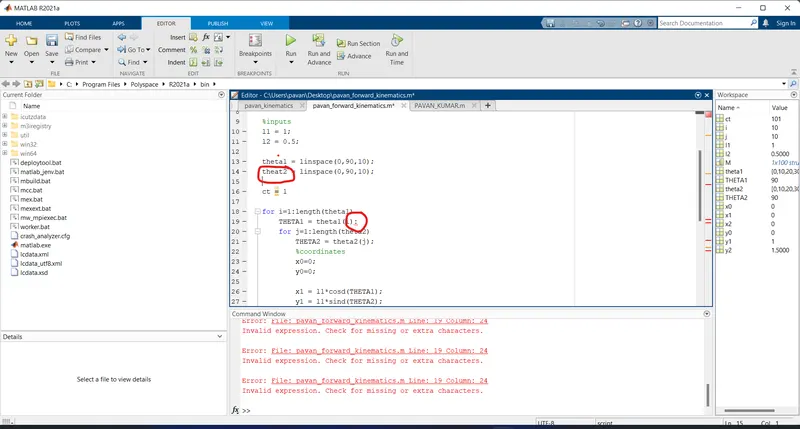
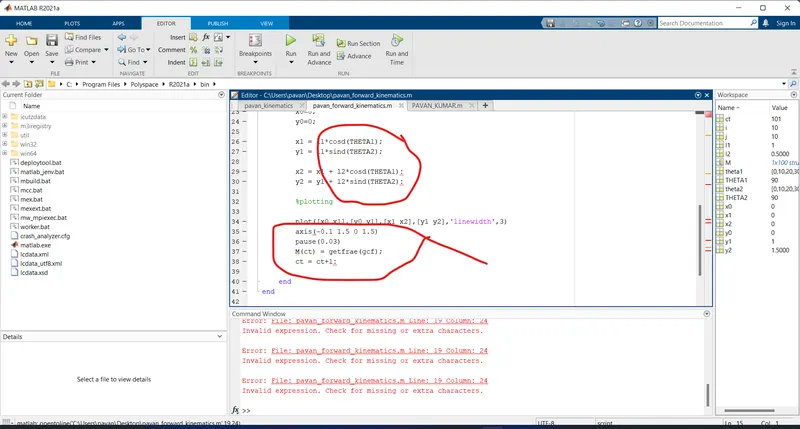
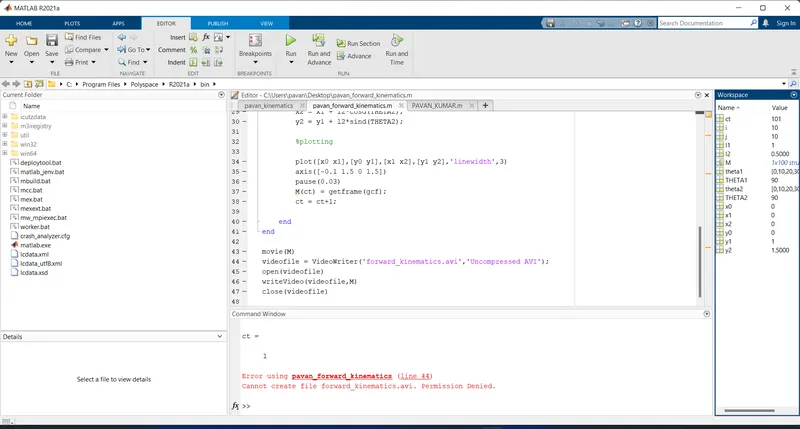
- majorly shown erros are coloums
- brackets
- spellings