Week 15 - Final Challenge
stage 1:
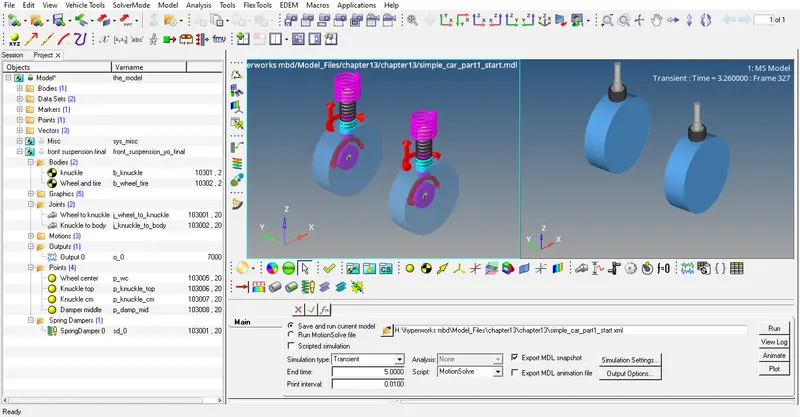
- importing the simple car model
- adding the damper entities has a pair
- making a left damper has a master
- giving k and c value
- adding necessary graphics for dampers
- creating force output
- running the model, analyzing the vector force magnitude in 3 directions
- exporting the model after making it has a subsystem
stage 2:
- importing the previous file
- importing the vehicle body system
- adding attachments
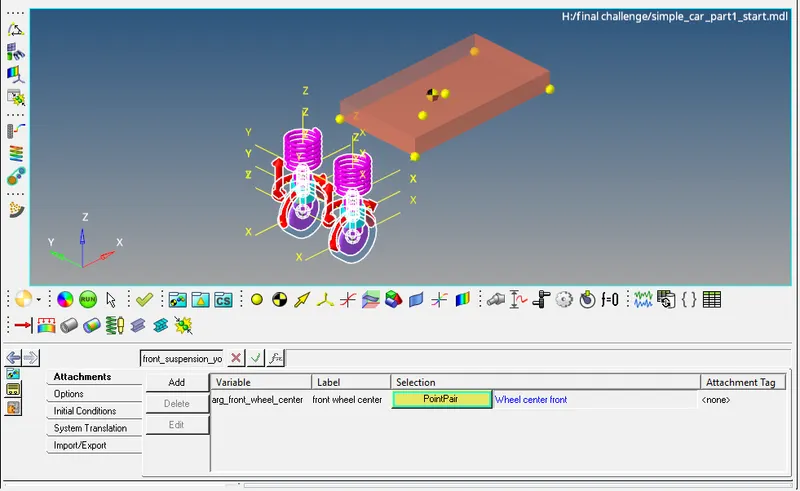
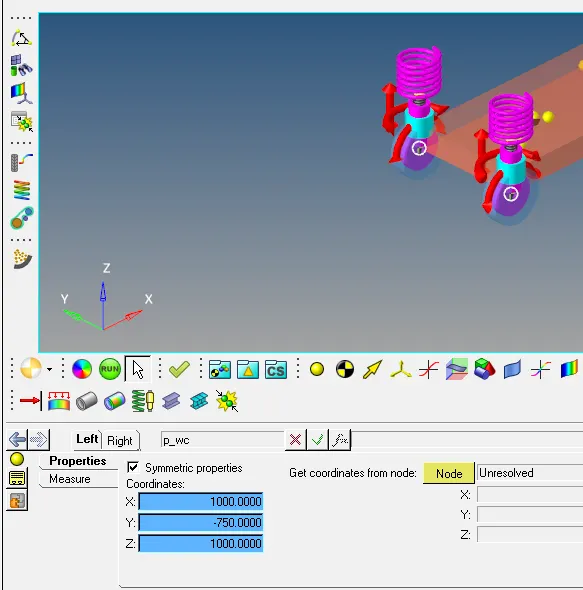
- parameterizing the hard point to attachments
- resolving the vehicle body attachments
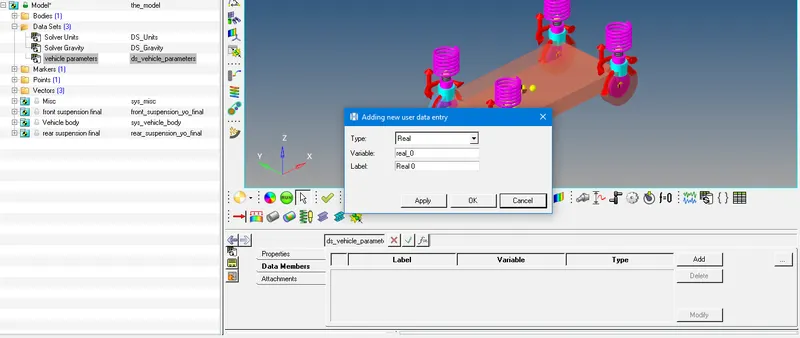
- adding a data set
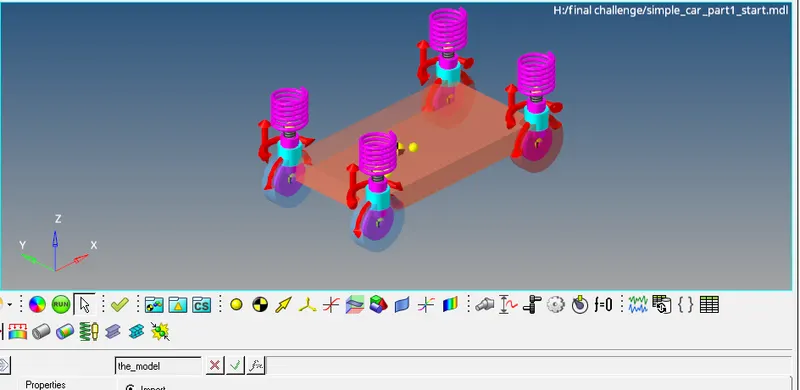
stage 3:
- importing the steering system
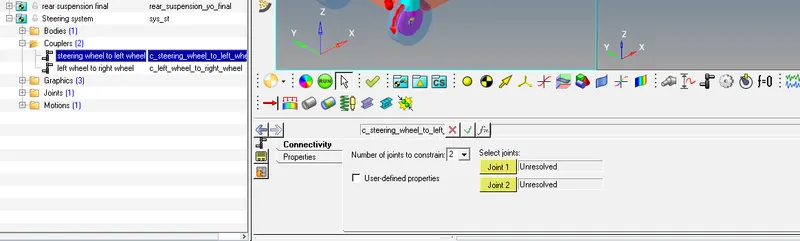
- adding couplers to the left, right, and steering wheel
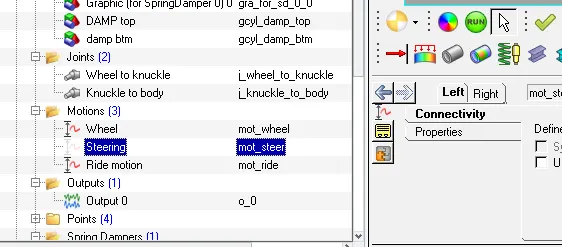
- deactivating the steering motion front and rear
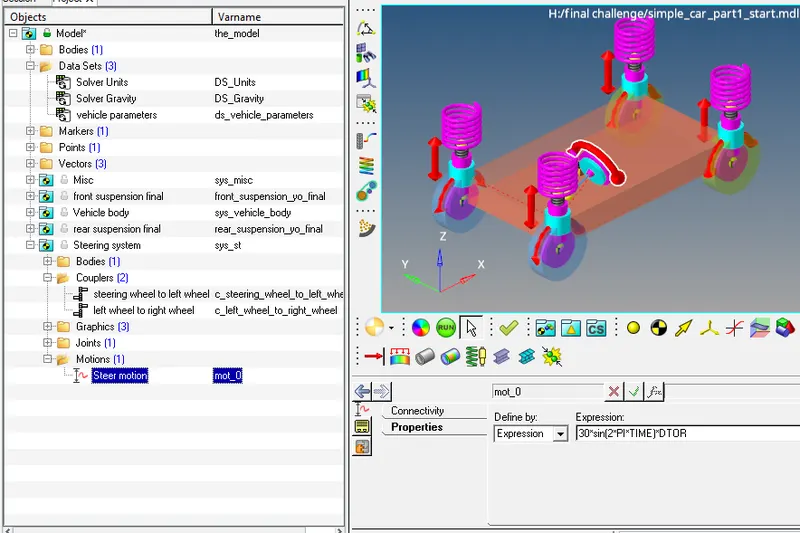
- providing the steering motion has 30*sin(2*P*time)*DTOR
- import road and add contacts
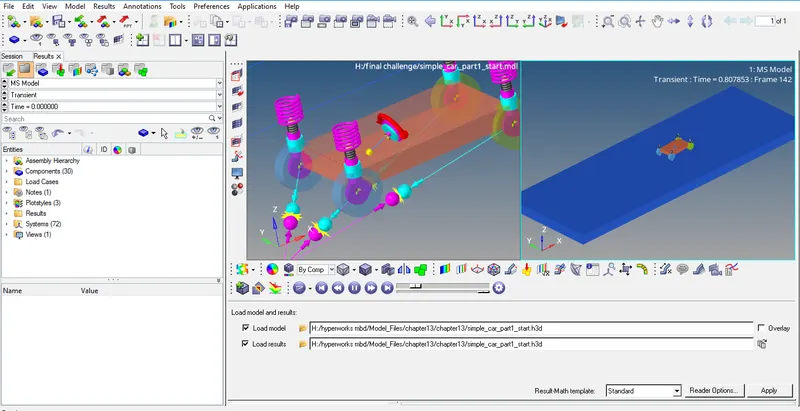
results: the entire vehicle is simulated using motion solve and motion view