Week-11 Challenge: Braking
Objective:
- Defined driving cycle , calculate the energy required for breaking.
- Discuss, Electric motor braking torque at high speed, How electric and mechanical brakes are coordinated.
- Write a program to plot contour of given motor speed , torque and efficiency values.
Answer #1
Calculation of energy required for breaking for defined driving cycle.
Drive cycle
A driving cycle is a series of data points representing the speed of a vehicle versus time. Driving cycles are produced by different countries and organizations to assess the performance of vehicles in various ways, as for instance fuel consumption, electric vehicle autonomy and polluting emissions.
From drive cycle, calculating the energy required for braking
Drive cycle is UDDS cycle which is urban dynamometer drive schedule. The data is taken for 1370s time for our simplicity of calculation we take 150 sec drive cycle time is consider. Speed which is in miles per hour has been converted into meter per second.
Drive cycle is given below
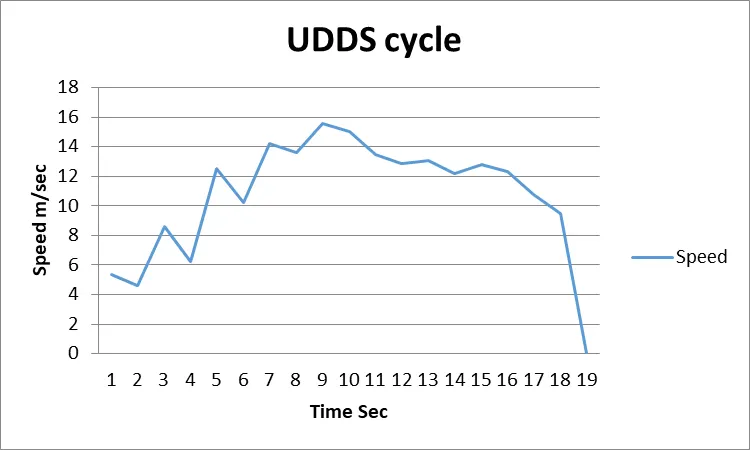
Fig -1
The equation for calculating braking energy :- The energy calculate by equation is given as follows ,
E = (1/2) * M * (Vi - Vf) ^2
Where ,
M = Mass of vehicle in Kg
Vi = Initial speed of the vehicle in m/s.
Vf = Final speed of the vehicle
From above drive cycle, we get 10 braking point. The mass of vehicle is constant is about 1500 Kg then the energy required for braking is calculate as follows:-
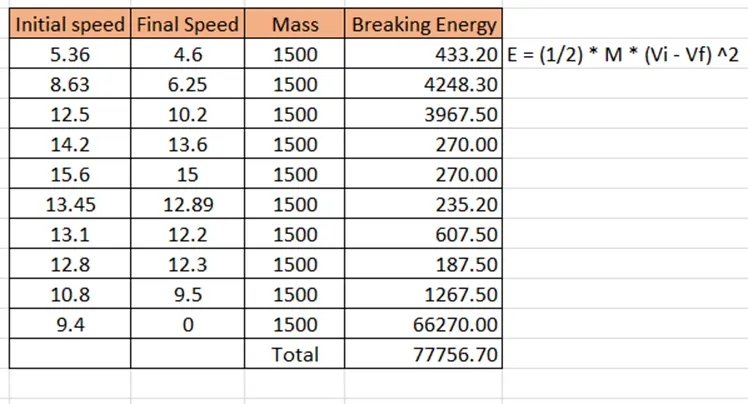
From above calculation the energy required for the braking is about 77.8 KW.
====================
Answer #2
Electric motor braking development with mechanical brakes.
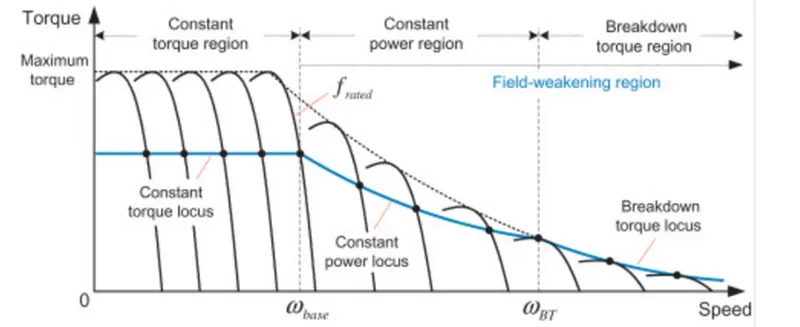
Fig -2
From above curve , we see the three region first one is constant torque region , constant second is power region, third is breakdown torque region. So at start of motor, the motor achieved the peak torque till the moment at it reaches the certain speed and after that it start rapidly drop. The reason of dropping the torque of motor because the motor shaft reaching the critical speed. The area motor achieve the peak torque and constant is called constant torque region.
The region where the torque reduce is known as constant power regionas the power generated by motor will be its peak.so the torque produced at constant power region is low this is reason where the motor does not produced braking torque in this region.
How electric brake and mechanical brake co-ordianate:-
There are two types of braking is used electric and mechanical braking system are as follows:-
1)Electric braking :-
In electric braking, the winding of the motor is used to produce the braking torque these braking torque developed during braking operation. these opeation opposes the rotation of shaft and it doing by changing the connection of motor.
Regenerative braking is a mechanism found on most hybrid and full-electric vehicles. It captures the kinetic energy from braking and converts it into the electrical power that charges the vehicle's high voltage battery. Regenerative braking also slows the car down, which assists the use of traditional brakes.
In a conventional braking system, a car slows down due to friction between the brake pads and rotors. But this system is highly inefficient when it comes to conserving energy. Nearly all of the kinetic energy propelling your car forward is lost as heat when you apply the brakes. That’s a lot of wasted energy!
Regenerative braking solves this problem by recapturing upwards of 70% of the kinetic energy that would otherwise be lost during braking. The amount of energy recovered depends on your car model and driving behaviour.
2)Mechanical braking :-
In mechanical braking , the frictional force produce between rotating part of wheel and brake drum produce require braking. to achieve these braking various mechanical part are use such as brake lining and brake drum.
Both these method co-ordinate in EV application as follows:-
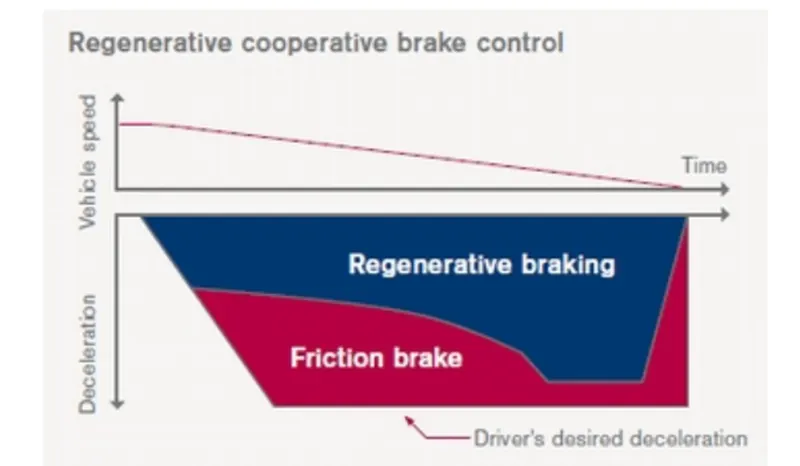
Fig -3
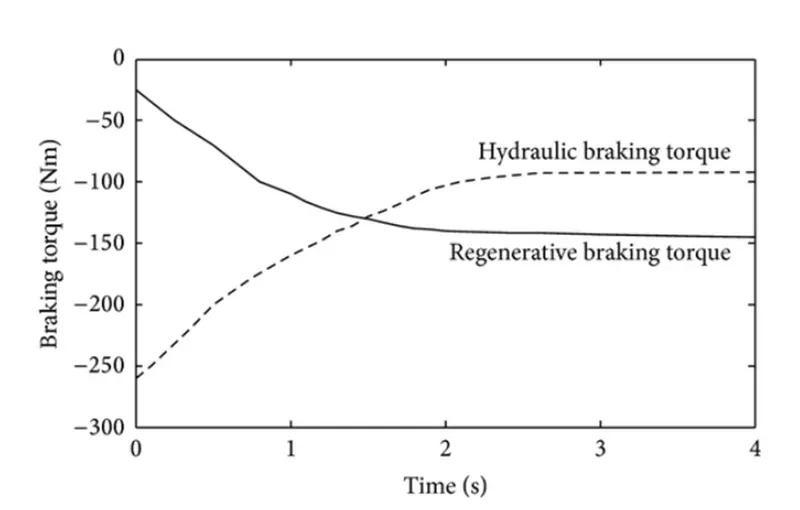
Fig -4
Fig -4 Regenerative braking torque and hydraulic braking torque,
In an Electric vehicle, at start of the vehicle the friction braking gives the 60 % contribution and regenrative braking give 40 % contribution and speed of vehicle start reduce. After some of the braking time the regenrative braking in role and provide the some of power supply back to the source . As we know the raking torque is very low at high speed at start so friction braking apply brake and slow the speed of vehicle and after that the regenrative braking in which motor act as generator and supply toward the source by producing negative torque.
======================================
Answer #3
MATLAB program for plot the contour chart of given motor speed, torque and efficiency values.
MATLAB program Coding:
Explanation:
- The starting codes using clearing all data codes.
- All speed and torque is defined as 2-dimensional linearly spaced arrays using the linspace command.
- The constant of motor losses like copper loss, iron loss, windage loss.
- 2-dimensional arrays are defined in 3-dimensionl arrays by using meshgrid command.
- Equating the equations motor losses based on the speed and torque.
- Output power is defined by using 3_dimensional speed and torque arrays.
- Input power is defined by using sum of motor losses and output.
- The Efficiency is defined ration of output power to input power, The mapping of efficiency ranges are set.
- Finally plotting the graph0.
Plot Screen shot:
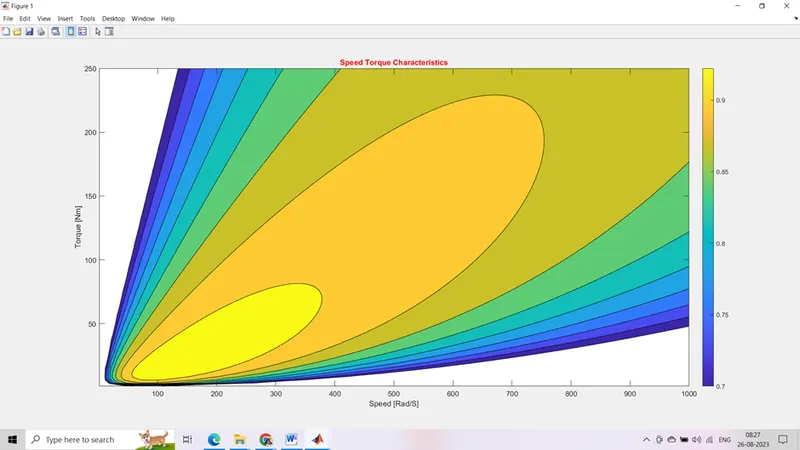
Result :
From the plot it can be observed that the speed and torque varies as efficiency increase. This is occur due to motor losses. As we see the drak blue region represent the 70% efficiency and the yellow region represnt 93% efficiency. Ex.- when it is at 70 % efficiency the torque reaches its peak value 250 Nm. it means the when the vehicle is at very low spweed the torque decrease as the speed increase for same efficviency. and at 93% efficiency the speed and torque required much less compared to an efficiency 70%. Greater the motor efficiency lower speed torque combination is required to overcome the motor losses.