Week-11 Challenge: Braking
Q1.
Driving cycle:-
The braking performance is one of the most important concerns in vehicle safety. In urban area driving, a significant amount of energy is consumed in braking. Electrification of vehicles makes it feasible to recover some of the energy lost in braking. A hybrid braking system was developed to ensure the efficient braking of the vehicle and recovering the braking energy. The design and control objectives of such a hybrid braking system are to ensure sufficient braking force to quickly reduce the vehicle speed, properly distributing the brake force to the front and rear axle, and also recover as much braking energy as possible. So understanding of braking energy of a driving cycle is important. Now, it is also important to mention that braking energy also depends upon the type of driving cycle i.e. the higher number of time the vehicle will have rapid speed changes and will come to rest then the braking energy will automatically rise for that particular drive cycle than other driving cycle where the rapid speed changes don't occur.
Breking Energy = 1/2*m*v^2
m = Mass Of vehicle(Kg)
v= velosity of vehicle(m/s)
Calculated in Matlab below
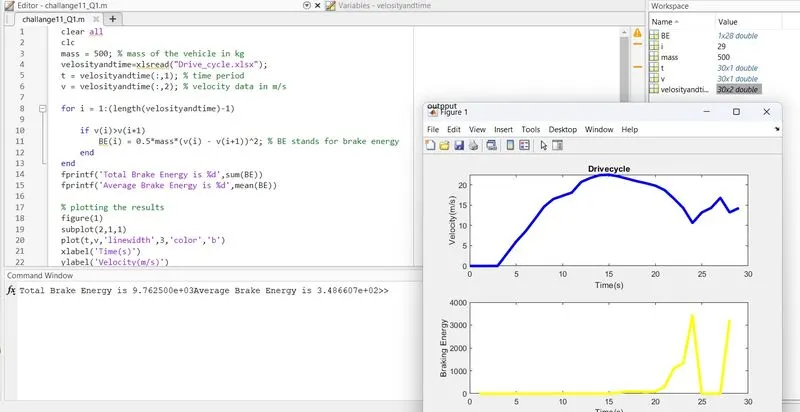
mat file also uplodate name :- challange11_Q1.m
****************************************************************************************************
Q2.
The electric motor can't develop braking torque at high speed similiar to starting because once the electric supply is pulled off from the motor,it acts as a generator and due to the flux weakening effect of the electric generator,the generator produces low torque as expected.
Regerative Braking:
Regenerative braking is an energy recovery mechanism that slows down a moving vehicle or object by converting its kinetic energy into a form that can be either used immediately or stored until needed. In this mechanism, the electric traction motor uses the vehicle's momentum to recover energy that would otherwise be lost to the brake discs as heat. This contrasts with conventional braking systems, where the excess kinetic energy is converted to unwanted and wasted heat due to friction in the brakes, or with dynamic brakes, where the energy is recovered by using electric motors as generators but is immediately dissipated as heat in resistors. In addition to improving the overall efficiency of the vehicle, regeneration can significantly extend the life of the braking system as the mechanical parts will not wear out very quickly.
The most common form of regenerative brake involves using an electric motor as an electric generator. The working of the regenerative braking system depends upon the working principle of an electric motor, which is an important component of the system. The electric motor gets activated when some electric current is passed through it. But, when some external force is applied to activate the motor (during the braking), then it behaves as a generator and generates electricity. This means that whenever the motor runs in one direction, the electric energy gets converted into mechanical energy, which is then used to accelerate the vehicle, and whenever the motor runs in the opposite direction, it performs functions of a generator, which then converts mechanical energy into electrical energy, which makes it possible to utilize the rotational force of the driving axle to turn the electric motors, which results in regenerating electric energy for storage in the battery and simultaneously reducing the speed of the car with the regenerative resistance of the electric motors. This electricity is then used for recharging the battery.
Coordination of Electric and Mechanical Brake :
In an electric Motor, the Total Brake distribution is in two aspects which are Electrical Brake which is called Regenerative Brake, and Mechanical Brake or Classical Brake with a hydraulic cylindrical system. Brake Force distribution must be uniform, If the Regenerative braking power requirement is more than the charging limit of the battery or more than the regenerative capacity of the machine we must apply Mechanical brakes as well. In a practical case, the combination of these two is applied. So usually it is a combined response of Mechanical brake and Regenerative brake. The reason for how this braking force is combined, that particular phenomena are called Brake Control Strategies. There are two Brake Control Strategies, which are Series - In case of Series, we apply Mechanical brake and Regenerative electric brake one after another. We can apply only one brake strategy at a time either apply Regeneratively or apply Mechanical brake. The Series Brake Control Strategy has a further classification, that is based on whether we want the comfort of driver or Brake behavior compared to energy efficiency. Parallel - In the case of Parallel, we apply both brakes simultaneously. This Particular Parallel braking is going to happen both at a time. Electric Driven Intelligent Brake (EDIB) is a combination of Hydraulic brake or Mechanical brake along with a Regenerative brake. It is a Parallel braking technique. The Control criteria such that at low speed use regenerative braking higher and at high speed or during the initial braking period we actually combine the both.
****************************************************************************************************
Q3
In this below MATLAB script, we create arrays for the speed and the torque of the motor using the ‘linspace’ command. For the speed, consider a range of values from 0 to 2000 radians per second whereas for the torque, consider a range of values from 0 to 300Nm. These arrays are then used to create 2D grid coordinates using the ‘meshgrid’ command. These coordinates will help in the creation of the contour plot. To find the efficiency of the motor, we need to consider the various losses that occur in the motor’s operation. These are:
- Copper losses
- Iron losses
- Windage losses
- Conduction losses
These various losses are dependent on the speed and the torque of the motor. They each also have a characteristic constant of proportionality which are all assumed for the following calculations and represented as 'K'. In each calculation, the speed and the torque are represented respectively as ω and T.
- Copper losses = KCu⋅ω2
- Iron losses =KFe⋅T2
- Windage losses =Kw⋅T3
The values of coefficients are taken as general values. Conduction losses are assumed to be 18 Joules.
Finally, we plot the contour with the 'contour' command. Besides, an array for the efficiency values we want to plot for is created called 'W' and is assigned for values ranging from an efficiency level of 0.75 to 0.95. This array is used in the creation of the contour. Axis labels and a title are also made for better readability.
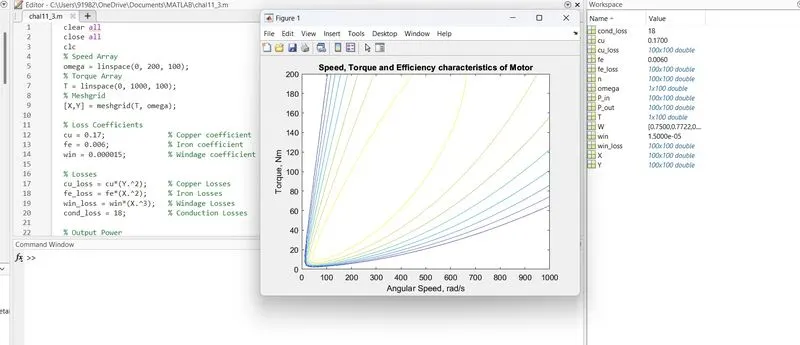
files are attched in uplod section