Project - Speed Control of a Direct Current (DC) motor
Project
Project Name :- Speed Control of Direct Current (DC) Method.
Aim :- Proportional, Integral, and Derivative (PID) control design knowledge gained in the training to design, develop and test a controller to maintain a desired speed for the motor.
Diagram :-
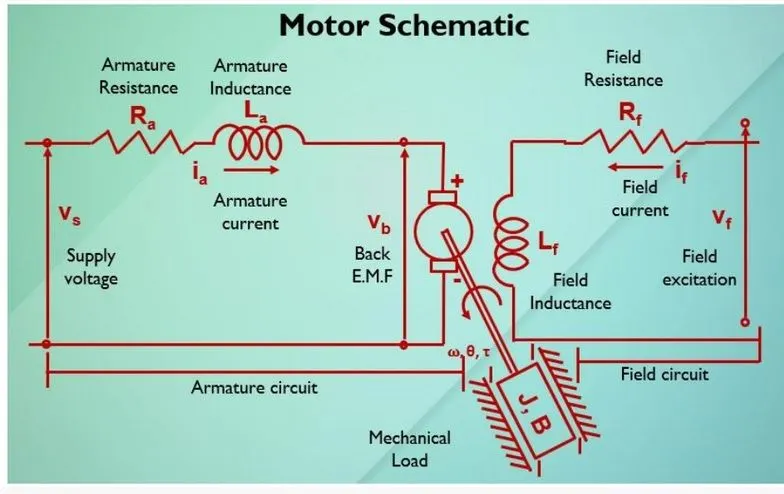
Using Kirchhoff's voltage law,
Vs = Ra*Ia+La*di/dt+Vb
Back EMF, angular velocity, and torque are related by.
Vb = Km*dtheta/dt T = Kt*i
Here, Km and Kt are the back emf and torque constants
respectively.
angular Veloscity W = theta
The Open loop transfer function for motor the speed (W) and supply voltage (Vs) can be control.
W(s)/Va(s)= Kt/JLa S^2+(JRa+BLa)S+(BRa+K-Km)
PID Design for Speed Control Of a DC Motor
Parameter
J - Moment of inertia of the rotor - 0.01 Kgm ^2
B - Motor viscous friction constant - 0.1 Nms
Km- Back EMF Constant - 0.01 V/radian /s
Kr - Motor Torque constant - 0.01 Nm/Ampere
Ra - Armature Resistance - 1ohm
La - Armature inducatancce - 0.5 Henry
Control design Objectives
Setting Time < 2S
Overshoot < 5 %
Steady State error <1 %
State Space Model
d/dt = [-B/J:KT/J:-km/La:-Ra/La] [theeta i]+ [0 L/La]Vs
Y = [1 0]
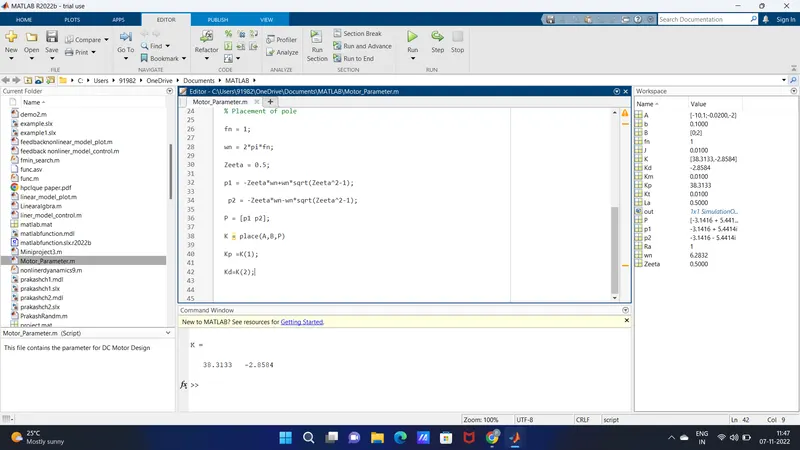
Program :-
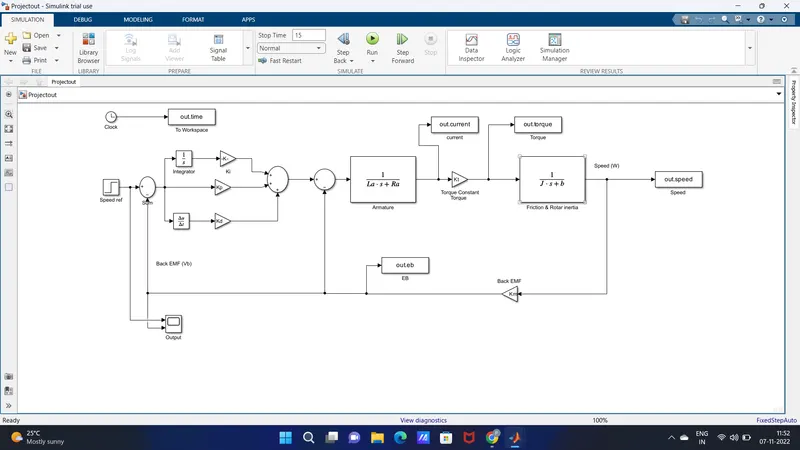
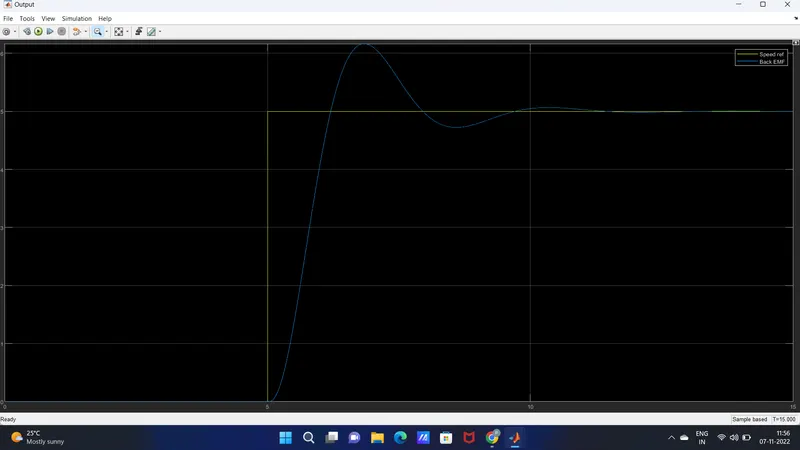
ScreeShot