Week-11 Challenge: Braking
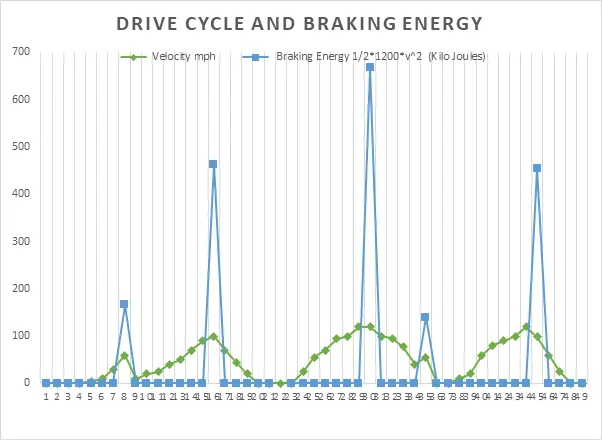
1.For a defined driving cycle, calculate the energy required for braking.
Considering a drive cycle with various braking intervals and hence calculating the braking energy required at corresponding braking interval.
Consider mass of vehicle m = 1200 Kg.
We know the braking energy when brakes are applied while vehicle is in motion is given by
Eb=12×mv2">Eb=12×mv2Eb=12×mv2
DRIVE CYCLE DATA WITH BRAKING ENERGY CALCULATION
|
Time |
Velocity m/s |
Velocity mph |
Braking Energy ½*m*v^2 (Kilo Joules) |
|
0 |
0.00 |
0 |
0 |
|
1 |
0.00 |
0 |
0 |
|
2 |
0.00 |
0 |
0 |
|
3 |
0.00 |
0 |
0 |
|
4 |
1.39 |
5 |
0 |
|
5 |
2.78 |
10 |
0 |
|
6 |
8.33 |
30 |
0 |
|
7 |
16.67 |
60 |
166.6666667 |
|
8 |
2.78 |
10 |
0 |
|
9 |
5.56 |
20 |
0 |
|
10 |
6.94 |
25 |
0 |
|
11 |
11.11 |
40 |
0 |
|
12 |
13.89 |
50 |
0 |
|
13 |
19.44 |
70 |
0 |
|
14 |
25.00 |
90 |
0 |
|
15 |
27.78 |
100 |
462.962963 |
|
16 |
19.44 |
70 |
0 |
|
17 |
12.50 |
45 |
0 |
|
18 |
5.56 |
20 |
0 |
|
19 |
0.00 |
0 |
0 |
|
20 |
0.00 |
0 |
0 |
|
21 |
0.00 |
0 |
|
|
22 |
0.00 |
0 |
0 |
|
23 |
6.94 |
25 |
0 |
|
|
|
|
|
PLOT
2.Why electric motor can’t develop braking torque at high speed similar to starting? How electric and mechanical brakes are coordinated?
Let us consider the torque speed characteristics.
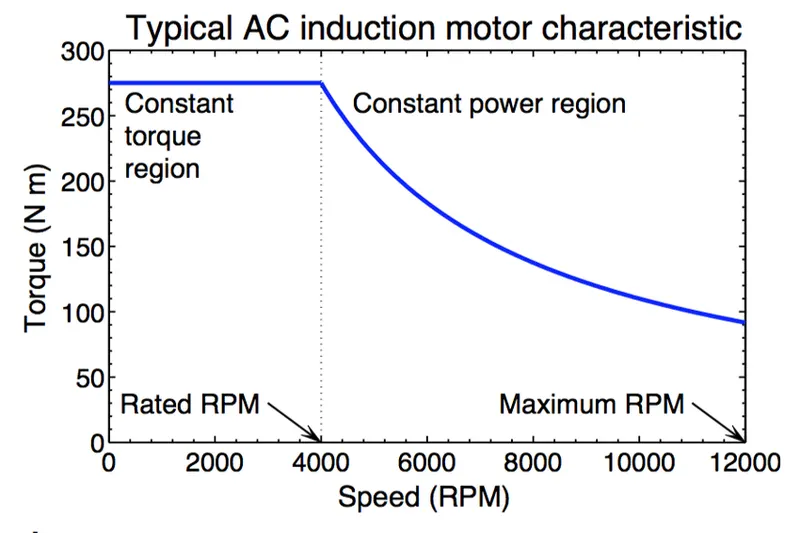
- From this curve we have two region, constant torque and constant power region. At the start the motor achieves peak torque till it reaches a certain motor speed range from where it will rapidly drop. The reason due to the drop in torque is due to the motor shaft reaching critical speed and the area where the peak torque is constant is known as the constant torque region of the motor. The region where the torque decreases is known as the constant power region as the power generated by the motor will be at it's peak.
- Since the torque produced at the constant power region is very low, it is not possible to develop enough braking torque in this region. The braking torque produced increases as the speed decreases.
How are electric brakes and mechanical brakes co-ordinated?
- In electric vehicles, two types of braking systems are used electric brake system and mechanical brake system.
Electric Braking System: In electrical braking, the winding of the motor is used to produce a braking torque. A braking torque is developed during the braking operation. This braking torque opposes the motion of the rotating member or shaft. This is achieved by suitably changing the electrical connections of the motor. The motor operates on a speed–torque characteristic, depending upon the method of braking employed.
Mechanical Braking System: In mechanical braking, the frictional force between the rotating parts and the brake drums produces the required braking. To achieve this, mechanical equipment, such as brake linings and brake drums, are required. Whether electrical or mechanical, the braking of the drive should stop the motor at the specified point of time and position.
- The electric braking system used in EVs and HEVs is regenerative braking. This method uses the motor as a generator during braking, developing a retarding torque, which acts on the running motor and halts it. The kinetic energy and potential energy, minus the losses of the motor are returned to the mains and the motor runs at a constant speed. Thus, regenerative braking eliminates the tendency of the load to accelerate the motor.
- Mechanical braking systems used can be either disc or drum brake system. Where in case of a disc brake system friction pads rub against a disc when the brake pedal is applied and the kinetic energy is converted to heat and slows the vehicle down. In a drum brake system a set of brake shoes which are the friction materials press against a drum.
- Since the braking torque is very less at high speeds, mechanical brakes are applied to slow down the vehicle. As the motor reaches the constant torque region the regenerative braking system takes effect where the motor acts as a generator and the negative torque produced charges the battery pack.
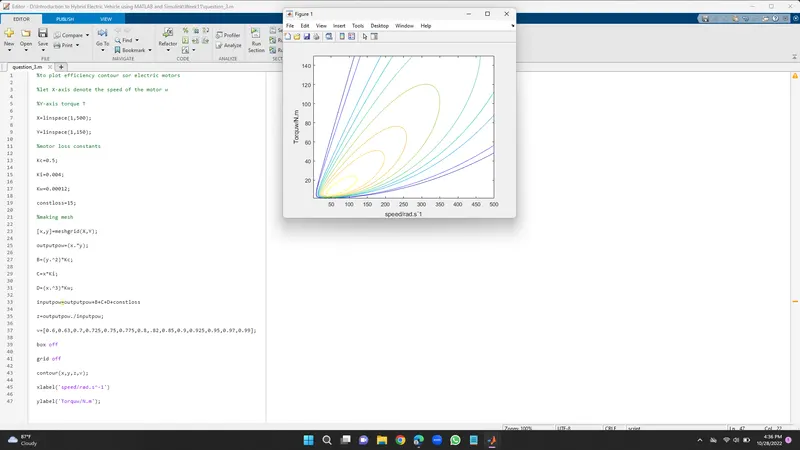
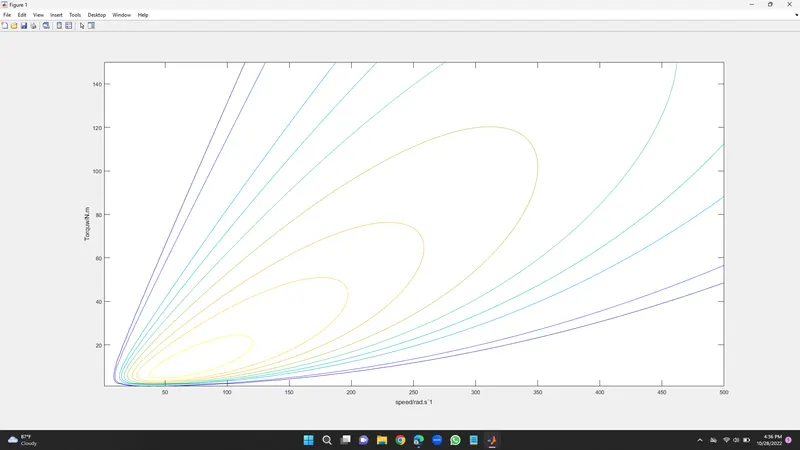
3.Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all the plots.
Copper loss-I2R">I2RI2R:where R is Armature resistance and torque is proportional to current, the copper loss can be considered as kc.T2">kc.T2kc.T2 where kc">kckcis to take care of resistance of brushes and also take care of flux and its effect.
Cu losses = kc.T2">kc.T2kc.T2
Iron loss: Iron losses are nothing but magnetic losses, which is denoted by ki.ω">ki.ωki.ω, where Ki factor is based in the magnetic field effect. For permanent magnets have constant magnetic field and this iron losses is based on the value of Ki and this are going to change according to the speed. At Various speed have different value of back EMF and that is going to affect the iron losses
Iron losses=ki.ω">ki.ωki.ω
Windage losses: This is mechanical or friction of windage losses. This is based on size of shape of motor and the amount of windage losses that the motor is going to experience.
Windage losses =kw.ω3">kw.ω3kw.ω3
Total losses : The Total losse are considering the above four losses and denoted as,
Total losses= kc.T2+ki.ω+kw.ω3+C">kc.T2+ki.ω+kw.ω3+Ckc.T2+ki.ω+kw.ω3+C
All motors are model as per the above equation of losses.
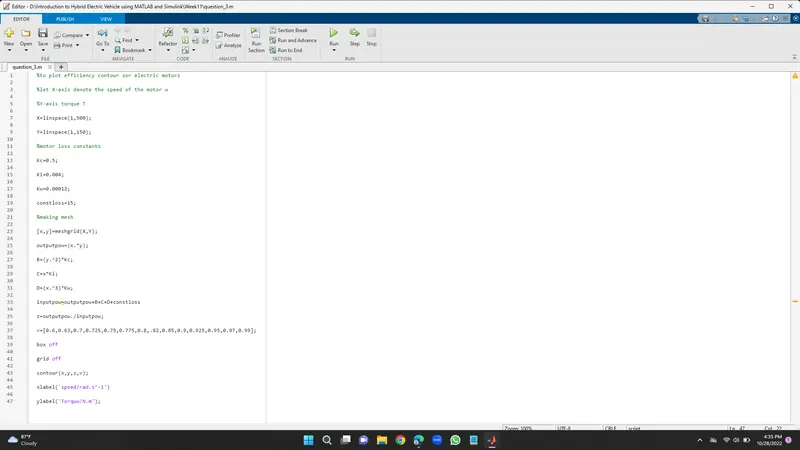
MATLAB PROGRAM TO PLOT THE MOTOR-SPEED-TORQUE CONTOUR EFFICIENCY:
%to plot efficiency contour sor electric motors
%let X-axis denote the speed of the motor w
%Y-axis torque T
X=linspace(1,500);
Y=linspace(1,150);
%motor loss constants
Kc=0.5;
Ki=0.004;
Kw=0.00012;
constloss=15;
%making mesh
[x,y]=meshgrid(X,Y);
outputpow=(x.*y);
B=(y.^2)*Kc;
C=x*Ki;
D=(x.^3)*Kw;
inputpow=outputpow+B+C+D+constloss
z=outputpow./inputpow;
v=[0.6,0.63,0.7,0.725,0.75,0.775,0.8,.82,0.85,0.9,0.925,0.95,0.97,0.99];
box off
grid off
contour(x,y,z,v);
xlabel('speed/rad.s^-1')
ylabel('Torquw/N.m');