Week-11 Challenge: Braking
Question1: For a defined driving cycle, calculate the energy required for braking.
CASE1:
considering the velocity of a vehicle from 63 sec to 74 sec
kerb weight = 800kg
payload = 400kg
total weight (m) = 1200kg
initial velocity(V_i) = 80kmph = 22.22m/sec
final velocity(V_f) = 0 kmph
time taken to decelerate the vehicle = 11sec
1.energy required for braking:
E = 1/2.m.(Vi - Vf)
= 1/2*1200*(22.2 - 0) = 13.320kj
2.force required for braking:
F = m.d
where d = (V_i - V_f/t) t = time in sec
F = 1200.(22.2-0/11) = 2.42KN
3.power required for braking:
P = F.(Vi-Vf)
= 2.42(22.2-0) = 53.72kw
CASE2:
considering the velocity of a vehicle from 31sec to 41 sec
kerb weight = 800kg
payload = 400kg
total weight (m) = 1200kg
initial velocity(V_i) = 59kmph = 16.38m/sec
final velocity(V_f) = 30 kmph = 8.3m/sec
time taken to decelerate the vehicle = 10sec
1.energy required for braking:
E = 1/2.m.(Vi - Vf)
= 1/2*1200*(16.38 - 8.3) = 4.848kj
2.force required for braking:
F = m.d
where d = (V_i - V_f/t) t = time in sec
F = 1200.(16.38-8.3/10) = 0.881KN
3.power required for braking:
P = F.(Vi-Vf)
= 0.881(16.38-8.3) = 6.130kw
Question2:Why electric motor can’t develop braking torque at high speed similar to starting?
A running motor may be brought to rest quickly by either mechanical braking or electrical braking. The mechanical braking is applied by means of mechanical break shoes. Hence the smoothness of mechanical braking is dependent on the surface and physical condition of brakes. Smooth braking of a motor can be achieved by electric braking.
Electric Braking
The electric braking of a DC motor is of three types, (i) Rheostatic or dynamic braking, (ii) Plugging or reverse current braking and (iii) Regenerative beaking.
(i) Rheostatic or dynamic braking:
In case of DC shunt motors, armature is disconnected from the supply and a rheostat (variable resistor) is connected across it. The field winding is left connected across the supply. Obviously, now armature is driven by the inertia and hence machine starts acting as a generator. Thus the machine will now feed the current to the connected rheostat and heat will dissipate at the rate of I2R. Braking effect is controlled by varying the resistance connected across the armature.In case of DC series motor, motor is disconnected from the supply and field connections are reversed and a rheostat is connected in series. The field connections are reversed to make sure that the current through field winding will flow in the same direction as before.
(ii) Plugging or Reverse current braking:
In this method, armature connections are reversed and hence motor tends to run in opposite direction. Due to reversal of the armature terminals, applied voltage V and back emf Eb starts acting in the same direction and hence the total armature current exceeds. To limit this armature current a variable resistor is connected across the armature. This is similar for both series and shunt wound methods. Plugging gives greater braking torque as compared to rheostatic braking. This method is generally used in controlling elevators, machine tools, printing presses etc.
(iii) Regenerative braking:
Regenerative braking is used where, load on the motor has very high inertia (e.g in electric trains). When applied voltage to the motor is reduced to less than back emf Eb, obviously armature current Ia will get reversed, and hence armature torque is reversed. Thus speed falls. As generated emf is greater than applied voltage (machine is acting as a DC generator), power will be returned to the line, this action is called as regeneration. Speed keeps falling, back emf Eb also falls until it becomes lower than applied voltage and direction of armature current again becomes opposite to Eb.
speed and torque characteristics in dc motor:
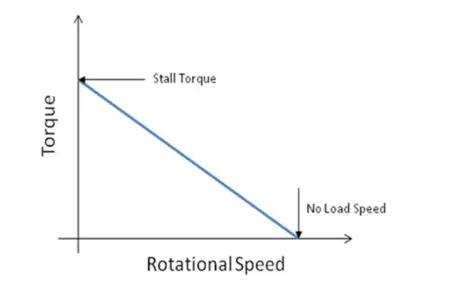
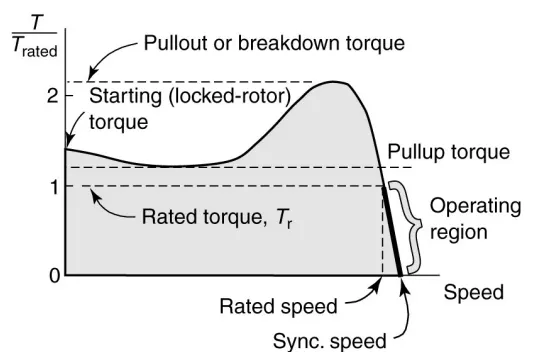
Here in the both cases of AC and DC motors there is no torque at maximum speed,gradually the torque decreases at high speed as the speed tends to be maximum speed. this situation does not occurs at the beginning of the acceleration because most of the torque is used to increase the kinetic energy of the load but when the speed is already high and no extra nload is applied it is not possible to increase
the torque as well as to develop the braking torque.The braking operation happens in the motion which is being distributed as per the brake energy and the regenerative braking.
How electric and mechanical brakes are coordinated?
mainly two ways in braking in EV they are
1.series:Regenrative braking and mechanical braking braking applied one after another
2.parallel:Both regenrative braking and mechanical braking applied simantaneously
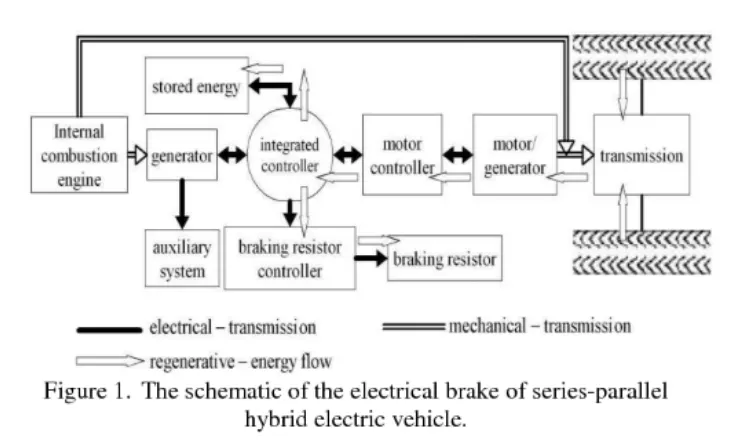
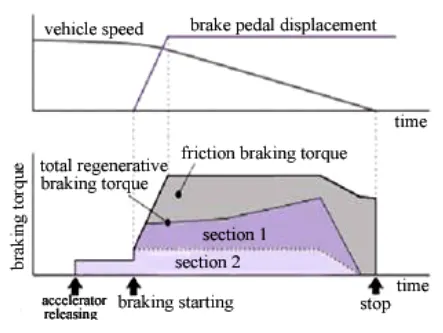
When brake pedal is pressed the hydraulic fluid reaches the brake piston and created the braking pressure on the wheels and the same kinetic energy is been used by the regenrative braking for generative more power using the bidirectional motor which operatives as a generator while braking.
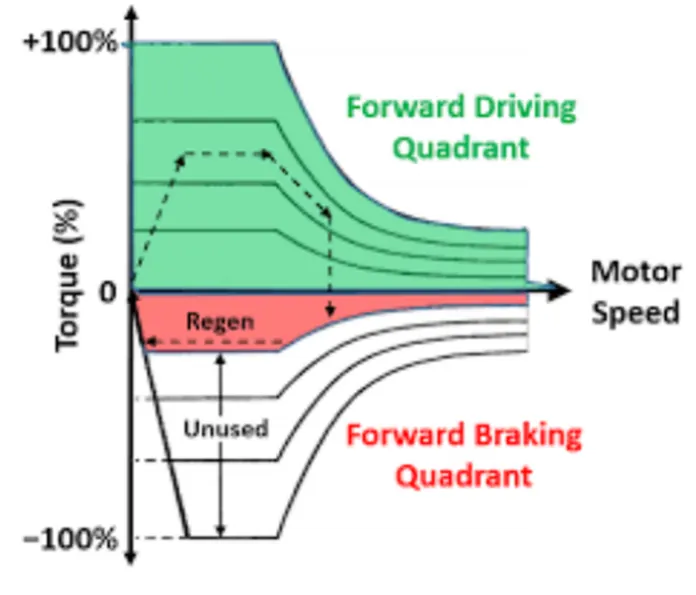
The torque and speed characteristics of the braking system as follows:
Question 3: Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all the plots.
MATLAB CODE: This matlab code script file attached below.
clear all close all clc
%inputs %speed array(W) W = linspace(0,1000,250); %torque array(T) T = linspace(0,250,250);
%loss coefficients %copper losses(Kc) Kc = 0.20; %iron losses Ki = 0.008; %windage losses(Kw) Kw = 0.000018;
%meshgrid [X,Y] = meshgrid(W,T); copper_loss = (Y.^2)*Kc; iron_loss = X.*Ki; windage_loss = (X.^3)*Kw; c = 25;
%output power(P_o) P_o = X.*Y; %input power(P_in) P_in = P_o + (copper_loss + iron_loss + windage_loss + c);
%Efficiency(E) E = (P_o./P_in); n = linspace(0.7,0.95,10); contour(X,Y,E,n) Xlim(0,1000) Ylim(0,250) xlabel('speed(rad/sec)') ylabel('torque(N_m)')
Initially provide input parameters,motor speed,torque and loss coefficients next calculate the losses by meshgrid of motor speed and torque using Meshgrid() command Next calculate output power,input power and efficiency A nd next step is plot the contour pf motor speed,torque and efficiency
results:
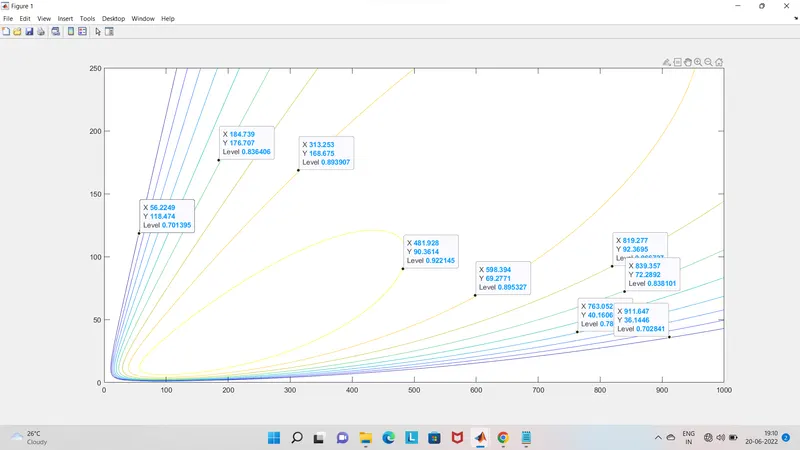
Take Matlab reference from Video 51,52 for breaking and make contour line program from video 54 as per matlab code making and result come.