Week-4 Challenge WOT Condition Part-2
Aim - To Study on Powertrain Blockset in MATLAB .
1) What is the difterence between mapped and dynamic model of engine, motor and generator How can
you change model type.
2) How does the model calculate miles per gallon? Which factors are considered to model fuel flow
3) Run the HEV Reference Application with WOT drive cycle. Change the grade and wind velocity in
the environment block. Comment on the results.
4) Keeping all other parameters same, compare the simulated results of hybrid and pure electric
powertrains.
A) Difference between mapped and dynamic model of engine, motor and generator.
-Powertroin Blockset provides two types of engine models mapped and dynomic. Mapped engines represent macro engine behavior as a set of lookup tables (broke torque, fuel flow, air mass flow, exhaust temperature, efficiency, and emissions) as functions of commanded load and measured engine speed. Dynamic engines decompose engine behavior into individual component models that account for engine dynamics, most notably intake airflow and turbocharger dynamics. You con switch between engine model types based on your application. Dynamic engine models are suitable for designing control, estimator, and diagnostic algorithms that depend on dynamic subsystem states, for example, in closed-loop AFR control algorithm development. Mapped engine models ore suitable for analysis and design activities thot do not require engine subsystem dynamic characteristics, for example, in engine and transmission powertrain matching analysis for fuel economy, emissions, and performance tradeoffs.
Mapped Model: —
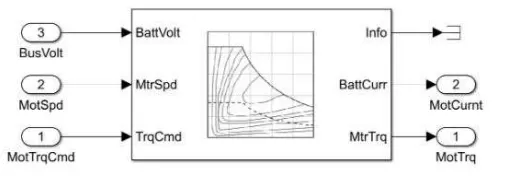
1) It uses a prebuilt data in lookup table for the simulation of powertrain block set.
2) In mapped model the calculations are very fast.
3)Electric losses are need to be specified if present.
4)Mapped model known as macro model.
Dynamic Model: -
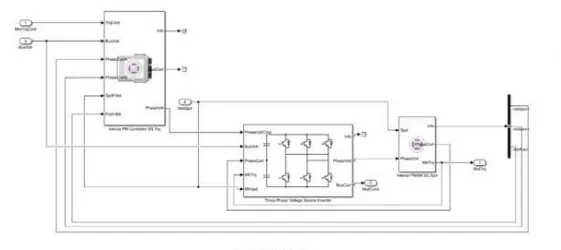
1) It uses real time data for calculating every behavior of vehicle characteristic like speed, velocity, drag, wheel braking etc.
2) In dynamic model the calculations are time consuming.
3)Dynamic model its known as micro model.
B) Changing Model Type:-
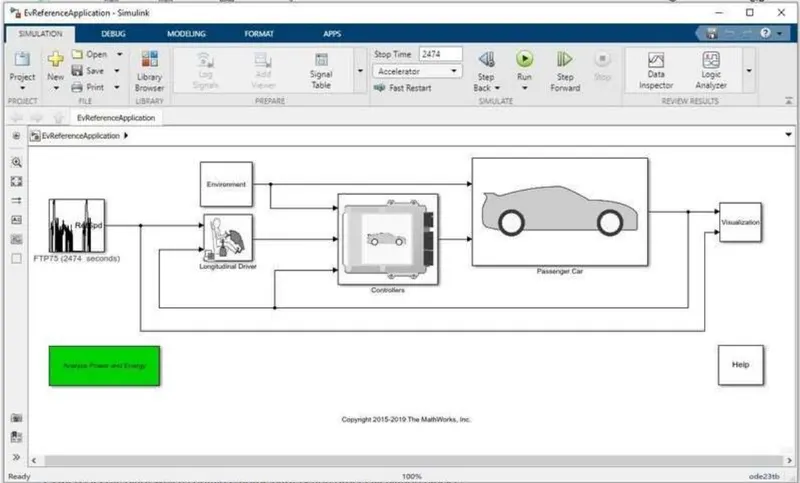
• Open ‘EV Reference Application‘ in powertrain blockset of MATLAB as shown in figure below.it is a Simulink model which consist of Drive cycle, Environment conditions, Longitudinal Driver controllers and Passenger Car.
NOTE:— For results open visualisation.
• Now open the passenger car Block and select the Electric plant block as shown in the figure below.
• Then select the ’MotGenEVMapped’ block as shown below.
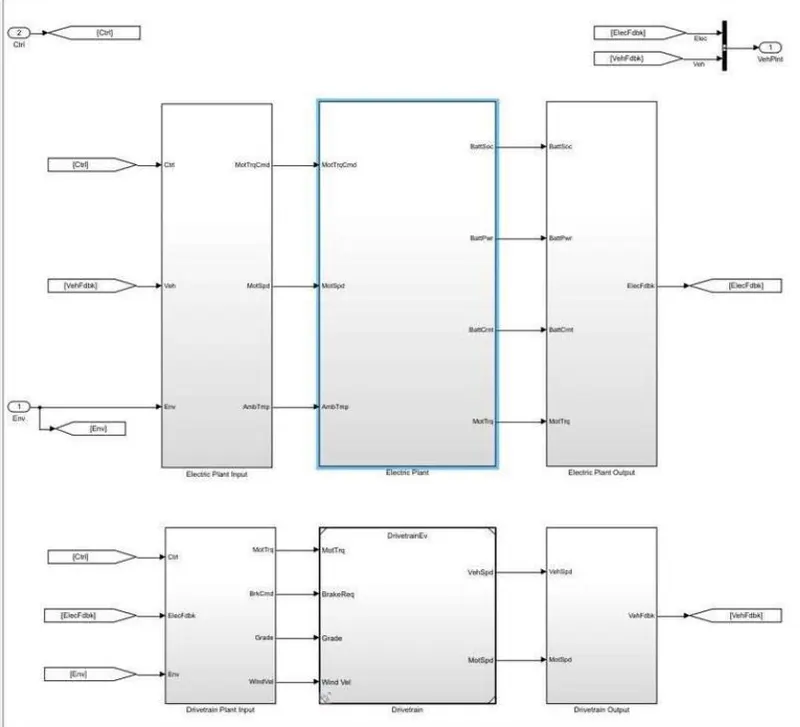
• From the below figure it is clear that by default mapped motor is selected.
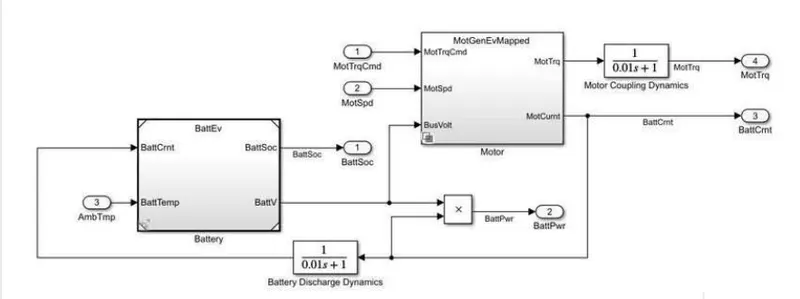
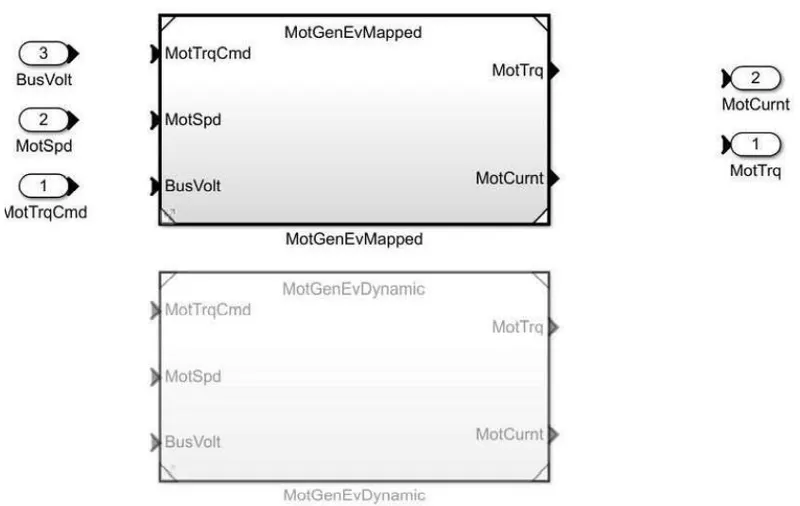
• Now for changing mapped to dynamic bIockset,right click on the screen and select variant. Then select Label Mode Active Choice and select MotGenEvDynamic.
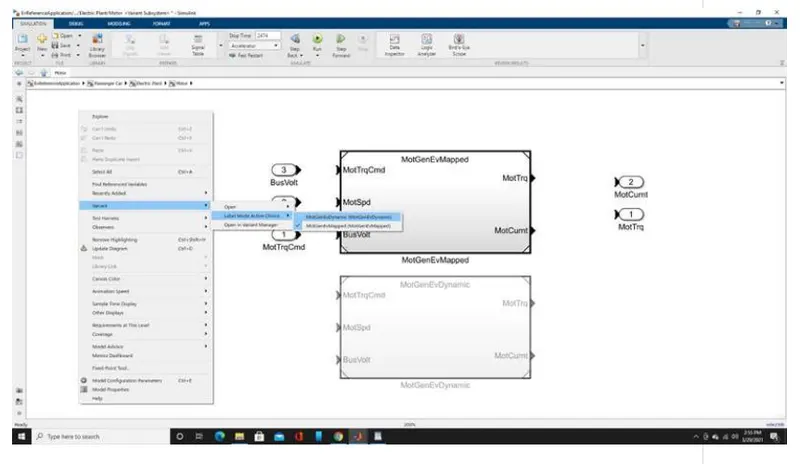
• Similarly we can change from dynamic to mapped by selecting MotGenMopped option.
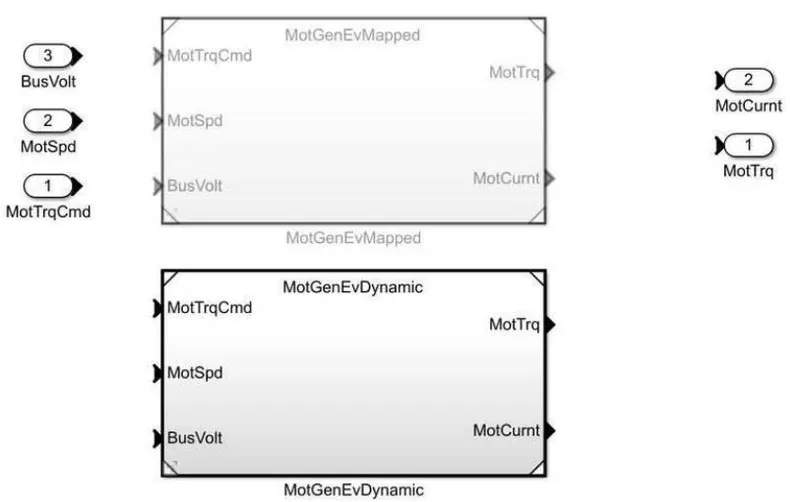
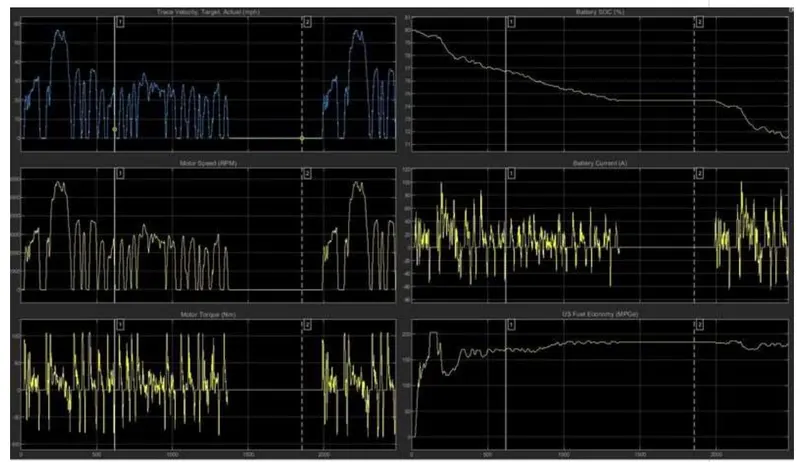
results:- By clicking on Run the results obtained when FTP75 drive cycle is used with a simulation time of 2474 sec is shown below. the result graph is obtained in visualisation block.
Solution 2:-
Miles per gallon (MPG) is a fuel economy rating determined by how far a car can travel on a gallons of gasoline or diesel. Although the metric version would be kilometres per litre, MPG is adopted in
many metric-system countries, like Canada. While it is both cheaper and better for the environment to achieve a higher MPG rating, there is a curve, that the EPA calls the "MPG Illusion" that shows the cost-benefits of increasing MPG decrease with higher rating. For example, to travel 1,000 miles, a car that gets 10 MPG will require 100 gallons of fuel. Conversely, a car thot gets 15 MPG will require 67 gallons of fuel. In this case, an increase of just 5 MPG cuts fuel consumption by 33%. When a car gets 30 MPG, however, increasing its mileage to 35 MPG will only save 5 gallons of fuel over 1,000 miles.
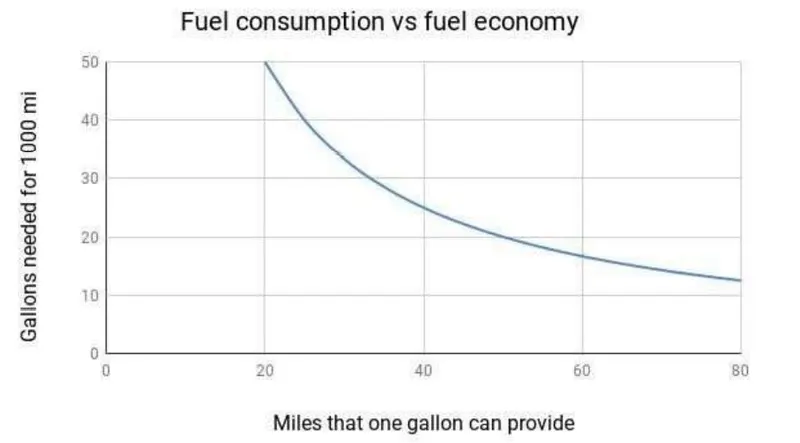
From the above data it is clear that the fuel economy (MPG) is high in Electric vehicles.
Calculation of miles per gallon in EV Reference Application’ model -
1) Open EV reference application model in MATLAB and inside the visualisation block we can see the blocks which are used for calculation of MPG.
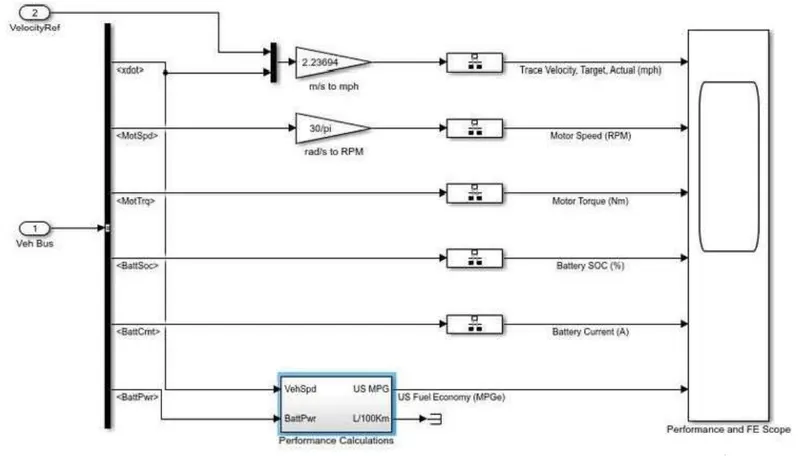
2)Now open the performance calculation block as shown below figure.
Note:-
• 264.172 US Gallons = 1000L
• 1 Galton = 33.7 Kilowatt hours of Energy in electric vehicles.
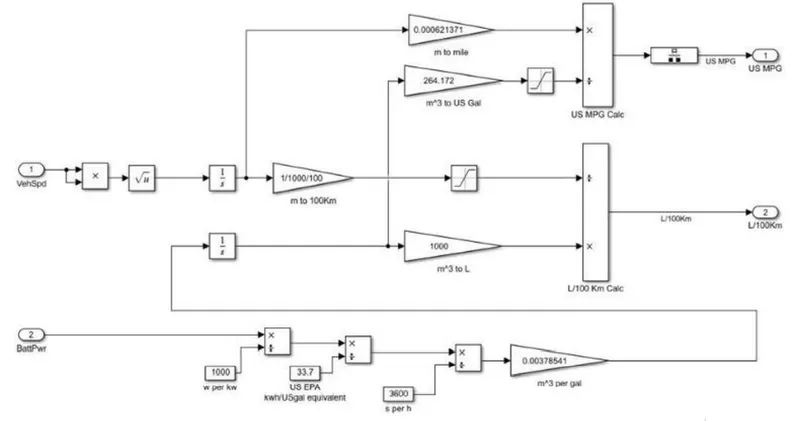
1)Here vehicle speed (x) is multiplied itself and then square rooted . The value is then integrated (1/s) and converted into meters(m) Then the meters(m} is converted into miles in the block (m to
mile) then it is divided by US Gal to get US MPG.
2) For US Gallon we need to divide battery power divided by 1000 and then divide by 33.7. Now it is converted from sec to hours by dividing with 3600 then it is converted to m^3 per gal.
3) The value is finally converted into Gallon and used as MPG after dividing miles with gallon.
Factors considered in model fuel flow:-
1)Battery power Capacity should be high and vehicle power consumption should be low for higher MPGe (Miles Per Gallon equivalent).
2)vehicIe speed
Solution 3. 'HEV Reference Application' with WOT drive cycle.
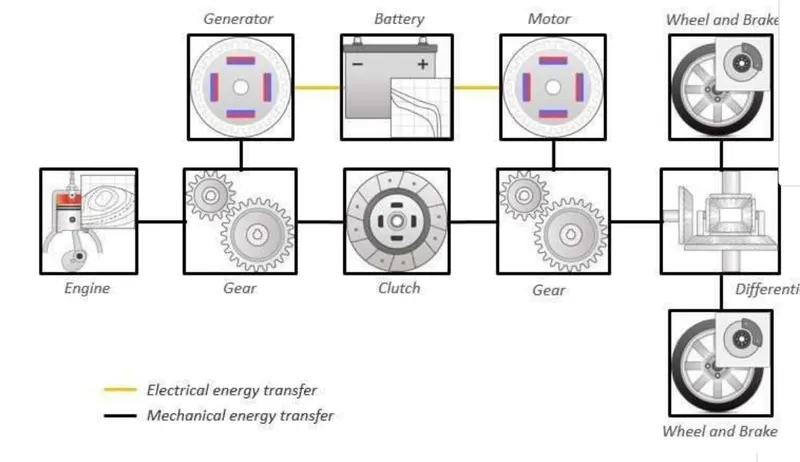
The hybrid electric vehicle reference application represents a full multimode hybrid electric vehicle (HEV) model with an internal combustion engine, transmission, battery, motor, generator,
and associated powertroin control algorithms. Use the reference application for powertrain matching analysis and component selection, control and diagnostic algorithm design, and hardware—in—
the-loop (HIL) testing.
By default, the HEV multimode reference application is configured with:
• Mapped motor and generator.
• l.5L spark ignition (SI) dynamic engine.
This diagram shows the powertrain configuration.
HEV Reference Application model:-
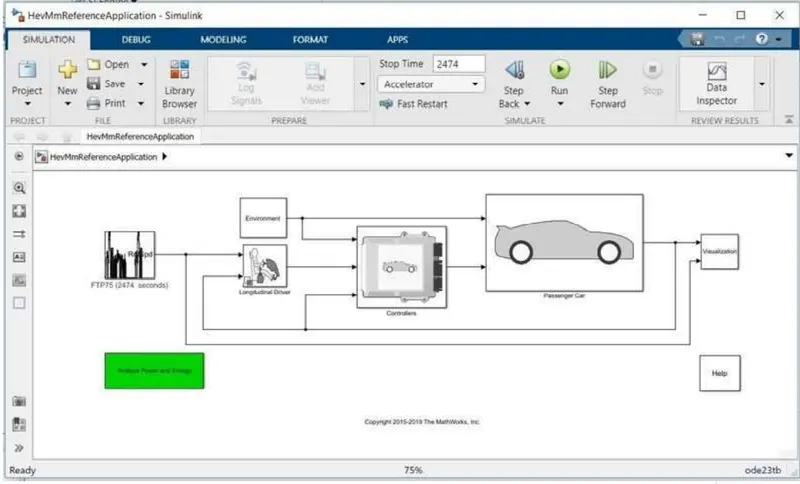
Description:-
1) Open ‘HEV Reference Application‘ model in MATLAB.
2) it consist of various subsystems which are simular to ’EV Reference Application‘ but the complexity is more in ‘HEV Reference Application‘ model.
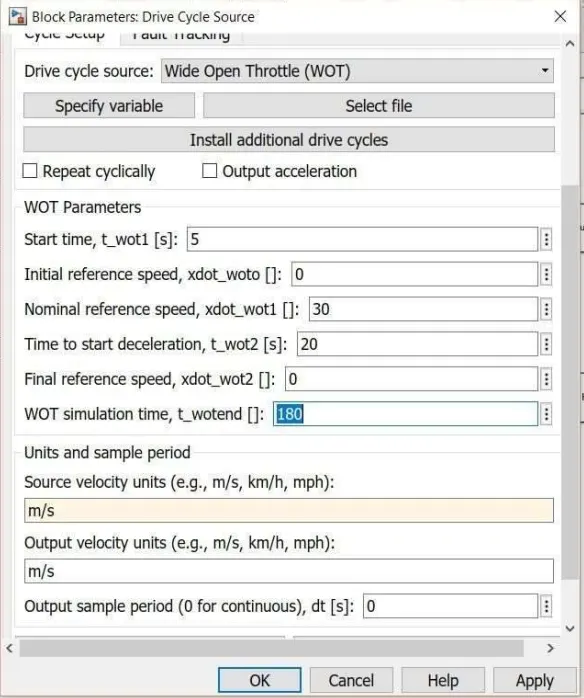
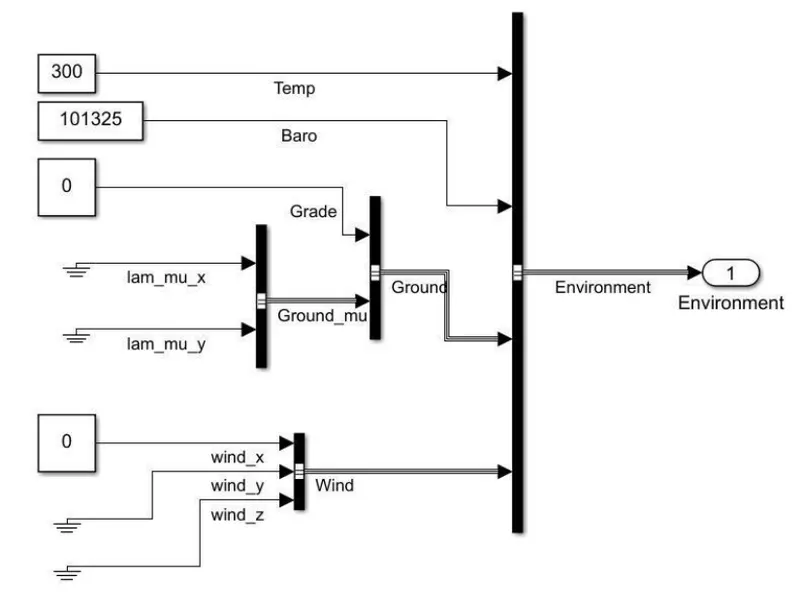
Case 1”- The default drive cycle is FTP75 with 2474 sec. Now change it to WOT drive cycle as below with WOT
simulation time as 180 sec and click on ’OK’.
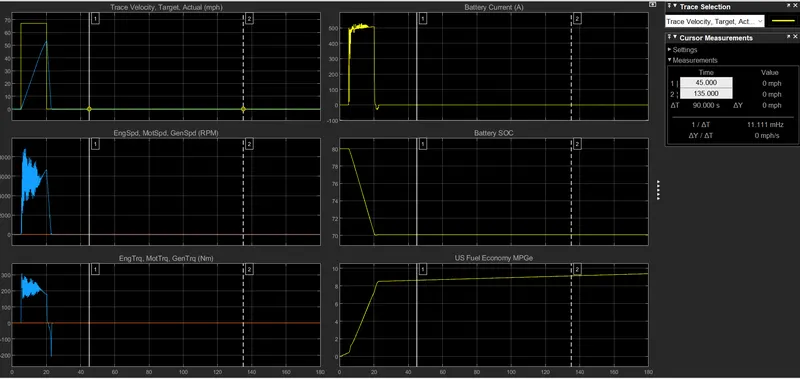
Result:-
1) The target velocity actual was able to achieve 67.1 mph.The battery current was increased upto 500 Amp and maintained for a duration of 14 sec.
2)Engine speed is able to achieve 8000 RPM and battery State of Charge(SOC) was decrease from 80 to72.
3) Engine torque increases intially and goes to negitive after 20th second and the peak torque achieve was around 275 Nm. The fuel economy was increased from 0 to 16 and remains constant.
Output Graph I:-
Case2:-
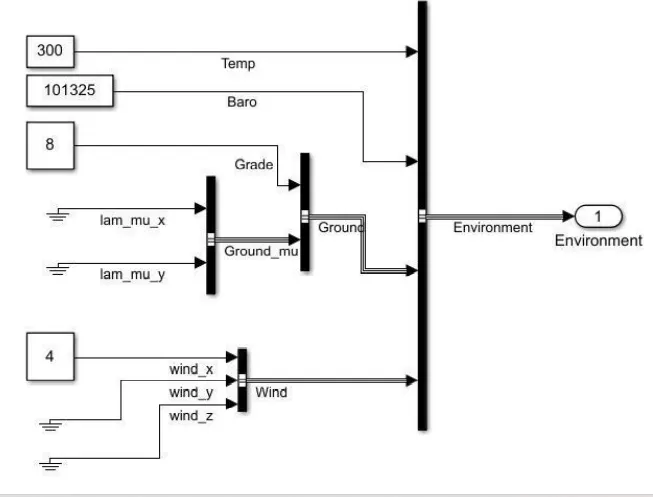
-Now changing the Environment sub-system in cased specification of HEV reference application. The grade was now changed from 0 to 8 and wind velocity from 0 to 4.
Enviroment Block:-
Output Graph 2:-
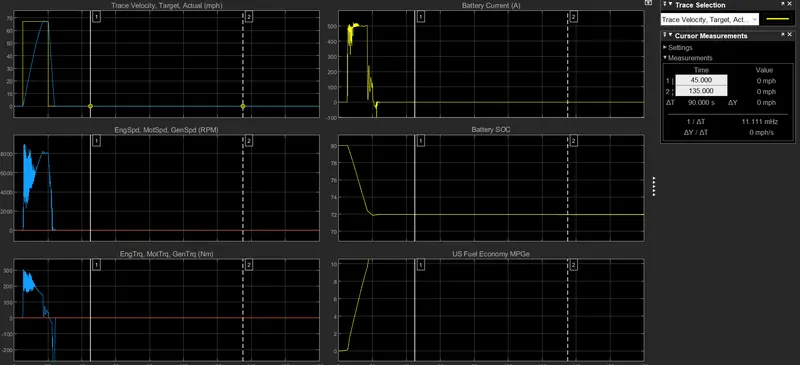
Result:-
1) The target velocity actual was only able to achieve 50.4 mph.The battery current was increased upto 500 Amp and maintained for a duration of 14 sec.
2)Engine speed was able to achieve 8000 RPM but for a small duration of time and battery State of Charge(SOC) was decrease from 80to70.
3) Engine torque increases intially and goes to negitive after 20th second and the peak torque achieve was around 275 Nm. The fuel economy was increased from 0 to 8.7 and remains constant.
Solution 4 :-
Case 1:- HEV Multimode Reference Application
1) open Hev Reference Application model in MATLAB.
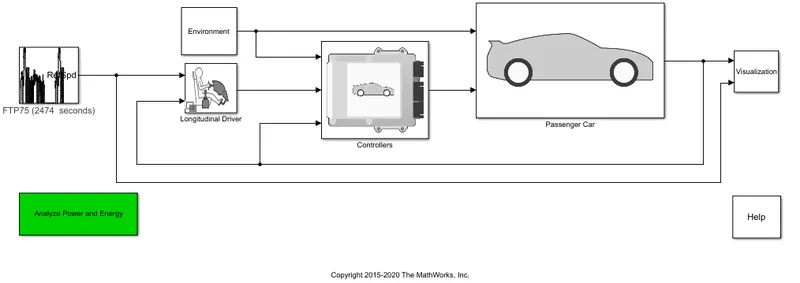
2) The model consist of Environment, Drive cycle, Longitudinal Driver passenger and visualisation Subsystem.
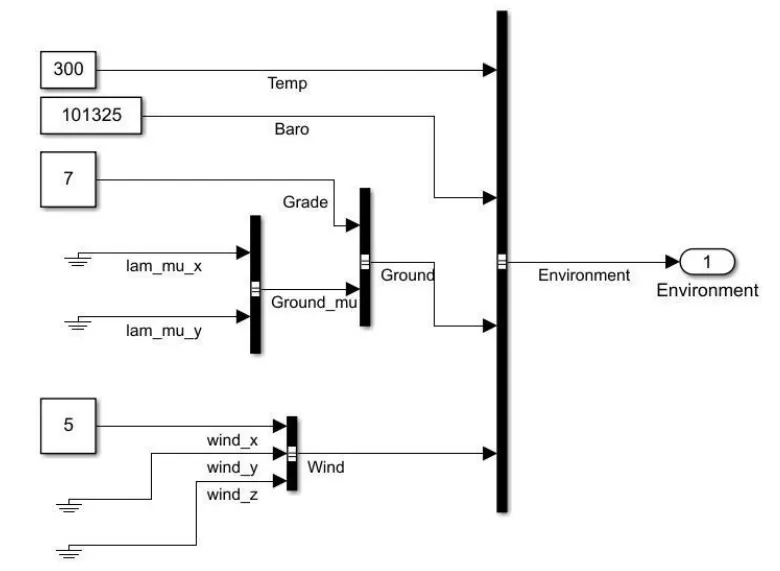
3) open the environment block and change the grade value to 7 and wind velocity to 5.
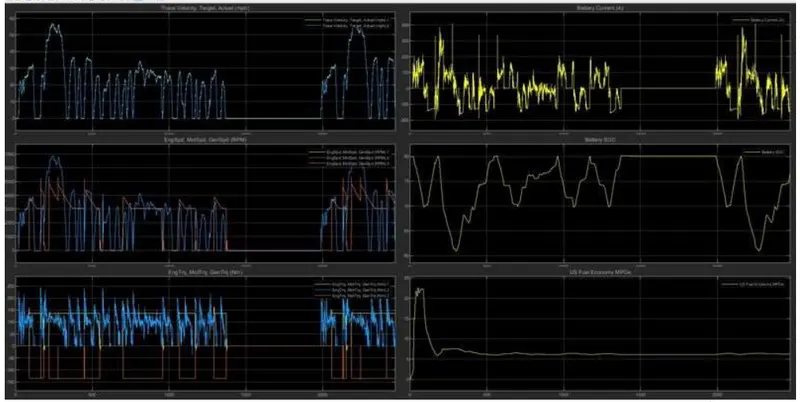
4) Now run the simulation with 2474 seconds and go to visualisation to see the graph.
Model:-
Environment Bolck:-
Result Graph:-
Case 2:- EV Reference appllication model:-
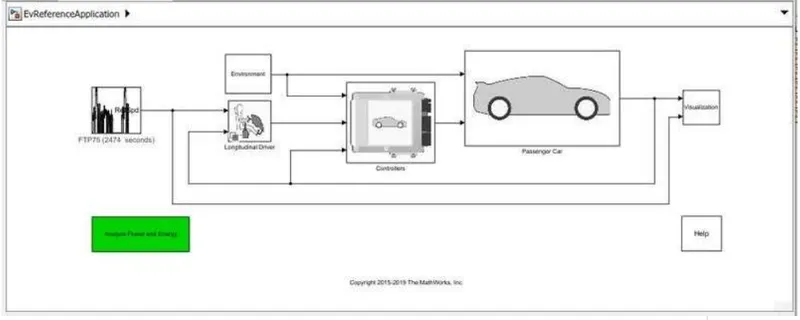
1) open Electric Vehicle Reference Application model in MATLAB.
2) The model consist of Environment, Drive cycle, Longitudinal Driver passenger and visualisation Subsystem as similar to HEV but as it is a pure electric vehicle the complexity in the model is
less and the rendering time is less.
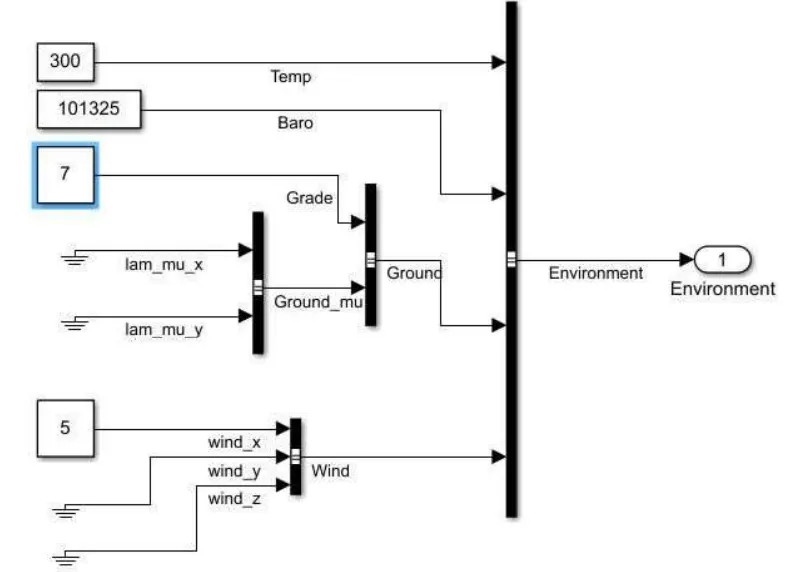
3) open the environment block and change the grade value to 7 and wind velocity to 5.
4) Now run the simulation with 2474 seconds and go to visualisation to see the graph.
Model -
Environment Block Changes:-
Result Graph:-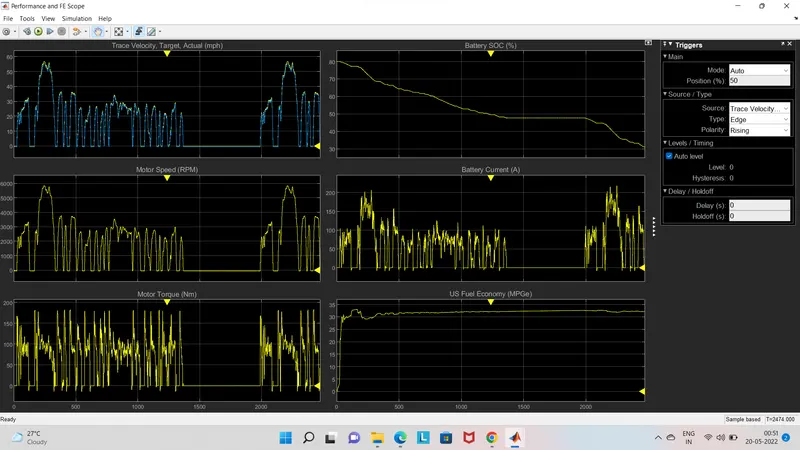
Conclusion:-
1) Battery current is continuesly changing in HEV due to charging and discharging while in pure EV the battery current is consistanty dropping.
2) The US fuel economy is high in EV compared to HEV , traveling cost is less for EV.
3) The motor speed (RPM) is high for HEV compared to EV.
4)Also observed that hybrid vehicle take more simulation time than pure EV vehicle .
5)The pure EV drive achive less top speed comapre with HEV.
6)Motor used in EV its more capacity than the HEV motor.