Week-11 Challenge: Braking
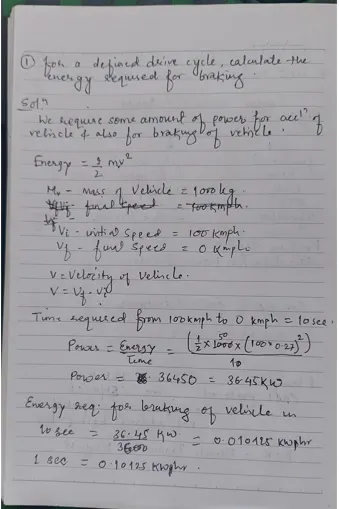
- For a defined driving cycle, calculate the energy required for braking.
2.Why electric motor can’t develop braking torque at high speed similar to starting? How electric and mechanical brakes are coordinated?
Electric motors are perfectly capable of generating maximum torque at any speed up to rated speed.
(Rated speed is the maximum speed the manufacturer says you can run the motor at, for an indefinite period of time, without damaging or overheating.)
As you can see, torque of a DC shunt motor decreases as speed increase.
Let's have a look at the favorite motor of the industry, the Induction motor.
As you can see, an Induction motor does not generate max torque at zero speed but at certain speed much like a internal combustion engine.
But the thing is, these characteristics are obtained when we run the motor directly from a rated supply. Fortunately, we do not run motors directly from supply. We use Motor Controllers in-between the motor and the supply.
Motor Controllers provide lots of advantages over running from from direct supply, Speed Control, regenerative breaking, smooth starting to name a few.
Motor controllers emloys one of several control techniques like PWM, space vector modulation, variable frequency etc etc to control motor torque, speed, power output. They can also make a motor produce max torque at any speed below rated speed.
Here's a graph showing the operating region (how a motor can be operated) of any electric motor.
The dashed line represent torque output and X axis represent rotational speed.
As evident from the graph, maximum torque output can be maintained upto the rated speed. When rated speed is reached, motor hits it's power limit, so further increase in speed requires torque to be decreased.
How electric and mechanical brakes are coordinated?
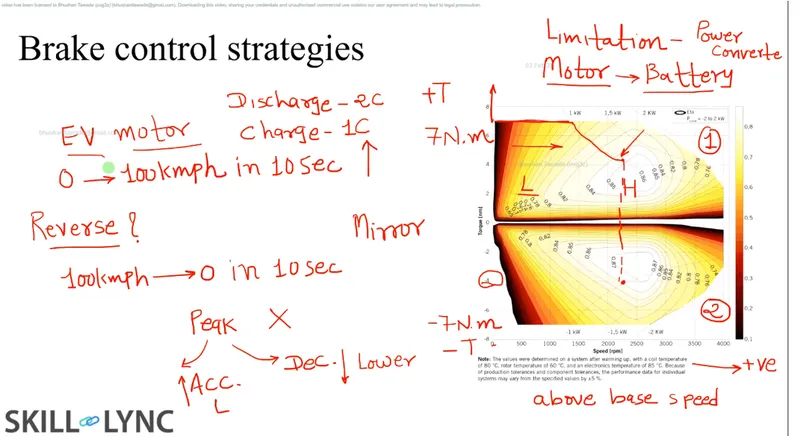
In Vehicle, Brake Control Strategies:
Series Braking : Electrical Braking and Mechanical Braking Done one after another.
Parallel Braking : Both Braking apply Simulatneously.
Electrical Braking: 1)Plugging 2)DC Injection Braking 3)Eddy Current Braking 4) Dynamic Resistance Braking 5)Regenrative Braking 6) Sharing the DC BUS
Mecahnical Braking:1) Drum Brakes 2)Disk Brakes 3)Band Brakes 4)Pawl and Ratchet Brakes
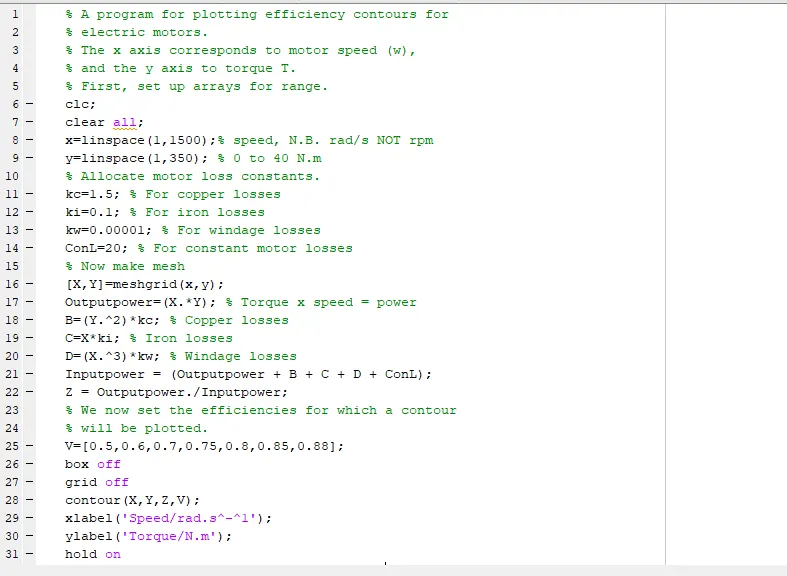
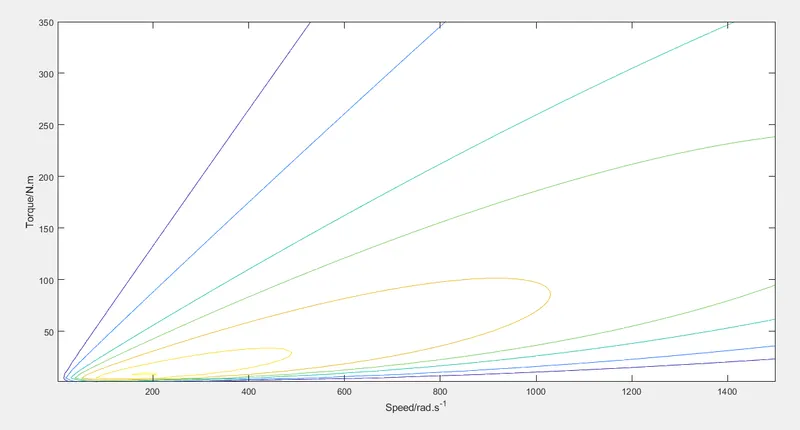
3.Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all the plots.