Week-11 Challenge: Braking
Ans 1) Driving cycle: It is a speed point versus time plot used to calculate the fuel consumption of a vehicle, which is later on compared with different vehicles.
Main uses of drving cycle includes :
i) To assess the performance of a vehicle like fuel efficiency and emission tests.
ii) To analyze battery state and energy consumption in EVs.
iii) To simulate vehicle model prior to actual development.
Braking: It is the process of controlling the velocity of the object by inhibiting its motion. An object in motion possesses kinetic energy and to bring the object to rest this kinetic energy is needed to be removed or to be converted in some other form of energy.
Most common type of braking is mechanical braking which applies frictional force to convert the kinetic energy of the vehicle into thermal energy through brake pads.
Braking system which do not use frictional force are referred as regenerative braking system(RBS). In RBS, the kinetic energy is converted into some other forms of useful energy, which can be stored for later use, increasing fuel efficiency.
E(kinetic) = 1/2*m*v^2
where,
m = mass of the vehicle in Kg
v = velocity of the vehicle in m/s
E(kinetic) - Kinetic energy in KJ
Matlab Code for calculating energy required for braking
clear all
close all
clc
% Reading the data file.
DC=xlsread('Velocityandtime');
T=DC(:,1); %Time in seconds
S=DC(:,2); % Speed in kmph

%other data
m= 1000; % mass in kg
V=S./3.6; % Speed in m/s

% To create an array to store values for Deceleration & Braking energy
Z=length(T);
deceleration=zeros(1,Z);
acceleration=zeros(1,Z);
BE=zeros(1,Z);
AE=zeros(1,Z);

for i=1:(length(T)-1)
    if V(i)>V(i+1)
        BE(i)=0.5*(V(i)-V(i+1))^2; % Braking energy in joules

        speed_decrease(i)= V(i+1)-V(i);
        deceleration(i)=speed_decrease(i);
        % since Time Delta is 1s Acc/dec=V/T..m/s^2, where T=1
    end

    if V(i)<V(i+1)
        AE(i)=0.5*m*(V(i)-V(i+1))^2; %Accelerating energy in joules

        speed_increase(i)= V(i+1)-V(i);
        acceleration(i)=speed_increase(i);
    end

end
%Total Braking Energy in KJ
B_E=(sum(BE)/1000);
% Total Acceleration Energy in KJ
A_E=(sum(AE)/1000);
% Plotting Curves
figure(1)
subplot(2,1,1)
plot(T,S,'color','b')
xlabel('Time(s)')
ylabel('Speed(Kmph)')
title('Drive cycle')

subplot(2,1,2)
plot(T,deceleration,'color','r')
hold on
plot(T,acceleration,'color','g')
xlabel('Time(s)')
ylabel('Acc/Dec(m/s^2)')
title('Acceleration-Deceleration')

figure(2)
plot(T,BE)
hold on
plot(T,AE)
xlabel('Time(s)')
ylabel('Energy(J)')
title('Energy consumed during Braking & required for accelerating throughout the drive cycle')
legend('Braking Energy','Accelerating Energy')

fprintf('Total Energy consumed during Braking is %f KJ',B_E)
disp(' ')
fprintf('Total Energy consumed during acceleration is %f KJ',A_E)
Code Explaination:
i) An excel sheet with time vs velocity data is imported into matlab workspace and the values are inserted in an array.
ii) A for loop for the length of time value is been created. The variable name length is defined.
iii) Acceleration and deceleration values are calculated inside a for loop.
iv) Total energy is calculated.
Results
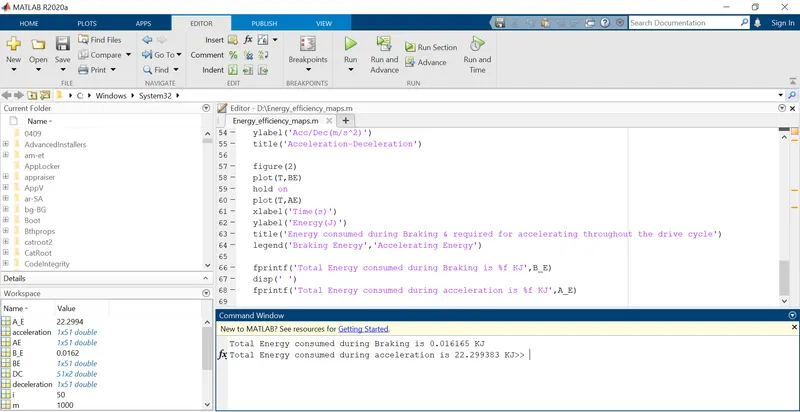
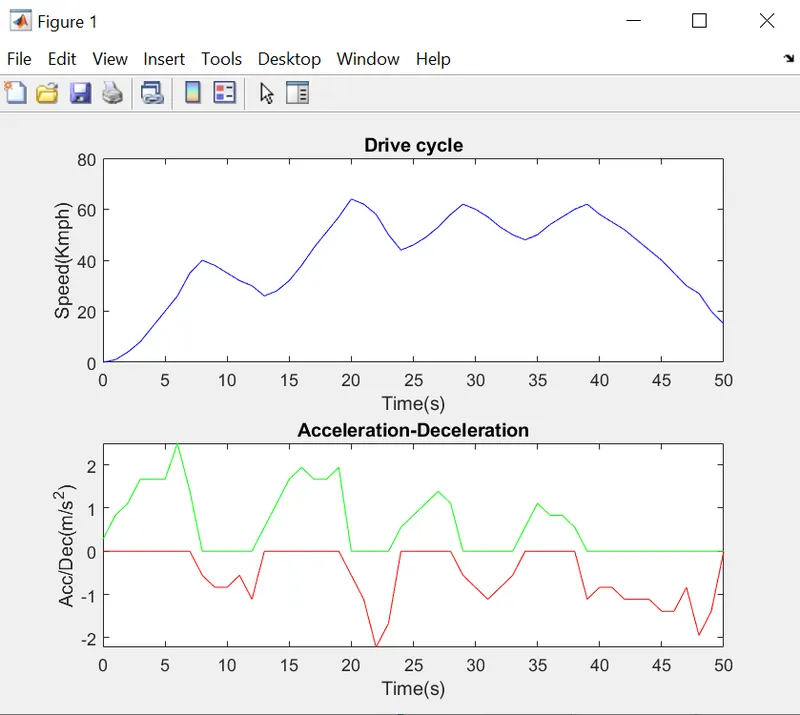
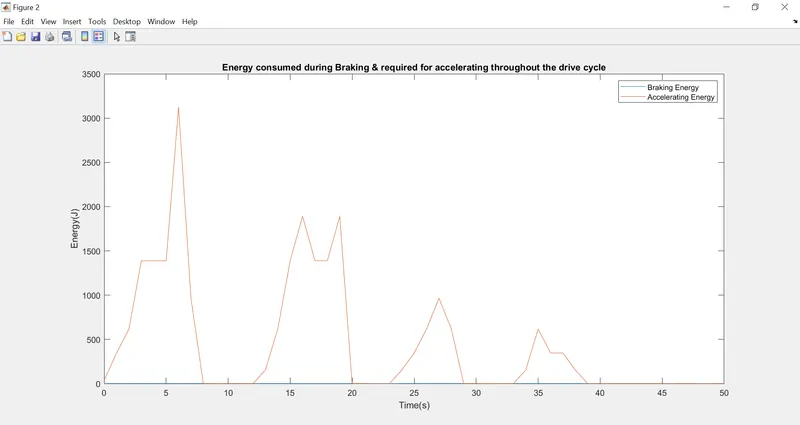
Ans 2)
Regenerative braking:
This kinetic energy recovery system that transfer the kinetic energy of an object into potential or stored energy to slow down the vehicle and as a result to increase the fuel efficiency. There are mutliple methods of energy conversion in RBSs including spring, flywheel, electromagnetic and hydraulic. More recently, an electromagnetic-flywheel hybrid.
They are installed along the drive train or fitted to the drive wheels of a vehicle where they inhibit the motion of the wheels using magnetic fields or mechanical torque. These methods of motion inhibition allow energy to be generated under braking, as opposed to frictional brakes which releases energy in the atmosphere as heat through frictional pads.
Limitations:
The maximum recharging rate of the circuit and the capacity of battery is limited.
Braking torque at high speed in an electric motor:
In EV application there is motor-generator and battery pack for power supply.
For regenerative braking the motor will act as generator i.e. the direction of the electric flow is reversed, the electric motor will rather than taking in current to spin the armature, the armature is spun through the field by deceleration of the vehicle. The electricity produced is used to charge the battery.
As the motor revs are increased, it also creates "back electromotive force" or "back emf".The faster the motor spins, the more back EMF is created, reducing the effective voltage it can deliver. But at zero RPM, all the electricity the motor creates from the time electric power applied becomes instant torque-without any back EMF to reduce its output. The higher the revs, the more back emf, meaning that instantaneous torque effect diminishes.
Whenever -> Frictional torque + Additional loads = Motor torque, the load remains in equilibrium(moves under a contant speed)
Whenever -> Frictional torque + Additional loads < Motor torque, the load accerates (Motor torque - Friction torque - Additional loads = Acceleration torque >0).
But at high speed the BEMF is so close to Vbus that the applicable Motor torque gets limited, the bigger the Friction torque + Additional load is, the smaller the acceleration torque becomes.
This situation does not occur at the beginning of an acceleration because most of the torque is used to increase the kinetical energy of the load ( and motor). But when the speed is already so high and no extra load is applied it is not possible to increase the torque.
We can prevent this by,
- Increase DC bus voltage.
- Unlimit system acceleration.
- use motor with less resistance and lower back emf proportion.
How electric and mechanical brakes are coordinated?
A regenerative Braking system is used to convert waste energy(heat) into useful energy(stored in battery) with the help of a motor which acts as a generator when reversed. There are certain limitation with RBS i.e. the electric motor is unable to provide all the brake torque neccessary for large decelerations. Therefore RBS is operated in conjunction with a friction(mechanical) braking system.
The RBS and Mechanical Brake system are used in strategic manner which is called as Brake Control Strategy.
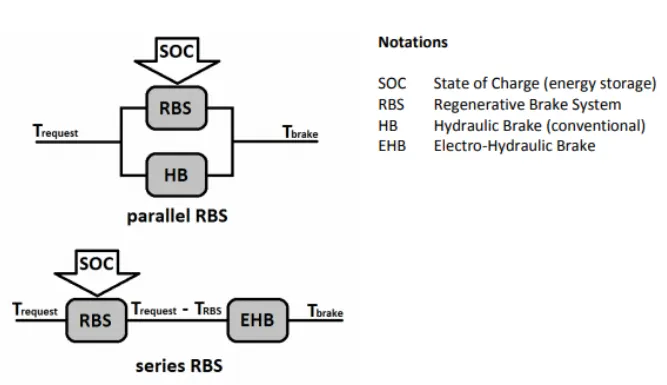
1. Series Brake Control or Series RBS:
In this type of control system the Mechanical Brakes and Regenerative(Electric) Brakes are applied one after the other.
The series brake system is further classified:
a. Comfort of the drive
b. Braking according to the energy efficiency.
2. Parallel Brake Control or Parallel RBS:
In this type of brake control system both the mechanical and RBS are applied simultaneously.
Ans 3)
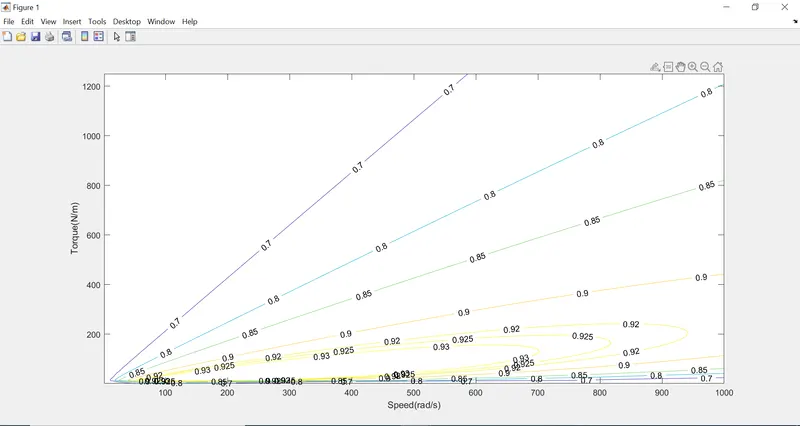
1. Copper Loss: I^2.R, where R is the armature resistance and we can say that torque is proportional to current, this copper loss can be consider as Kc.T^2, where Kc is the resistance of brushes and the flux and its effect.
Copper Losses = KcT^2
2. Iron Losses: Iron losses occured due to magnetic losses and it is denoted as Ki.ω, where Ki is the factor which is based on the magnetic field and this iron losses are based on the value of Ki and this keeps on changing due to variation in speed.
Iron Losses = Ki.ω
3. Windage Losses: This is based on the size & shape of the motor and the amount of windage losses that the motor is going to experience.
Windage Losses = Kw.ω^3
4. Constant Losses: This losses are present in the motor constantly and are denoted by C.
Total losses are are considered by combining all the four losses and denoted as,
Total Losses + KcT^2 + Ki.ω + Kw.ω^3 +C
clear all
close all
clc
x = linspace(1,1000); % Speed in rad/s
y = linspace(1,1250); % Torque in Nm

% Motor loss constants
Kc = 0.2; % Copper Loss
Ki = 0.008; % Iron loss
Kw = 0.00001; % windage loss
C = 20; % constant motor loss
[X,Y] = meshgrid(x,y);
Output_Power = (X.*Y);
C_1 = (Y.^2)*Kc;% Copper Loss
I_1 = (X*Ki);% Iron loss
W_1 = (X.^3)*Kw;% windage loss

Input_Power = Output_Power + C_1 +I_1 +W_1 +C;
Z = Output_Power./Input_Power;
V = [0.70,0.80,0.85,0.90,0.92,0.925,0.93];
box off
grid off
[c,h] = contour(X,Y,Z,V);
xlabel('Speed(rad/s)');
ylabel('Torque(N/m)');
clabel(c,h);
RESULT: