Week-11 Challenge: Braking
1. For a defined driving cycle, calculate the energy required for braking.
Calculate the energy required for braking of UDDS cycle:
Braking is a condition of slowing down or stopping a moving vehicle as required.There are several technique to apply braking, which can be mechanical or electrical.The most commonly used technique is by applying friction.It consumes energy.The consumed kinetic energy can be derived with the help of following equation;
Braking Energy=(1/2)*m*v^2
where the braking energy is the kinetic energy in unit of joule.
m=total mass of the vehicle (vehicle mass + pay load)in unit of kg.
v = (Initial velocity - final velocity)in unit m/s.
eg:
If initial speed of the vehicle is 20m/s
Final speed is 10m/s.
The mass of the vehicle is 500kg.
Then the required kinetic energy for braking is,
Braking energy = (1/2)*500*(20-10)^2
=25k
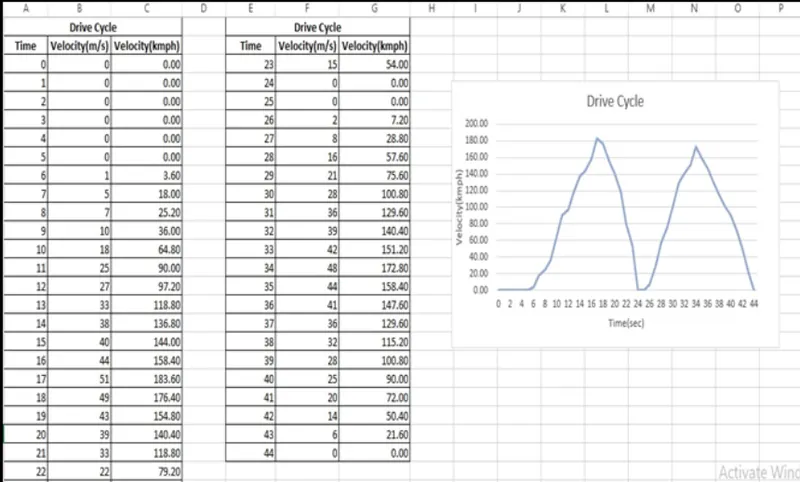
Here for a Drive cycle the required braking energy is calculated for each second of time to slow down or stop the vehicle.
Braking energy calculation for UDDS driving cycle:
2. Why electric motor can’t develop braking torque at high speed similar to starting? How electric and mechanical brakes are coordinated?
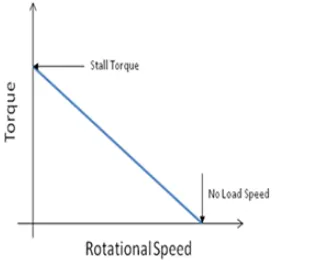
DC motor speed torque characteristic :
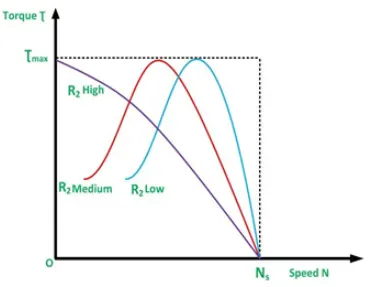
Here for both in case of AC or DC there is no torque at maximum speed, gradually the torque decreases at the high speed as the speed tends to be maximum speed.This situation doesnot occur at the beginning of acceleration because most of the torque is used to increase the kinetic energy of the load and motor.
But when the speed is already high and no extra load is applied it is not possible to increase the torque as well as to develope braking torque.The braking operation happends in the motion which is been distributed as per proportion in the motion which is been distributed as per proportion in the brake energy and the regenerative braking.
* MECHANICAL BRAKING:
Mechanical brakes all act by generating frictional forces as two surfaces rub against each other.The stopping power or capacity of a brake depends largely on the surface area of frictional surface as well as on the actuation force applied.
Mechanical brakes are assemblies consisting of mechanical elements for the slowing or stopping of shaft in equipment drives.They use levers or linkages to transmit force from one point to another.Braking slows or stops the movement of the coupled shafts.There are several types of mechanical brakes.
1. BAND BRAKES:
These are the simplest brake configuration, have a metal band lined with heat and wear resistance friction material.
2.DRUM BRAKES:
These are commonly used on automobile rear wheel, work when shoes press against a spinning surface called a drum.
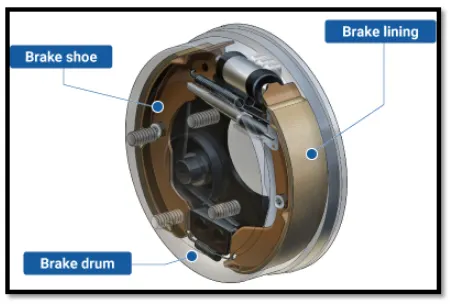
3.DRUM BRAKES:
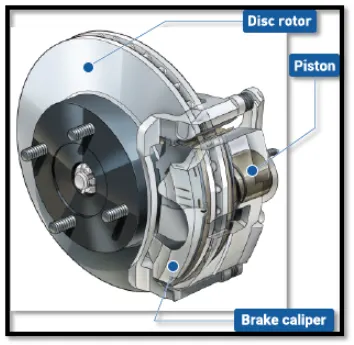
These are constructed pf brake pads, a calliper and a rotor.During operation, the brake pads are squeezed against the rotor.
**ELECTRICAL BRAKING :
Electrical braking are devices that use an electrical current or magnetic actuating force to slow or stop the motion of a rotating component.They are used in industrial nad vehicular braking application that require fast response times and precise tension control.
The magnet in the backing plate has 2 conductor wires which tap directly into the wiring.When electricity is on, it magnetizes the brake magnet.The magnet is attracted to the drum face.When it contrats this area, the friction causes it to rotate, which moves the actuating arm and pushes the shoes press against the inside of the drum, they prevent the hub and consequently the wheel that is touching the ground.
An Electrical braking scheme called the Regenerative braking is now being employed for electic braking.
Here during the braking action, the motor is operated as generator.As we know that during generating action, a counter torque is produced.So this counter torque opposes the motion of motor and motor comes to halt.Moreover, the brake energy is converted to electrical energy which can be fed back to the source using power converters.
Electrical and mechanical brake co-ordination :
There are mainly 2 ways by which the Electrical vehicles could be braked
Series-Regenerative braking and Mechanical braking both are applied one after another.
Parallel-Regeneraive braking and mechanical braking both are applied simultaneously.
When brake pedal is pressed the hydraulic fluid reaches the brake piston and created the braking pressure on the wheel and the same kinetic enrgy is been used by the Regenerative braking for generating more power using the Bi-Directional motor which operates as a generator while braking.
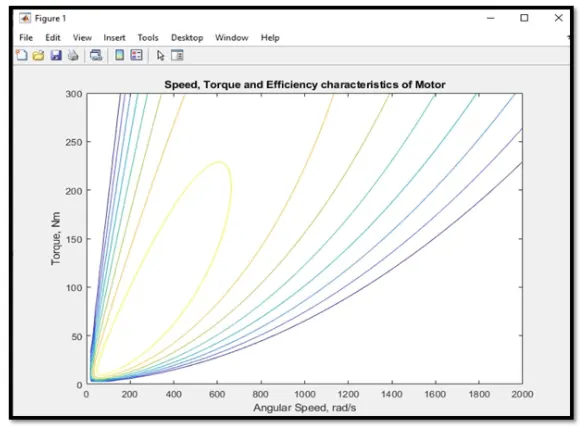
3. Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all the plots.
clear all
close all
clc

%speed array
omega= linspace(0,300,100);

%Torque array
T=linspace(0,2000,100);

% Meshgrid
[X,Y]=meshgrid(T,omega);

%Loss Co-Effecients
cu = 0.17;   % copper co-effecient
fe = 0.006;  % Iron co-effecient
win=0.000015; %Windage co-effecient

%losses
cu_loss = cu*(Y.^2);   %Copper loss
fe_loss = fe*(X.^2);   %Iron loss
win_loss = win*(X.^3); %Windage loss
cond_loss = 18;        %Condition loss

%Output power
P_out = (X.*Y);

%Input power
P_inp = (P_out) + (cu_loss) +(fe_loss) + (win_loss)+ (cond_loss);

%Effeciency
n=((P_out)/(P_inp));

%Effeciency value for contour
w=linspace(0.75, 0.95, 10);
%Contour plot
xlabel('Angular speed, rad/s')
ylabel('Torque,Nm')
title('Speed, Torque and effeciency characteristic of motor')
Explanation:
In this matlab file we have created array for the speed and the torque of the motor using the 'linspace' command.For the speed, consider a range of value from 0 to 2000 radians per second whereas for the torque, consider a range of value from 0 to 300Nm.These arrays are then used to create 2D grid coordinates using the 'meshgrid' command.
These co-ordinates will help in the creation of the contour plot.In order to find the effeciency of the motr, we need to consider the various losses that occur in the motor's operation.
These are nothig but the Coper lossses. iron losses, windage losses and condition losses.
These various losses are dependent on the speed and the torque of the motor.They also have a characteristic constant of proportionality which are all assumed for the following calculations and represented as K.In eachcalculation, the speed and the torque are represented respectively as w and T.
Output :