Vehicle Adaptive Cruise Control
AIM: TO CREATE A SIMULINK MODEL FOR VEHICLE ADAPTIVE CRUISE CONTROL
OBJECTIVES OF THIS PROJECT:
- Developing Adaptive Cruise Control feature as per the Requirement Document using MATLAB Simulink.
- Follow all the MBD related processes: Requirement Tagging & Traceability, SLDD creation, Configuration Parameter changes, Model Advisor check & Code Generation.
- In Configuration Parameters: enable “Support Floating Numbers” under Code Generation settings.
- Use Embedded Coder to generate the code.
- If choosing code generation, Storage class for Input signals: ImportedExtern; Storage class for Output signal: Export to File; Storage class for local signals: localizable; Storage class for calibration signals: Const.
- Choose sample time for all signals as 0.01s
GENERAL OVERVIEW:
Adaptive Cruise Control Feature for passenger cars allows the host vehicle to adapt to the speed in line with the flow of traffic. Driving in heavy traffic or keeping a safe distance to the preceding vehicle calls for a high level of concentration. The Adaptive Cruise Control feature can reduce the stress on the driver by automatically controlling the vehicle speed & maintaining a predefined minimum distance to the preceding vehicle. As a consequence, the driver enjoys more comfort & can concentrate on the road little better.
A radar sensor is usually at the core of the Adaptive Cruise Control. Installed at the front of the vehicle, the system permanently monitors the road ahead. As long as the road ahead is clear, cruise control feature maintains the speed set by the driver. If the system spots a slower vehicle within its detection range, it gently reduces speed by releasing the accelerator or actively engaging the brake control system. If the vehicle ahead speeds up or changes lanes, the cruise control automatically accelerates to the driver’s desired speed.
Standard Adaptive Cruise Control can be activated from speeds of around 30 km/h (20 mph) upwards and supports the driver, primarily on cross-country journeys or on freeways. The cruise control stop & go variant is also active at speeds below 30 km/h (20 mph). It can maintain the set distance to the preceding vehicle even at very low speeds and can decelerate to a complete standstill. When the vehicle remains stopped longer, the driver needs only to reactivate the system, for example by briefly stepping on the gas pedal to return to cruise control mode. In this way, cruise control stop & go supports the driver even in heavy traffic and traffic jams.
Since Adaptive Cruise Control is a comfort and convenience system, brake interventions and vehicle acceleration only take place within defined limits. Even with Adaptive Cruise Control switched on, it remains the driver’s responsibility to monitor the speed and distance from the vehicle in front.
Requirement 1– Lead Vehicle:
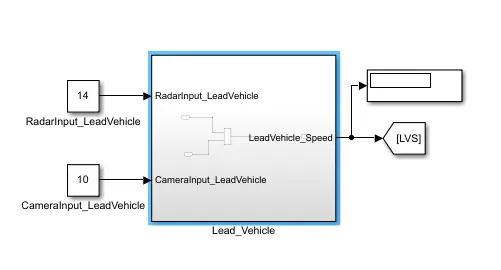
- Lead Vehicle is a vehicle which is driving in the road ahead of our drive vehicle. Two input signals (Signal Name: CameraInput_LeadVehicle & RadarInput_LeadVehicle).
- Ideally sensor fusion techniques will be deployed to process & analyze data from camera & radar. For complexity reasons, let’s not adapt to any such algorithms.
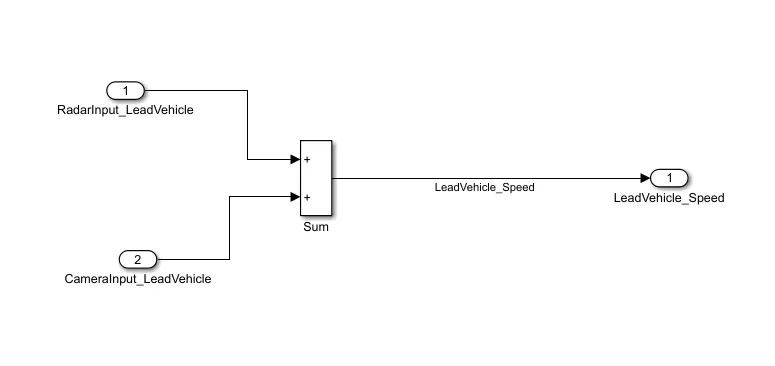
- We can simply add both the radar & camera inputs & the corresponding output is read as Speed profile output (Signal Name: LeadVehicle_Speed).
- Speed data of the lead vehicle is critical in implementing the Adaptive Cruise Control algorithm.
Requirement 2 – Drive Vehicle:
- Drive Vehicle is the vehicle driven by the user & this is the vehicle which has ACC algorithm in it.
- Like the Lead Vehicle, Drive Vehicle algorithm also has 2 input signals (Signal Name: CameraInput_DriveVehicle, RadarInput_DriveVehicle) & one signal coming as an Input to this subsystem (Signal Name: Acceleration_Mode) – three inputs into this requirement in total.
- Like the above requirement, sensor fusion techniques will also be deployed here, for complexity reasons we are ignoring them.
- Two output signals come from this subsystem (Signal Name: DriveVehicle_Speed & LeadVehicle_Detected).
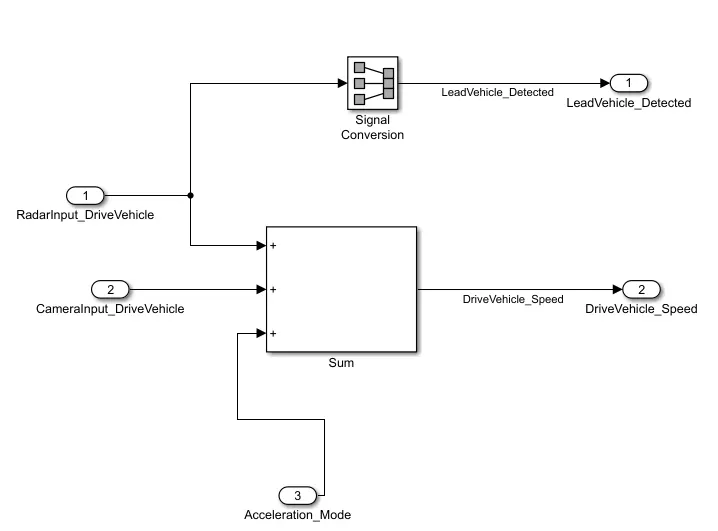
- Signal DriveVehicle_Speed is summation of three input signals mentioned above & LeadVehicle_Detected is renamed from Input Signal RadarInput_DriveVehicle by mere use of Signal Conversion block.
Requirement 3 – Adaptive Cruise Control Algorithm:
- Adaptive Cruise Control feature has 3 major modes of operation: OFF Mode, STANDBY Mode & ON Mode. This particular requirement has to be implemented as state machine logic in Simulink.
- The input signals to this state machine system are (Signal Name: Time_Gap, Set_Speed, Set_Gap, CruiseSwitch, SetSwitch).
- Also, the output signals (Signal Name: DriveVehicle_Speed & LeadVehicle_Detected) from requirement-2 is fed back as an input signal into this state machine block.
- Additionally, output signal (Signal Name: LeadVehicle_Speed) from requirement-1 is given as an input signal to this state machine block as well.
- Output from this subsystem is a signal (Signal Name: Acceleration_Mode) which governs the vehicular speed of the drive vehicle which automatically adjusts its speed & velocity to match the lead vehicle.
Requirement 3a – ACC OFF MODE state logic:
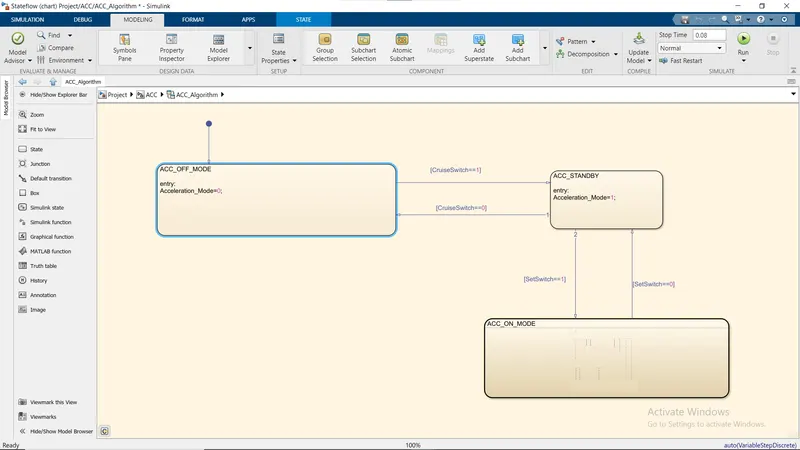
- This is the default state inside state machine logic. Output signal Acceleration_Mode is at value 0 in this state.
- This state is governed by input signal CruiseSwitch.
- If CruiseSwitch is equal to 1, state ACC STANDBY mode will get activated. If CruiseSwitch is equal to 0, state ACC OFF mode will get activated, from either ACC ON mode or ACC STANDBY mode
Requirement 3b – ACC STANDBY MODE state logic:
- This is the second activated state inside state machine logic. Output signal Acceleration_Mode is at value 1 in this state.
- This state is governed by both input signals CruiseSwitch & SetSwitch.
- If CruiseSwitch is equal to 1, state ACC STANDBY mode will get activated. If CruiseSwitch is equal to 0, state ACC OFF mode will get activated, from either ACC ON mode or ACC STANDBY mode
- If SetSwitch is equal to 1, state ACC ON mode will get activated. If SetSwitch is equal to 0, state ACC STANDBY mode will get activated.
Requirement 3c – ACC ON MODE state logic:
This state will be activated when input signal SetSwitch is equal to 1. There are 6 sub states to this state logic: They are:
- LeadVehicle_Detected_Follow (Default)
- LeadVehicle_Not_Detected
- LeadVehicle_Detected_Resume
- LeadVehicle_Not_Detected_Resume
- LeadVehicle_Speed_lessthan_Set_Speed
Requirement 3c (i) – LeadVehicle_Detected_Follow (ACC ON MODE):
- This is the default sub state inside ACC ON MODE state. Output signal Acceleration_Mode is equal to 2.
- Condition to transit from LeadVehicle_Detected_Follow to LeadVehicle_Not_Detected; Input signal condition LeadVehicle_Detected == 0.
- Condition to transit from LeadVehicle_Detected_Follow to LeadVehicle_Speed_lessthan_Set_Speed; Input Signals condition (LeadVehicle_Detected == 1) && (LeadVehicle_Speed < Set_Speed) || (Time_Gap < Set_Gap).
Requirement 3c (ii) – LeadVehicle_Not_Detected (ACC ON MODE):
- Output signal Acceleration_Mode is equal to 1.
- Condition to transit from LeadVehicle_Not_Detected to LeadVehicle_Detected_Follow; Input signals condition [(LeadVehicle_Detected==1) && (DriveVehicle_Speed == Set_Speed) && (LeadVehicle_Speed >= Set_Speed) && (Time_Gap >= Set_Gap)]
- Condition to transit from LeadVehicle_Not_Detected to LeadVehicle_Speed_lessthan_Set_Speed; Input signals condition [(LeadVehicle_Detected == 1) && (LeadVehicle_Speed < Set_Speed) || (Time_Gap < Set_Gap)]
Requirement 3c (iii) – LeadVehicle_Detected_Resume (ACC ON MODE):
- Output signal Acceleration_Mode is equal to 3.
- Condition to transit from LeadVehicle_Detected_Resume to LeadVehicle_Detected_Follow; Input signals condition [(DriveVehicle_Speed == Set_Speed) && (LeadVehicle_Speed >= Set_Speed) && (Time_Gap >= Set_Gap)]
- Condition to transit from LeadVehicle_Detected_Resume to LeadVehicle_Not_Detected_Resume; Input signal condition LeadVehicle_Detected==0.
- Condition to transit from LeadVehicle_Detected_Resume to LeadVehicle_Speed_equal_Set_Speed; Input Signal condition [(DriveVehicle_Speed < Set_Speed) && (LeadVehicle_Speed > DriveVehicle_Speed) && (Time_Gap >= Set_Gap)]
Requirement 3c (iv) - LeadVehicle_Not_Detected_Resume (ACC ON MODE):
- Output signal Acceleration_Mode is equal to 1.
Requirement 3c (v) - LeadVehicle_Speed_lessthan_Set_Speed (ACC ON MODE):
- Output signal Acceleration_Mode is equal to 4.
- Condition to transit from LeadVehicle_Speed_lessthan_Set_Speed to LeadVehicle_Not_Detected; Input signal condition [(LeadVehicle_Detected == 0) && (DriveVehicle_Speed == Set_Speed)]
- Condition to transit from LeadVehicle_Speed_lessthan_Set_Speed to LeadVehicle_Speed_equal_Set_Speed; Input signals condition [((LeadVehicle_Speed*1.25>=DriveVehicle_Speed) && (LeadVehicle_Speed * 0.75<=DriveVehicle_Speed)) && (DriveVehicle_Speed < Set_Speed) && ((Time_Gap<=1.25*Set_Gap) && (Time_Gap >=0.75*Set_Gap))]
Requirement 3c (vi) - LeadVehicle_Speed_equal_Set_Speed (ACC ON MODE):
- Output signal Acceleration_Mode is equal to 5.
- Condition to transit from LeadVehicle_Speed_equal_Set_Speed to LeadVehicle_Not_Detected_Resume; Input signal conditions is [(LeadVehicle_Detected == 0) || (DriveVehicle_Speed <= Set_Speed)]
- Condition to transit from LeadVehicle_Speed_equal_Set_Speed to LeadVehicle_Detected_Resume; Input signal conditions [(DriveVehicle_Speed < Set_Speed) && (LeadVehicle_Speed > DriveVehicle_Speed) || (Time_Gap >= Set_Gap)]
- Condition to transit from LeadVehicle_Speed_equal_Set_Speed to LeadVehicle_Speed_lessthan_Set_Speed; Input signals conditions [(LeadVehicle_Speed<Set_Speed) && (LeadVehicle_Speed<DriveVehicle_Speed) || (Time_Gap==0.75*Set_Gap)]
SIMULINK MODEL:
MAIN SYSTEM:
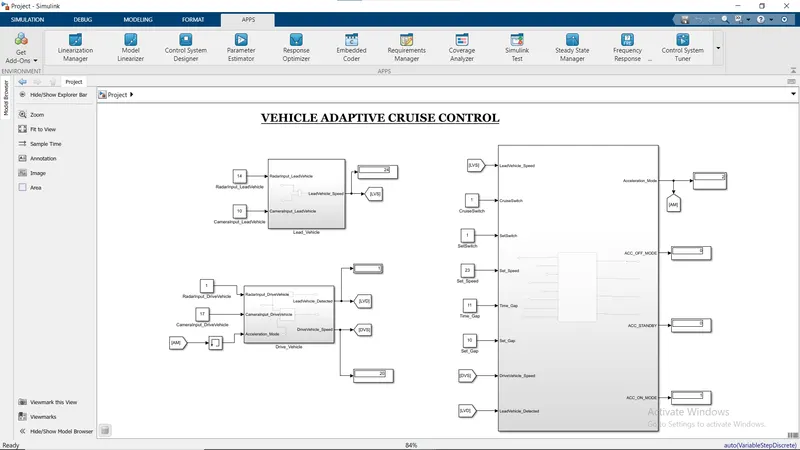
>> The main window of this simulink model consists of three subsystems. Each satisfies a requirement.
>> The three subsystems are 'Lead_Vehicle' , 'Drive_Vehicle' and 'ACC Algorithm'.
>> These subsystems are connected using 'From' and 'GoTO' blocks.
LEAD VEHICLE:
>> The lead vehicle subsystem takes two inputs 'RadarInput_LeadVehicle' and 'CameraInput_LeadVehicle', which are added using a summation block to an output 'LeadVehicle_Speed'/
DRIVE VEHICLE:
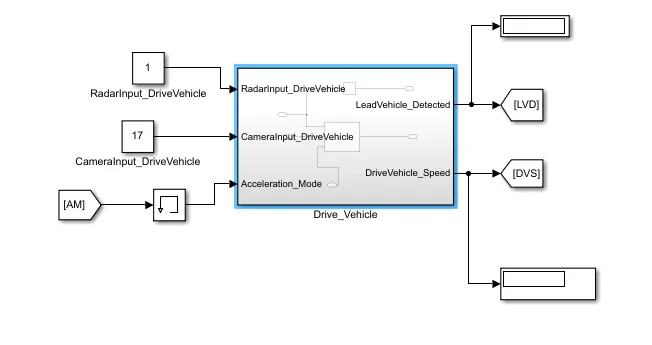
>> Drive_Vehicle subsystem takes three input 'RadarInput_DriveVehicle','CameraInput_DriveVehicle' and 'Acceleration_Mode'.
>> As Acceleration_Mode is an input from the state chart and thus, entangled in an Algebraic Loop. To avoid the error we are using a 'Memory' block to integrate the values.
>> A Signal_Conversion block is used to convert the signal from 'RadarInput_DriveVehicle' and giving it out as 'LeadVehicle_Detected'
>>DriveVehicle_Speed output is the summation of all the three inputs. For this purpose we used a summation block.
>> To easily modify values and rectify errors or changes modes, the output blocks are connected to a display each. And since, the input blocks are constant blocks we can easily change the values.
ADAPTIVE CRUISE CONTROL ALGORITHM:
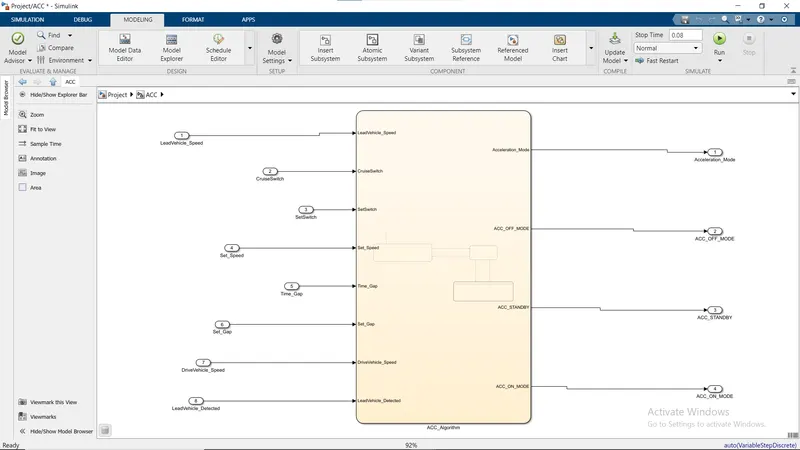
>> This subsystem consists of a state chart which 8 inputs from the other two subsystems as per the requirements mentions and 1 main output i.e., Acceleration_Mode, and three optional outputs 'ACC_OFF_MODE', 'ACC_STANDBY' and 'ACC_ON_MODE' are created for easy debugging purpose.
>>In the main window, we can observe that the Acceleration_Mode is fed to Drive_Vehicle as one of its input. Thus, acting as a feedback.
ACC MAIN STATE CHART:
>> The main state chart consists of three modes (states) 'ACC_OFF_MODE' , 'ACC_STANDBY' and 'ACC_ON_MODE' which are mainly switched betwwen each other by 'CruiseSwitch and SetSwitch' conditions.
>> Each state has an 'entry' variable.
ACC ON MODE SUBCHART:
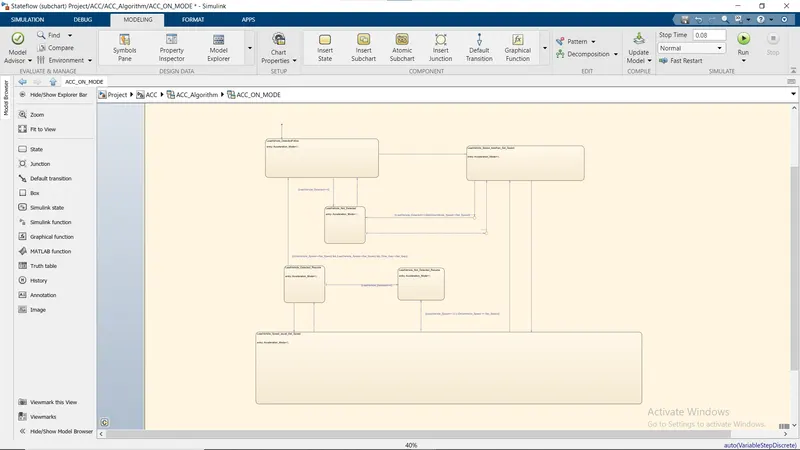
>>The third state i.e., ACC_ON_MODE, has 6 subcharts or child charts as per the requirements.
>> The switch conditions are written in the 'condition' points of the transitions as per the requirements mentioned.
DATA DICTIONARY:
Source:
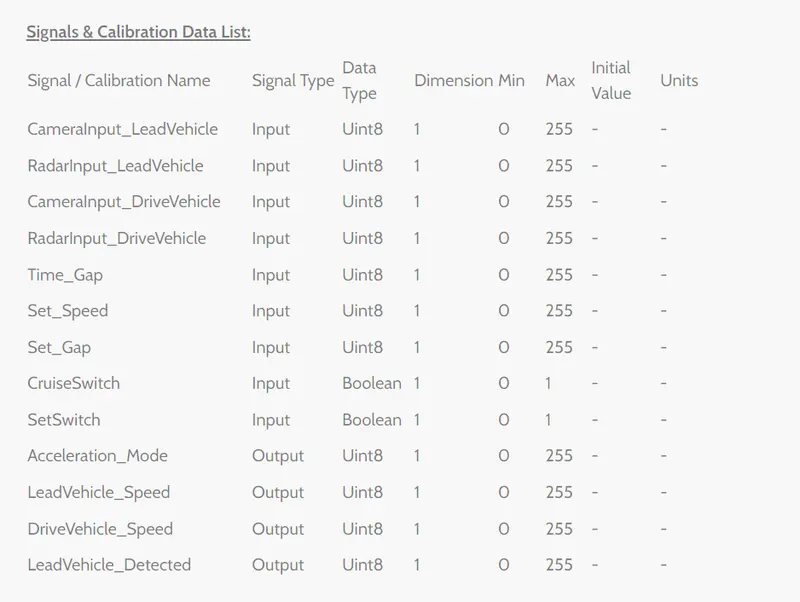
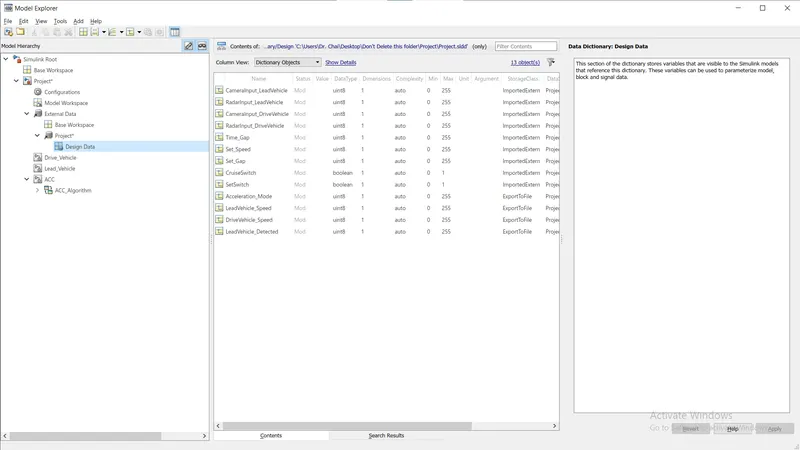
>> Each variable and signals are configured according to the requirements and stored in the Data Dictionary.
REQUIREMENTS MANAGER:
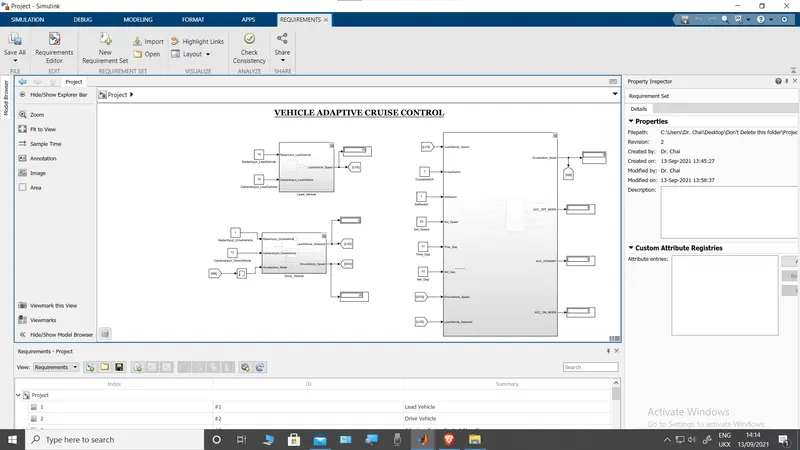
>> A Requirement set is been created through Requirements Manager option from the APPS menu.
>> The requirements are linked to each requirement blocks/subsystems. These can be viewed from the Requirement Editor mode.
>> The requirement files are attached.
MODEL ADVISOR:
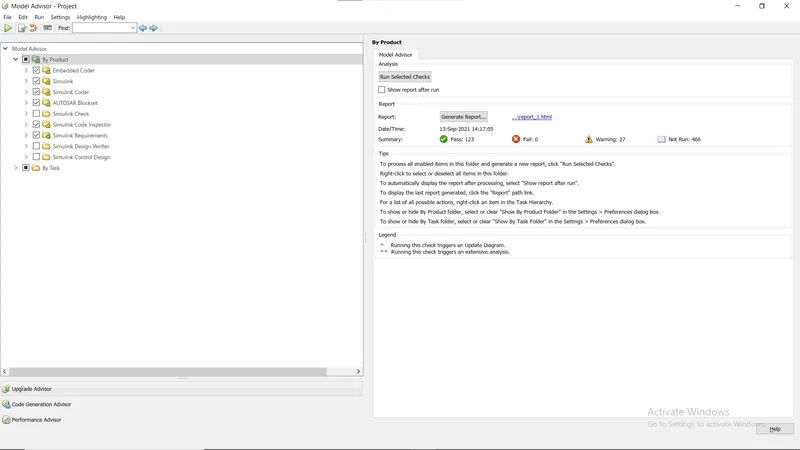
>> Model Advisor is run to check warnings and errors in the model and model settings, and rectify/optimise according to them.
>> Model Advisor report is been attached to this project.
CONFIGURATION PARAMETERS FOR CODE GENERATION:
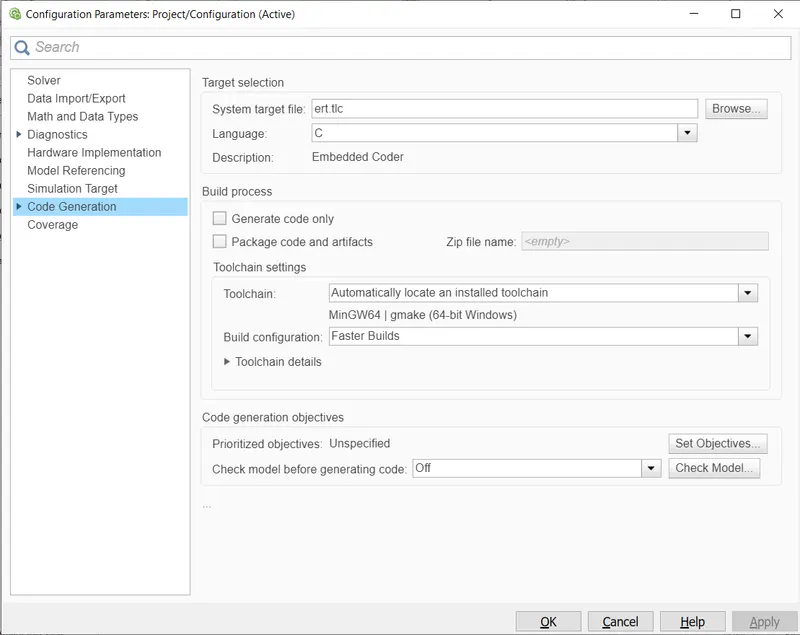
>> The configuration parameters are modified.
>> System target file in the code generation is set as 'ert.tlc' as we are using embedded coder for code generation and language is set for 'C'.
CODE GENERATION:
>>Using the embedded coder tab in the APPS menu a C code for our model is built.
/*
 * File: Project.c
 *
 * Code generated for Simulink model 'Project'.
 *
 * Model version                  : 1.15
 * Simulink Coder version         : 9.5 (R2021a) 14-Nov-2020
 * C/C++ source code generated on : Mon Sep 13 15:06:52 2021
 *
 * Target selection: ert.tlc
 * Embedded hardware selection: Intel->x86-64 (Windows64)
 * Code generation objectives: Unspecified
 * Validation result: Not run
 */

#include "Project.h"
#include "Project_private.h"

/* Named constants for Chart: '/ACC_Algorithm' */
#define IN_LeadVehicle_Detected_Resume ((uint8_T)2U)
#define IN_LeadVehicle_Not_Detected_Res ((uint8_T)4U)
#define IN_LeadVehicle_Speed_equal_Set_ ((uint8_T)5U)
#define P_IN_LeadVehicle_DetectedFollow ((uint8_T)1U)
#define Pro_IN_LeadVehicle_Not_Detected ((uint8_T)3U)
#define Project_IN_ACC_OFF_MODE        ((uint8_T)1U)
#define Project_IN_ACC_ON_MODE         ((uint8_T)2U)
#define Project_IN_ACC_STANDBY         ((uint8_T)3U)

/* Block states (default storage) */
DW_Project_T Project_DW;

/* Real-time model */
static RT_MODEL_Project_T Project_M_;
RT_MODEL_Project_T *const Project_M = &Project_M_;

/* Model step function */
void Project_step(void)
{
  uint8_T rtb_DriveVehicle_Speed;

  /* Sum: '/Sum' incorporates:
   *  Constant: '/CameraInput_DriveVehicle'
   *  Constant: '/RadarInput_DriveVehicle'
   *  Memory: '/Memory'
   */
  rtb_DriveVehicle_Speed = (uint8_T)(Project_DW.Memory_PreviousInput + 18U);

  /* Chart: '/ACC_Algorithm' incorporates:
   *  Constant: '/CameraInput_DriveVehicle'
   *  Constant: '/RadarInput_DriveVehicle'
   *  Constant: '/Set_Speed'
   *  Memory: '/Memory'
   *  Sum: '/Sum'
   */
  if (Project_DW.is_active_c3_Project == 0U) {
    Project_DW.is_active_c3_Project = 1U;
    Project_DW.is_c3_Project = Project_IN_ACC_OFF_MODE;

    /* Update for Memory: '/Memory' */
    Project_DW.Memory_PreviousInput = 0U;
  } else {
    switch (Project_DW.is_c3_Project) {
     case Project_IN_ACC_OFF_MODE:
      Project_DW.is_c3_Project = Project_IN_ACC_STANDBY;

      /* Update for Memory: '/Memory' */
      Project_DW.Memory_PreviousInput = 1U;
      break;

     case Project_IN_ACC_ON_MODE:
      switch (Project_DW.is_ACC_ON_MODE) {
       case P_IN_LeadVehicle_DetectedFollow:
        /* Update for Memory: '/Memory' */
        Project_DW.Memory_PreviousInput = 2U;
        break;

       case IN_LeadVehicle_Detected_Resume:
        /* Update for Memory: '/Memory' */
        Project_DW.Memory_PreviousInput = 3U;
        if (rtb_DriveVehicle_Speed == 23) {
          Project_DW.is_ACC_ON_MODE = P_IN_LeadVehicle_DetectedFollow;

          /* Update for Memory: '/Memory' */
          Project_DW.Memory_PreviousInput = 2U;
        } else if ((rtb_DriveVehicle_Speed < 23) && (24 > rtb_DriveVehicle_Speed))
        {
          Project_DW.is_ACC_ON_MODE = IN_LeadVehicle_Speed_equal_Set_;

          /* Update for Memory: '/Memory' */
          Project_DW.Memory_PreviousInput = 5U;
        }
        break;

       case Pro_IN_LeadVehicle_Not_Detected:
        /* Update for Memory: '/Memory' */
        Project_DW.Memory_PreviousInput = 1U;
        if (rtb_DriveVehicle_Speed == 23) {
          Project_DW.is_ACC_ON_MODE = P_IN_LeadVehicle_DetectedFollow;

          /* Update for Memory: '/Memory' */
          Project_DW.Memory_PreviousInput = 2U;
        }
        break;

       case IN_LeadVehicle_Not_Detected_Res:
        /* Update for Memory: '/Memory' */
        Project_DW.Memory_PreviousInput = 1U;
        break;

       case IN_LeadVehicle_Speed_equal_Set_:
        if ((uint8_T)(Project_DW.Memory_PreviousInput + 18U) <= 23) {
          Project_DW.is_ACC_ON_MODE = IN_LeadVehicle_Not_Detected_Res;

          /* Update for Memory: '/Memory' */
          Project_DW.Memory_PreviousInput = 1U;
        } else {
          Project_DW.is_ACC_ON_MODE = IN_LeadVehicle_Detected_Resume;

          /* Update for Memory: '/Memory' */
          Project_DW.Memory_PreviousInput = 3U;
        }
        break;

       default:
        /* Update for Memory: '/Memory' */
        /* case IN_LeadVehicle_Speed_lessthan_Set_Speed: */
        Project_DW.Memory_PreviousInput = 4U;
        if ((30 >= rtb_DriveVehicle_Speed) && (18 <= rtb_DriveVehicle_Speed) &&
            (rtb_DriveVehicle_Speed < 23)) {
          Project_DW.is_ACC_ON_MODE = IN_LeadVehicle_Speed_equal_Set_;

          /* Update for Memory: '/Memory' */
          Project_DW.Memory_PreviousInput = 5U;
        }
        break;
      }
      break;

     default:
      /* case IN_ACC_STANDBY: */
      Project_DW.is_c3_Project = Project_IN_ACC_ON_MODE;
      Project_DW.is_ACC_ON_MODE = P_IN_LeadVehicle_DetectedFollow;

      /* Update for Memory: '/Memory' */
      Project_DW.Memory_PreviousInput = 2U;
      break;
    }
  }

  /* End of Chart: '/ACC_Algorithm' */
}

/* Model initialize function */
void Project_initialize(void)
{
  /* (no initialization code required) */
}

/* Model terminate function */
void Project_terminate(void)
{
  /* (no terminate code required) */
}

/*
 * File trailer for generated code.
 *
 * [EOF]
 */
CONCLUSION:
>> A simulation model for Vehicle Adaptive Cruise Control is been created where the acceleration modes are changed according to the camera and radar inputs.