Transfer Function
AIM:
To study the car's autonomous driving and the transfer function for the spring-mass and electrical system.
OBJECTIVE:
- How hybrid electric cars can be operated more efficiently by autonomous driving systems?
- Derive transfer function of suspension system of a car and convert it state-space format.
- Are the transfer functions of RC and CR (output across R) circuits the same?
OBJECTIVE 1- How hybrid electric cars can be operated more efficiently by autonomous driving systems?
Hybrid electric cars are the future of the Automotive Industries.
A self-driving car is a vehicle that can sense the environment and can navigate itself through the environment without human input.
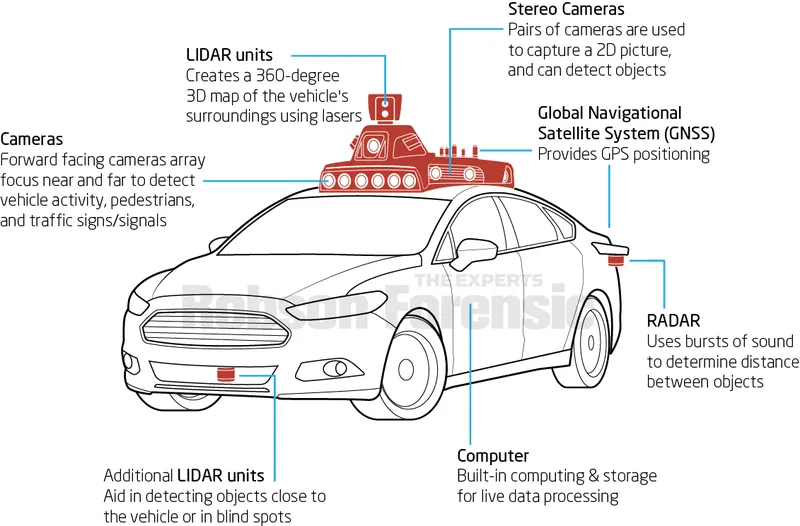
Self-driving cars do have many sensors like LIDAR, RADAR, Ultrasonic, GPS, etc that helps navigation.
Autonomous driving cars:
The Society of Automotive Engineers (SAE) has classified self-driving vehicles into stages, which range from Level 0 to 5. Let’s take a brief look at each stage.
Level 0 does not feature any self-driving tech at all.
Level 1 cars offer at least one system that helps the driver brake, steer, or accelerate, but if there are multiple systems, they cannot communicate with each other.
Level 2 cars can simultaneously control steering and speed, even if the driver is not driving, for short periods of time. Think lane-centering technology combined with advanced cruise control, as an example.
Level 3 vehicles are fully autonomous but require driver attention. These cars aren’t yet available but are being tested by some tech startups.
Level 4 cars, once programmed to a destination, will not need driver input, but the controls are available should the driver wish to intervene.
Level 5 cars will be fully autonomous without any driver input whatsoever.
Currently, very few vehicles offer Level 3 technologies, and no Level 4 or Level 5 systems have been commercially deployed.
Hybrid Electric cars:
A hybrid electric vehicle (HEV) has two types of energy storage units, electricity, and fuel. Electricity means that a battery is used to store the energy and that an electromotor will be used as a traction motor.
Fuel means that a tank is required, and that an Internal Combustion Engine is used to generate mechanical power, or that a fuel cell will be used to convert fuel to electrical energy. In the latter case, traction will be performed by the electromotor only. In the first case, the vehicle will have both an engine and a motor.
Depending on the drive train structure (how motor and engine are connected), we can distinguish between parallel, series, or combined HEVs.
Depending on the share of the electromotor to the traction power, we can distinguish between mild or micro-hybrid (start-stop systems), power assist hybrid, full hybrid, and plug-in hybrid.
Depending on the nature of the non-electric energy source, we can distinguish between combustion (ICE), fuel cell, hydraulic or pneumatic power, and human power. In the first case, the ICE is a spark-ignition engines(gasoline) or compression ignition direct injection(diesel) engine. In the first two cases, the energy conversion unit may be powered by gasoline, methanol, compressed natural gas, hydrogen, or other alternative fuels.
Hybrid electric cars can be operated more efficiently by autonomous driving systems:
Applying hybrid-electric technology to our self-driving vehicles delivers several benefits, including maximum mileage to keep the vehicle on the road. Plus, hybrids help provide the significant amount of electrical power required for self-driving sensors and computing systems without having a significant impact on the mileage.
Computer efficiency is at the top of mind for everyone involved in the race to develop self-driving cars.
The location is detected by the Global Positioning System (GPS). It is new and promising technology, which uses real-time geographical data received from several GPS satellites to calculate coordinates, speed, and course to help navigate the car. GPS integrates the data received from the tachometer, gyroscope, and altimeters to provide more accurate positioning.
For identifying the lane markings and the edges of roads, LIDAR(Light Detecting and Ranging) sensors are used. These sensors use the pulses of light off the surroundings. LIDAR consists of the emitter, mirror, and receiver. The emitter sends a laser beam bounces of the mirror 10-15 revolutions per min. After bouncing off objects, the laser beam returns through the mirror to the receiver. The data of such points is stored as point cloud data (pcd).
RADAR sensors are used as the adaptive cruise control(ACC) system to monitor the position of in-front vehicles. Also, Ultrasonic sensors are used to measure the position of objects very close to the vehicle such as speed-brakes and other vehicle parking. Cameras are also mounted to detect traffic signals, keep track of other vehicles and look out for pedestrians and obstacles on the road. The information from all of the sensors is analyzed by the central computer that manipulates the steering, accelerator, and brakes.
In autonomous cars, the switching of the fuel systems to the battery systems and vice-versa can be done by the car only without human assistance. By that, the car can be work more efficiently.
Other benefits of autonomous cars are,
- Reduce Accidents
- Reduce Traffic congestion
- Reduce CO2 Emissions
- Increased lane capacity
- Lower fuel consumption
- Transportation accessibility
- Reduce travel ties and transportation costs
- More effective and affordable taxis
- More efficient parking
OBJECTIVE 2 - Derive transfer function of suspension system of a car and convert it state-space format.
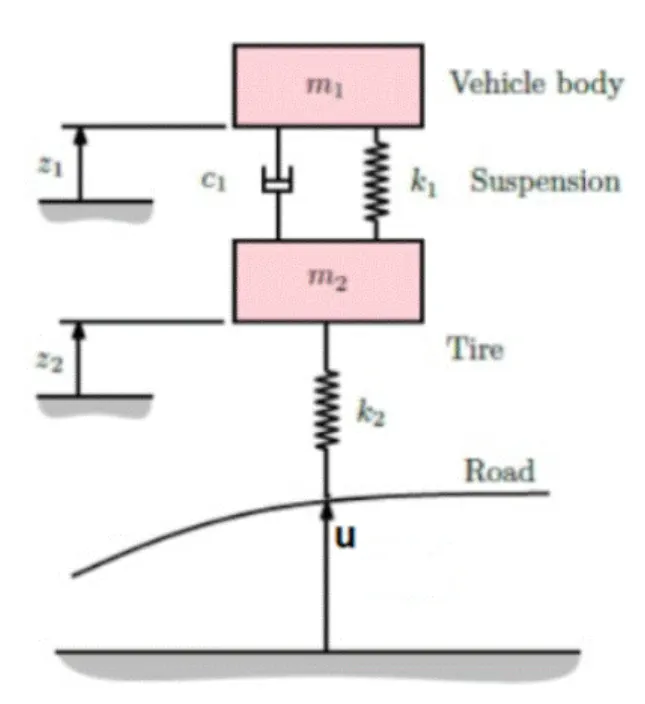
A quarter car model of a vehicle suspension is shown in the figure below. The model consists of a mass m1 corresponding to a quarter of the total vehicle mass (minus the wheels) and a mass m2 corresponding to a wheel. The suspension linking the vehicle body to the wheel consists of a spring of stiffness k1 in parallel with a shock absorber of damping coefficient c1. Meanwhile, the wheel is modeled as having a stiffness k2. Coordinates z1 and z2 measure the positions of masses m1 and m2 with respect to their static equilibrium positions (i.e., where the springs balance the gravity forces). The input to the suspension is the road surface displacement u, which is dependent on the road profile and vehicle speed.
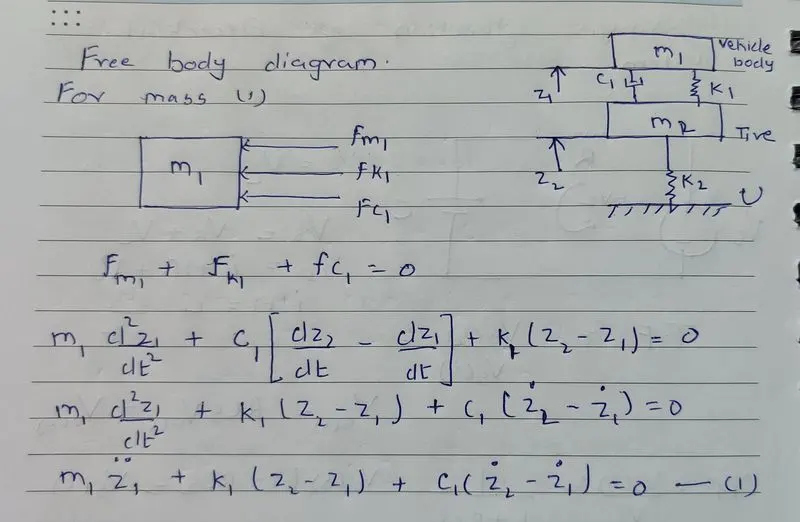
First, we will consider the m1 mass of the vehicle, and draw the free body diagram of the same and calculate the forces for that respective mass,
similarly, we can calculate the equation for the wheel mass that is m2
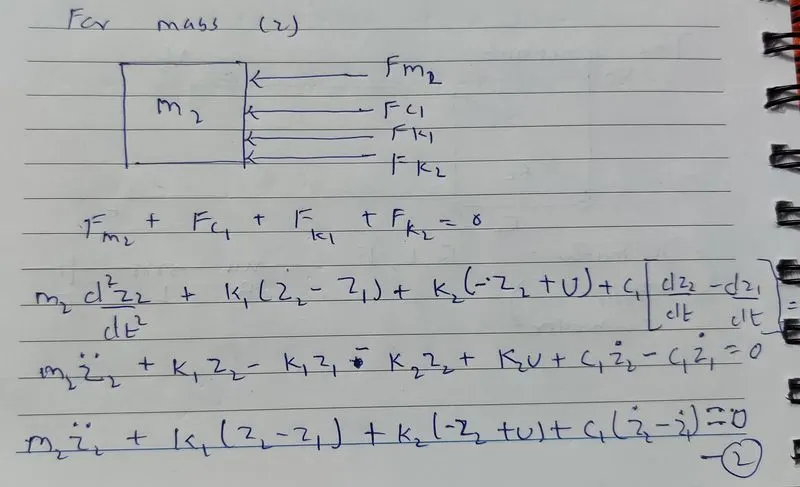
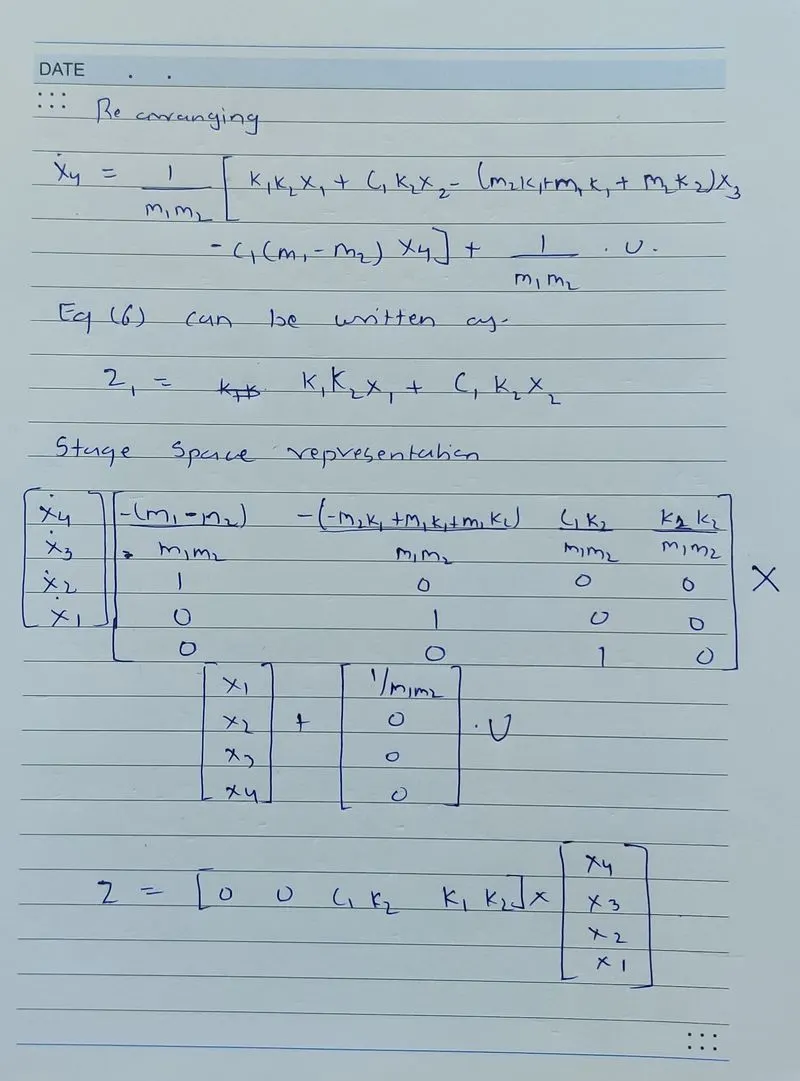
Now we will be taking the Laplace transform of differential equations to convert them to algebraic equations. The transfer function is to be converted into state-space representation. For mass 1 we will form the transfer function from the differential equation. Laplace transform is taken for equations (1) and equation (2).
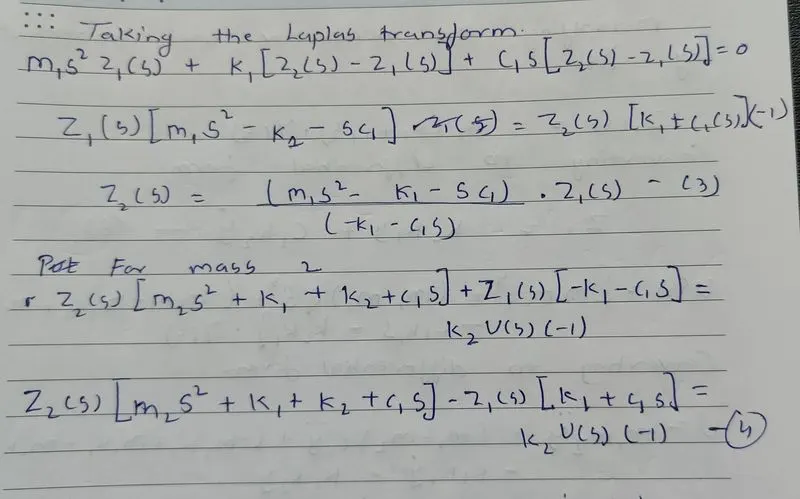
Putting the value of Z2 from equation 3 in equation 4. Now the equation can be written as
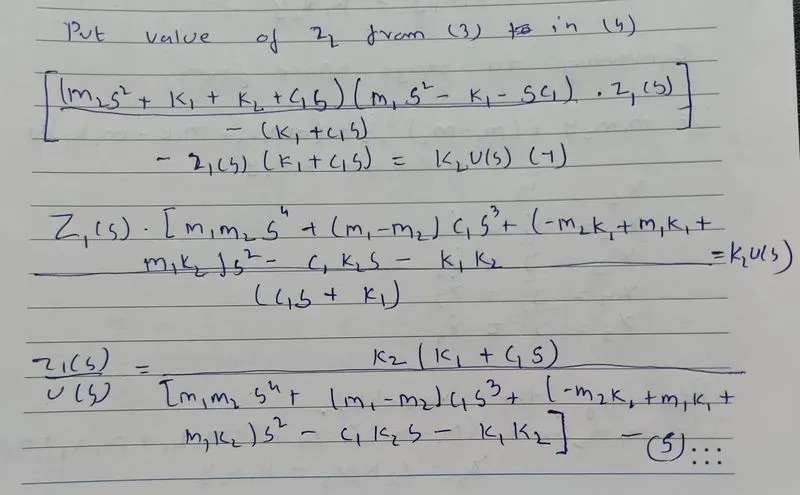
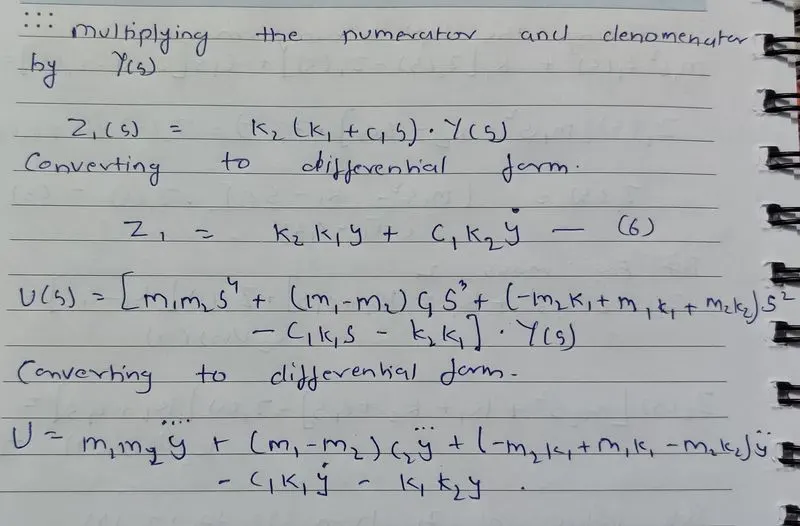
2b) Convert the transfer function to stage space form
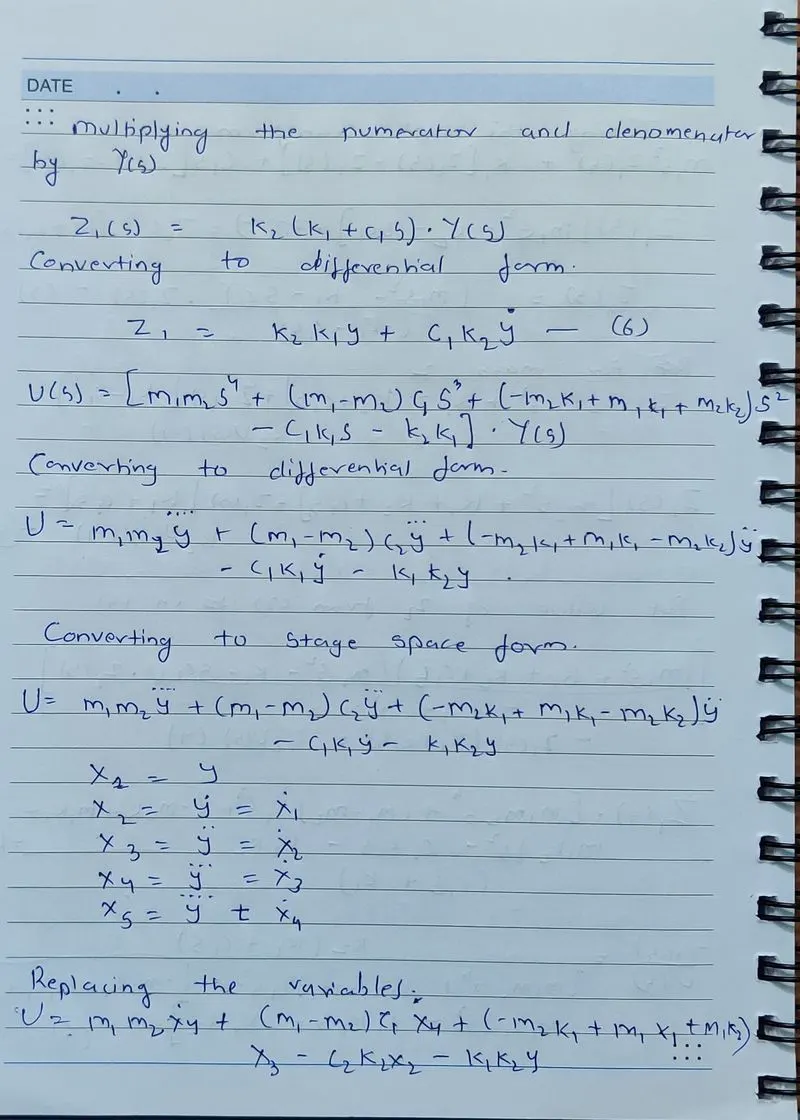
2c) Perform the same in MATLAB
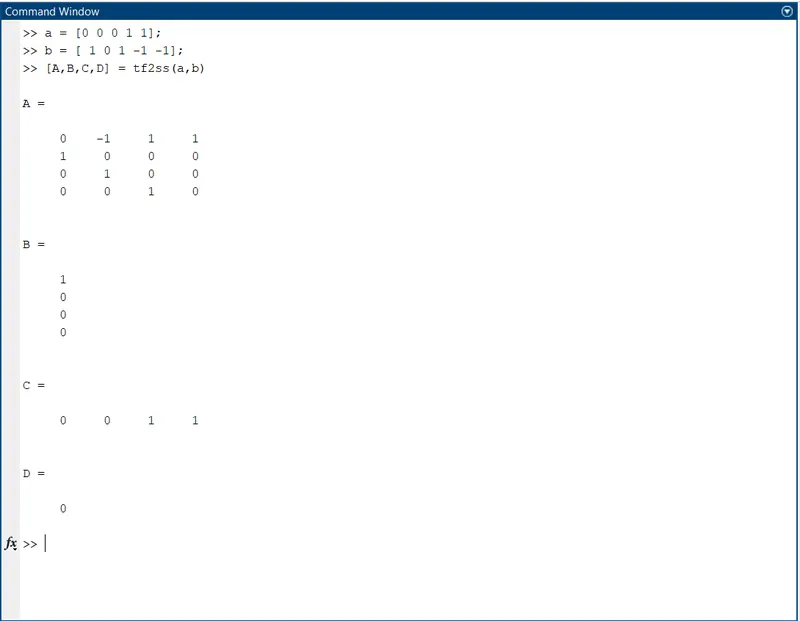
Thus the transfer function for the suspension is created and it is converter to its respective state-space representation.
STEPS
- Expand the command prompt.
- Type the required transfer function.
- Change the transfer function to the state-space model by typing the command "tf2ss"
- Press enter
- Check the error.
OBJECTIVE -3 Derive the transfer functions for the RC(output across C) and CR (output across R) circuits shown below. Are they equal?
The transfer function of the RC circuit is not the same because the output of the RC circuit CR circuit is not the same because the output of RC circuit is across capacitor whereas the output for the CR circuit is across Resistor.
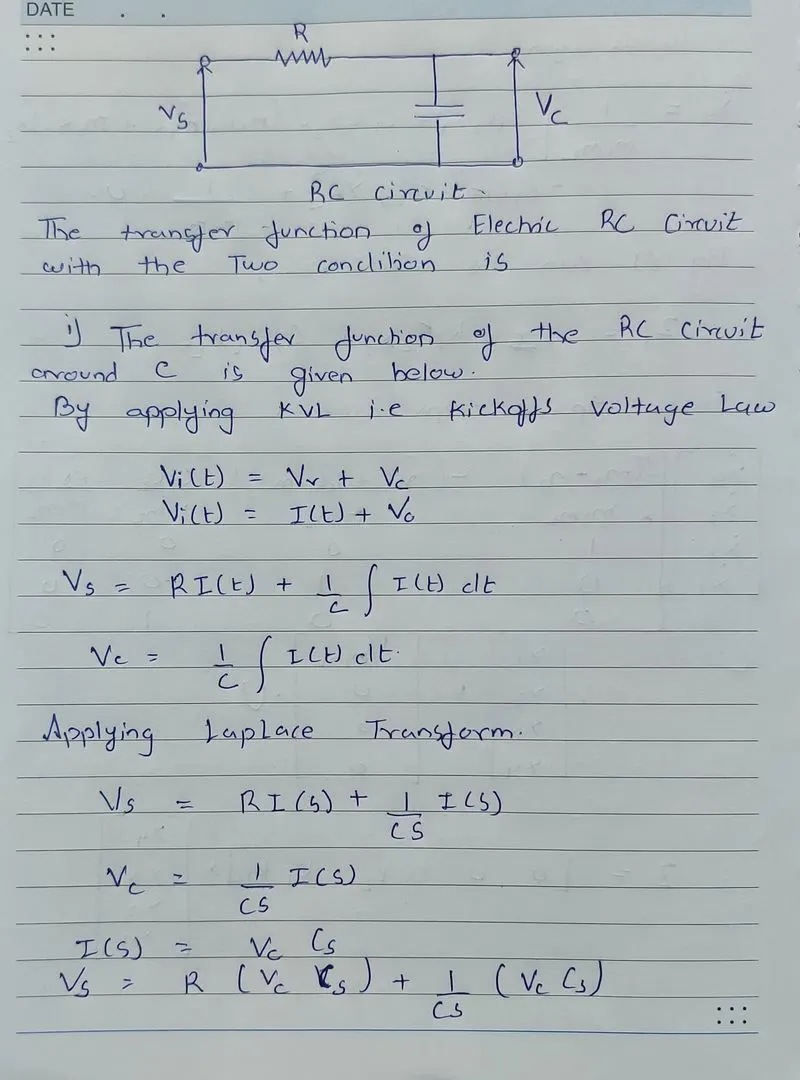
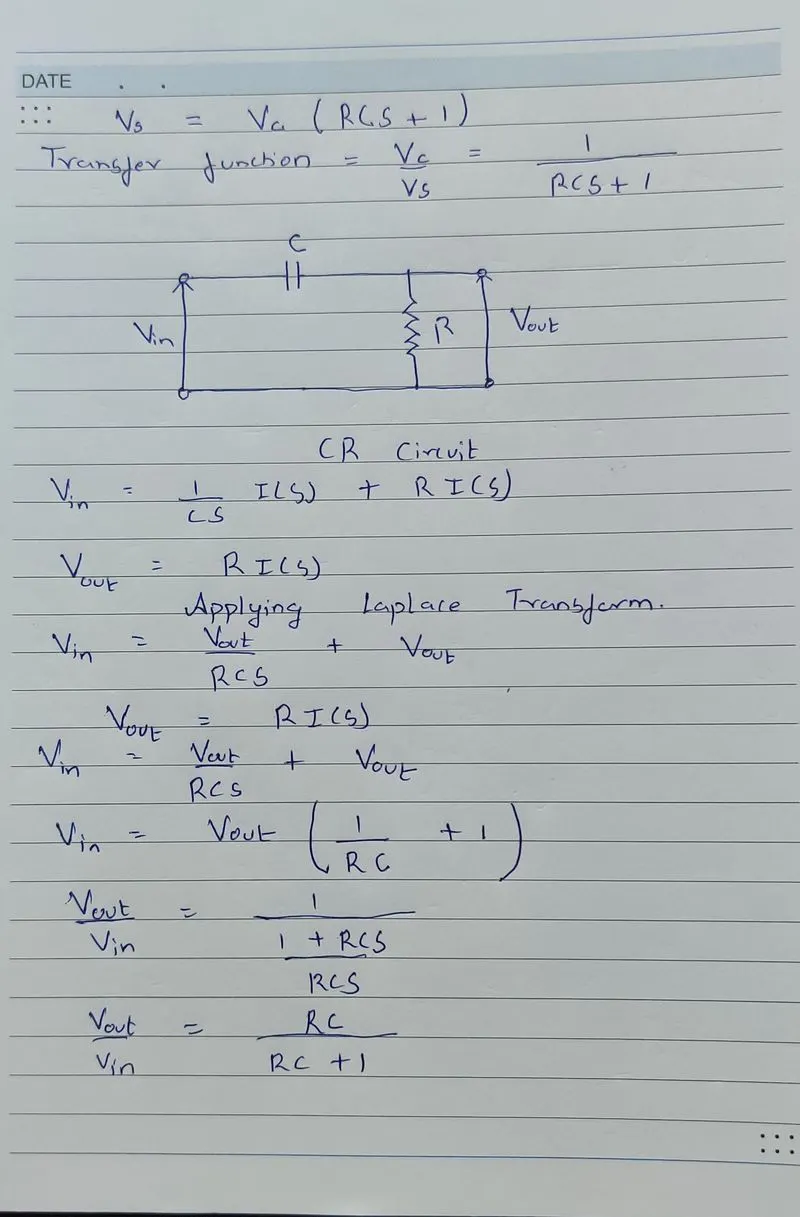
Hence they are not equal. Changing the position of the capacitor and resistor in the circuit doesn't make a difference to the input voltage but it changes the output voltage which is why the transfer function cannot be the same.
CONCLUSION
- We all know that there are few disadvantages of autonomous vehicles due to the bulkiness of the devices used in that but in the coming time we will overcome that much
- We got to find the method to convert the physical model of the spring, mass, damper and then converting it into the transfer function, then converting it into the state-space model.
- From above we have concluded that both the transfer functions are different in both the terms in accordance to the C and R.