TO WRITE A PROGRAM IN MATLAB TO STIMULATE THE FORWARD KINEMATIC OF 2R ROBOTIC ARM.
Aim- To write a program in matlab to stimulate the forward kinematic of 2R Robotic arm .
THEORY :
KINEMATICS-
kinematic is a subfield of physics ,developed in classical mechanics , that describe the motion of points ,bodies ,and system of bodies, without considering the force that cause them to move .
ROBOTIC ARM-
A robotic arm is a type of mechanical arm, usually programmable, with similar functions to a human arm; the arm may be the sum total of the mechanism or may be part of a more complex robot. The links of such a manipulator are connected by joints allowing either rotational motion (such as in an articulated robot) or translational (linear) displacement. The links of the manipulator can be considered to form a kinematic chain. The terminus of the kinematic chain of the manipulator is called the end effector and it is analogous to the human hand. However, the term "robotic hand" as a synonym of the robotic arm is often proscribed.
ALL DATA REQUIRED FOR ROBOTIC ARM STIMULATION :
The 2R robotic arm consist of 2 link and robotic manipulator which is connected at the end of the link 2. These two links are connected to a rotational joints .
THE 2 LINKS ARE AS FOLLOWS :
LINK 1 - it is of length L1 and rotated bY an angle of (theta1) around x-axis.
LINK 2- it is OF length L2 and rotated by an angle of (theta2) around x-axis .
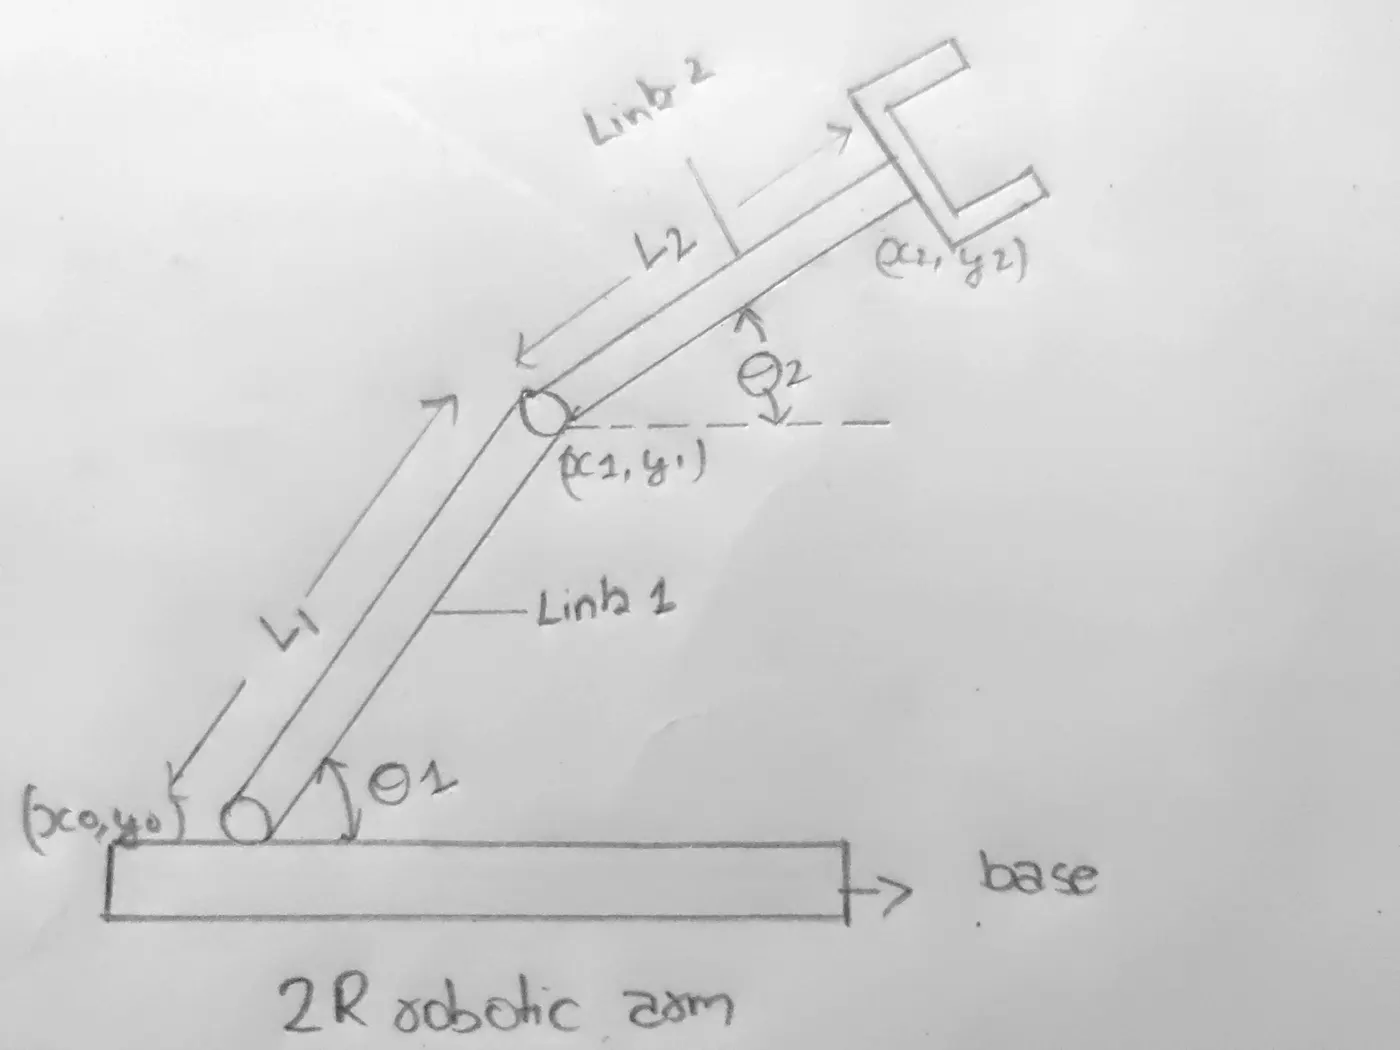
FIG -1
here we need to determine the quardinates of the three points,
origin point- x0 y0 ( starting point of link 1)
intermediate point - x1 y1 (endning point of link 1 and starting point of link 2 ) .
End point - x2 y2 ( ending point of link 2 ) .
now from fig -1 we have
x0 = 0
y0 = 0
x1 = l1*cosd(theta 1 )
y1 = l1*sind (theta1)
x2 = x1 +l2 cosd(theta2)
y2 = y1+l2 sind(theta2)
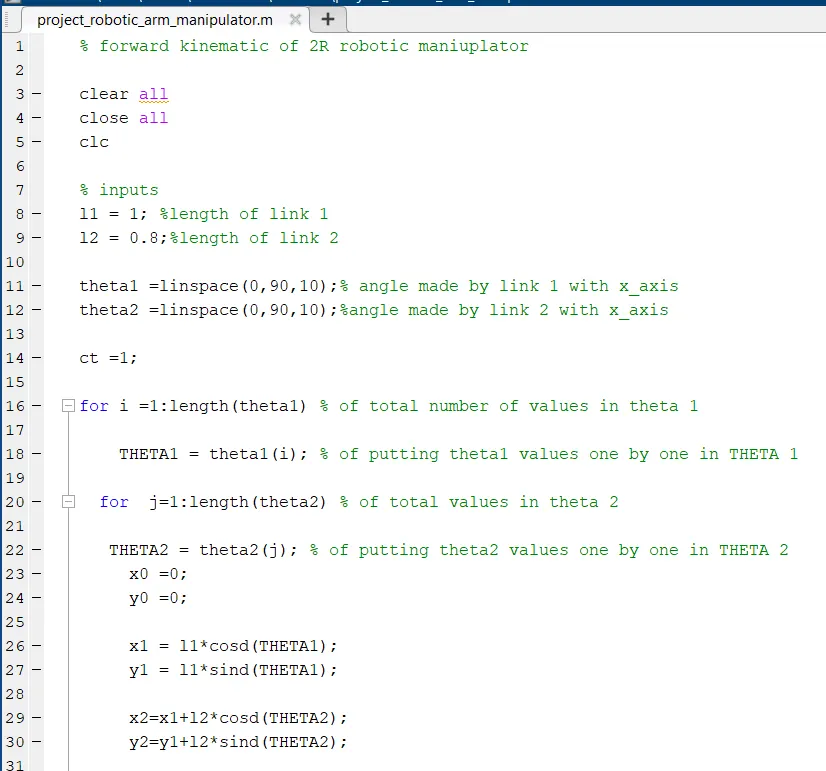
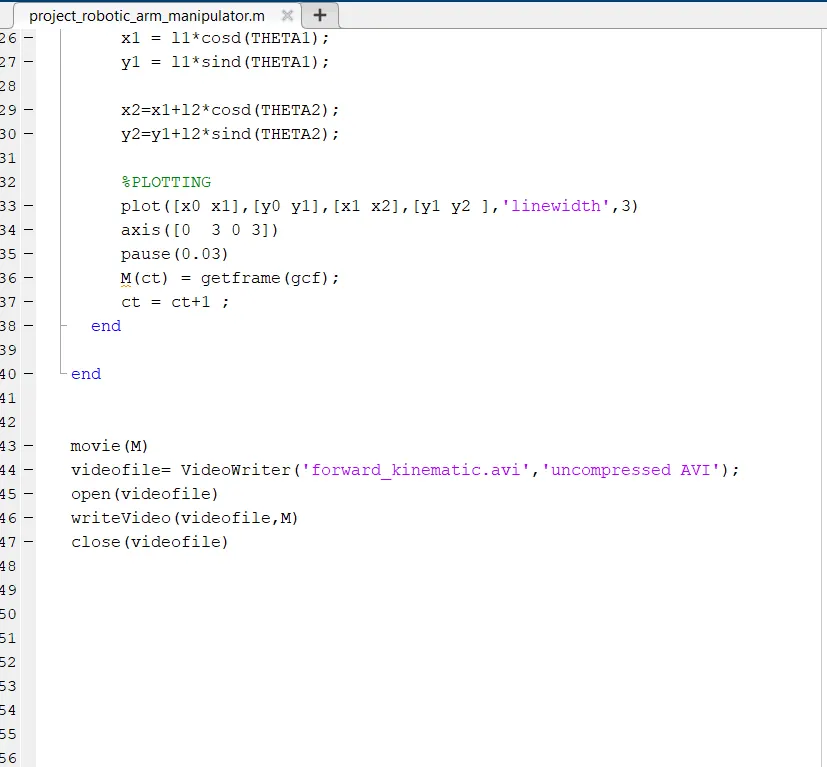
PROGRAM WRITTEN -
page -1
page -2
SIMULATION VIDEO LINK -
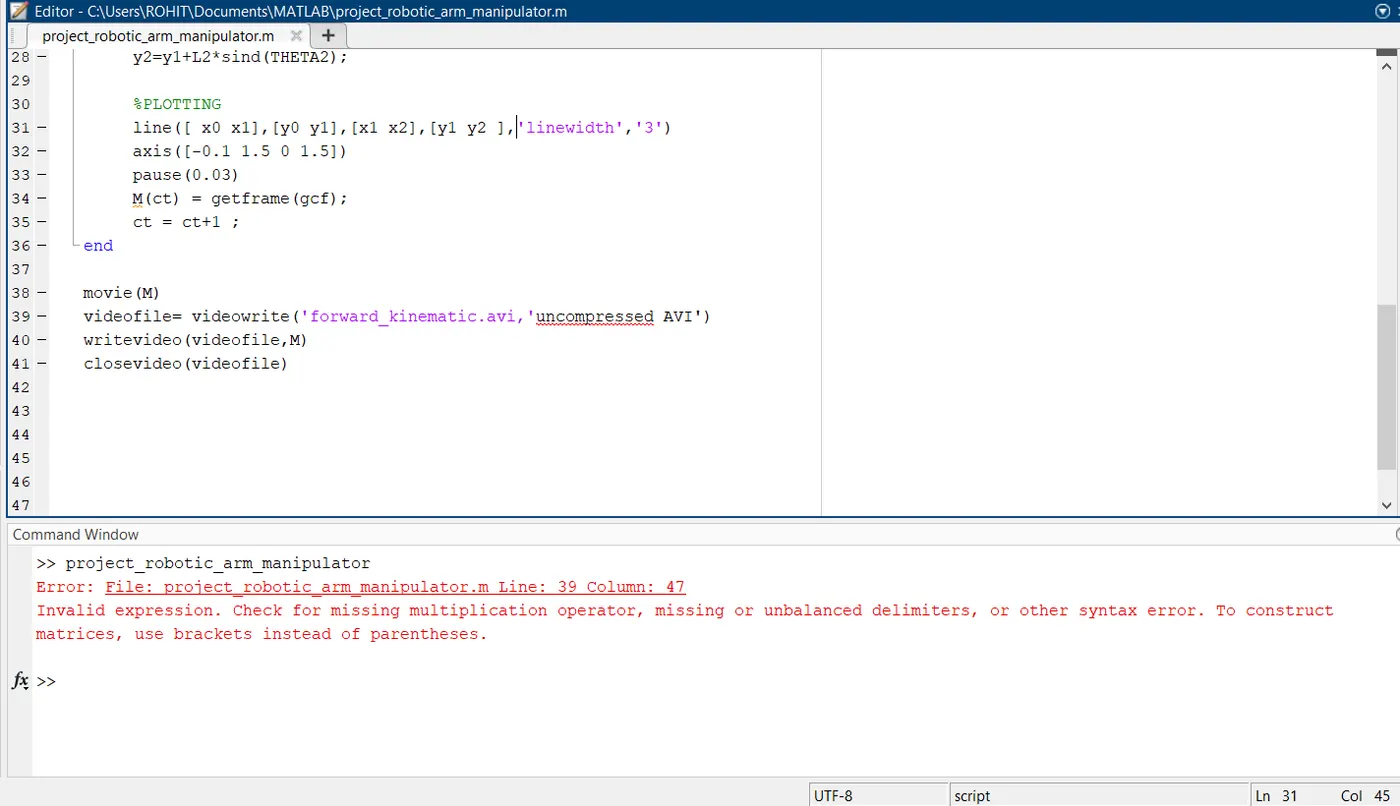
ERRORS I FACED WHILE WRITING A PROGRAMM
ERROR -1
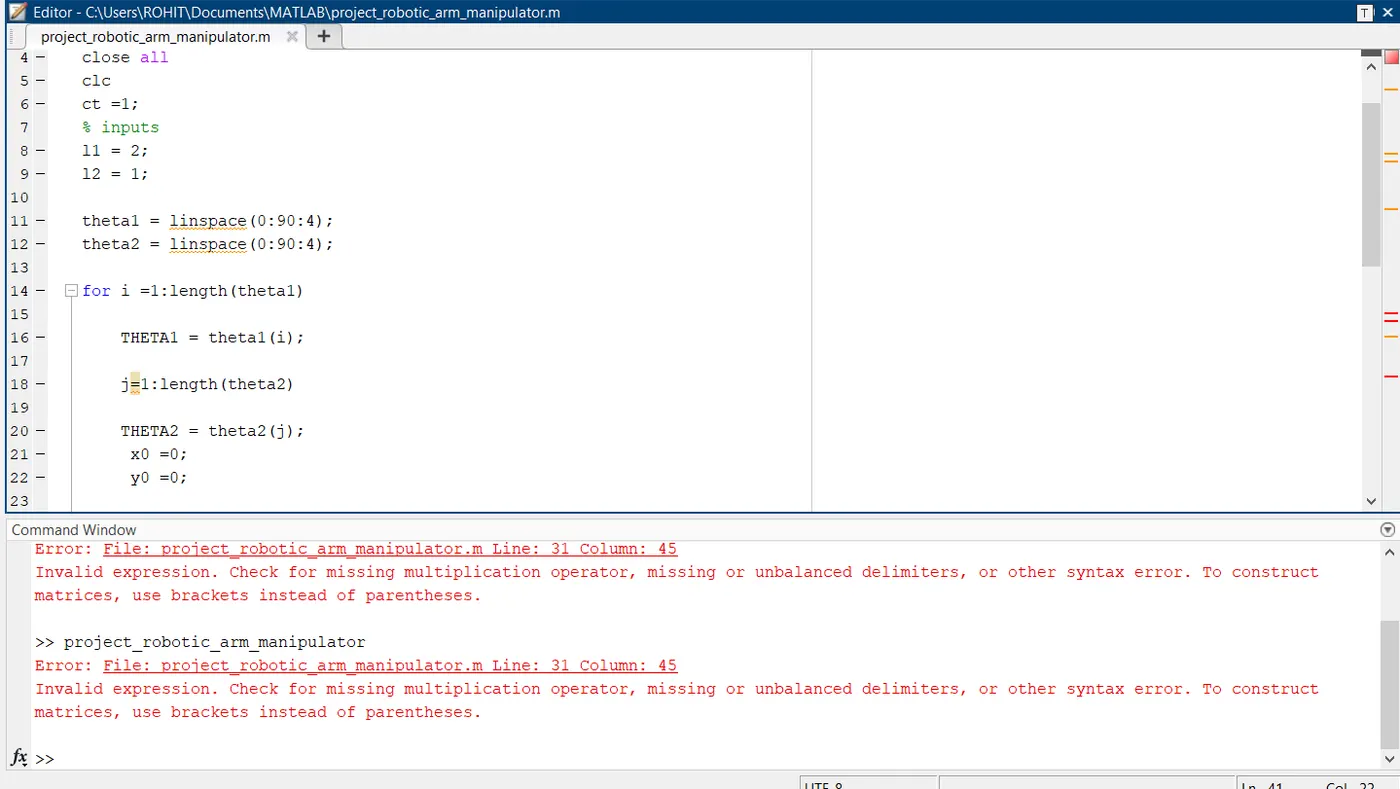
ERROR -2
RESULT -
THE PROGRAM FOR SIMULATION OF FORWAD KINEMATIC PF 2R ROBITIC ARM HAS BEEN CREATED USING MATLAB.