Section Modulus calculation and optimization
SECTION MODULUS CALCULATION OF HOOD
Aim:
To calculate the section modulus of the previously designed hood and also optimizing the design to see the difference in the bending strength of the hood.
Section Modulus:
It is the ratio of Moment of Inertia (I) of the beam cross-section about the neutral axis to the distance (ymax) of extreme fiber from the neutral axis.
Section modulus is a geometric property for a given cross-section used in the design of beams or flexural members. Other geometric properties used in design include area for tension and shear, radius of gyration for compression, and moment of inertia and polar moment of inertia for stiffness. There are two types of section modulus, the elastic section modulus and the plastic section modulus.
the section modulus is calculated by,
S= I/y
Where, S=Section Modulus
I = Moment of Inertia
y = distance between the neutral axis and the extreme end of the object
Types Of Section Modulus:
- Elastic Section Modulus
- Plastic Section Modulus
Elastic Section Modulus
The elastic section modulus is defined as the ratio of the second moment of area (or moment of inertia) and the distance from the neutral axis to any given (or extreme) fiber. It can also be defined in terms of the first moment of area.
| Cross-sectional shape | Figure | Equation | Comment |
|---|---|---|---|
| Rectangle | S = b h 2 6 {\displaystyle S={\cfrac {bh^{2}}{6}}}  |
Solid arrow represents neutral axis | |
| doubly symmetric I-section (major axis) | S x = B H 2 6 − b h 3 6 H {\displaystyle S_{x}={\cfrac {BH^{2}}{6}}-{\cfrac {bh^{3}}{6H}}} 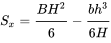
S x = I x y {\displaystyle S_{x}={\tfrac {I_{x}}{y}}} with y = H 2 {\displaystyle y={\cfrac {H}{2}}} |
NA indicates neutral axis | |
| doubly symmetric I-section (minor axis) | S y = B 2 ( H − h ) 6 + ( B − b ) 3 h 6 B {\displaystyle S_{y}={\cfrac {B^{2}(H-h)}{6}}+{\cfrac {(B-b)^{3}h}{6B}}} 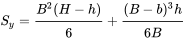 [4] |
NA indicates neutral axis | |
| Circle | S = π d 3 32 {\displaystyle S={\cfrac {\pi d^{3}}{32}}}  [3] |
Solid arrow represents neutral axis | |
| Circular hollow section | S = π ( r 2 4 − r 1 4 ) 4 r 2 = π ( d 2 4 − d 1 4 ) 32 d 2 {\displaystyle S={\cfrac {\pi \left(r_{2}^{4}-r_{1}^{4}\right)}{4r_{2}}}={\cfrac {\pi (d_{2}^{4}-d_{1}^{4})}{32d_{2}}}} 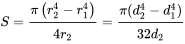 |
Solid arrow represents neutral axis | |
| Rectangular hollow section | S = B H 2 6 − b h 3 6 H {\displaystyle S={\cfrac {BH^{2}}{6}}-{\cfrac {bh^{3}}{6H}}} 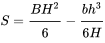 |
NA indicates neutral axis | |
| Diamond | S = B H 2 24 {\displaystyle S={\cfrac {BH^{2}}{24}}}  |
NA indicates neutral axis | |
| C-channel | S = B H 2 6 − b h 3 6 H {\displaystyle S={\cfrac {BH^{2}}{6}}-{\cfrac {bh^{3}}{6H}}} |
NA indicates neutral axis |
 ,

Plastic Section Modulus
The plastic section modulus is used for materials where elastic yielding is acceptable and plastic behavior is assumed to be an acceptable limit. Designs generally strive to ultimately remain below the plastic limit to avoid permanent deformations, often comparing the plastic capacity against amplified forces or stresses.
| Description | Figure | Equation | Comment |
|---|---|---|---|
| Rectangular section | Z P = b h 2 4 {\displaystyle Z_{P}={\cfrac {bh^{2}}{4}}}  [5][6] |
A C = A T = b h 2 {\displaystyle A_{C}=A_{T}={\cfrac {bh}{2}}}  , y C = y T = h 4 {\displaystyle y_{C}=y_{T}={\cfrac {h}{4}}}  |
|
| Rectangular hollow section | Z P = b h 2 4 − ( b − 2 t ) ( h 2 − t ) 2 {\displaystyle Z_{P}={\cfrac {bh^{2}}{4}}-(b-2t)\left({\cfrac {h}{2}}-t\right)^{2}} 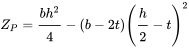 |
where: b = width, h = height, t = wall thickness | |
| For the two flanges of an I-beam with the web excluded[7] | Z P = b 1 t 1 y 1 + b 2 t 2 y 2 {\displaystyle Z_{P}=b_{1}t_{1}y_{1}+b_{2}t_{2}y_{2}\,} 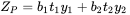 |
where:
b 1 , b 2 {\displaystyle b_{1},b_{2}} |
|
| For an I Beam including the web | Z P = b t f ( d − t f ) + 0.25 t w ( d − 2 t f ) 2 {\displaystyle Z_{P}=bt_{f}(d-t_{f})+0.25t_{w}(d-2t_{f})^{2}} 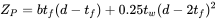 |
[8] | |
| For an I Beam (weak axis) | Z P = ( b 2 t f ) / 2 + 0.25 t w 2 ( d − 2 t f ) {\displaystyle Z_{P}=(b^{2}t_{f})/2+0.25t_{w}^{2}(d-2t_{f})} 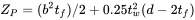 |
d = full height of the I beam | |
| Solid Circle | Z P = d 3 6 {\displaystyle Z_{P}={\cfrac {d^{3}}{6}}}  |
||
| Circular hollow section | Z P = d 2 3 − d 1 3 6 {\displaystyle Z_{P}={\cfrac {d_{2}^{3}-d_{1}^{3}}{6}}}  |
 =width, t 1 , t 2 {\displaystyle t_{1},t_{2}}
 =thickness, y 1 , y 2 {\displaystyle y_{1},y_{2}}
 are the distances from the neutral axis to the centroids of the flanges respectively.
Calculations:
Case 1:
Without optimisation,
the previously designed hood is imported and section inertia analysis is done.
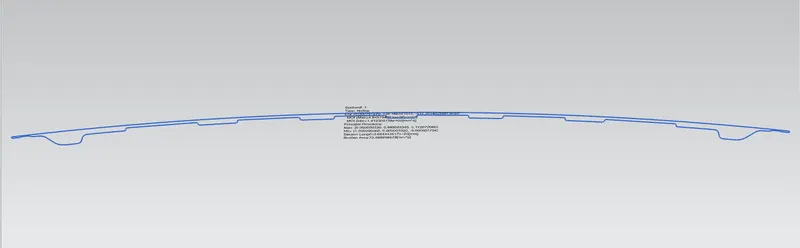
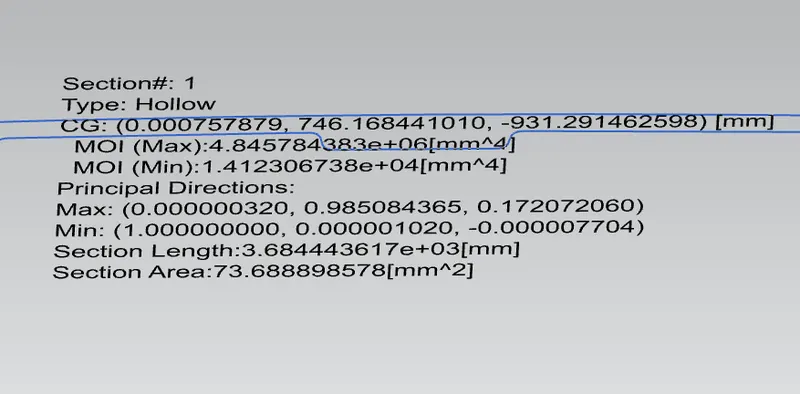
S= I/Y
Where, S=Section Modulus
I = Moment of Inertia(min value is used)
Y = total distance / 2
MOI (max) = 4.845784383e+06 (mm^4)
MOI (min) = 1.412306738e+04 (mm^4)
I=14123.06738(mm^4)
Y=876.3048m/2=438.1524m
therefore,
S=14123.06738/438.1524
S=32.233230675mm^3
Case 2:
After Optimisation,
the depth of the inner panel is increased by 0.5mm..
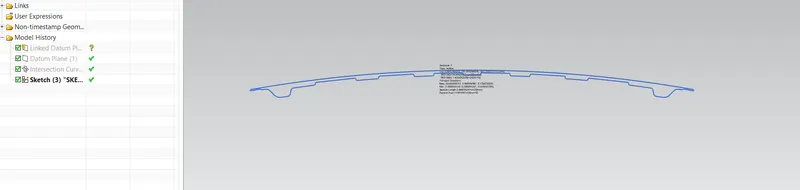
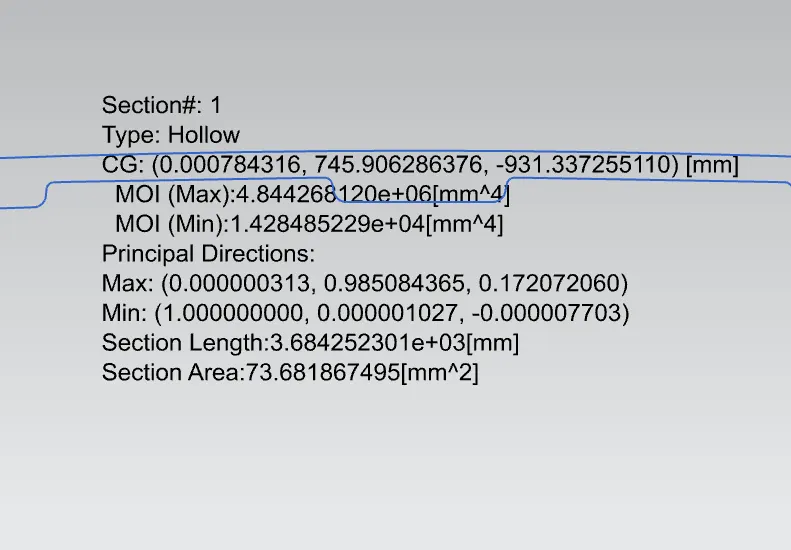
S= I/Y
Where, S=Section Modulus
I = Moment of Inertia(min value is used)
Y = total distance / 2
MOI (max) = 4.844268120e+06 (mm^4)
MOI (min) = 1.428485229e+04 (mm^4)
I=14284.85229
Y=876.3048m/2=438.1524m
therefore,
S=14284.85229/438.1524
S=32.6024741391mm^3
Conclusion:
From the result the strength of the material is directly proportional to the Moment of inertia. Hence, we increase the cross -section area of the hood, it will increase the strength of object. So, it will offer resistance against force acting on the Hood panel.
We can increase the section modulus just increasing the gap between the outer and inner panel.