Deriving 4th order approximation of a 2nd order derivative using Taylor Table method.
AIM: Deriving 4th order approximation of a 2nd order derivative using Taylor Table method.
OBJECTIVE:
A. Derive the following 4th order approximations of the second-order derivative,
- Central difference
- Skewed right-sided difference
- Skewed left-sided difference
B. To write a program in Matlab to evaluate the second-order derivative of the analytical function exp(x)⋅cos(x)">`exp(x).cos(s)`and compare it with the 3 numerical approximations derived.
C. To describe why a skewed scheme is useful and what can a skewed scheme do that a central difference scheme cannot.
Calculation
The formula to find the 4th order approximation of a second-order derivative using the central difference method is as follows
`(delta^2f)/(deltax^2) approx (a*f(x-2Deltax)+b*f(x-Deltax)+c*f(x)+d*f(x+Deltax)+e*f(x+2Deltax))/(Deltax^2)`
To solve the above equation we have to expand each term using the Taylor series and solve this coefficient. But this method is time-consuming and so instead we use Taylor table method. In this method, we won’t expand each term in the above equation individually. Instead, a table will be drawn in which the columns will represent the order of derivative, and rows will represent the terms whose Taylor series expansion has to be found out. And then the coefficients will be written in the respective places.
| Terms | `f(i)` | `Deltaxf^I(x)` | `Deltax^2f^(II)(x)` | `Deltax^3f^(III)(x)` | `Deltax^4f^(IV)(x)` |
| `a.f(i-2)` | a | -2a | `(4/2)a` | `((-8)/6)a` | `(16/24)a` |
| `b.f(i-1)` | b | -b | `b/2` | `-(b/6)` | `b/24` |
| `c.f(i)` | c | 0 | 0 | 0 | 0 |
| `d.f(i+1)` | d | d | `d/2` | `d/6` | `d/24` |
| `e.f(i+2)` | e | 2e | `(4/2)e` | `8/6e` | `16/24e` |
| Coefficient sum value | 0 | 0 | 1 | 0 | 0 |
Here we can see that the sum of coefficients in the 3rd column is 1. This is because we are finding the value of the second derivative.
The next step is to find the value of the coefficients by putting this in a matrix. A row of this matrix contains the column of the above table and the column of this matrix contains a row of the above table.
The matrix is given below
`A=[[1,1,1,1,1] , [-2 ,-1 ,0, 1, 2] , [2, 1/2, 0 ,1/2, 2] , [-8/6, -1/6 ,0 ,1/6 ,8/6] , [16/24, 1/24, 0, 1/24, 16/24]]`
Now we will creat a matrix containing variable as shown below.
`B = [[a],[b],[c],[d],[e]]`
And the last matrix is sum of coefficient matrix, which is given below,
`X = [[0],[0],[1],[0],[0]]`
As we know that the value of `A.B = X`
Equation this we can find the value of the coefficient.
Derivation of skewed right-sided difference method
The formula for finding the 4th order approximation of a second derivative is as follows,
`(delta^2f)/(deltax^2) approx (a*f(x)+b*f(x+Deltax)+c*f(x+2Deltax)+d*f(x+3Deltax)+e*f(x+4Deltax)+g*f(x+5Deltax))/(Deltax^2)`
| Terms | `f(x)` | `Delta xF^I(x)` | `Deltax^2f^(II)(x)` | `Deltax^3f^(III)(x)` | `Deltax^4f^(IV)(x)` | `Deltax^4f^V(x)` |
| `a.f(i)` | a | 0 | 0 | 0 | 0 | `0` |
| `b.f(i+1)` | b | b | `b/2` | `b/6` | `b/24` | `b/120` |
| `c.f(i+2)` | c | 2c | `4/2c` | `8/6c` | `16/24c` | `32/120c` |
| `d.(f(i+3)` | d | 3d | `9/2d` | `27/6d` | `81/24d` | `243/120d` |
| `e.f(i+4)` | e | 4e | `16/2e` | `64/6e` | `256/24e` | `1024/120e` |
| `g.f(1+5)` | g | 5g | `25/2g` | `125/2g` | `625/24g` | `3125/120g` |
| Coefficient sum value | 0 | 0 | 1 | 0 | 0 | 0 |
`A = [[1,1,1,1,1,1] , [0 ,1 ,2 ,3 ,4, 5] ,[0, 1/2 ,2, 9/2, 8 ,25/2], [0 ,1/6 ,4/3, 9/2, 32/3, 125/6] , [0 ,1/24, 16/24, 81/24, 256/24 ,625/24] , [0 ,1/120, 32/120 ,243/120, 1024/120, 3125/120]]`
`B = [[a],[b],[c],[d],[e],[g]]`
`C = [[0],[0],[1],[0],[0],[0]]`
Now putting these in the below equation
`A.B = X`
After finding the coefficient we will put those in equation (2).
Derivation of skewed left-sided difference method
The formula for finding the 4th order approximation of a second derivative is as follows,
`(delta^2f)/(deltax^2) approx (a*f(x-5Deltax)+b*f(x-4Deltax)+c*f(x-3Deltax)+d*f(x-2Deltax)+e*f(x-Deltax)+g*f(x))/(Deltax^2)`
| Terms | `F(i)` | `Deltaxf^I(x)` | `Deltax^2f^(II)(x)` | `Deltaxf^(III)(x)` | `Deltax^4f^(IV)(x)` | `Deltax^4f^(V)(x)` |
| `a.f(i-5)` | a | -5a | `25/2a` | `-125/6a` | `625/24a` | `-3125/120a` |
| `b.f(i-4)` | b | -4b | `16/2b` | `-64/6b` | `256/24b` | `-1024/120b` |
| `c.f(i-3)` | c | -3c | `9/2c` | `-27/6c` | `81/24c` | `-243/120c` |
| `d.(f-2)` | d | -2d | `4/2d` | `-8/6d` | `16/24d` | `243/120d` |
| `e.f(i-1)` | e | -e | `1/2` | `-1/6e` | `1/24e` | `-32/120e` |
| `g.f(i)` | g | 0 | 0 | 0 | 0 | 0 |
| Coefficient sum value | 0 | 0 | 0 | 0 | 0 |
`A = [[1,1,1,1,1,1] , [-5 ,-4 ,-3 ,-2, -1, 0] , [25/2, 16/2, 9/2, 4/2 ,1/2, 0] , [-125/6, -64/6 ,-27/6 ,-8/6 ,-1/6 ,0] ,[625/24, 256/24, 81/24, 16/24, 1/24, 0], [-3125/120 ,-1024/120,-243/120, -32/120, -1/120, 0]]`
`B = [[a],[b],[c],[d],[e],[g]]`
`C = [[0],[0],[1],[0],[0],[0]]`
Order of accuracy
Now let us check whether the 2 skewed schemes are 4th order accurate by using the following formula,
The order of accuracy, P = N -Q">P = N −QP = N -Q
Where N is the number of nodes in the stencil and Q is the order of derivative.
So from the above derivations, we know that order of derivative, Q=2">Q=2
And, N=6">N=6
this is the same as the number of coefficients in the equation.
So, P=6-2">P=6−2
=4">=4
Hence its proved that the two skewed schemes are 4th order accurate.
MATLAB code
Function code
Central difference
function [cd] = central_differencing (x,dx)

A = [1 1 1 1 1 ; -2 -1 0 1 2 ; 2 1/2 0 1/2 2 ; -8/6 -1/6 0 1/6 8/6 ; 16/24 1/24 0 1/24 16/24];
B = inv(A);
X = B(:,3);
a = X(1);
b = X(2);
c = X(3);
d=b;
e=a;
cd = (a*exp(x-(2.*dx)).*cos(x-(2.*dx))+b.*exp(x-dx).*cos(x-dx)+c*exp(x)*cos(x)+d.*exp(x+dx).*cos(x+dx)+e.*exp(x+(2*dx)).*cos(x+(2.*dx)))./dx.^2;
end
Right side differencing
function [rsd] = right_side_differencing (x,dx)

A = [1 1 1 1 1 1 ; 0 1 2 3 4 5 ; 0 1/2 2 9/2 8 25/2 ; 0 1/6 4/3 9/2 32/3 125/6 ; 0 1/24 16/24 81/24 256/24 625/24 ; 0 1/120 32/120 243/120 1024/120 3125/120 ];
B = inv(A);
X = B(:,3);
a = X(1);
b = X(2);
c = X(3);
d = X(4);
e = X(5);
g = X(6);

rsd = (a*exp(x)*cos(x)+b.*exp(x+dx).*cos(x+dx)+c.*exp(x+(2.*dx)).*cos(x+(2.*dx))+d.*exp(x+(3.*dx)).*cos(x+(3.*dx))+e.*exp(x+(4.*dx)).*cos(x+(4.*dx))+g.*exp(x+(5.*dx)).*cos(x+(5.*dx)))./dx.^2;
end
Left side differencing
function [lsd] = left_side_differencing (x,dx)

A=[1 1 1 1 1 1 ; -5 -4 -3 -2 -1 0 ; 25/2 16/2 9/2 4/2 1/2 0 ; -125/6 -64/6 -27/6 -8/6 -1/6 0 ; 625/24 256/24 81/24 16/24 1/24 0 ; -3125/120 -1024/120 -243/120 -32/120 -1/120 0 ];
B= inv(A);
X=B(:,3);
a = X(1);
b = X(2);
c = X(3);
d=X(4);
e=X(5);
g=X(6);
lsd = (a.*exp(x-(5.*dx)).*cos(x-(5.*dx))+b.*exp(x-(4.*dx)).*cos(x-(4.*dx))+c.*exp(x-(3.*dx)).*cos(x-(3.*dx))+d.*exp(x-(2.*dx)).*cos(x-(2.*dx))+e.*exp(x-dx).*cos(x-dx)+g*exp(x)*cos(x))./dx.^2;
end- In all three of the functions, we have created the respective matrix containing the coefficients that we already derived.
- Then another matrix is created which is equal to the inverse of the first matrix. For this, we have used the command ‘inv’, which will find the inverse of a given matrix.
- Then the 3rd column of this inverse matrix will be the required values of the coefficients. And we will assign each of these values to the respective coefficients and then use them in the equation.
These function programs will calculate the different methods of approximation as per the equations derived for them.
Main code
clc
clear all
close all

%defining variables
x = pi/3;
dx = linspace(pi/40,pi/4000,20);

% calculating the vvalue of second derivative
syms z;
f = exp(z)*cos(z);
%differenting the function
f_2 = diff(f,2);
analytical_derivative = vpa(subs(f_2,z,pi/3));
ad = double(analytical_derivative);

% for loop to call the function and calculate for different
for i = 1:length(dx)

    cd(i) = central_differencing(x,dx(i));
    rsd(i) =right_side_differencing(x,dx(i));
    lsd(i) = left_side_differencing(x,dx(i));

    % calculating the error
    error_central_difference = abs(cd-analytical_derivative);
    error_right_side_difference = abs(rsd - analytical_derivative);
    error_left_side_difference = abs(lsd-analytical_derivative);

end
%plotting the graphs

% 1st graph
figure(1)
yline(ad,'--','LineWidth',2 ,'color','r');
hold on
plot(dx,cd,'color','k','LineWidth',2 );
hold on
plot(dx,rsd,'color','g','LineWidth',2 );
hold on
plot(dx,lsd,'color','b','LineWidth',2 );
legend('analytical derivative','central differencing','right sided differencing','left sided differencing','location','best');
title('analytical derivative Vs other 3 differencing methods values')
ylabel('derivative value')
xlabel('dx value')

%2nd graph
figure(2)
loglog(dx,error_central_difference,'color','r','LineWidth',2 );
hold on
loglog(dx,error_right_side_difference,'color','g','LineWidth',2 );
hold on
loglog(dx,error_left_side_difference,'color','b','LineWidth',2 );
legend('central differencing error','right sided differencing error','left sided differencing error','location','best');
title('comparison of absolute error between 3 different  methods')
ylabel('error value')
xlabel('dx value')
- First, we have defined the variables used for the calculations. Here we have used ‘linspace’ command to create equally spaced 20 values between pi/40 and pi/4000 for dx.
- Then the analytical value of the second derivative is calculated. For this we have used ‘diff’ command in MATLAB. This command will differentiate symbolic expressions or functions.Syntax for this command is given below,
Df = diff(f,n)">Df = diff(f,n)Df = diff(f,n) computes the nth derivative of f">ff with respect to the symbolic variable.
- For creating a symbolic variable we have used ‘syms’ command.
- After finding the second derivative of the given function we will substitute the value of the variable using ‘vpa’ command.
- This value will be stored as symbolic variable , so in order to convert we use ‘double’ command , which will convert it to double-precision values.
- A for loop is opened with number of iterations equal to length of dx array.
- After that the functions are called inside the for loop. These functions contain the calculation for different methods of approximation.
- Then the error is calculated. Here we used ‘abs’ command , which will return the absolute value.
- Now the for loop is closed using the ‘end’ command.
- Next thing done is to plot a graph comparing the analytical derivative value with the values of other 3 differencing methods. To plot the analytical derivative value which is a constant value , we used ‘yline’ command. This command will plot a horizontal line with constant y-value.
- The second graph plots the comparison of absolute error between the three different methods. For plotting this we have used ‘loglog’ command to have better understanding of the characteristics.
RESULTS
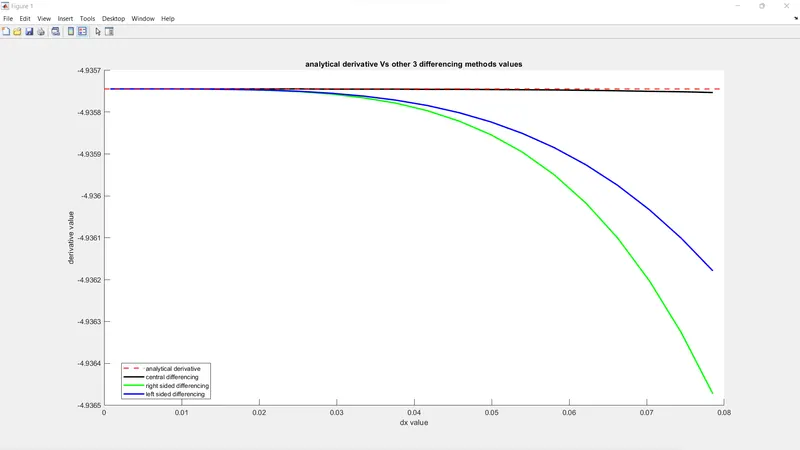
- Here we can see that the numerical derivative values are deviating from the analytical value as the step size increases. This shows that as we increase the step size the error also increases. Here the central differencing method is showing the least deviation and hence we can say that it is almost accurate at all values of dx in this case.
- Whereas right sided and left sided differencing methods are showing very large deviation from the exact value. This shows that these two methods are less accurate compared to central differencing method. Right sided method is the most deviating and hence it is the least accurate of all three methods.
Now let us look at the comparison of absolute error values of the three numerical approximation methods graph.
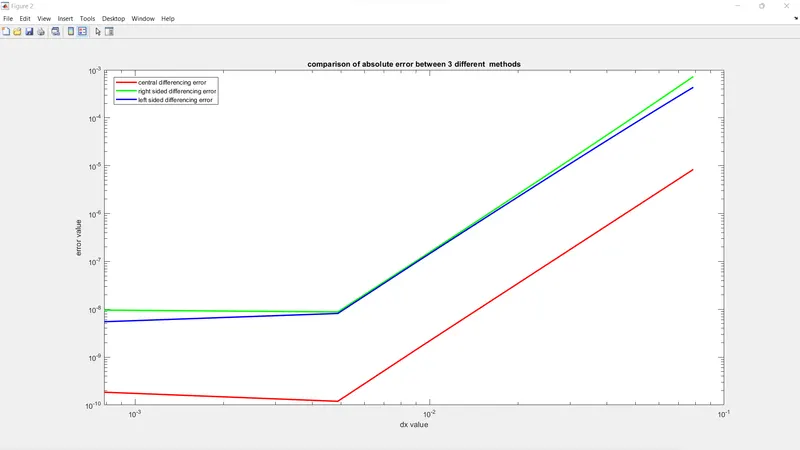
- In this graph we can see that the error is decreasing till a point as the value of dx is decreasing. At any given value of the dx we can see that the error value of central method is always lower compared to other two methods.
- Coming to the other two methods ,we can see that they are very close to each other , this means that the error values of these methods are comparable to each other and almost similar. Even then the left sided method is having low error at any given value of dx.
Advantage of skewed scheme over symmetric
To understand why a skewed is useful and what it can do that a symmetric can’t do , we need to take an example scenario , which is explained below,
Suppose if the flow field characteristics has to be evaluated starting from the boundary with second order accuracy. The y-axis is perpendicular to this boundary and we need to do the finite difference approximation at the boundary.
Let us first try to solve it using symmetric method , i.e central differencing , so for this method we need grid points on both sides of the initial point. So in this case we need to have values beyond the boundary , but this is not technically possible as there is no flow field beyond boundary. In this condition the symmetric method is of no use.
Now what are the other methods possible , we have forward differencing method which could be used but it is first order accurate , so we cannot use that.
Here comes the skewed schemes advantage. A skewed scheme is formulated by applying polynomial approach on Taylor series. In this example scenario we can apply skewed scheme because it uses information only on one side of the grid point at the boundary. So we need only the grid points above the boundary to find the finite difference expression for the derivative at the boundary. Also the order of accuracy can be decide as per the requirement by adding grid points.
CONCLUSION
MATLAB program that compares the central, right sided and left sided schemes of approximations for the second derivative against the analytical or exact derivative for a range of values for dx has been written successfully and the results has been plotted on a graph. Also the order of accuracy has been verified successfully.