Project - Speed Control of a Direct Current (DC) motor
* steps for the simulink model for the dc motor design are shown below:-
1) %parameter for finding the desired characteristic
J=0.01; %movement of inertia of the rotor in kgm^2
B=0.1; %motor viscous friction constant in Nms
Km=0.01; % Back EMF condtant in v/radins/s
Kt=0.01; % Motor torque constant Nm/Ampere
Ra=1.0; %Armature resistance in ohm
La=0.5; %Armature inductance in henry
2) % finding the values of matrix A and B
A=[-B/J Kt/J;-Km/La -Ra/La];
Bmatrix=[0;1/La];
3) %finding the value of zeta
zeta = 0.8;
4) %finding the value of frequency
fn=1;
Wn=2*pi*fn;
5) %finding the roots by using roots command
P=roots([1 12.5664 39.44]);
6) %use the place command for finding the poles
K=place(A, Bmatrix, P);
7) Kp=6.8780; %value of Kp
Kd=0.832; %value od Kd
Ki=22; %value of Ki
8) In that challenge instead using plot command i used the scope block ti show the direct result.
please find the attatched file of the dc motor control design and also i attatched the script file.
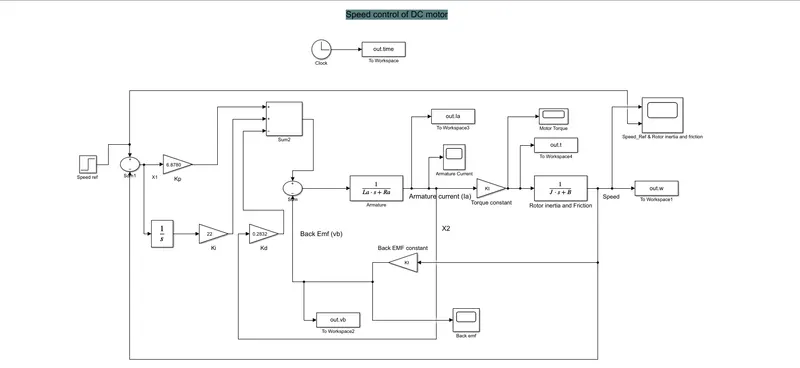
final project module in that image.
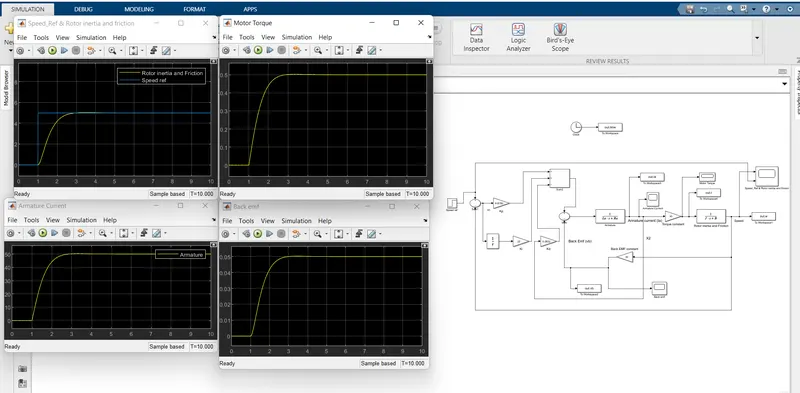
Speed control for DC motor module shown below.
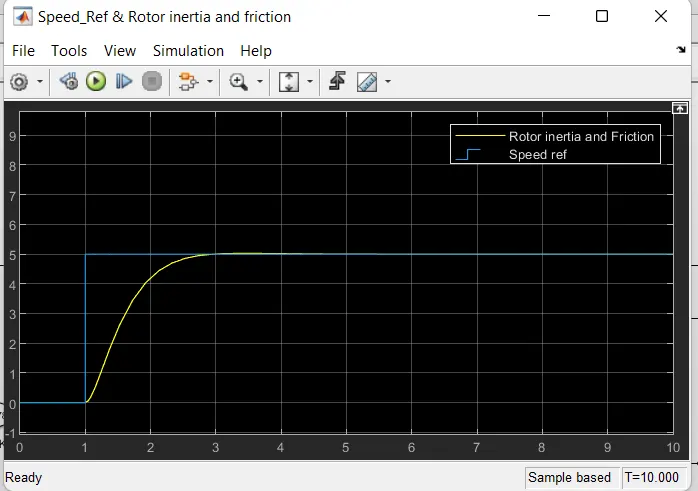
Speed ref and rotor inertia friction graph shown below:-
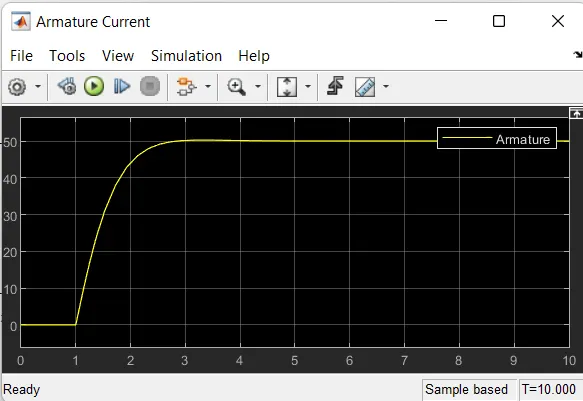
Armature current graph shown in below:-
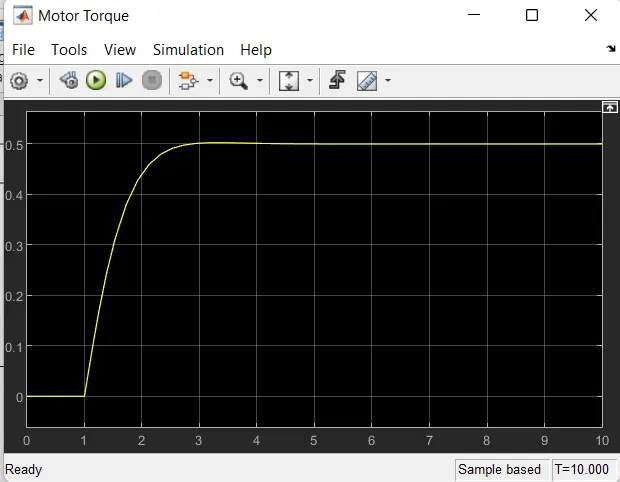
Motor Torque graph shown below:-
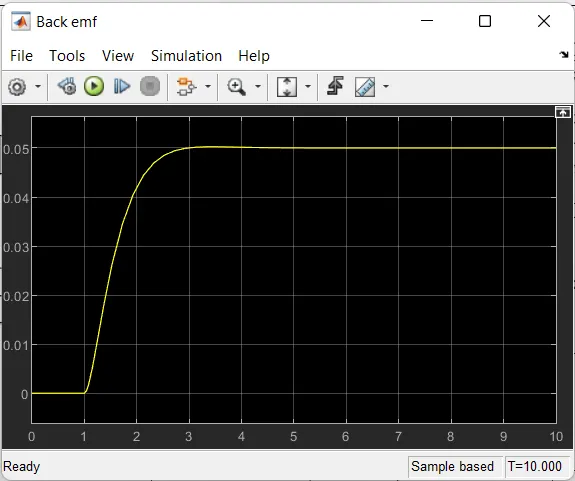
Back emf graph shown below:-