Project - Speed Control of a Direct Current (DC) motor
AIM:
To Build a Simulink model for the DC motor.
To Use the Proportional, Integral, and Derivative (PID) control design knowledge gained in the training to design, develop and test a controller to maintain a desired speed for the motor.
OBJECTIVE:
Build the DC motor simulink model and the control the speed of the motor with the help of PID controller. observe the speed of DC motor for the various input conditions.
THEROY:
DC motor schematic
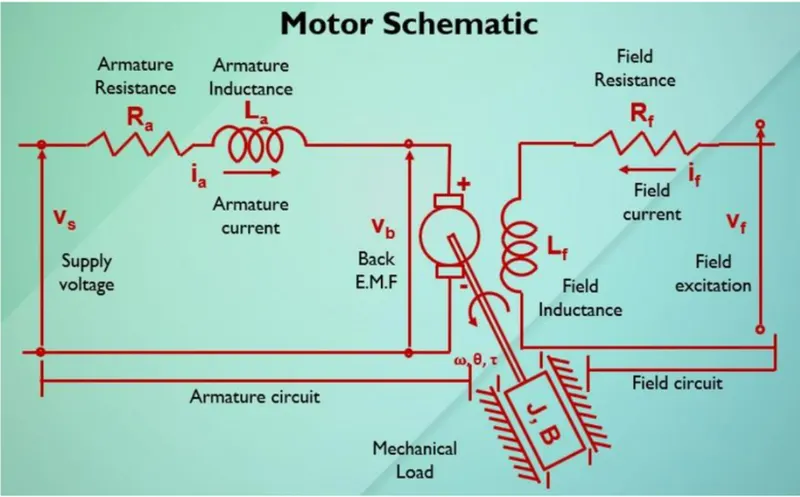
THE DC MOTOR PARAMETERS :
J = moment of inertia
B = Damping constant
R = Armature resistance
L = Armature inductance
Vb = Back EMF
Kt = Motor torque
V = voltage
FORMULAS FOR THE DC MOTOR :
**motor torque T = Kt*I
**Back EMF Vb = Kb*w = Kb(d_teta/dt)
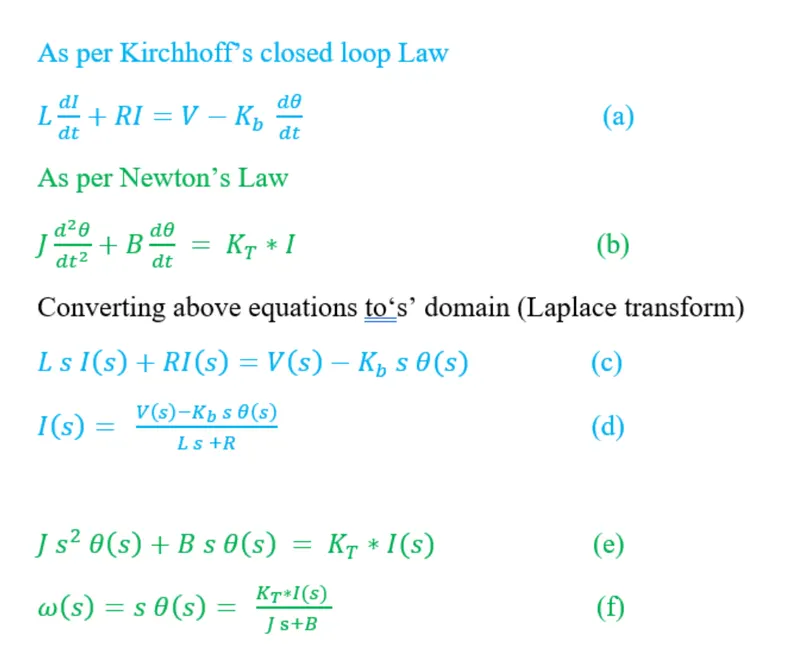
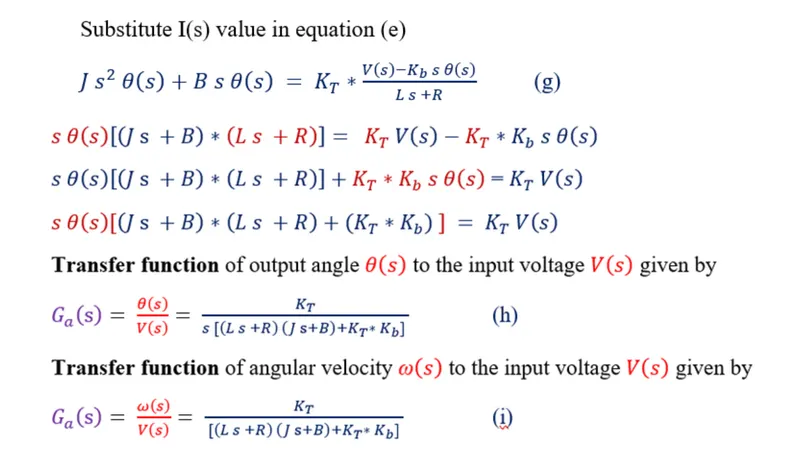
FOR MODELING THE ABOVE DC MOTOR SCHEMATIC THE EQUATIOMS ARE
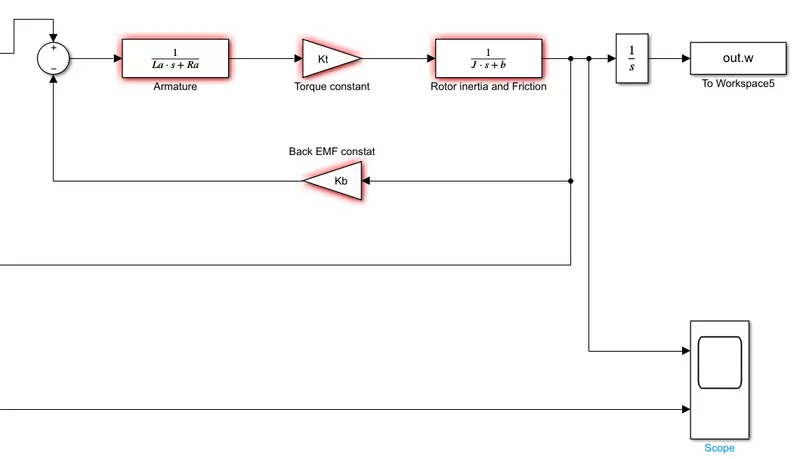
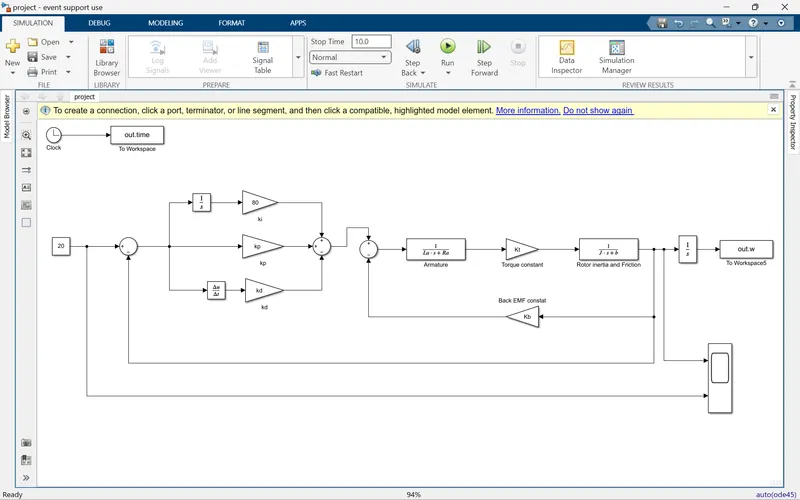
SIMULINK MODEL FOR DC MOTOR
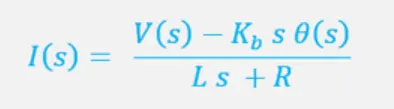
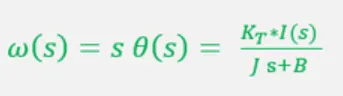
PID CONTROLLER :
The proportional integral derivative controller is the control loop mechanism. it produces the output that is feedback from the plant and that is controlled to desired input signal.The expression for the PID controller is
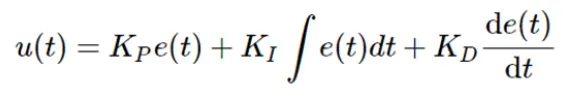
Applying Laplace transform on both sides
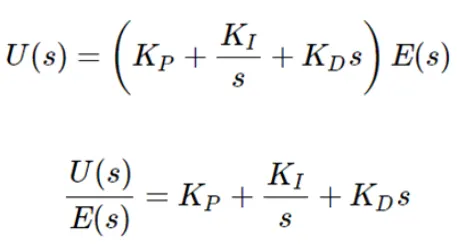
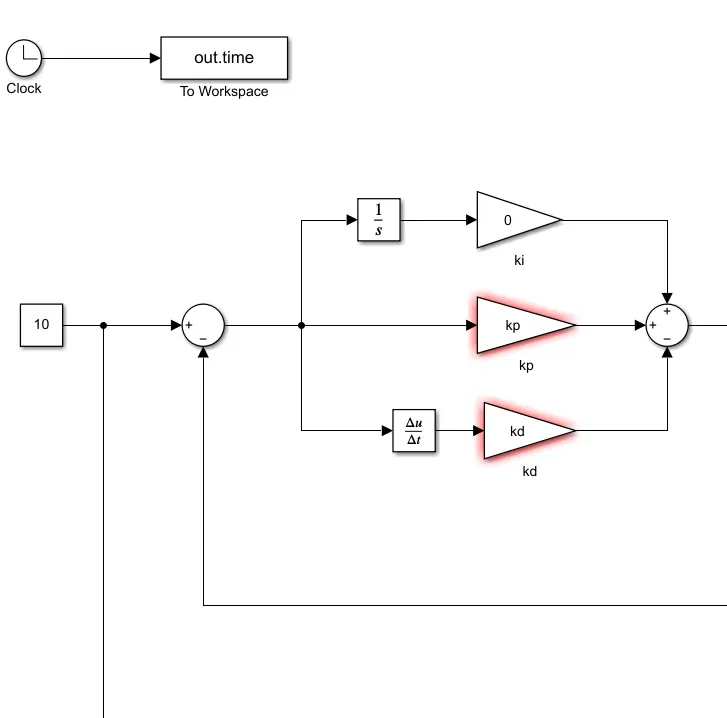
SIMULINK MODEL FOR PID CONTROLLER:
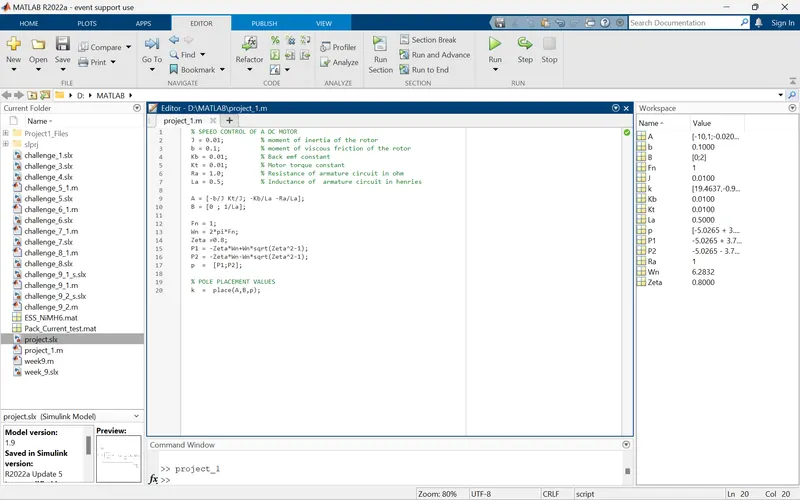
MATLAB CODING FOR DC MOTOR WITH PID CONTROLLER GAINS:
SIMULINK MODEL:
REGULATING THE ki GAIN AND OBSERVE THE BEST RESPONCE:
Let ki = 10 for x_ref = 20
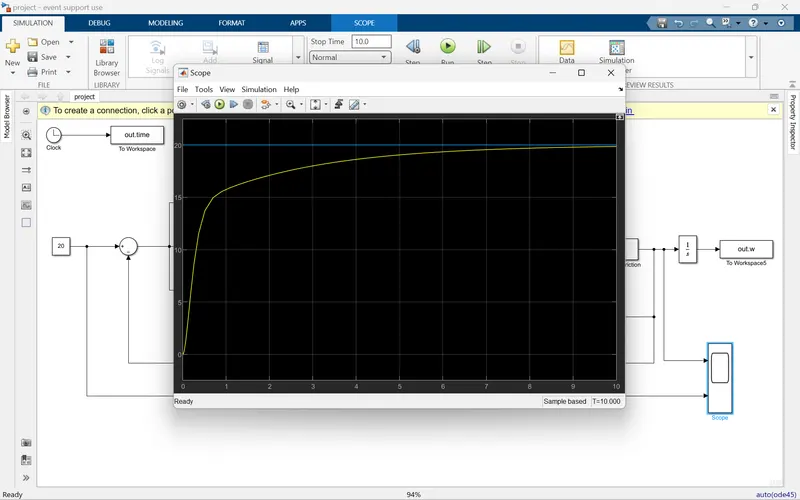
In the scope the PID control is trying to control the motor but under shoot is happend. The control not that much effect on motor. It is not controlling atleast 3 sec.
Let ki = 25
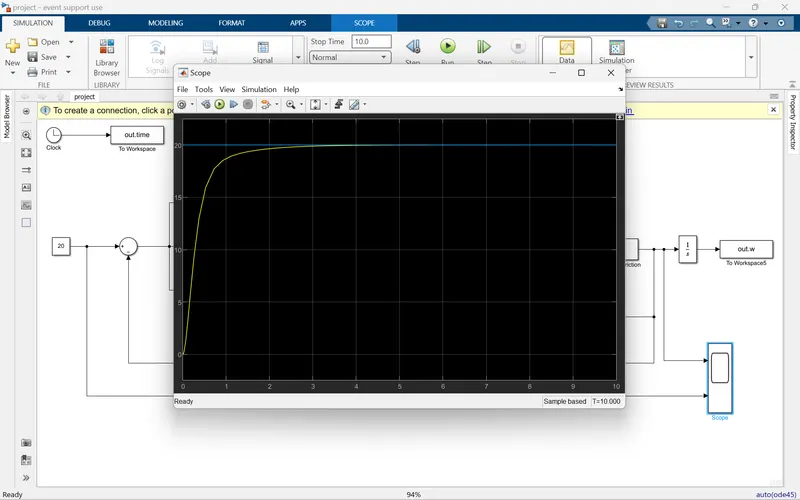
Here in this case the under is minimized but it controls the system less than 2 sec lets try for another value of ki.
Let ki=35
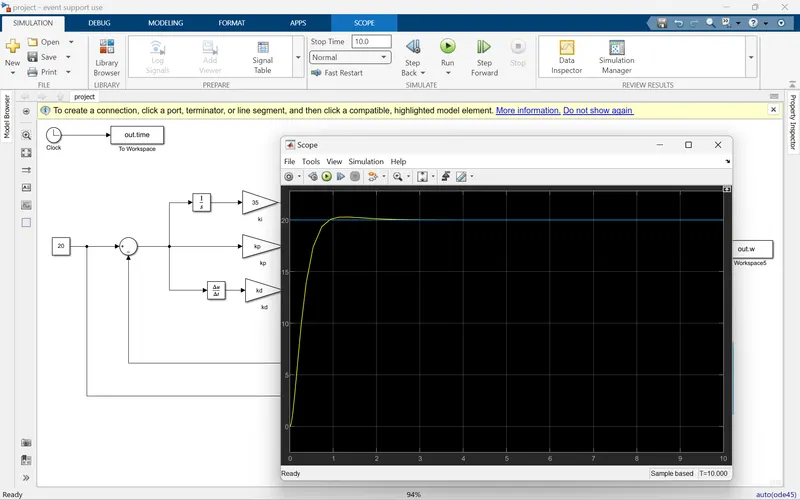
The value of ki is some over shotted slitely in this case. in order to slove that decrease the ki value.
Let ki = 30.5
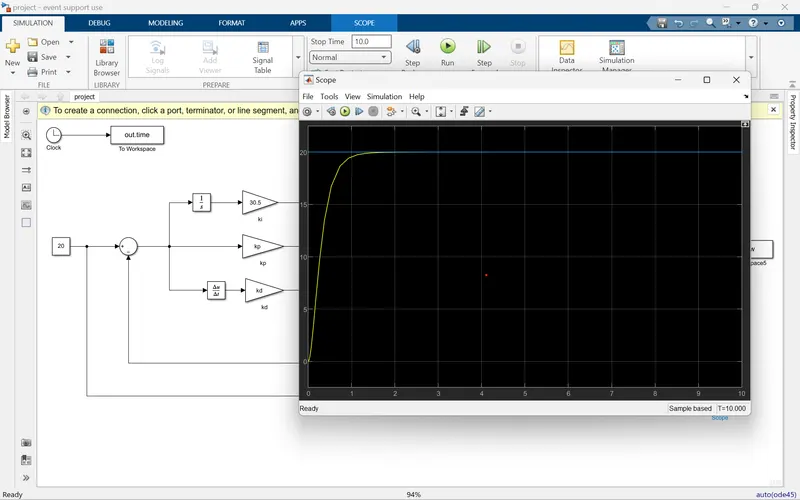
Eventually the system that is the PID controller is controlling the motor at the ki value of 30.5 and the motor is controlled in less than 2sec.
CONCLUSION:
Here the DC motor is modeled and matrics of A B are formed from the equations
The PID controller is modeled in simulink and the gain values are calculated using the palce command.
The model is modeled with feedback signal as speed.i can approach from armature as well.
By tunnung the value of ki i got the control without any under shoot, over shoot and study time.
Hence the Simulink model for the DC motor is bulieded. And tested the controller to maintain a desired speed for the motor.